Related Experiment Video
Updated: May 7, 2026
Spatial Multiobjective Optimization of Agricultural Conservation Practices using a SWAT Model and an Evolutionary Algorithm
Published on: December 9, 2012
Convergence analysis of particle swarm optimizer and its improved algorithm based on velocity differential evolution
Hongtao Ye1, Wenguang Luo, Zhenqiang Li
1School of Electrical and Information Engineering, Guangxi University of Science and Technology, Liuzhou 545006, China. yehongtao@126.com

Abstract:
This paper presents an analysis of the relationship of particle velocity and convergence of the particle swarm optimization. Its premature convergence is due to the decrease of particle velocity in search space that leads to a total implosion and ultimately fitness stagnation of the swarm. An improved algorithm which introduces a velocity differential evolution (DE) strategy for the hierarchical particle swarm optimization (H-PSO) is proposed to improve its performance. The DE is employed to regulate the particle velocity rather than the traditional particle position in case that the optimal result has not improved after several iterations. The benchmark functions will be illustrated to demonstrate the effectiveness of the proposed method.
Related Concept Videos
 01:24
Relative Motion Analysis - Velocity
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
 01:11
Relative Velocity in Two Dimensions
 01:29
Distance Problem
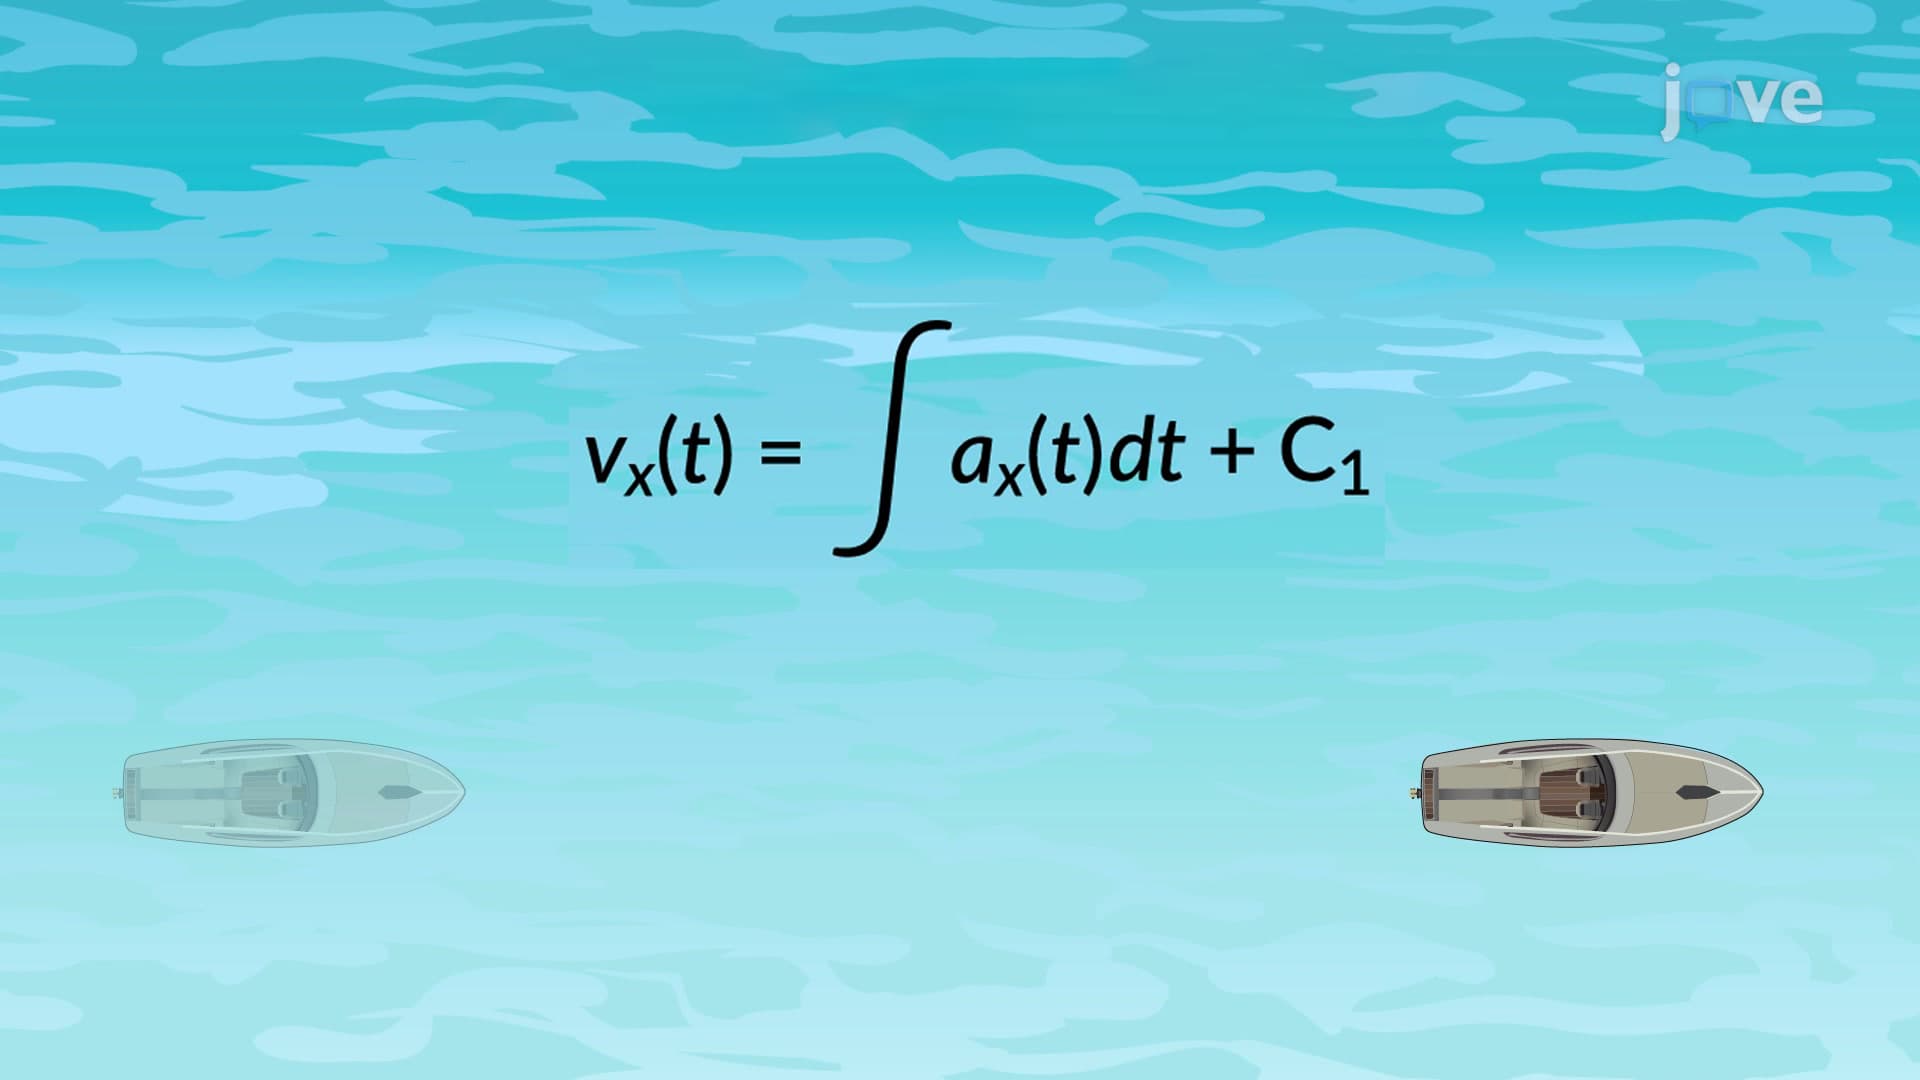 01:13
Velocity and Position by Integral Method
Consider an example to calculate the velocity and position from the acceleration function. A motorboat is traveling at a constant velocity of 5.0 m/s when it starts to decelerate to arrive at the dock. Its acceleration is...
 01:34
Velocity and Position by Graphical Method
 01:10
Relative Velocity in One Dimension