Related Experiment Video
Updated: May 6, 2026

The Impact of Motor Task Conditions on Goal-Directed Arm Reaching Kinematics and Trunk Compensation in Chronic Stroke Survivors
Published on: May 2, 2021
Energy-related optimal control accounts for gravitational load: comparing shoulder, elbow, and wrist rotations
Jérémie Gaveau1, Bastien Berret, Laurent Demougeot
1Université de Bourgogne, UFR STAPS, Dijon, France;

Abstract:
We permanently deal with gravity force. Experimental evidences revealed that moving against gravity strongly differs from moving along the gravity vector. This directional asymmetry has been attributed to an optimal planning process that optimizes gravity force effects to minimize energy. Yet, only few studies have considered the case of vertical movements in the context of optimal control. What kind of cost is better suited to explain kinematic patterns in the vertical plane? Here, we aimed to understand further how the central nervous system (CNS) plans and controls vertical arm movements. Our reasoning was the following: if the CNS optimizes gravity mechanical effects on the moving limbs, kinematic patterns should change according to the direction and the magnitude of the gravity torque being encountered in the motion. Ten subjects carried out single-joint movements, i.e., rotation around the shoulder (whole arm), elbow (forearm), and wrist (hand) joints, in the vertical plane. Joint kinematics were analyzed and compared with various theoretical optimal model predictions (minimum absolute work-jerk, jerk, torque change, and variance). We found both direction-dependent and joint-dependent variations in several kinematic parameters. Notably, directional asymmetries decreased according to a proximodistal gradient. Numerical simulations revealed that our experimental findings could be attributed to an optimal motor planning (minimum absolute work-jerk) that integrates the direction and the magnitude of gravity torque and minimizes the absolute work of forces (energy-related cost) around each joint. Present results support the general idea that the CNS implements optimal solutions according to the dynamic context of the action.
Related Concept Videos
 01:13
Stability of Equilibrium Configuration: Problem Solving
Problem-solving in the context of the stability of equilibrium configuration...
 01:11
Work-Energy Theorem for Rotational Motion
 01:10
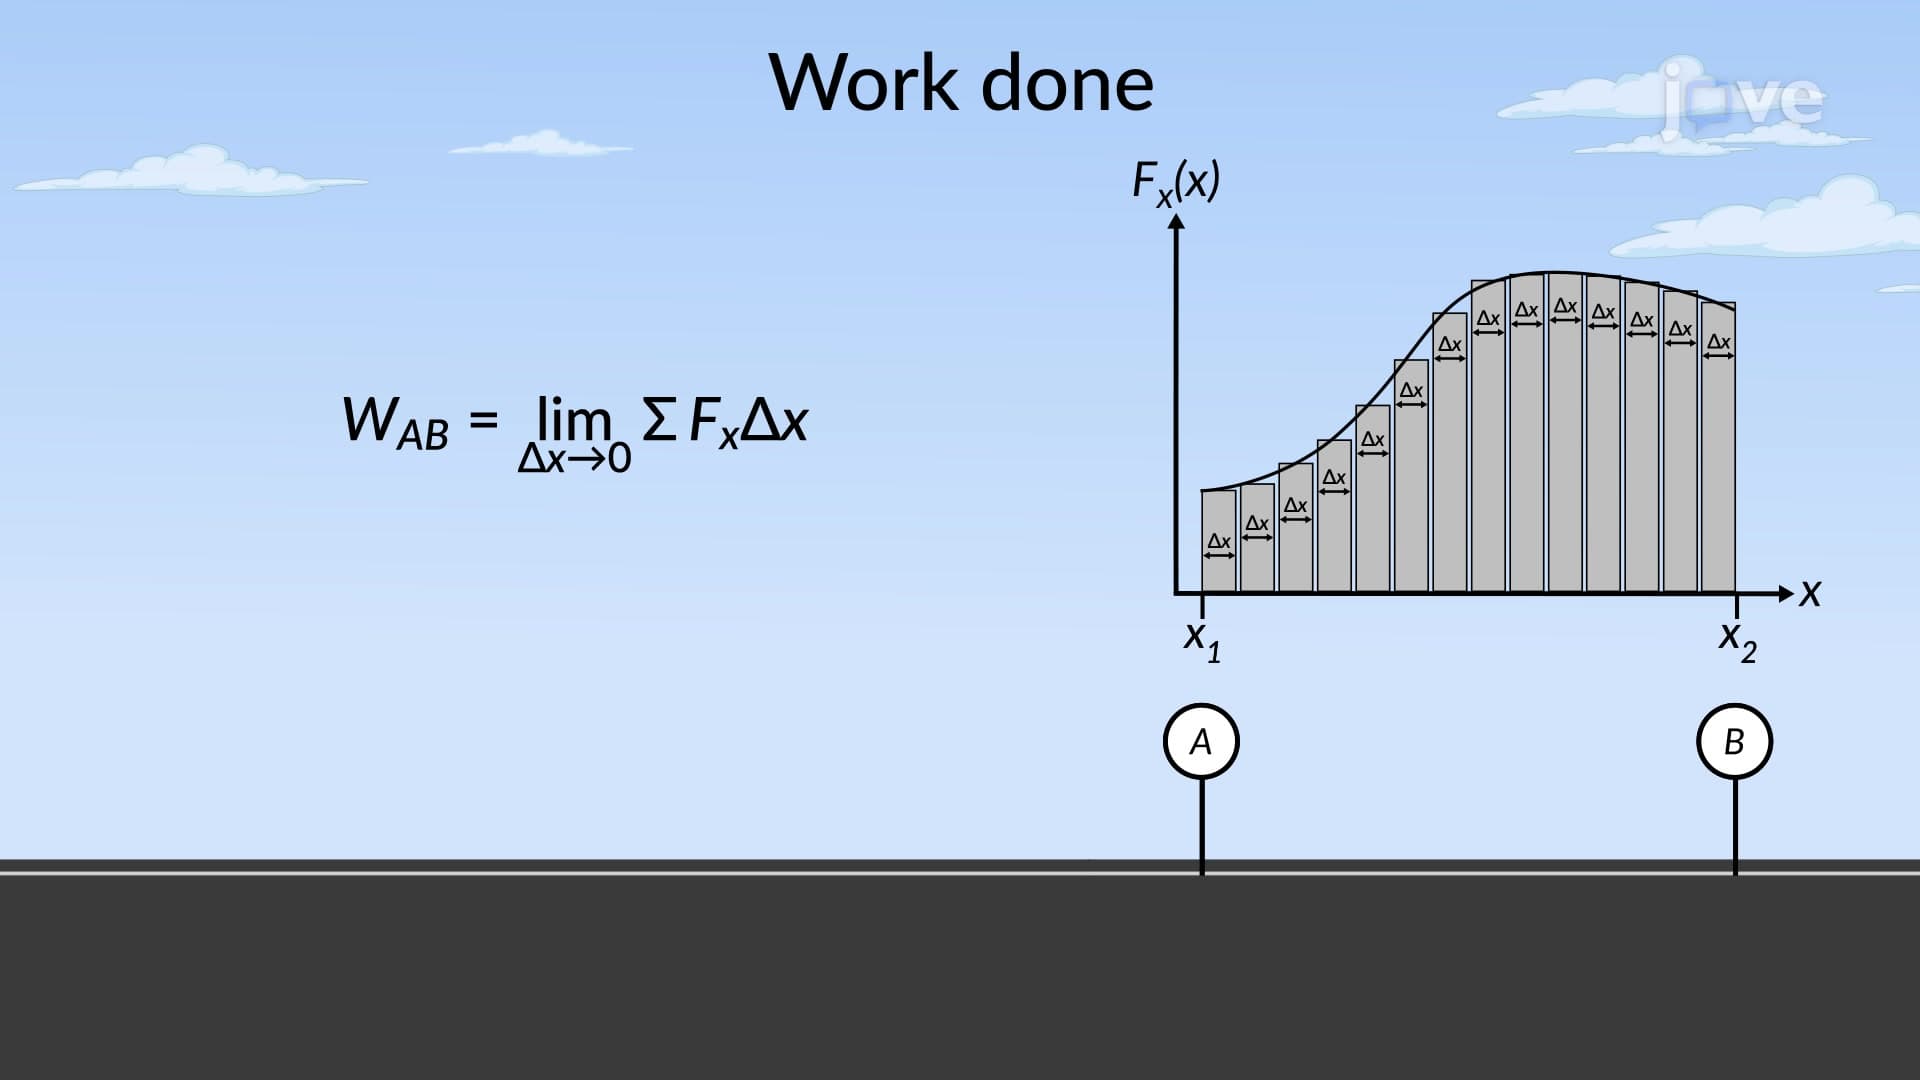
Work and Energy for Variable Forces
 01:28
Apparent Weight and the Earth's Rotation
For an object on the Earth's equator, the net centripetal force that accounts for its rotation is the Earth's pull towards its center, or the weight minus the normal force that prevents it from piercing into the Earth's surface....
 01:27
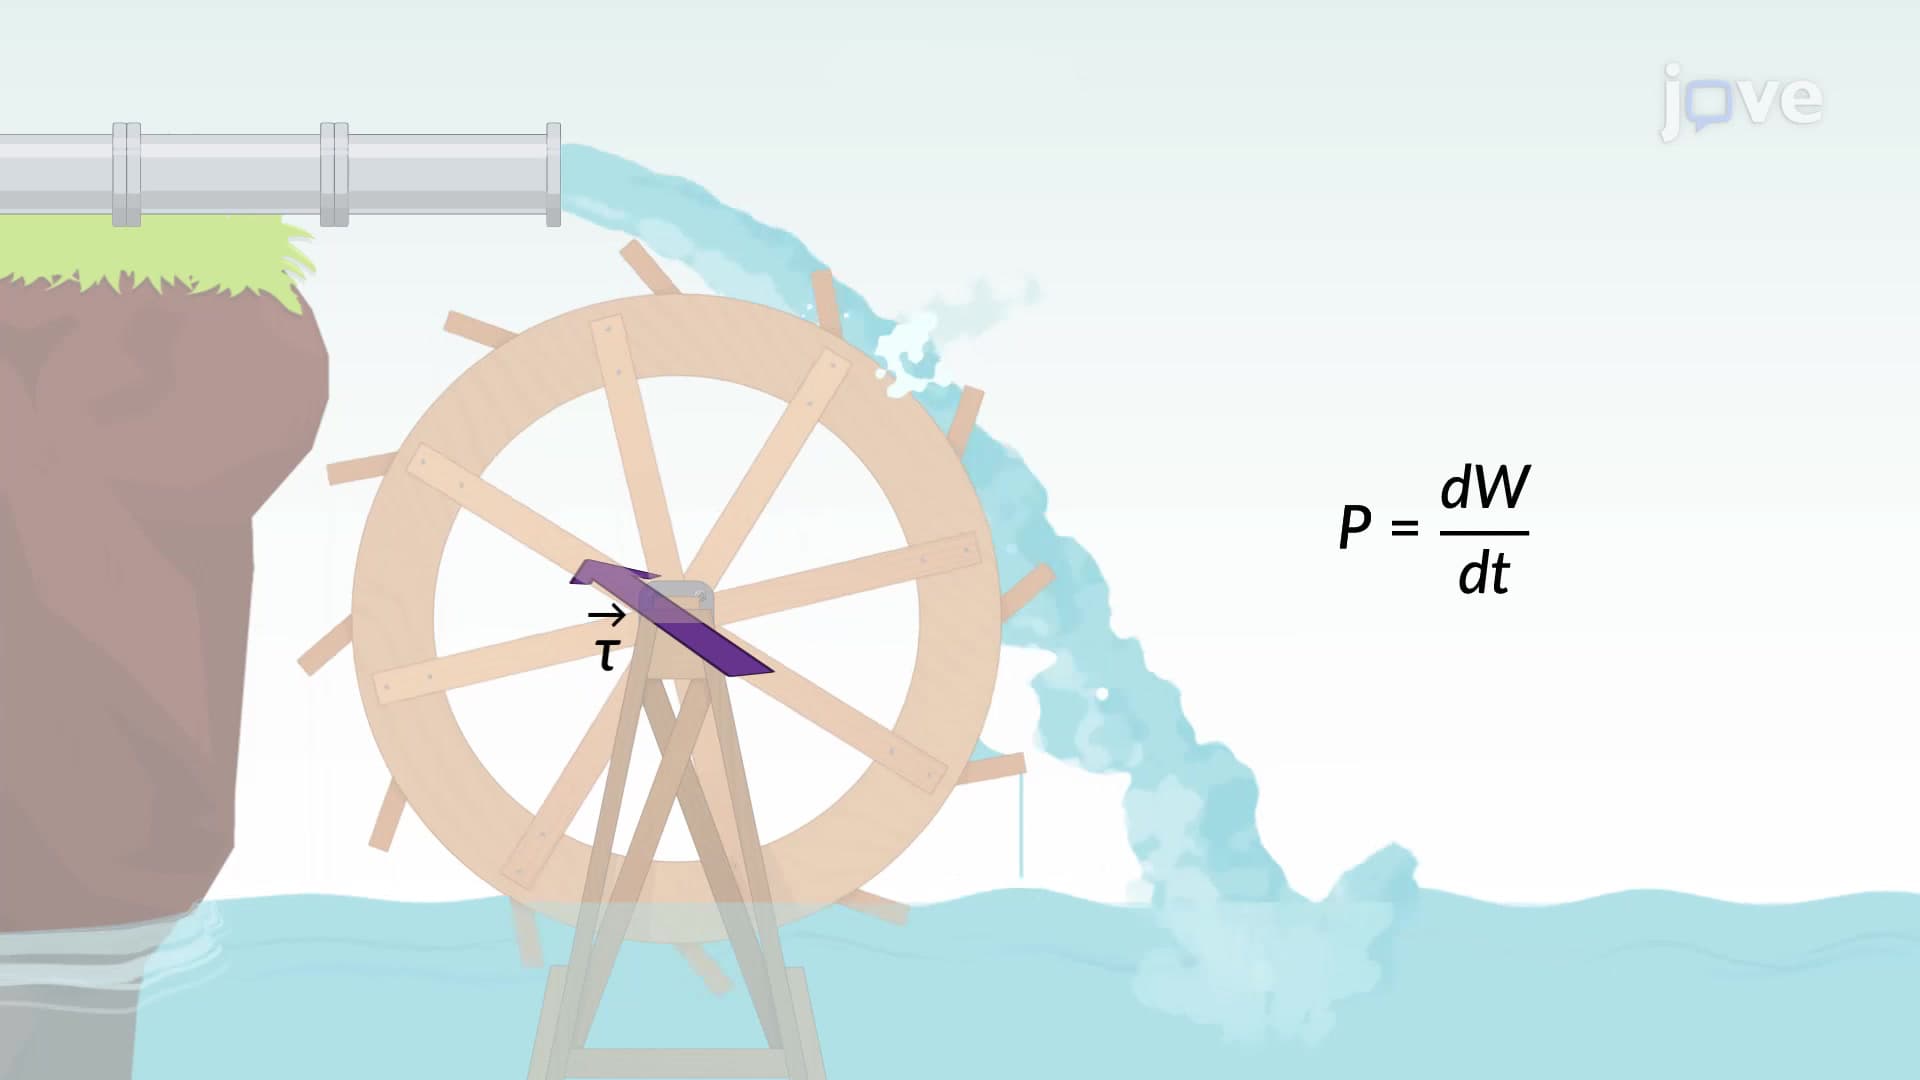
Work and Power for Rotational Motion
Similarly, the power delivered to a system that is rotating about a fixed axis...
 01:24
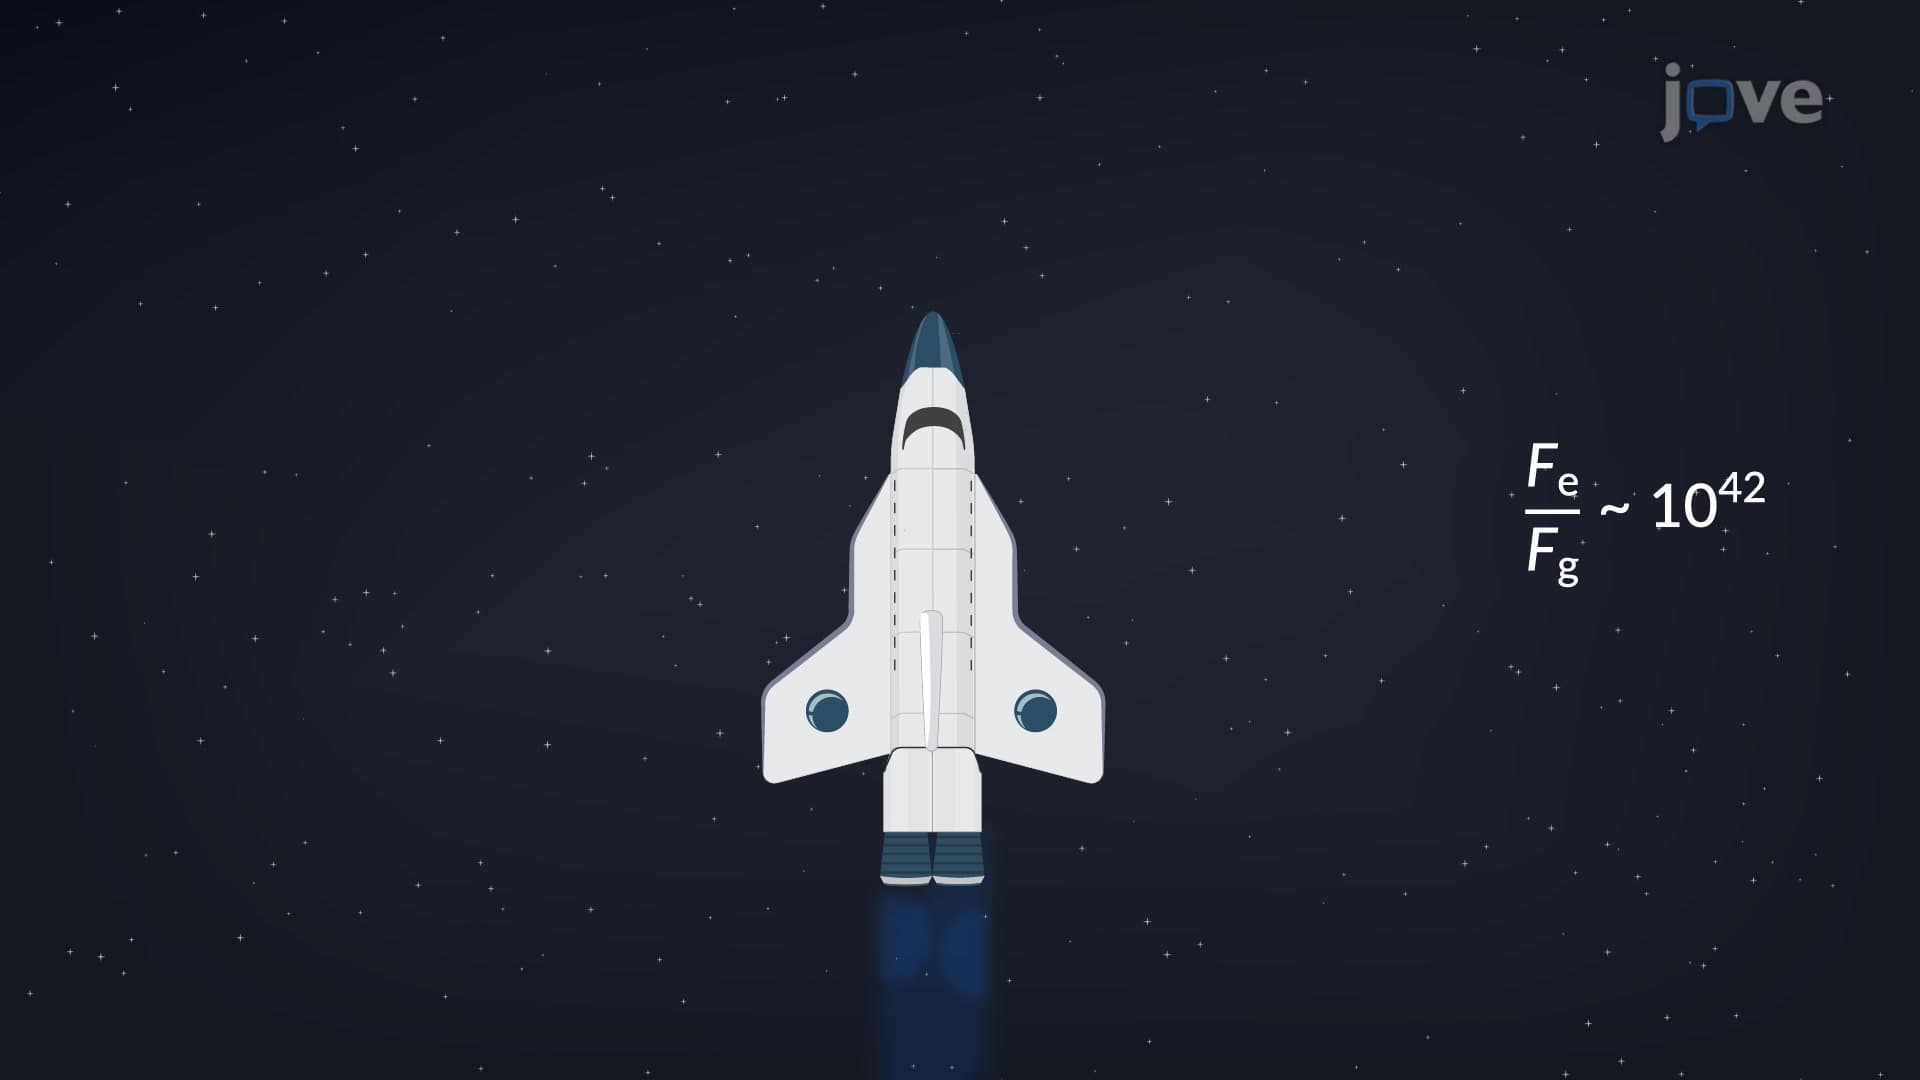
Comparison Between Electrical And Gravitational Forces
Since both are inverse square law forces, the distance gets canceled when the ratio of the two forces is considered. Instead, the ratio of the electrical and gravitational forces depends on...