Related Experiment Video
Updated: May 6, 2026
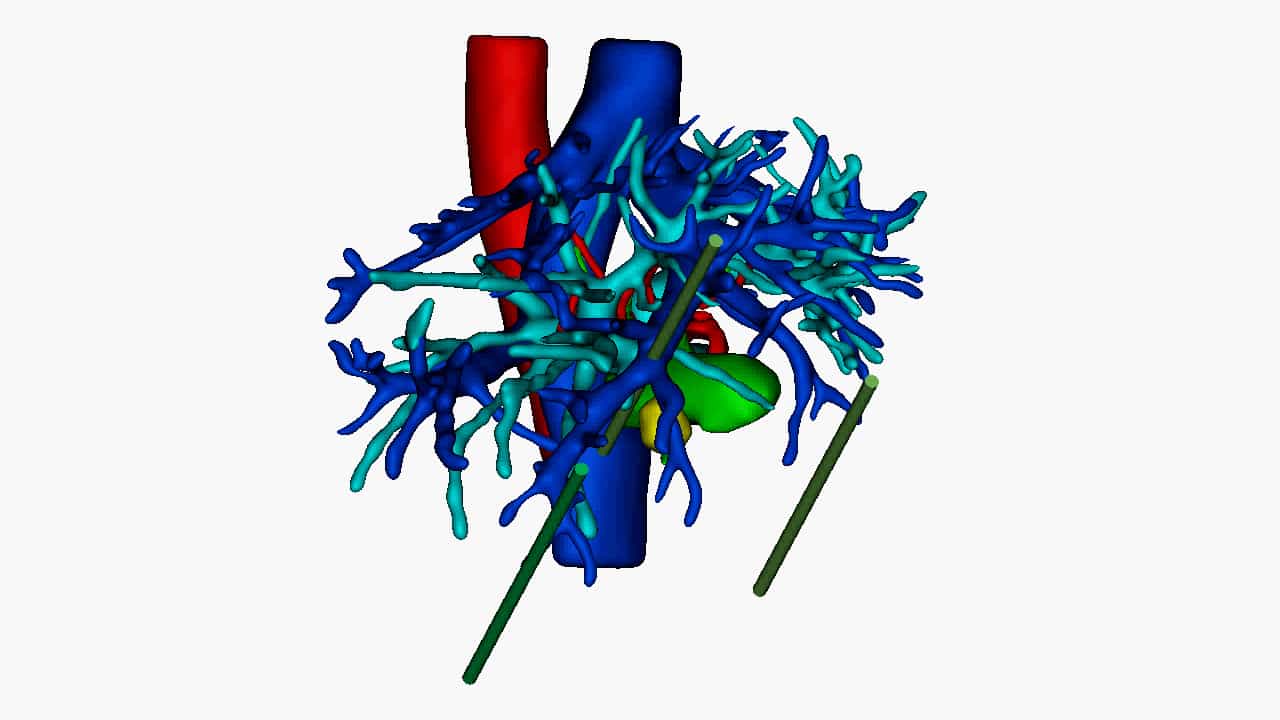

Three-dimensional Location Approach with Silk Thread Guided Laparoscopic Segmentectomy for Liver Tumor
Published on: May 23, 2025
Real-time image guidance in laparoscopic liver surgery: first clinical experience with a guidance system based on
Hannes G Kenngott1, Martin Wagner, Matthias Gondan
1Department of Surgery, University of Heidelberg, Im Neuenheimer Feld 110, 69120, Heidelberg, Germany, hannes.kenngott@med.uni-heidelberg.de.

Background:
Laparoscopic liver surgery is particularly challenging owing to restricted access, risk of bleeding, and lack of haptic feedback. Navigation systems have the potential to improve information on the exact position of intrahepatic tumors, and thus facilitate oncological resection. This study aims to evaluate the feasibility of a commercially available augmented reality (AR) guidance system employing intraoperative robotic C-arm cone-beam computed tomography (CBCT) for laparoscopic liver surgery.
Methods:
A human liver-like phantom with 16 target fiducials was used to evaluate the Syngo iPilot(®) AR system. Subsequently, the system was used for the laparoscopic resection of a hepatocellular carcinoma in segment 7 of a 50-year-old male patient.
Results:
In the phantom experiment, the AR system showed a mean target registration error of 0.96 ± 0.52 mm, with a maximum error of 2.49 mm. The patient successfully underwent the operation and showed no postoperative complications.
Conclusion:
The use of intraoperative CBCT and AR for laparoscopic liver resection is feasible and could be considered an option for future liver surgery in complex cases.
More Related Videos
 05:27
Laparoscopic Anatomical Hepatectomy Using Takasaki's Approach and Indocyanine Green Fluorescence Navigation
Published on: May 16, 2025
 09:21
A Novel Dual-Modal Deep Learning Approach for Real-Time Removal of Hepatic Fluorescence in Indocyanine Green-Guided Laparoscopic Cholecystectomy
Published on: April 17, 2026