Related Experiment Video
Updated: May 6, 2026


An Inertial Measurement Unit Based Method to Estimate Hip and Knee Joint Kinematics in Team Sport Athletes on the Field
Published on: May 26, 2020
A robust nonlinear observer for real-time attitude estimation using low-cost MEMS inertial sensors
José Fermi Guerrero-Castellanos1, Heberto Madrigal-Sastre, Sylvain Durand
1Faculty of Electronic, Autonomous University of Puebla (BUAP), Ciudad universitaria, Puebla 72570, Mexico. fguerrero@ece.buap.mx.

Abstract:
This paper deals with the attitude estimation of a rigid body equipped with angular velocity sensors and reference vector sensors. A quaternion-based nonlinear observer is proposed in order to fuse all information sources and to obtain an accurate estimation of the attitude. It is shown that the observer error dynamics can be separated into two passive subsystems connected in "feedback". Then, this property is used to show that the error dynamics is input-to-state stable when the measurement disturbance is seen as an input and the error as the state. These results allow one to affirm that the observer is "robustly stable". The proposed observer is evaluated in real-time with the design and implementation of an Attitude and Heading Reference System (AHRS) based on low-cost MEMS (Micro-Electro-Mechanical Systems) Inertial Measure Unit (IMU) and magnetic sensors and a 16-bit microcontroller. The resulting estimates are compared with a high precision motion system to demonstrate its performance.

Related Concept Videos
 01:02
Gyroscope
 01:24
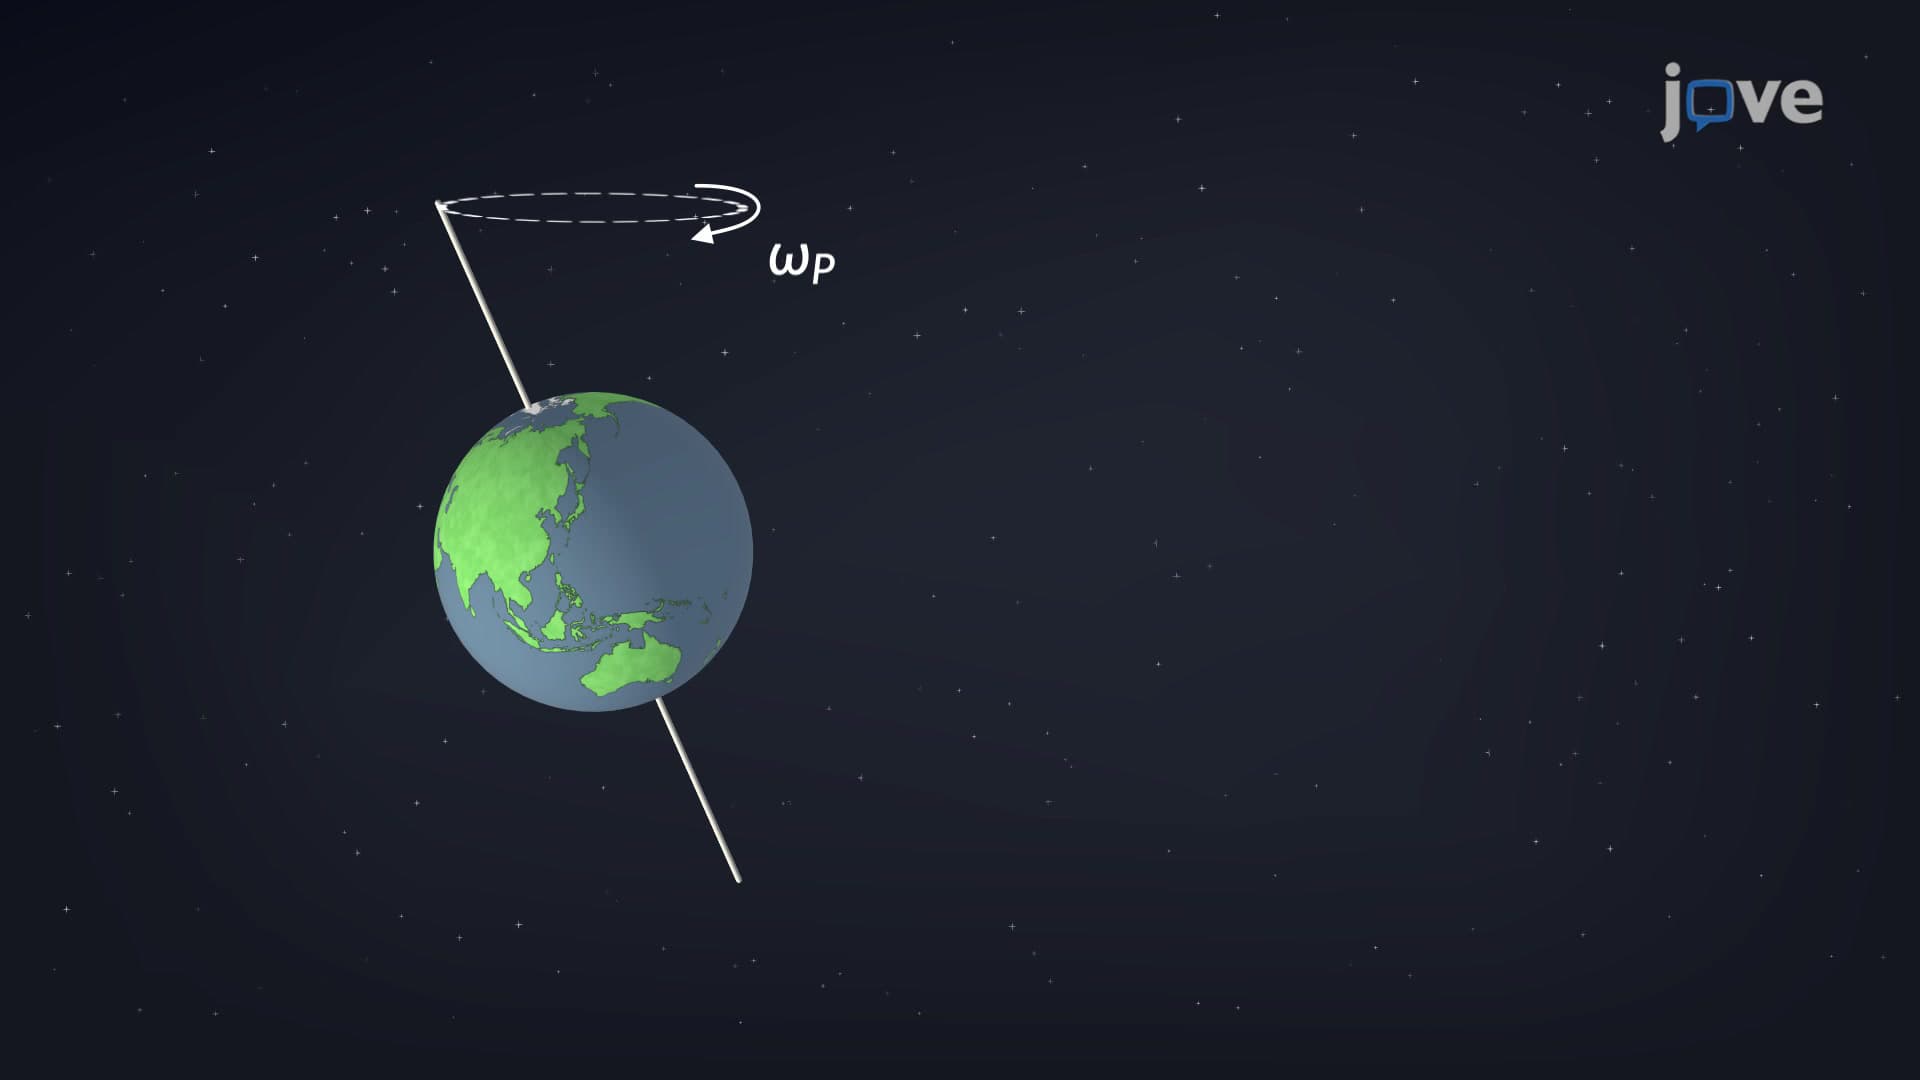
Gyroscope: Precession
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...
 01:03
Inertial Frames of Reference