Related Experiment Video
Updated: May 5, 2026

Data Acquisition Protocol for Determining Embedded Sensitivity Functions
Published on: April 20, 2016
Theoretical foundations for traditional and generalized sensitivity functions for nonlinear delay differential
H Thomas Banks1, Danielle Robbins, Karyn L Sutton
1Center for Research in Scientific Computation, Center for Quantitative Sciences in Biomedicine, Raleigh, NC 27695-8212, United States. htbanks@ncsu.edu.

Abstract:
In this paper we present new results for differentiability of delay systems with respect to initial conditions and delays. After motivating our results with a wide range of delay examples arising in biology applications, we further note the need for sensitivity functions (both traditional and generalized sensitivity functions), especially in control and estimation problems. We summarize general existence and uniqueness results before turning to our main results on differentiation with respect to delays, etc. Finally we discuss use of our results in the context of estimation problems.
Related Concept Videos
 01:26
Linear Approximation in Frequency Domain
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
 01:26
Classification of Systems-I
Homogeneity dictates that if an input x(t) is multiplied by a constant c, the output y(t) is multiplied by the same constant. Mathematically, this is expressed as:
 01:18
Second Order systems II
 01:20
Introduction to Differential Equations
 01:21
First Order Systems
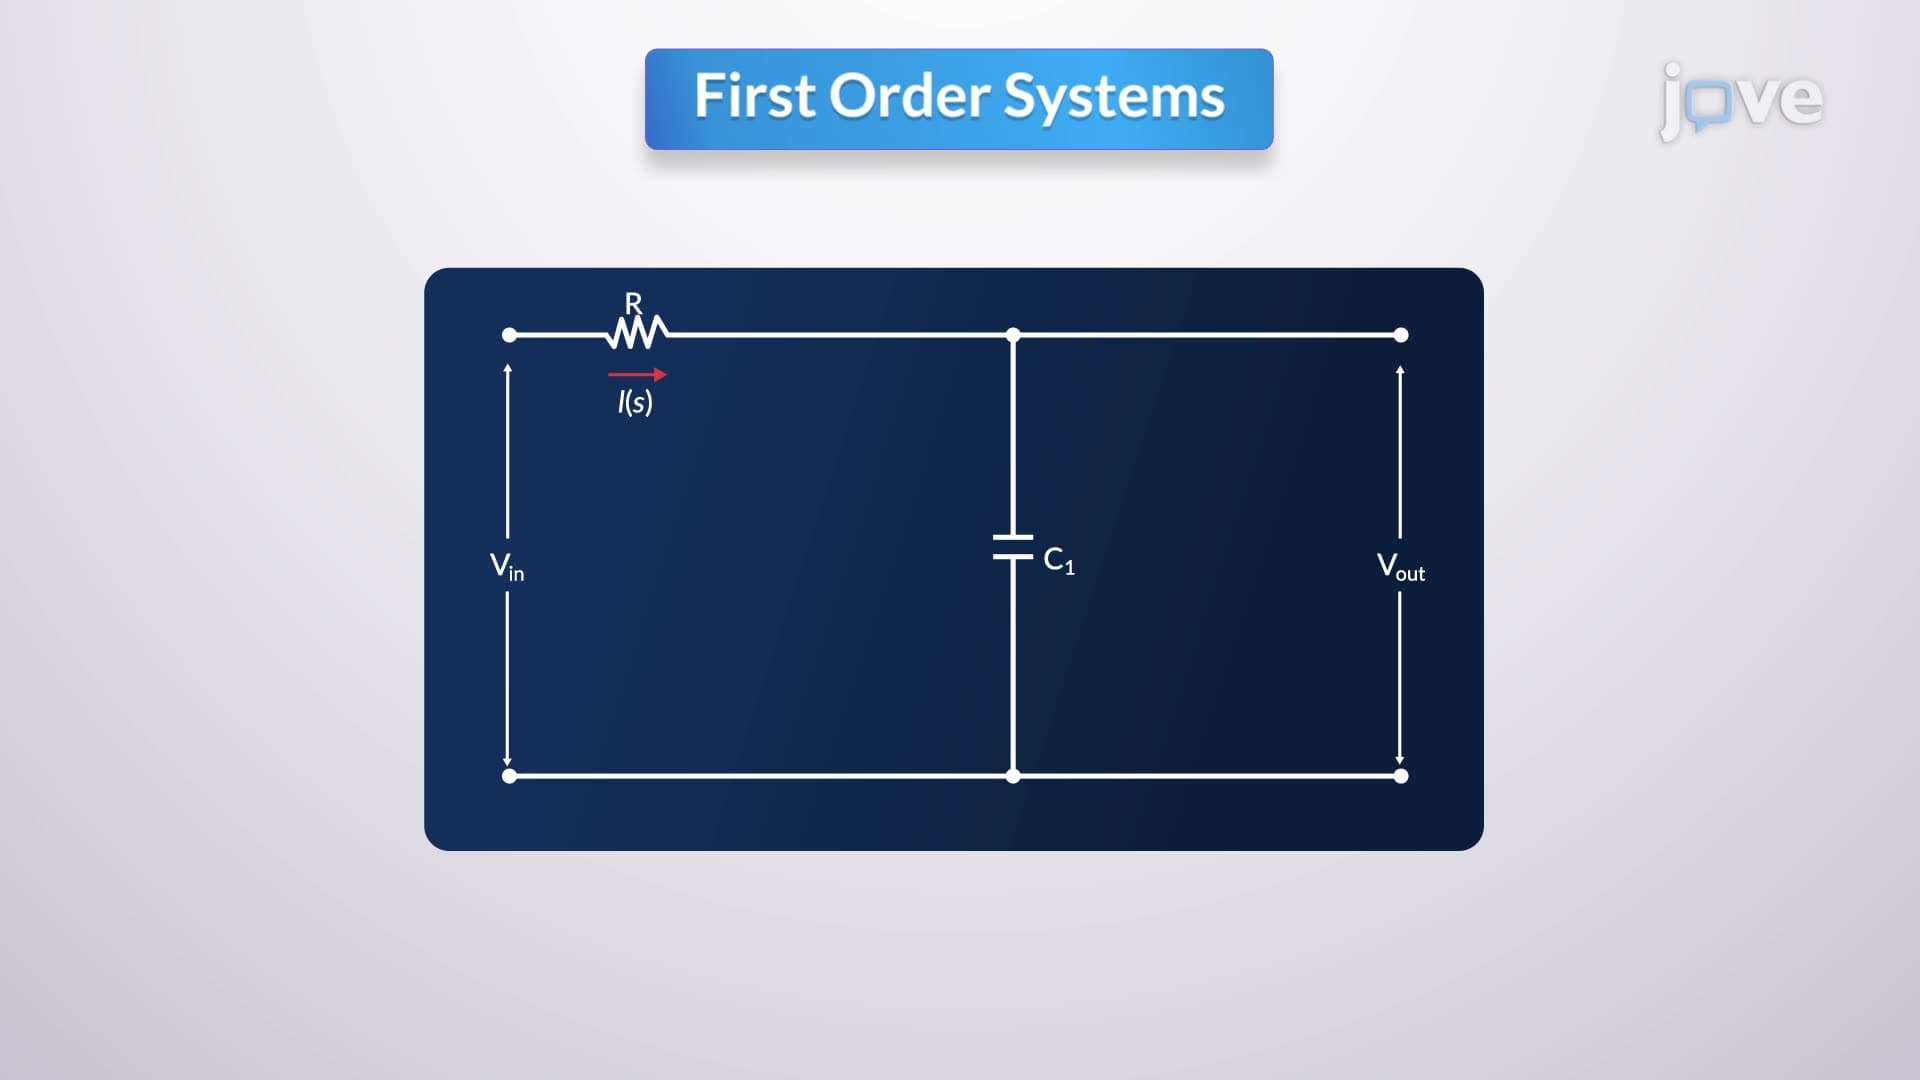
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...
 01:11
Types of Responses of Series RLC Circuits