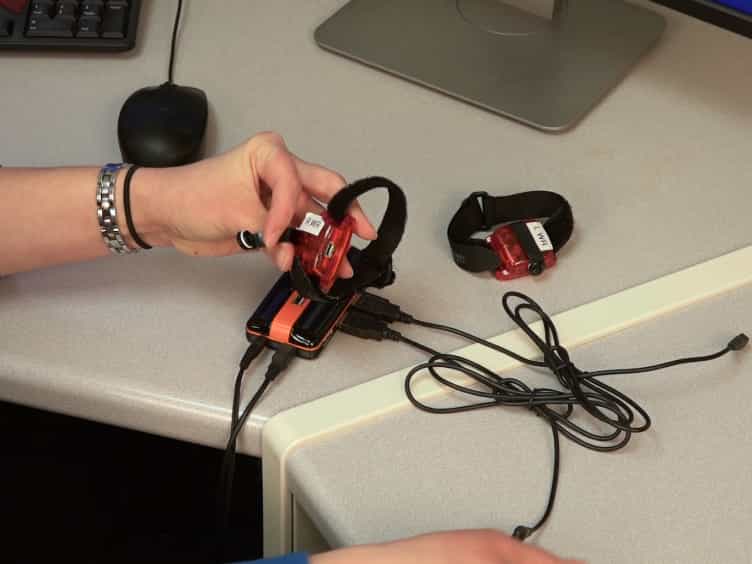
Related Experiment Video
Updated: May 5, 2026


An Inertial Measurement Unit Based Method to Estimate Hip and Knee Joint Kinematics in Team Sport Athletes on the Field
Published on: May 26, 2020
Effectiveness of variable-gain Kalman filter based on angle error calculated from acceleration signals in lower limb
Yuta Teruyama1, Takashi Watanabe
1Graduate School of Biomedical Engineering, Tohoku University, Sendai 980-8579, Japan.

Abstract:
The wearable sensor system developed by our group, which measured lower limb angles using Kalman-filtering-based method, was suggested to be useful in evaluation of gait function for rehabilitation support. However, it was expected to reduce variations of measurement errors. In this paper, a variable-Kalman-gain method based on angle error that was calculated from acceleration signals was proposed to improve measurement accuracy. The proposed method was tested comparing to fixed-gain Kalman filter and a variable-Kalman-gain method that was based on acceleration magnitude used in previous studies. First, in angle measurement in treadmill walking, the proposed method measured lower limb angles with the highest measurement accuracy and improved significantly foot inclination angle measurement, while it improved slightly shank and thigh inclination angles. The variable-gain method based on acceleration magnitude was not effective for our Kalman filter system. Then, in angle measurement of a rigid body model, it was shown that the proposed method had measurement accuracy similar to or higher than results seen in other studies that used markers of camera-based motion measurement system fixing on a rigid plate together with a sensor or on the sensor directly. The proposed method was found to be effective in angle measurement with inertial sensors.
Related Concept Videos
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...
 01:11
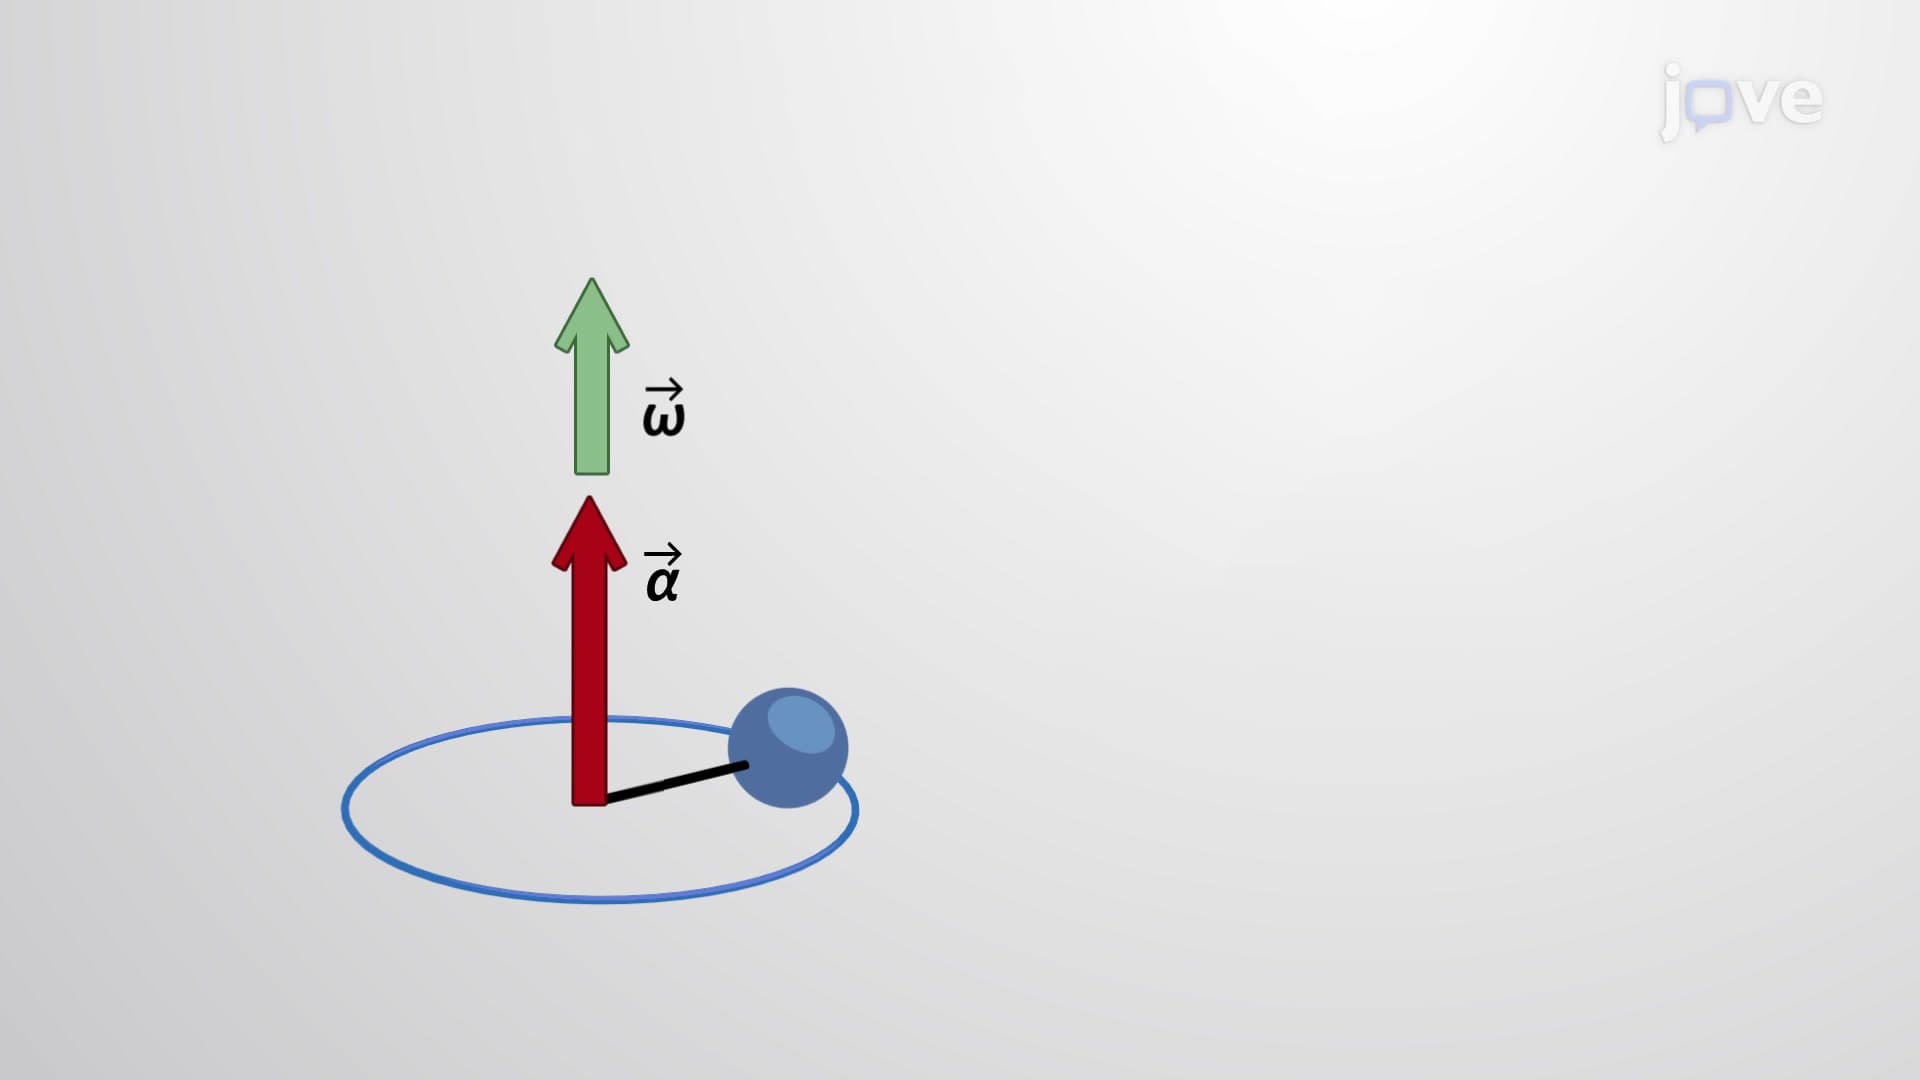
Angular Velocity and Acceleration
 01:10
Relative Motion Analysis - Acceleration
 01:12
Measuring Acceleration Due to Gravity
A simple pendulum can be described as a point mass and a string. Meanwhile, a physical pendulum is any object whose oscillations are similar to a simple pendulum, but cannot be modeled as a point mass on a string because its mass is distributed over a larger area. The behavior of a physical pendulum can be modeled using the principles of...