Related Experiment Video
Updated: May 5, 2026

Basics of Multivariate Analysis in Neuroimaging Data
Published on: July 24, 2010
On Kolmogorov Asymptotics of Estimators of the Misclassification Error Rate in Linear Discriminant Analysis
Amin Zollanvari1, Marc G Genton
1Department of Statistics and Department of Electrical and Computer Engineering, Texas A&M University, College Station, TX 77843, USA.

Abstract:
We provide a fundamental theorem that can be used in conjunction with Kolmogorov asymptotic conditions to derive the first moments of well-known estimators of the actual error rate in linear discriminant analysis of a multivariate Gaussian model under the assumption of a common known covariance matrix. The estimators studied in this paper are plug-in and smoothed resubstitution error estimators, both of which have not been studied before under Kolmogorov asymptotic conditions. As a result of this work, we present an optimal smoothing parameter that makes the smoothed resubstitution an unbiased estimator of the true error. For the sake of completeness, we further show how to utilize the presented fundamental theorem to achieve several previously reported results, namely the first moment of the resubstitution estimator and the actual error rate. We provide numerical examples to show the accuracy of the succeeding finite sample approximations in situations where the number of dimensions is comparable or even larger than the sample size.
Related Concept Videos
 01:19
Expected Frequencies in Goodness-of-Fit Tests
 01:15
Chebyshev's Theorem to Interpret Standard Deviation
 01:29
Mechanistic Models: Compartment Models in Algorithms for Numerical Problem Solving
In individual population analyses, different algorithms are employed, such as Cauchy's method, which uses a...
 01:19
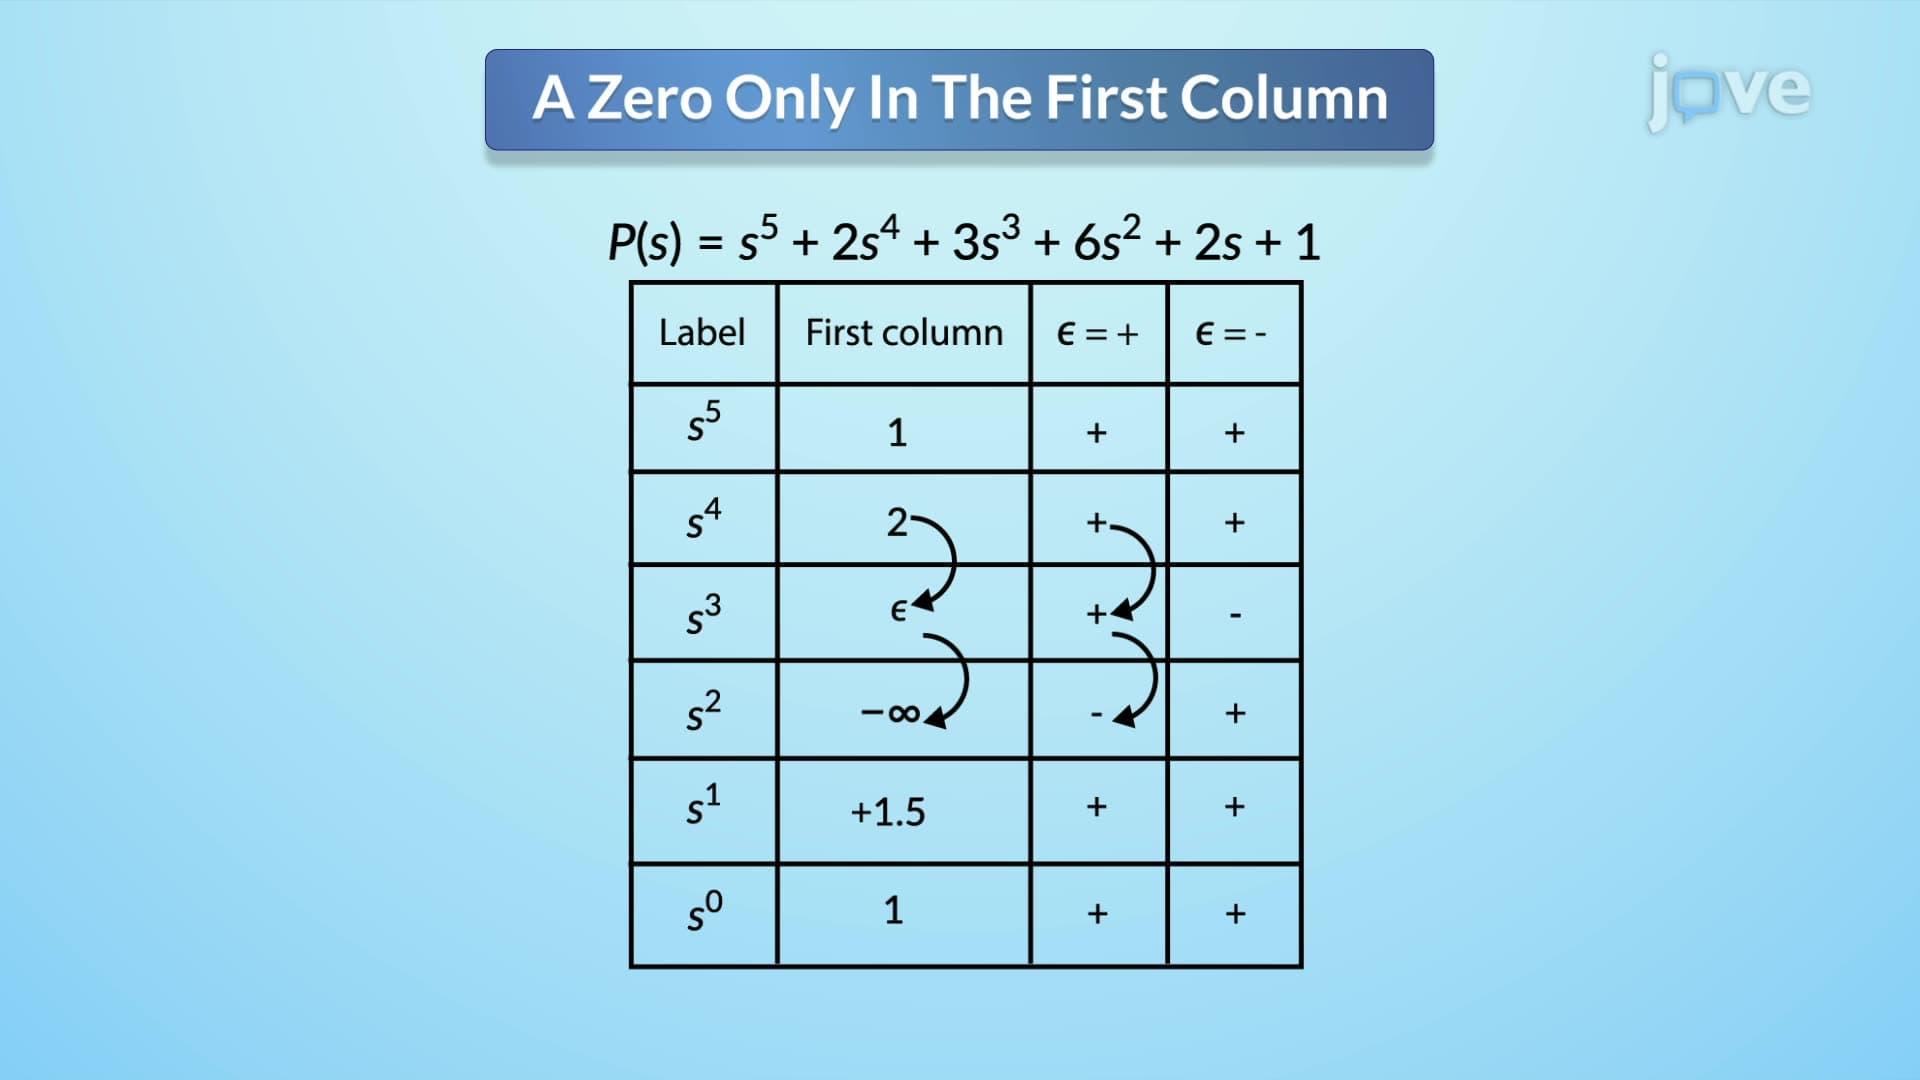
Routh-Hurwitz Criterion II
The first scenario occurs when a singular zero appears in the first column of the Routh table. This situation creates a division by zero issues. To resolve this, a small positive or negative number, denoted as epsilon (∈), is substituted for the zero. The stability analysis proceeds by assuming a sign for ∈. If ∈ is positive, any sign change in the first...
 01:29
Application of Linearization and Approximation
 01:13
Accuracy and Errors in Hypothesis Testing
In hypothesis testing, the probability of making a Type I error, denoted as α, is commonly set at 0.05. This significance level indicates a 5%...