Extended space method for parameter identifiability of DAE systems

Li Chen1, Xi Chen1, Jixin Qian1
1State Key Laboratory of Industrial Control Technology, Department of Control Science & Engineering, Zhejiang University, Hangzhou 310027, China.

Abstract:
Mathematical models of physical systems often have parameters that must be identified from physical data. This makes the analysis of the parameter identifiability of the given model system an essential prerequisite. Thus far, several methods have been proposed for analyzing the parameter identifiability of ordinary differential equation (ODE) systems. But, to the best of our knowledge, the parameter identifiability of differential algebraic equation (DAE) systems has scarcely been analyzed as a specific topic. Traditional differential algebraic (DA) methods developed for ODE systems are often applied directly on DAE systems. These methods, however, are not always applicable, e.g., when the prime ideal condition is not satisfied by a DAE system. In this paper, we propose a novel method to analyze the identifiability of DAE systems, based on the concept of space extension, through which the algebraic and differential variables can be decoupled. Furthermore, an inherent, low-dimensional, regular ODE system can be obtained, which is the external equivalent of the original DAE system. Subsequently, the differential algebraic (DA) method can then be used to analyze the identifiability of the low-dimension ODE system. Theoretical analysis is also presented for the proposed method. Two examples, including a simplified interaction model and an isothermal reactor system, are presented to illustrate the detailed steps and effectiveness of the proposed method.

Related Concept Videos
 01:27
State Space Representation
Consider an RLC circuit, a...
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:21
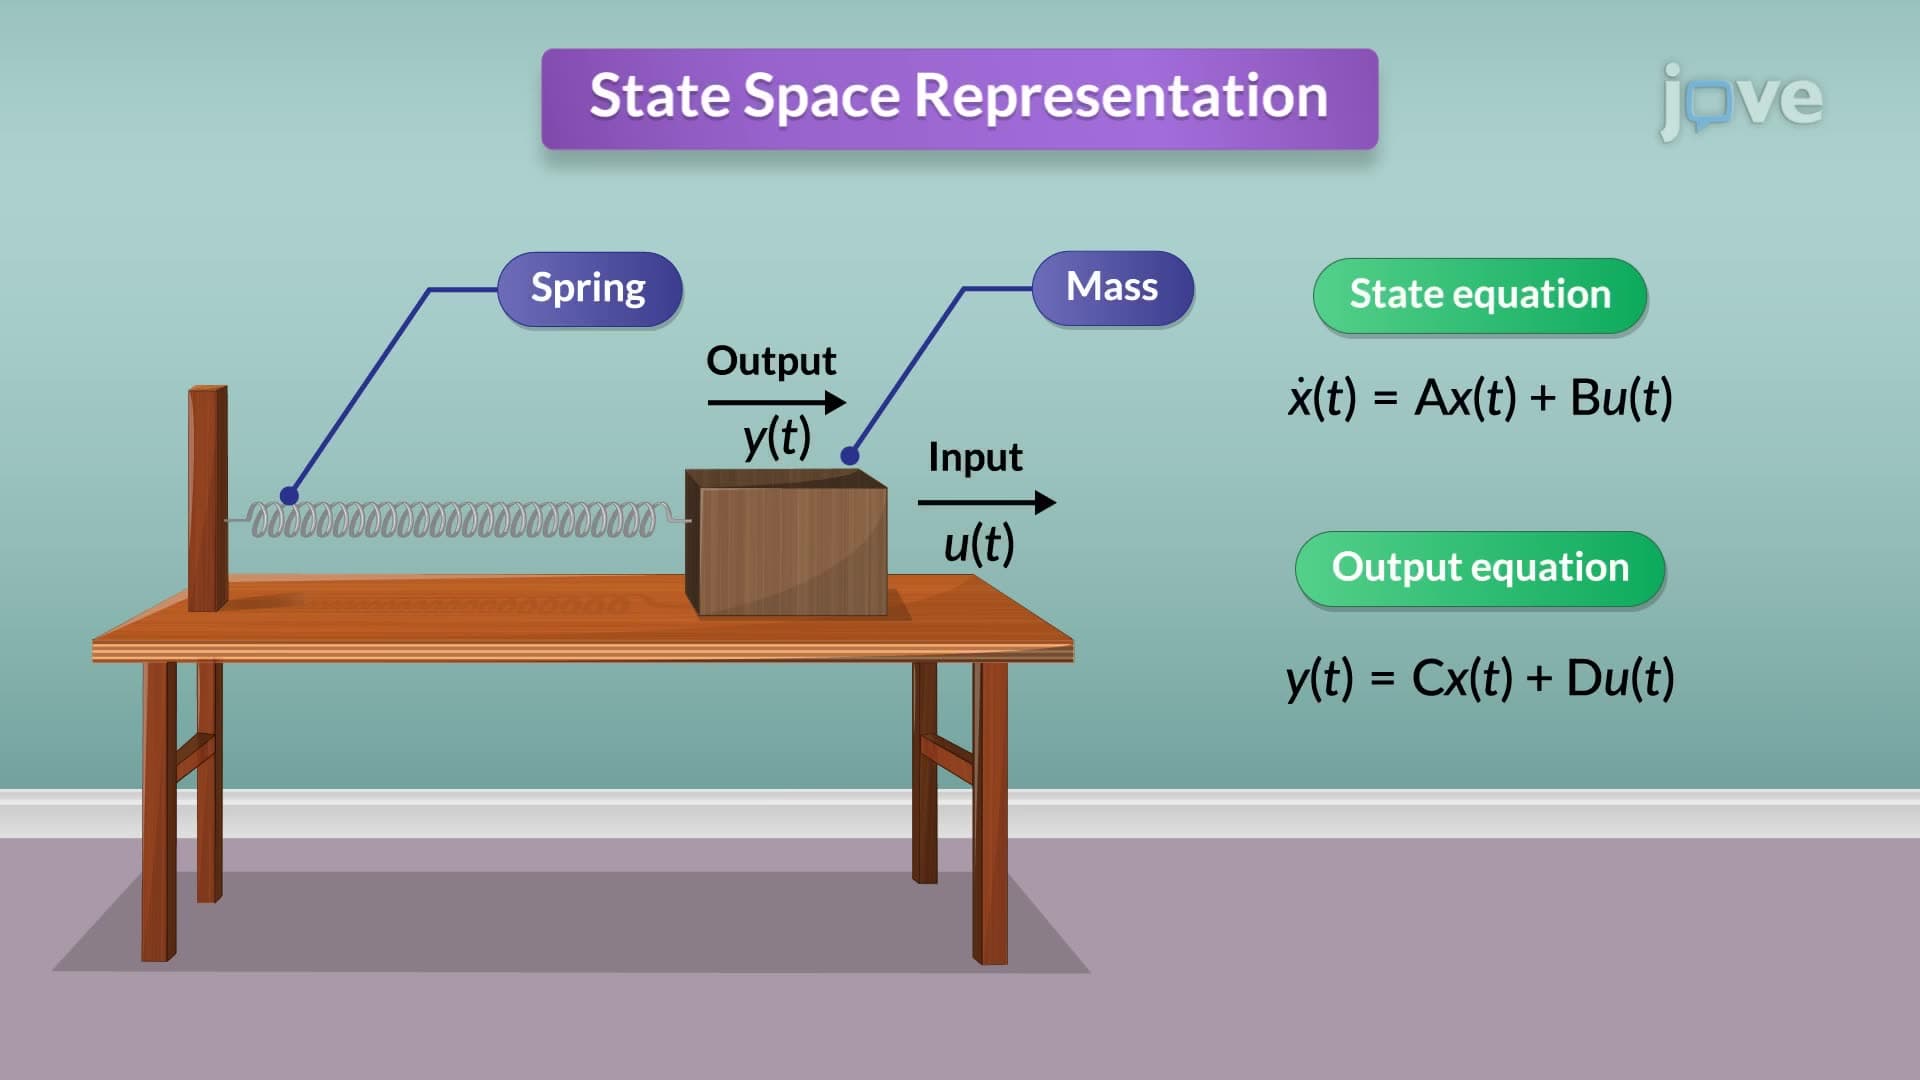
State Space to Transfer Function
The transformation process begins with the state-space representation, characterized by the state equation and the output equation. These equations are typically represented as:
 01:20
Separable Differential Equations
 01:22
Multi-input and Multi-variable systems
In the absence of...
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...