Robust master-slave synchronization for general uncertain delayed dynamical model based on adaptive control scheme

Tianbo Wang1, Wuneng Zhou2, Shouwei Zhao1
1College of Fundamental Studies, Shanghai University of Engineering Science, Shanghai 201620, PR China.

Abstract:
In this paper, the robust exponential synchronization problem for a class of uncertain delayed master-slave dynamical system is investigated by using the adaptive control method. Different from some existing master-slave models, the considered master-slave system includes bounded unmodeled dynamics. In order to compensate the effect of unmodeled dynamics and effectively achieve synchronization, a novel adaptive controller with simple updated laws is proposed. Moreover, the results are given in terms of LMIs, which can be easily solved by LMI Toolbox in Matlab. A numerical example is given to illustrate the effectiveness of the method.


Related Concept Videos
 01:30
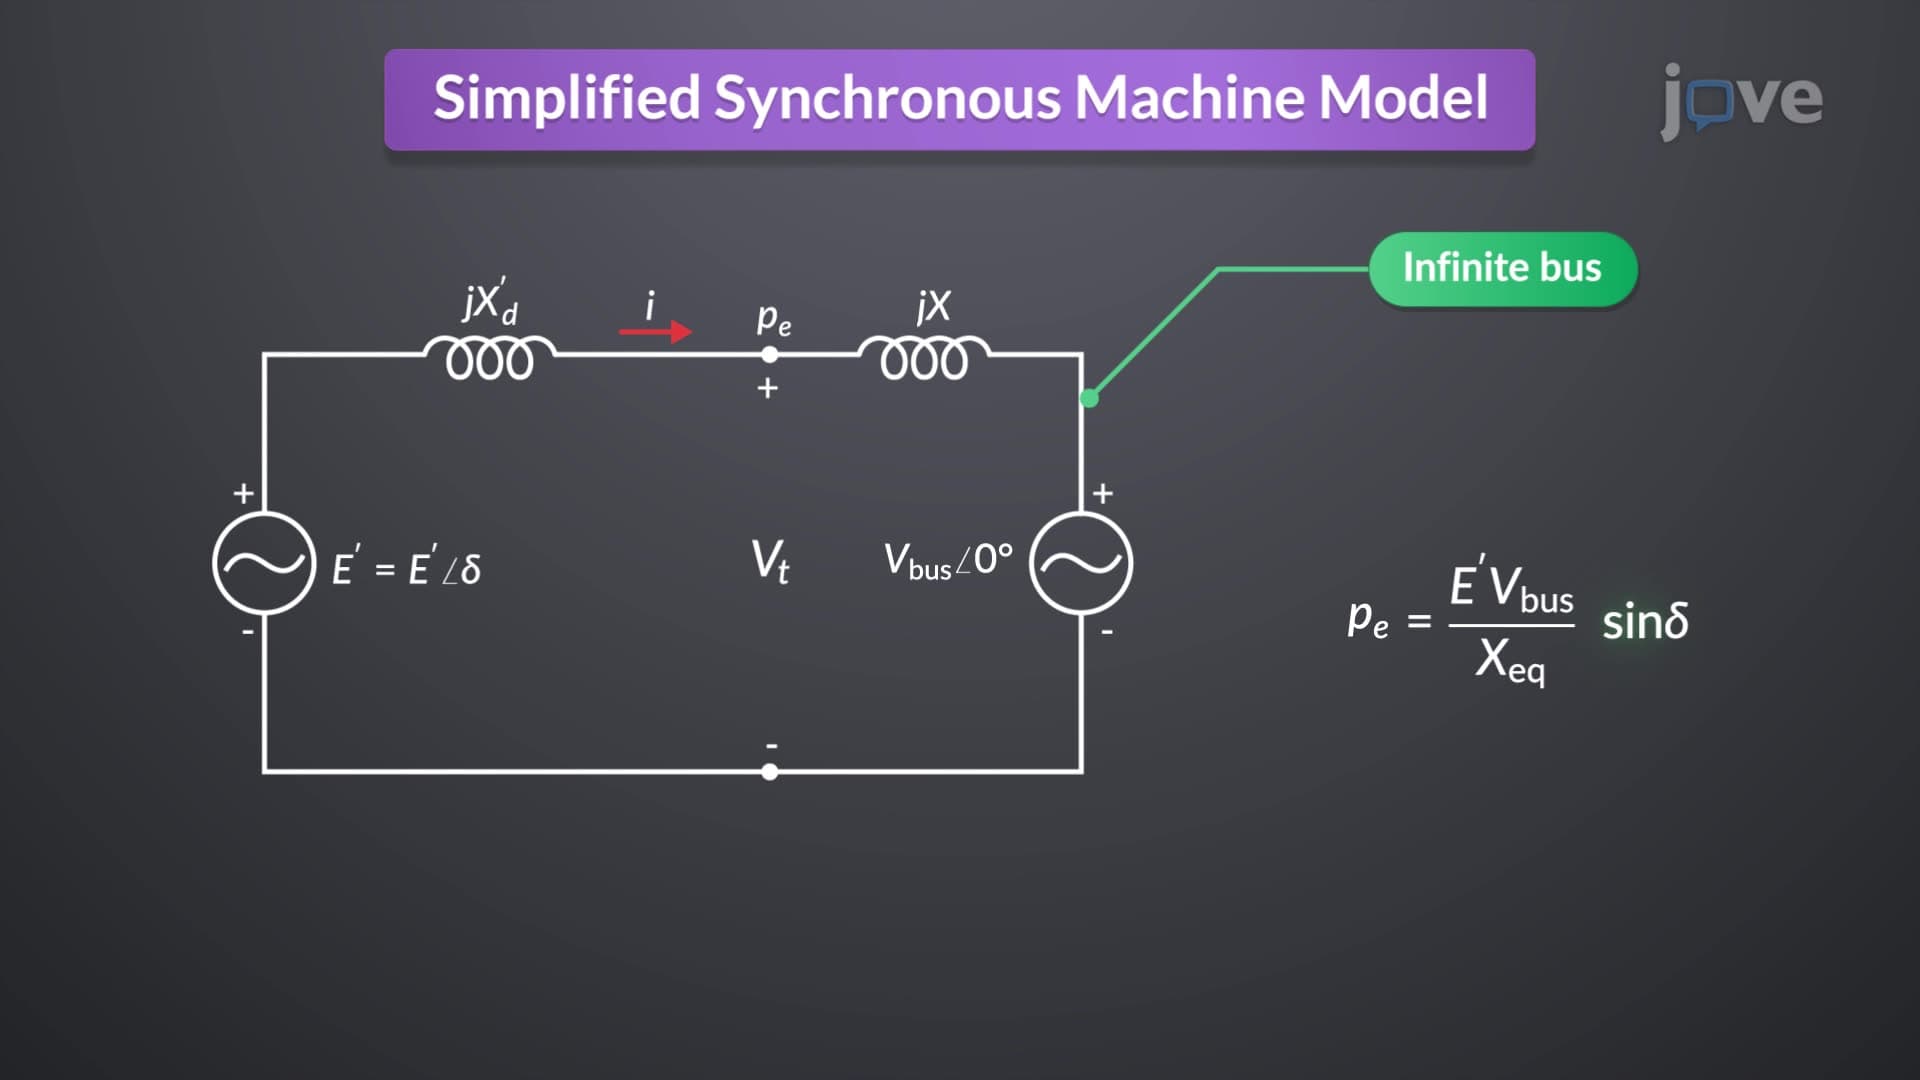
Simplified Synchronous Machine Model
In this model, each generator is connected to a...
 01:24
BIBO stability of continuous and discrete -time systems
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system....
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:25
Multimachine Stability
In analyzing the system, the nodal equations represent the relationship between bus voltages, machine voltages, and machine currents. The nodal equation is given by:
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...