Related Experiment Video
Updated: May 3, 2026
Subject-specific Musculoskeletal Model for Studying Bone Strain During Dynamic Motion
Published on: April 11, 2018
One-degree-of-freedom spherical model for the passive motion of the human ankle joint
Nicola Sancisi1, Benedetta Baldisserri, Vincenzo Parenti-Castelli
1DIN-Department of Industrial Engineering, University of Bologna, Viale del Risorgimento 2, 40136, Bologna, Italy, nicola.sancisi@unibo.it.

Abstract:
Mathematical modelling of mobility at the human ankle joint is essential for prosthetics and orthotic design. The scope of this study is to show that the ankle joint passive motion can be represented by a one-degree-of-freedom spherical motion. Moreover, this motion is modelled by a one-degree-of-freedom spherical parallel mechanism model, and the optimal pivot-point position is determined. Passive motion and anatomical data were taken from in vitro experiments in nine lower limb specimens. For each of these, a spherical mechanism, including the tibiofibular and talocalcaneal segments connected by a spherical pair and by the calcaneofibular and tibiocalcaneal ligament links, was defined from the corresponding experimental kinematics and geometry. An iterative procedure was used to optimize the geometry of the model, able to predict original experimental motion. The results of the simulations showed a good replication of the original natural motion, despite the numerous model assumptions and simplifications, with mean differences between experiments and predictions smaller than 1.3 mm (average 0.33 mm) for the three joint position components and smaller than 0.7° (average 0.32°) for the two out-of-sagittal plane rotations, once plotted versus the full flexion arc. The relevant pivot-point position after model optimization was found within the tibial mortise, but not exactly in a central location. The present combined experimental and modelling analysis of passive motion at the human ankle joint shows that a one degree-of-freedom spherical mechanism predicts well what is observed in real joints, although its computational complexity is comparable to the standard hinge joint model.
Related Concept Videos
 01:10
Ankle Joint
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:09
Functional Classification of Joints
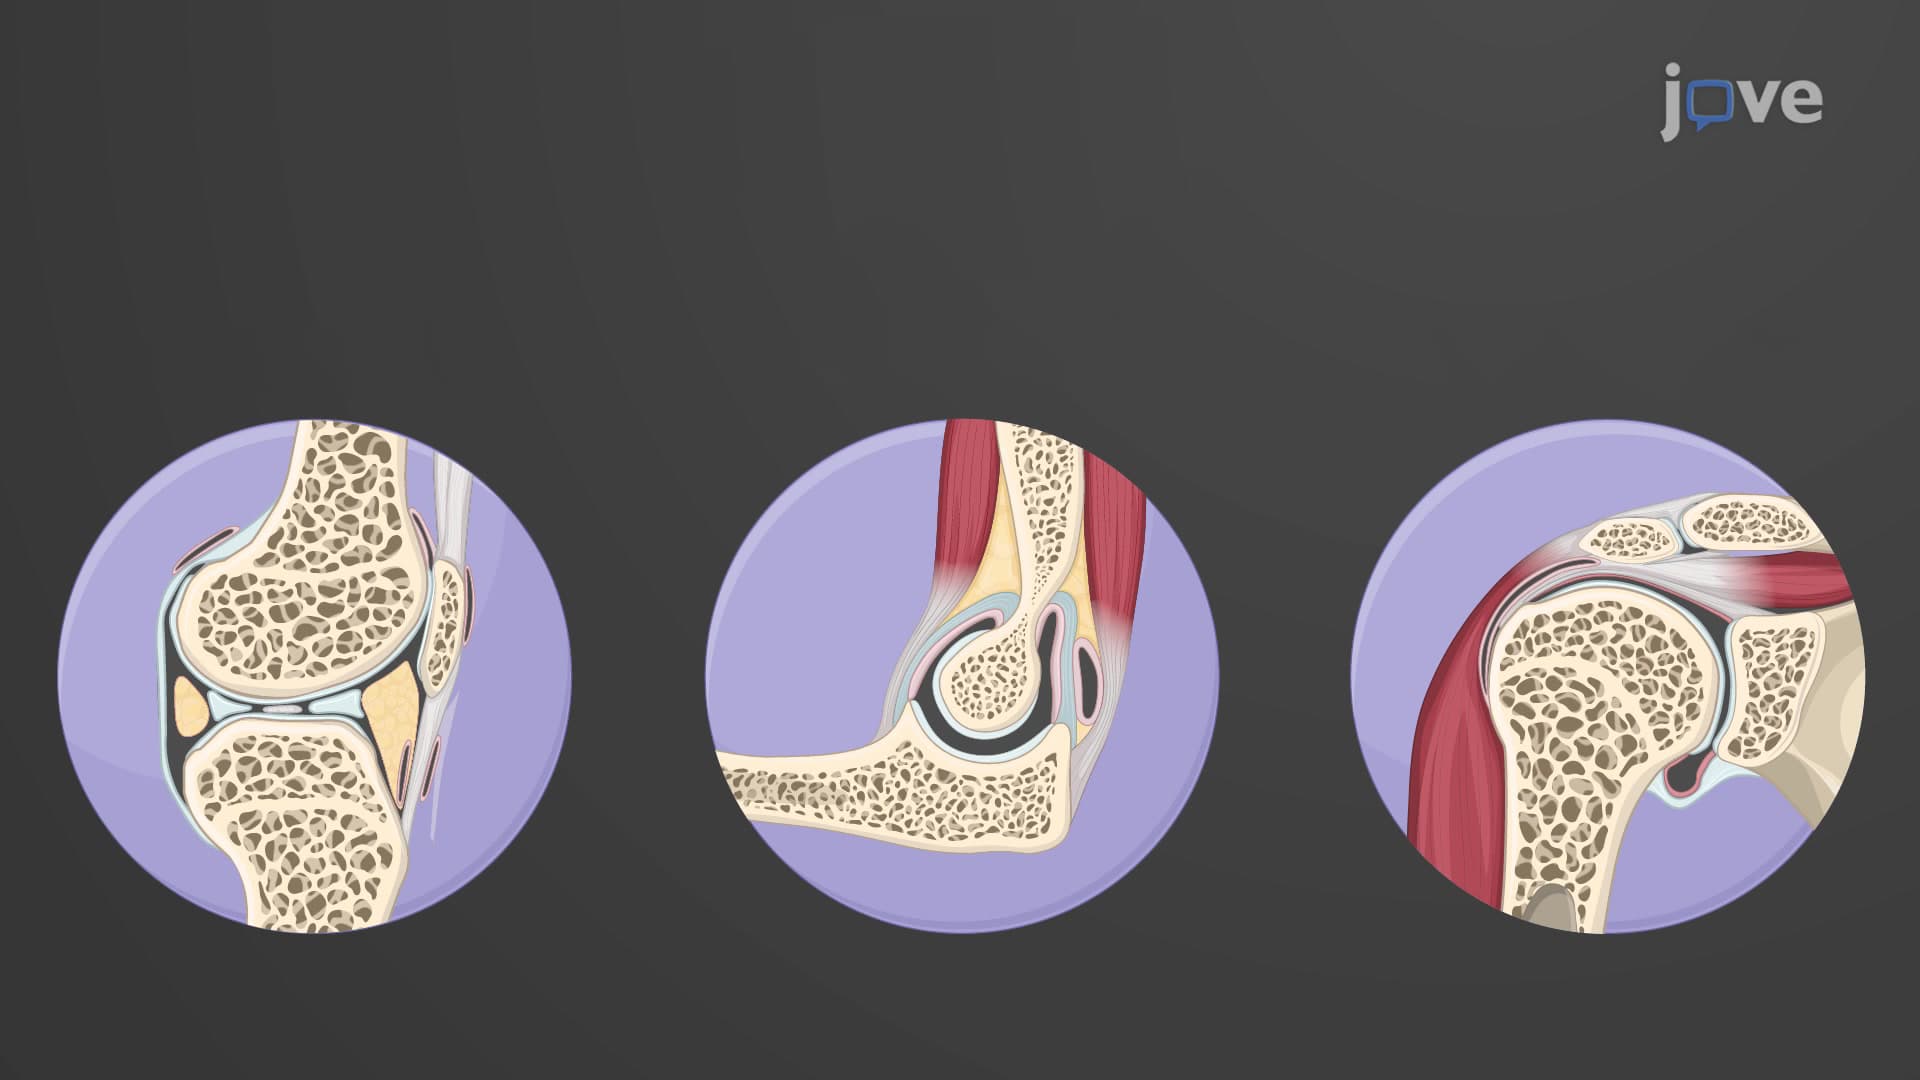
The functional classification of joints is determined by the amount of mobility between the adjacent bones. Joints are functionally classified as a synarthrosis or immobile joint, an amphiarthrosis or slightly moveable joint, or as a diarthrosis, a freely moveable joint. Fibrous and cartilaginous joints can be functionally classified as either synarthroses or amphiarthroses, whereas all synovial joints are classified as diarthroses.
Synarthrosis
An...
 01:26
Rotational Motion about a Fixed Axis
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...