Related Experiment Video
Updated: May 2, 2026
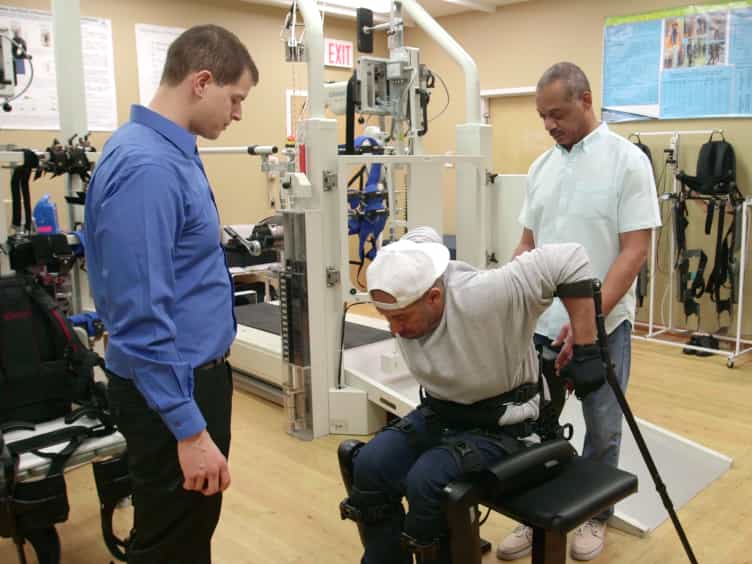
Training Persons with Spinal Cord Injury to Ambulate Using a Powered Exoskeleton
Published on: June 16, 2016
A new dynamic model of the wheelchair propulsion on straight and curvilinear level-ground paths
Félix Chénier1, Pascal Bigras, Rachid Aissaoui
1a Laboratoire de recherche en Imagerie et Orthopédie (LIO) , Centre de recherche du Centre hospitalier de l'Université de Montréal (CRCHUM) , Montreal , Quebec , Canada H3C 1K3.

Abstract:
Independent-roller ergometers (IREs) are commonly used to simulate the behaviour of a wheelchair propelled in a straight line. They cannot, however, simulate curvilinear propulsion. To this effect, a motorised wheelchair ergometer could be used, provided that a dynamic model of the wheelchair-user system propelled on straight and curvilinear paths (WSC) is available. In this article, we present such a WSC model, its parameter identification procedure and its prediction error. Ten healthy subjects propelled an instrumented wheelchair through a controlled path. Both IRE and WSC models estimated the rear wheels' velocities based on the users' propulsive moments. On curvilinear paths, the outward wheel shows root mean square (RMS) errors of 13% in an IRE vs 8% in a WSC. The inward wheel shows RMS errors of 21% in an IRE vs 11% in a WSC. Differences between both models are highly significant (p < 0.001). A wheelchair ergometer based on this new WSC model will be more accurate than a roller ergometer when simulating wheelchair propulsion in tight environments, where many turns are necessary.
More Related Videos
Related Concept Videos
 01:17
Dynamics Of Circular Motion: Applications
 01:17
Rolling Resistance: Problem Solving
 01:11
Direct Motor Pathways
The corticospinal tract is responsible for the voluntary movement of the limbs and trunk. It originates in the cerebral cortex of the brain and descends through the cerebrum's internal capsule and...
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the...
 01:23
Quadratic Models