Related Experiment Video
Updated: May 3, 2026
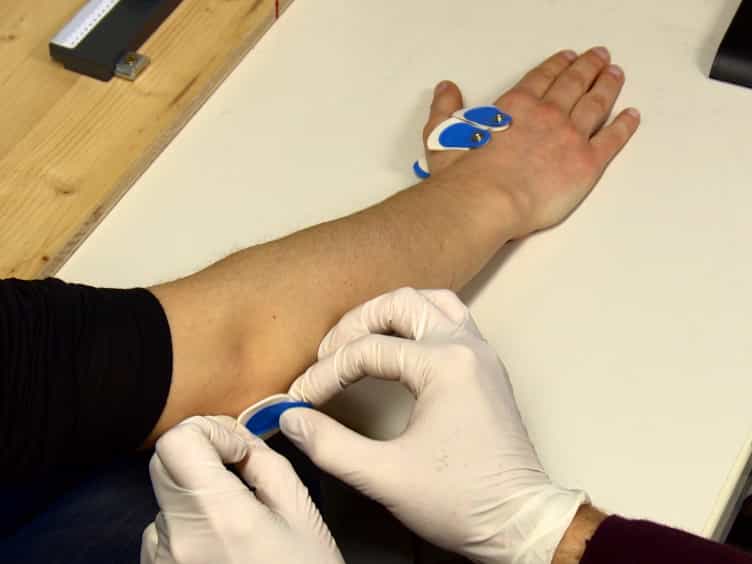

Force and Position Control in Humans - The Role of Augmented Feedback
Published on: June 19, 2016
Virtual grasping: closed-loop force control using electrotactile feedback
Nikola Jorgovanovic1, Strahinja Dosen2, Damir J Djozic1
1Department for Systems, Signals and Control, Faculty of Technical Sciences, University of Novi Sad, Novi Sad, Serbia.

Abstract:
Closing the control loop by providing somatosensory feedback to the user of a prosthesis is a well-known, long standing challenge in the field of prosthetics. Various approaches have been investigated for feedback restoration, ranging from direct neural stimulation to noninvasive sensory substitution methods. Although there are many studies presenting closed-loop systems, only a few of them objectively evaluated the closed-loop performance, mostly using vibrotactile stimulation. Importantly, the conclusions about the utility of the feedback were partly contradictory. The goal of the current study was to systematically investigate the capability of human subjects to control grasping force in closed loop using electrotactile feedback. We have developed a realistic experimental setup for virtual grasping, which operated in real time, included a set of real life objects, as well as a graphical and dynamical model of the prosthesis. We have used the setup to test 10 healthy, able bodied subjects to investigate the role of training, feedback and feedforward control, robustness of the closed loop, and the ability of the human subjects to generalize the control to previously "unseen" objects. Overall, the outcomes of this study are very optimistic with regard to the benefits of feedback and reveal various, practically relevant, aspects of closed-loop control.

Related Concept Videos
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:30
Three-Dimensional Force System
 01:01
Feedback Loops