Related Experiment Video
Updated: May 2, 2026

3D Kinematic Gait Analysis for Preclinical Studies in Rodents
Published on: August 3, 2019
Stance phase kinematics and kinetics of horses trotting over poles
H M Clayton1, N C Stubbs, M Lavagnino
1McPhail Equine Performance Center, College of Veterinary Medicine, Michigan State University, East Lansing, USA.

Reason For Performing Study:
Trotting over poles is frequently used therapeutically to restore swing phase ranges of joint motion. It is not known whether ground reaction forces (GRFs) increase as the swing phase limbs are lifted higher to clear the poles. Higher GRFs might be painful or jeopardise healing of musculoskeletal injuries.
Objectives:
To measure stance phase kinematics and GRFs in the forelimbs and hindlimbs of horses trotting on level ground, over low poles and over high poles, and to test the hypothesis that trotting over poles is associated with increases in peak GRFs and impulses in the supporting hindlimb and forelimb compared with trotting over level ground.
Study Design:
Repeated measures experimental study on horses with normal gait.
Methods:
Kinematic and GRF data were collected from 8 horses trotting on level ground under 3 conditions performed in random order: no poles, low (11 cm) poles and high (20 cm) poles spaced 1.05 ± 0.05 m apart. Spatiotemporal and angular kinematic variables and GRFs were measured during stance. Comparisons among conditions were made using repeated measures ANOVA (P<0.05) with Bonferroni correction for post hoc testing.
Results:
The only GRF component that increased when trotting over poles was peak forelimb braking GRF. Forelimb vertical and braking impulses increased and the transverse impulse changed from medially to laterally directed. Extension of the metatarsophalangeal and metacarpophalangeal joints did not change.
Conclusions:
The fact that peak vertical forces and extension of the metatarsophalangeal and metacarpophalangeal joints did not increase when trotting over poles suggests that loading of the musculoskeletal tissues is comparable with that associated with trotting on level ground in horses with symmetrical movement at trot. The findings support the use of trot poles during rehabilitation from lameness in horses that move symmetrically. The generation of laterally directed forelimb transverse forces suggests that trotting over poles may recruit the forelimb adductor musculature.
Related Concept Videos
 01:24
Pole and System Stability
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's...
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
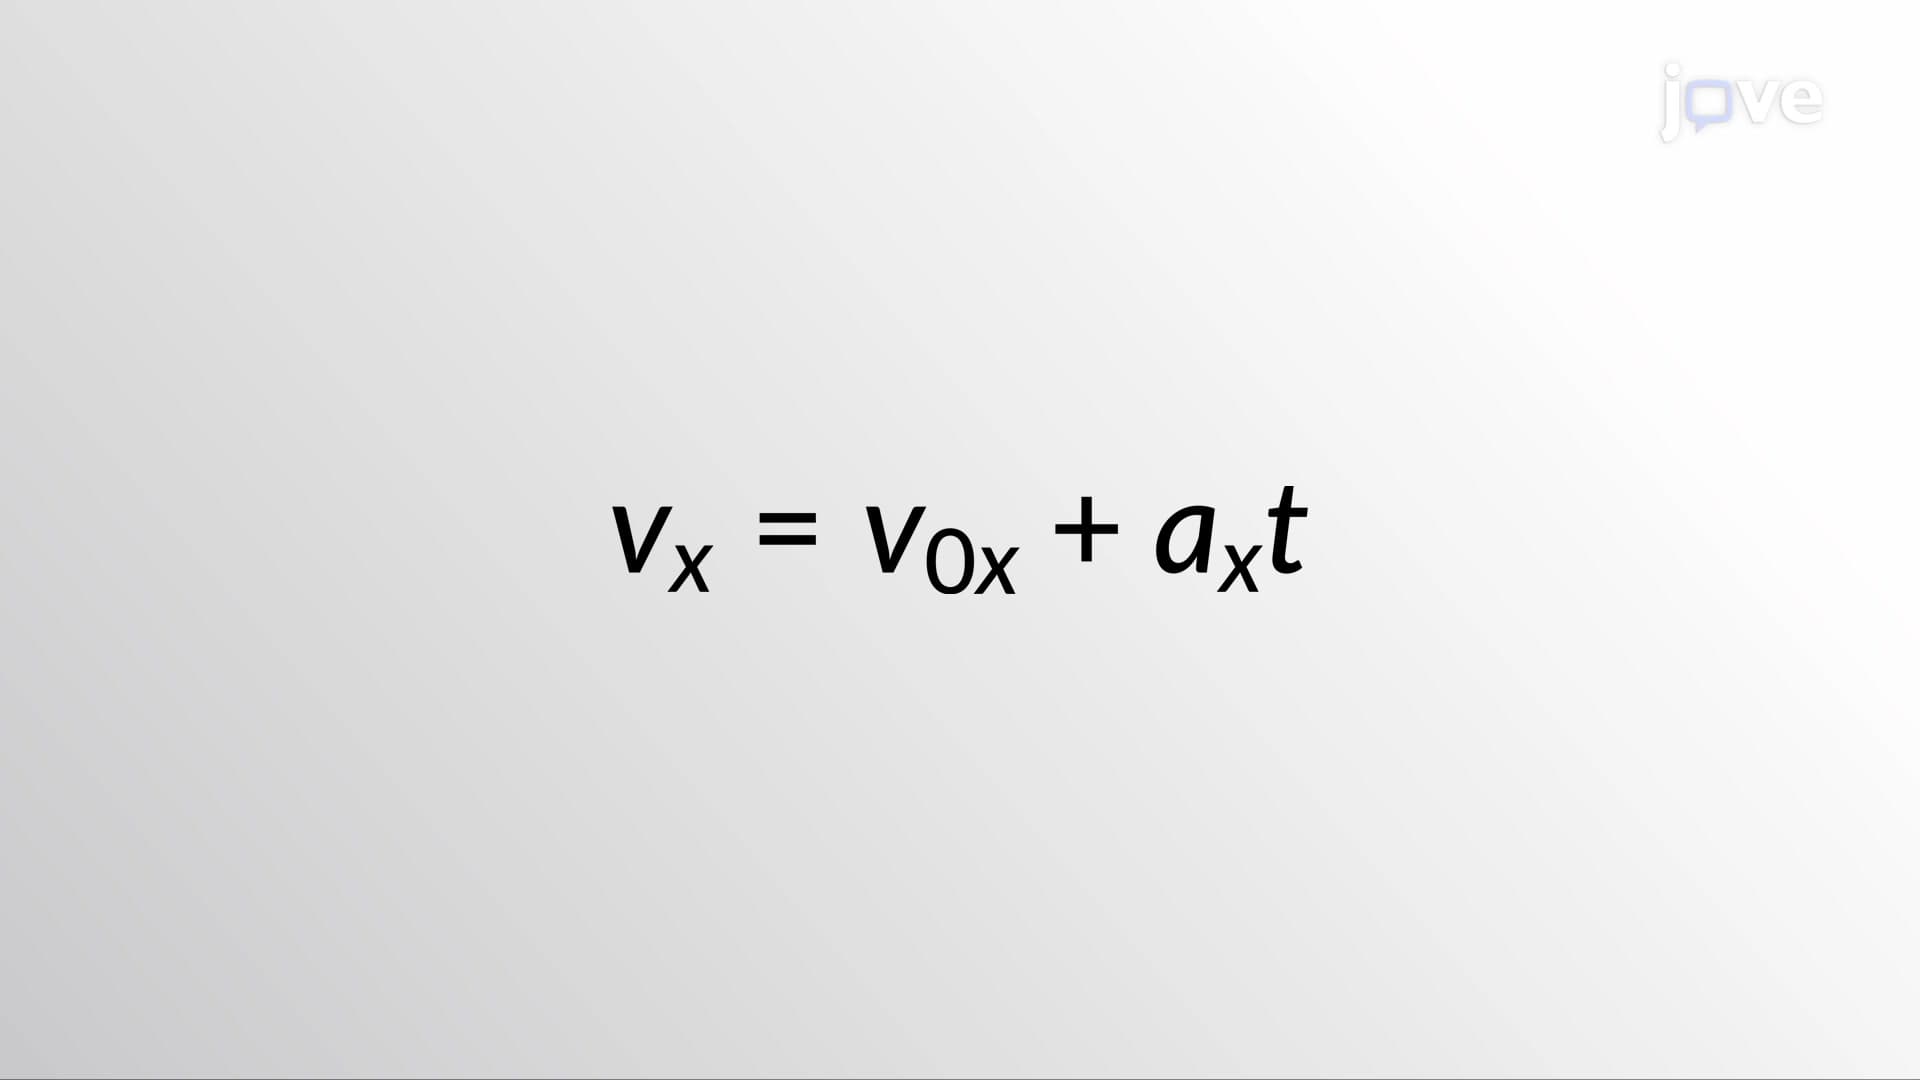 01:26
Kinematic Equations - I
 01:18
Kinematic Equations - III
Using the kinematic equations,...
 01:15
Kinematic Equations: Problem Solving
 01:28
Stability
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...