Wrist kinematic coupling and performance during functional tasks: effects of constrained motion
Related Experiment Video
Updated: Aug 18, 2026
Intracortical Inhibition Within the Primary Motor Cortex Can Be Modulated by Changing the Focus of Attention
Published on: September 11, 2017
Rohit Garg1, Andrew P Kraszewski1, Holbrook H Stoecklein1
1Motion Analysis Laboratory and the Hand and Upper Extremity Service, Hospital for Special Surgery, New York, NY; Department of Orthopaedics, Brown University, Providence, RI.

Purpose:
To quantify the coupled motion of the wrist during selected functional tasks and to determine the effects of constraining this coupled motion using a radial-ulnar deviation blocking splint on performance of these tasks.
Methods:
Ten healthy, right-handed men performed 15 trials during selected functional tasks with and without a splint, blocking radial and ulnar deviation. The following tasks were performed: dart throwing, hammering, basketball free-throw, overhand baseball and football throwing, clubbing, and pouring. Kinematic coupling parameters (coupling, kinematic path length, flexion-extension range of motion, radial-ulnar deviation range of motion, flexion-extension offset, and radial-ulnar deviation offset) and performance were determined for each functional task. A generalized estimation equation model was used to determine whether each kinematic coupling parameter was significantly different across tasks. A repeated-measures generalized estimation equation model was used to test for differences in performance and kinematic coupling parameters between the free and splinted conditions.
Results:
Wrist motion exhibited linear coupling between flexion-extension and radial-ulnar deviation, demonstrated by R(2) values from 0.70 to 0.99. Average wrist coupling and kinematic path lengths were significantly different among tasks. Coupling means and kinematic path lengths were different between free and splinted conditions across all tasks other than pouring. Performance was different between wrist conditions for dart throwing, hammering, basketball shooting, and pouring.
Conclusions:
Wrist kinematic coupling parameters are task specific in healthy individuals. Functional performance is decreased when wrist coupling is constrained by an external splint.
Clinical Relevance:
Surgical procedures that restrict wrist coupling may have a detrimental effect on functional performance as defined in the study. Patients may benefit from surgical reconstructive procedures and wrist rehabilitation protocols designed to restore kinematic coupling.
More Related Videos
 08:45
Kinematic Analysis Using 3D Motion Capture of Drinking Task in People With and Without Upper-extremity Impairments
Published on: March 28, 2018
 15:00
The Impact of Motor Task Conditions on Goal-Directed Arm Reaching Kinematics and Trunk Compensation in Chronic Stroke Survivors
Published on: May 2, 2021
Related Concept Videos
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:18
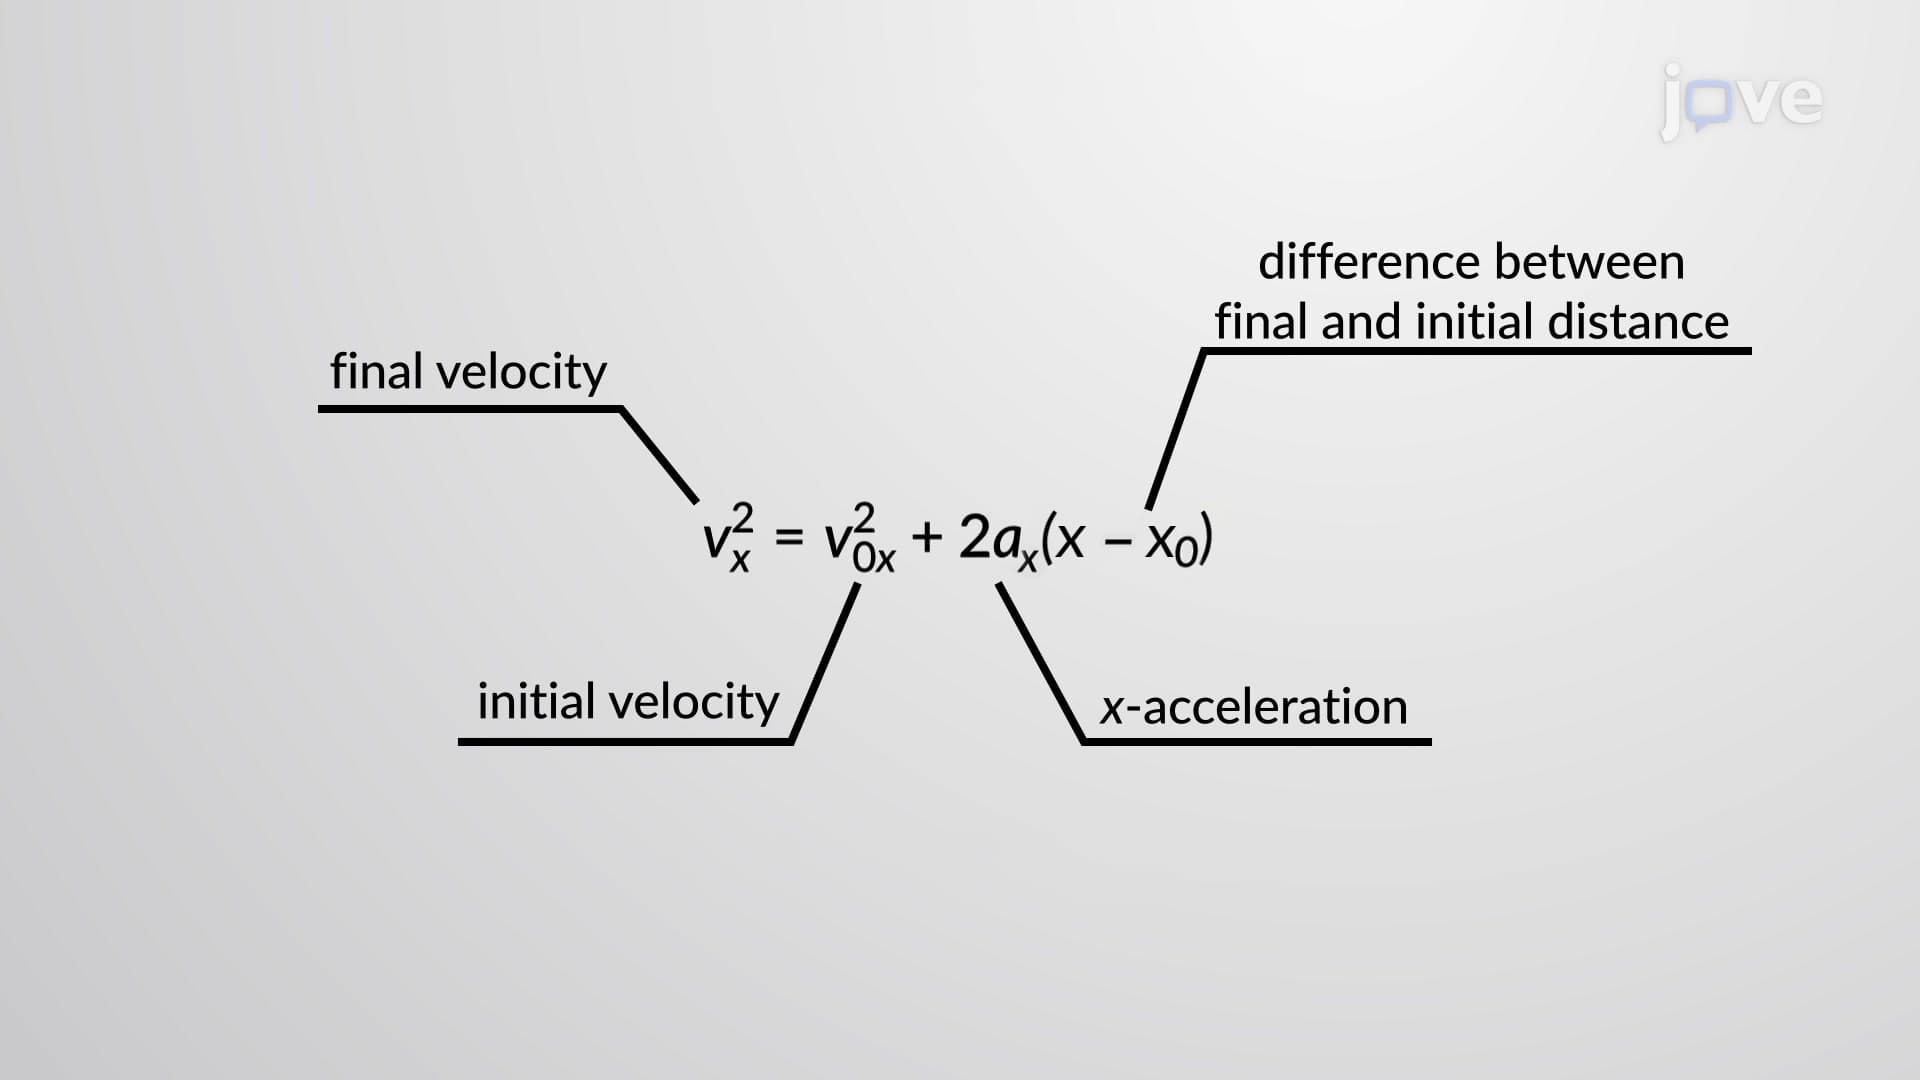
Kinematic Equations - III
Using the kinematic equations,...
 01:15
Kinematic Equations: Problem Solving
 01:16
Muscles that Move the Forearm
Forearm Flexors
The biceps brachii, brachialis, and brachioradialis are forearm flexors. The biceps brachii is made up of two heads. Its long head originates at the supraglenoid tubercle of the scapula, whereas that of the short head is...
 01:16
Muscles of the Forearm that Move the Hand and Fingers
Anterior Compartment
The anterior compartment muscles originate from the humerus. They primarily function as flexors and are also known as flexor muscles. They typically insert on the carpals, metacarpals, and phalanges. The superficial layer includes the flexor carpi radialis,...
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...