Related Experiment Video
Updated: May 2, 2026
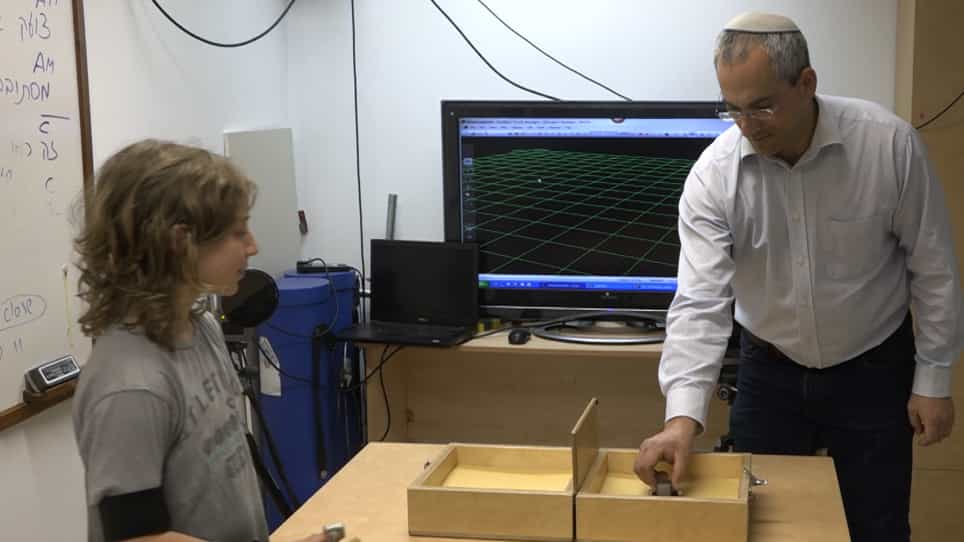

Applying Incongruent Visual-Tactile Stimuli during Object Transfer with Vibro-Tactile Feedback
Published on: May 23, 2019
Visual-haptic integration with pliers and tongs: signal "weights" take account of changes in haptic sensitivity
Chie Takahashi1, Simon J Watt2
1Wolfson Centre for Cognitive Neuroscience, School of Psychology, Bangor University Bangor, UK ; Behavioural Brain Science Centre, School of Psychology, University of Birmingham Birmingham, UK.

Abstract:
When we hold an object while looking at it, estimates from visual and haptic cues to size are combined in a statistically optimal fashion, whereby the "weight" given to each signal reflects their relative reliabilities. This allows object properties to be estimated more precisely than would otherwise be possible. Tools such as pliers and tongs systematically perturb the mapping between object size and the hand opening. This could complicate visual-haptic integration because it may alter the reliability of the haptic signal, thereby disrupting the determination of appropriate signal weights. To investigate this we first measured the reliability of haptic size estimates made with virtual pliers-like tools (created using a stereoscopic display and force-feedback robots) with different "gains" between hand opening and object size. Haptic reliability in tool use was straightforwardly determined by a combination of sensitivity to changes in hand opening and the effects of tool geometry. The precise pattern of sensitivity to hand opening, which violated Weber's law, meant that haptic reliability changed with tool gain. We then examined whether the visuo-motor system accounts for these reliability changes. We measured the weight given to visual and haptic stimuli when both were available, again with different tool gains, by measuring the perceived size of stimuli in which visual and haptic sizes were varied independently. The weight given to each sensory cue changed with tool gain in a manner that closely resembled the predictions of optimal sensory integration. The results are consistent with the idea that different tool geometries are modeled by the brain, allowing it to calculate not only the distal properties of objects felt with tools, but also the certainty with which those properties are known. These findings highlight the flexibility of human sensory integration and tool-use, and potentially provide an approach for optimizing the design of visual-haptic devices.
Related Concept Videos
 01:27
Tactile and Chemical Senses
 01:19
Machines
A free-body diagram of the...
 01:15
Sensory Modalities
General senses refer to the broad category of sensory information detected by receptors in the body and can be further grouped into somatic and visceral senses. Somatic sensations include touch, pressure, temperature, and pain and are essential for navigating our environment and...
 01:06
Virtual Work for a System of Connected Rigid Bodies
Next,...
 01:33
Somatosensation