Related Experiment Video
Updated: May 2, 2026

3D Kinematic Gait Analysis for Preclinical Studies in Rodents
Published on: August 3, 2019
Swing phase kinematics of horses trotting over poles
S Brown1, N C Stubbs, L J Kaiser
1McPhail Equine Performance Center, College of Veterinary Medicine, Michigan State University, East Lansing, USA.

Reasons For Performing Study:
Trotting over poles is used therapeutically to restore full ranges of limb joint motion. The mechanics of trotting over poles have not yet been described, hence quantitative evidence for the presumed therapeutic effects is lacking.
Objectives:
To compare limb kinematics in horses trotting over level ground, over low poles and over high poles to determine changes in joint angulations and hoof flight arcs.
Study Design:
Repeated measures experimental study in sound horses.
Methods:
Standard motion analysis procedures with skin-fixed reflective markers were used to measure swing phase kinematics from 8 horses trotting on level ground, over low (11 cm) and high (20 cm) poles spaced 1.05 ± 0.05 m apart. Spatiotemporal variables and peak swing phase joint flexion angles were compared using repeated measures ANOVA (P<0.05) with Bonferroni correction for pairwise post hoc testing.
Results:
Peak heights of the fore and hind hooves increased significantly and progressively from no poles (fore: 13.8 ± 3.8 cm; hind: 10.8 ± 2.4 cm) to low poles (fore: 30.9 ± 4.9 cm; hind: 24.9 ± 3.7 cm) and to high poles (fore: 41.0 ± 3.9 cm; hind: 32.7 ± 4.0 cm). All joints of the fore- and hindlimbs contributed to the increase in hoof height through increased swing phase flexion. The hooves cleared the poles due to increases in joint flexion rather than by raising the body higher during the suspension phases of the stride.
Conclusions:
The increases in swing phase joint flexions indicate that trotting over poles is effective for activating and strengthening the flexor musculature. Unlike the use of proprioceptive stimulation devices in which the effects decrease over time due to habituation, the horse is required to elevate the hooves to ensure clearance whenever poles are present. The need to raise the limbs sufficiently to clear the poles and place the hooves accurately requires visuomotor coordination, which may be useful in the rehabilitation of neurological cases. The Summary is available in Chinese - see Supporting information.

Related Concept Videos
 01:24
Pole and System Stability
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's...
 01:21
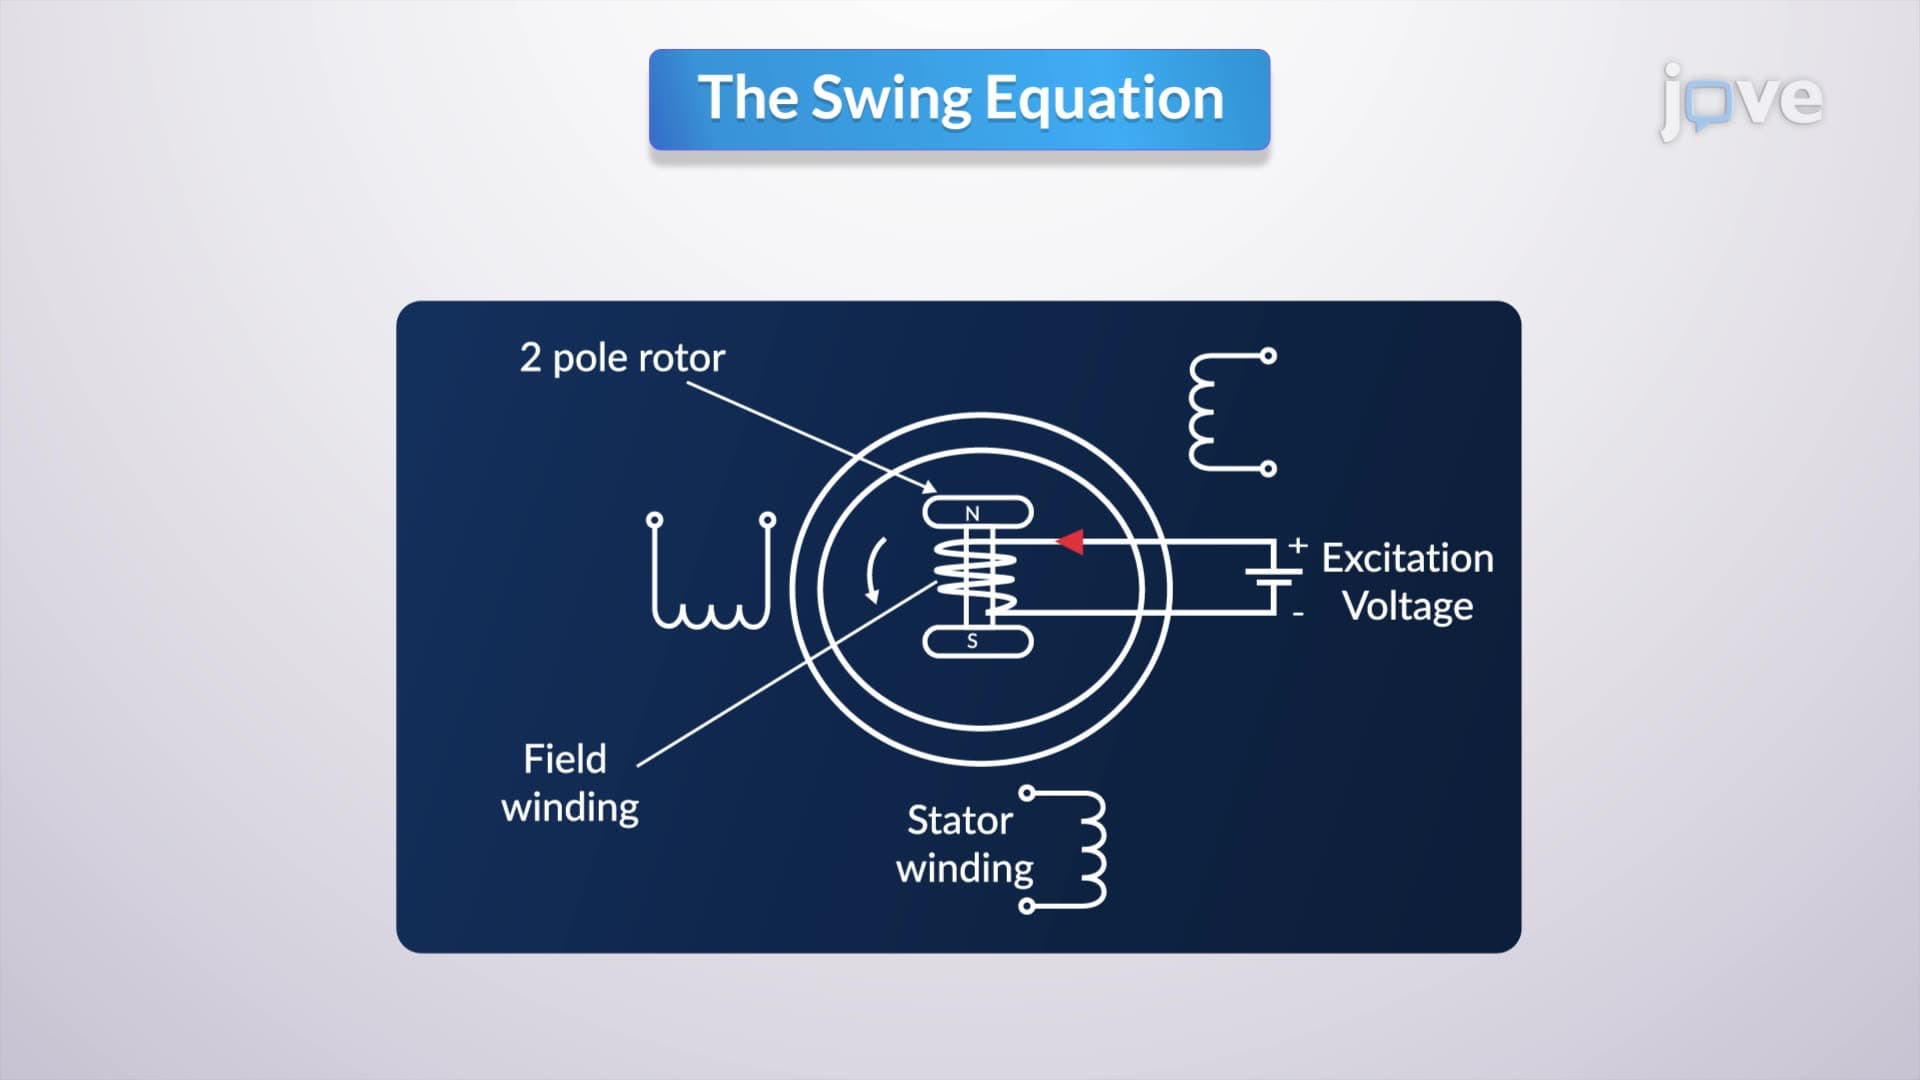
The Swing Equation
In a steady-state operation, the mechanical torque (Τm) supplied to the generator is balanced by the electrical torque...
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:17
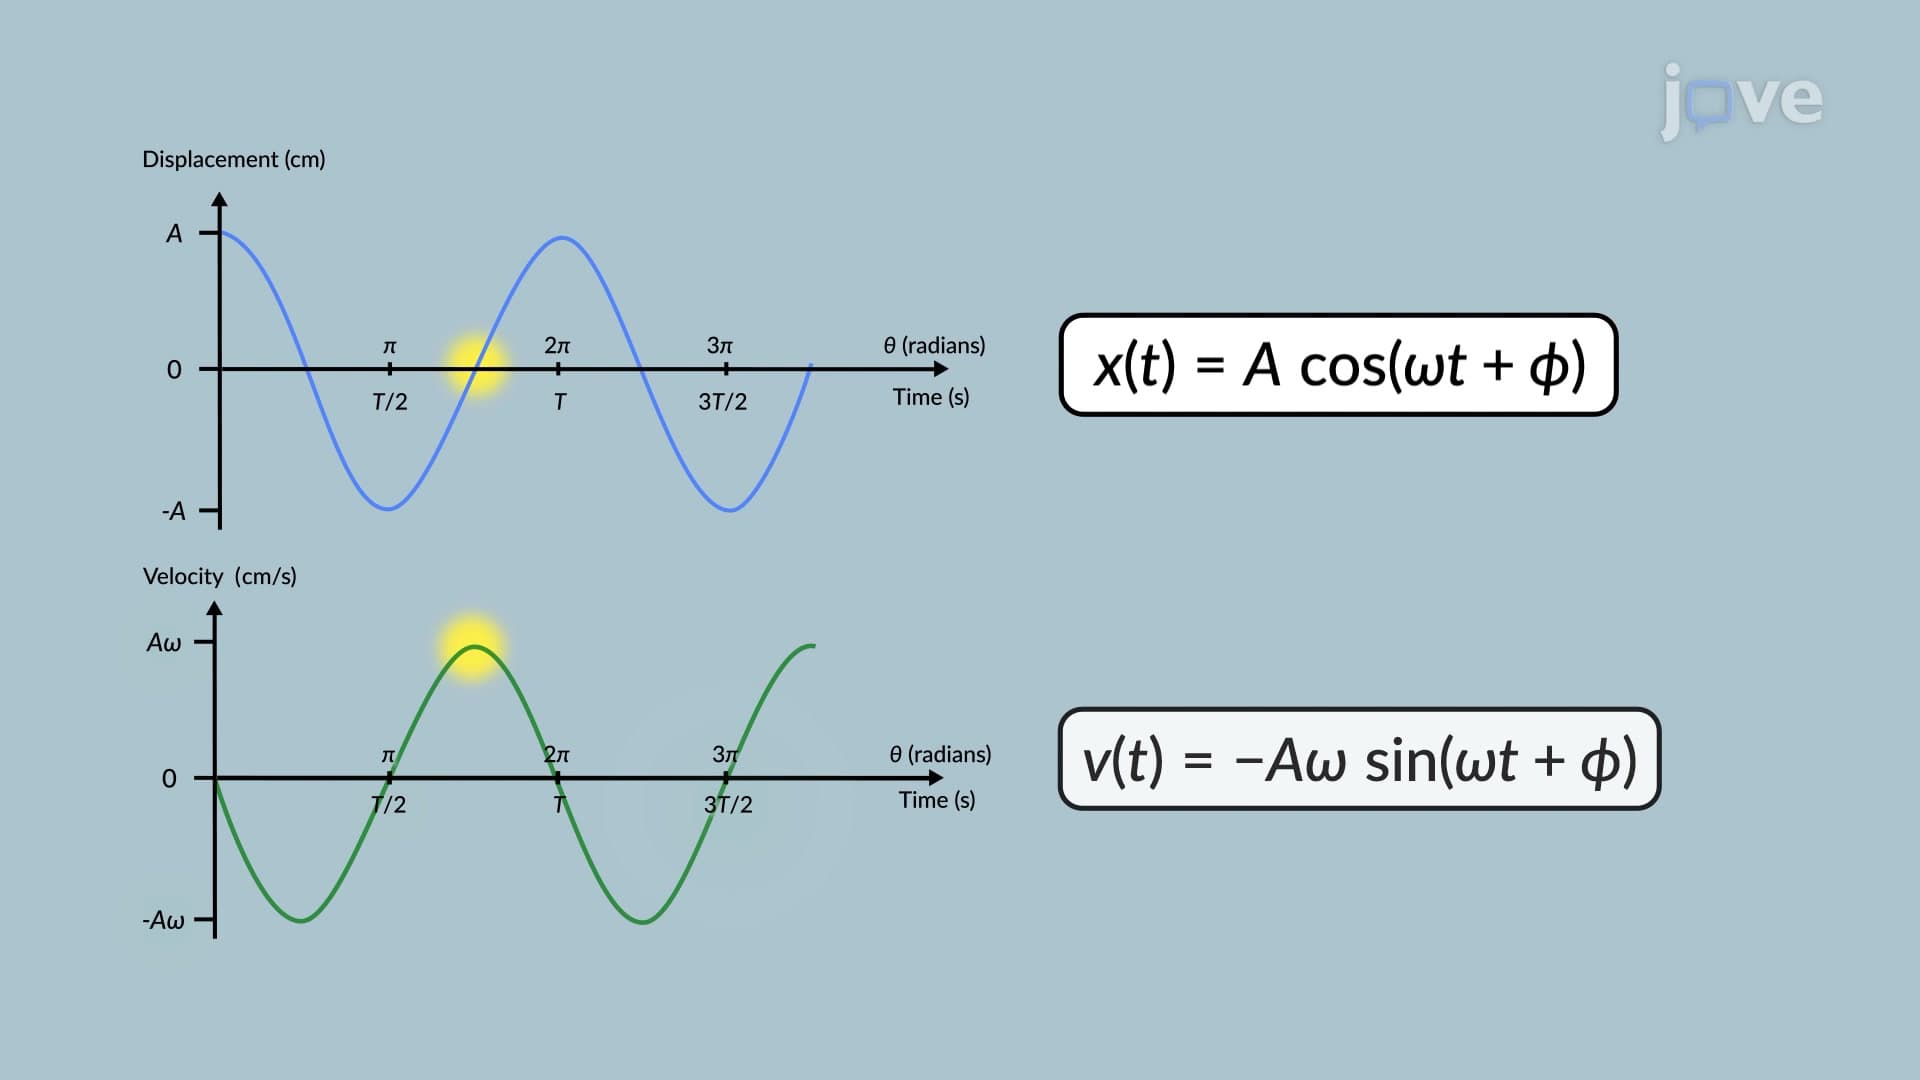
Characteristics of Simple Harmonic Motion
 01:09
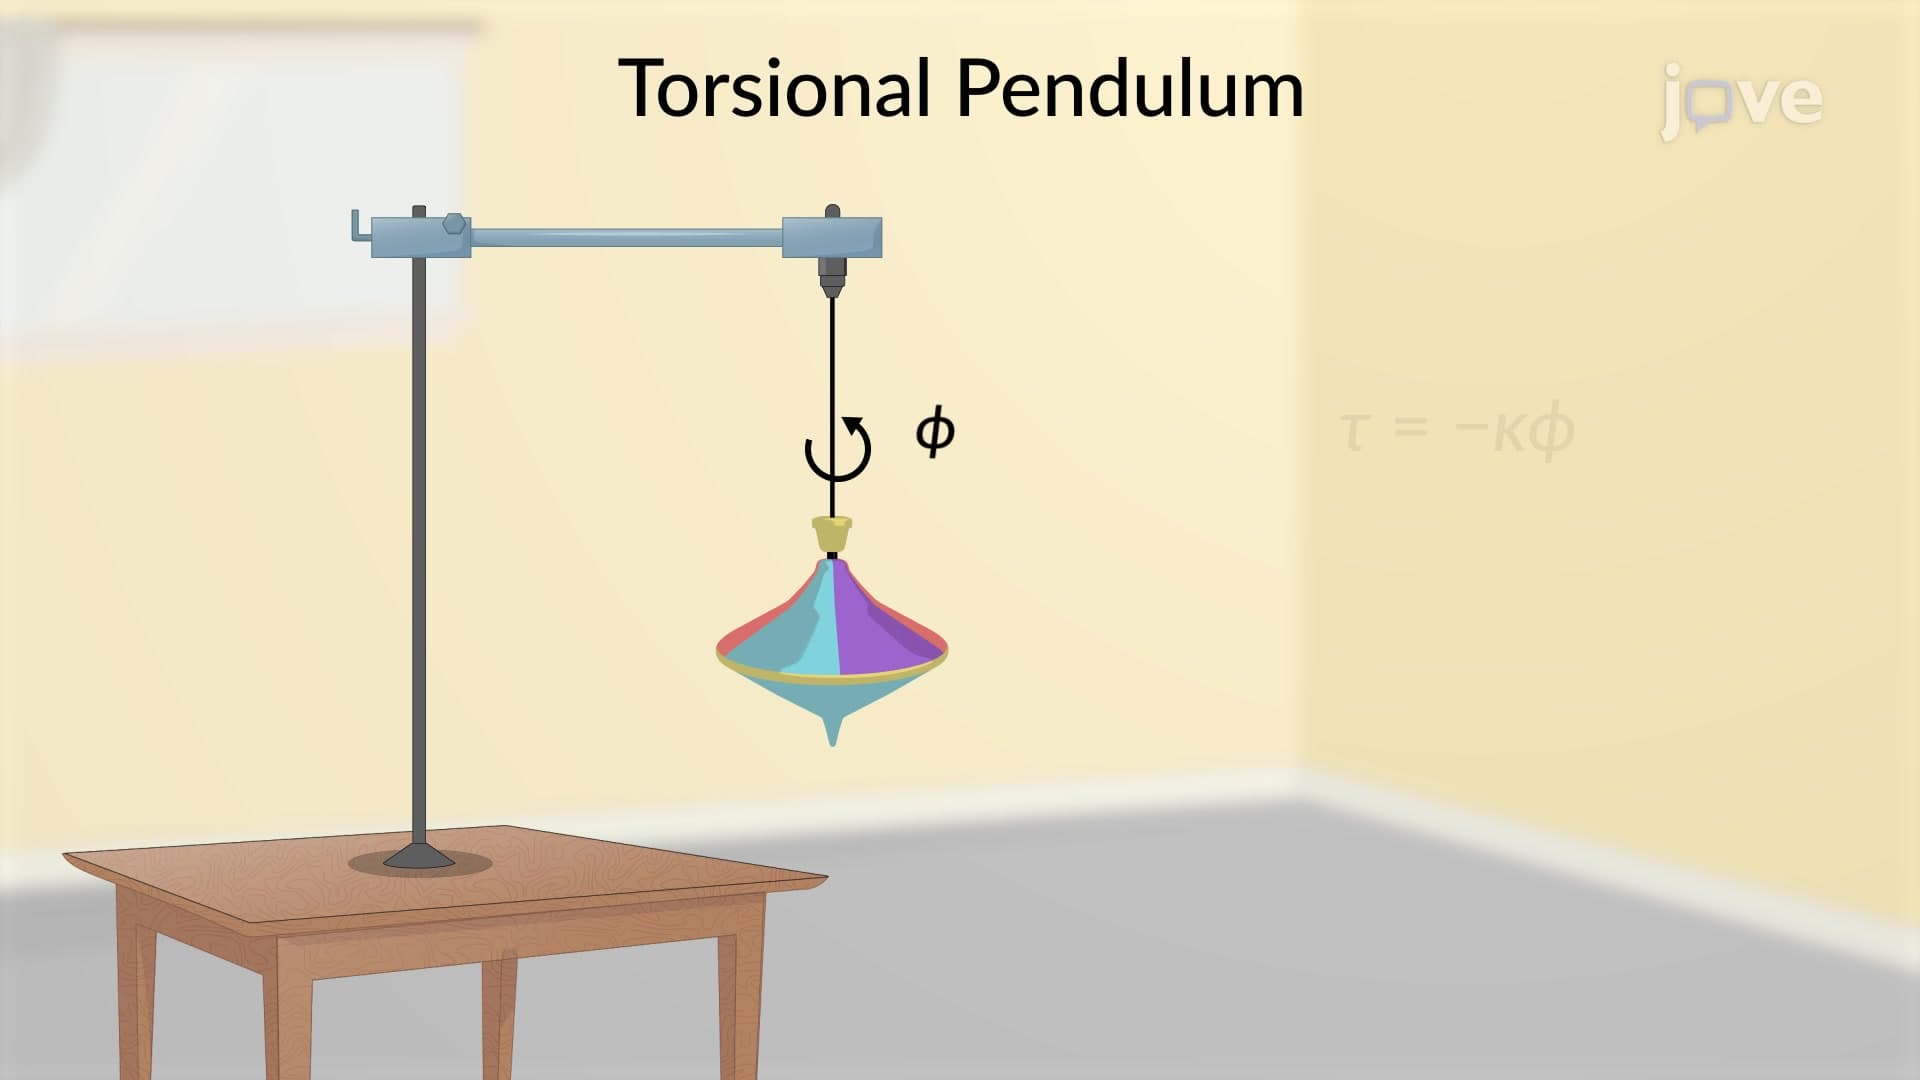
Torsional Pendulum
As long as the rigid body's angular displacement is small, its oscillation can be modeled as a linear angular oscillation. The amplitude of the oscillation is an angle. The role of mass is played...
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...