Related Experiment Video
Updated: May 1, 2026
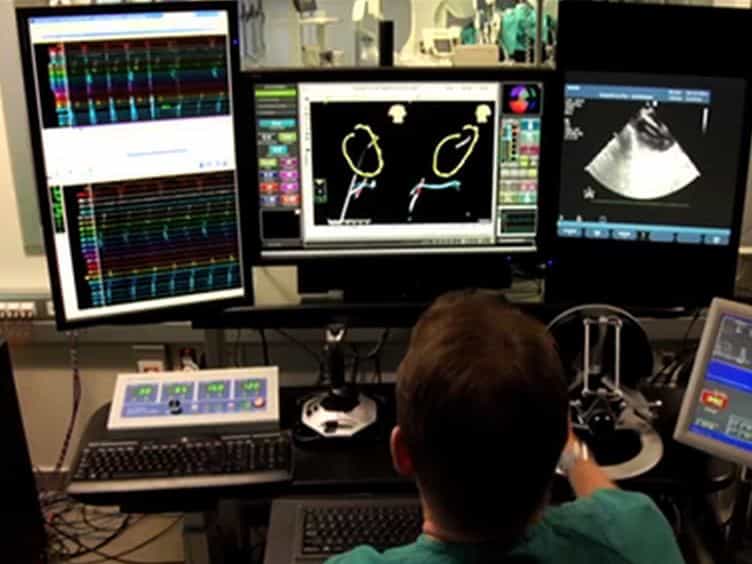
Remote Magnetic Navigation for Accurate, Real-time Catheter Positioning and Ablation in Cardiac Electrophysiology Procedures
Published on: April 21, 2013
Motion-adapted catheter navigation with real-time instantiation and improved visualisation
Su-Lin Lee1, Ka-Wai Kwok2, Lichao Wang2
1Hamlyn Centre for Robotic Surgery, Imperial College London, London SW7 2AZ, UK. su-lin.lee@imperial.ac.uk.

Abstract:
The improvements to catheter manipulation by the use of robot-assisted catheter navigation for endovascular procedures include increased precision, stability of motion and operator comfort. However, navigation through the vasculature under fluoroscopic guidance is still challenging, mostly due to physiological motion and when tortuous vessels are involved. In this paper, we propose a motion-adaptive catheter navigation scheme based on shape modelling to compensate for these dynamic effects, permitting predictive and dynamic navigations. This allows for timed manipulations synchronised with the vascular motion. The technical contribution of the paper includes the following two aspects. Firstly, a dynamic shape modelling and real-time instantiation scheme based on sparse data obtained intra-operatively is proposed for improved visualisation of the 3D vasculature during endovascular intervention. Secondly, a reconstructed frontal view from the catheter tip using the derived dynamic model is used as an interventional aid to user guidance. To demonstrate the practical value of the proposed framework, a simulated aortic branch cannulation procedure is used with detailed user validation to demonstrate the improvement in navigation quality and efficiency.
More Related Videos
 10:25
Technical Approach for Infrared Tracking for Soft Tissue Navigation with a Holographic Head-Mounted Display and Preclinical Validation
Published on: September 2, 2025
 07:46
Author Spotlight: Revolutionizing Remote Surgery with Augmented Reality and Robotics for Enhanced Precision and Accessibility
Published on: August 9, 2024