Related Experiment Video
Updated: Apr 30, 2026
Isokinetic Robotic Device to Improve Test-Retest and Inter-Rater Reliability for Stretch Reflex Measurements in Stroke Patients with Spasticity
Published on: June 12, 2019
GPI based velocity/force observer design for robot manipulators
Alejandro Gutiérrez-Giles1, Marco A Arteaga-Pérez1
1Departamento de Control y Robótica, DIE, Facultad de Ingeniería, Universidad Nacional Autónoma de México, Apdo. Postal 70-256, México, D. F., 04510, Mexico.

Abstract:
In many applications involving a robot in contact with a surface it is important to control the interaction between the manipulator and its environment, usually by employing force sensors. However, sometimes it is desirable to remove them due to a variety of reasons, e.g. high costs, noisy measurements and a narrow bandwidth. To overcome these drawbacks, in this work it is proposed as a velocity/force observer based on the Generalized Proportional Integral (GPI) technique. Joint velocities and contact forces are estimated with only position measurements and then used in a force/position control scheme. Ultimate boundedness of the observation errors is formally proven and an arbitrarily small ultimate bound is then achieved. Simulation results are used to validate the proposed approach.


Related Concept Videos
 01:24
PI Controller: Design
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:34
Velocity and Position by Graphical Method
 01:30
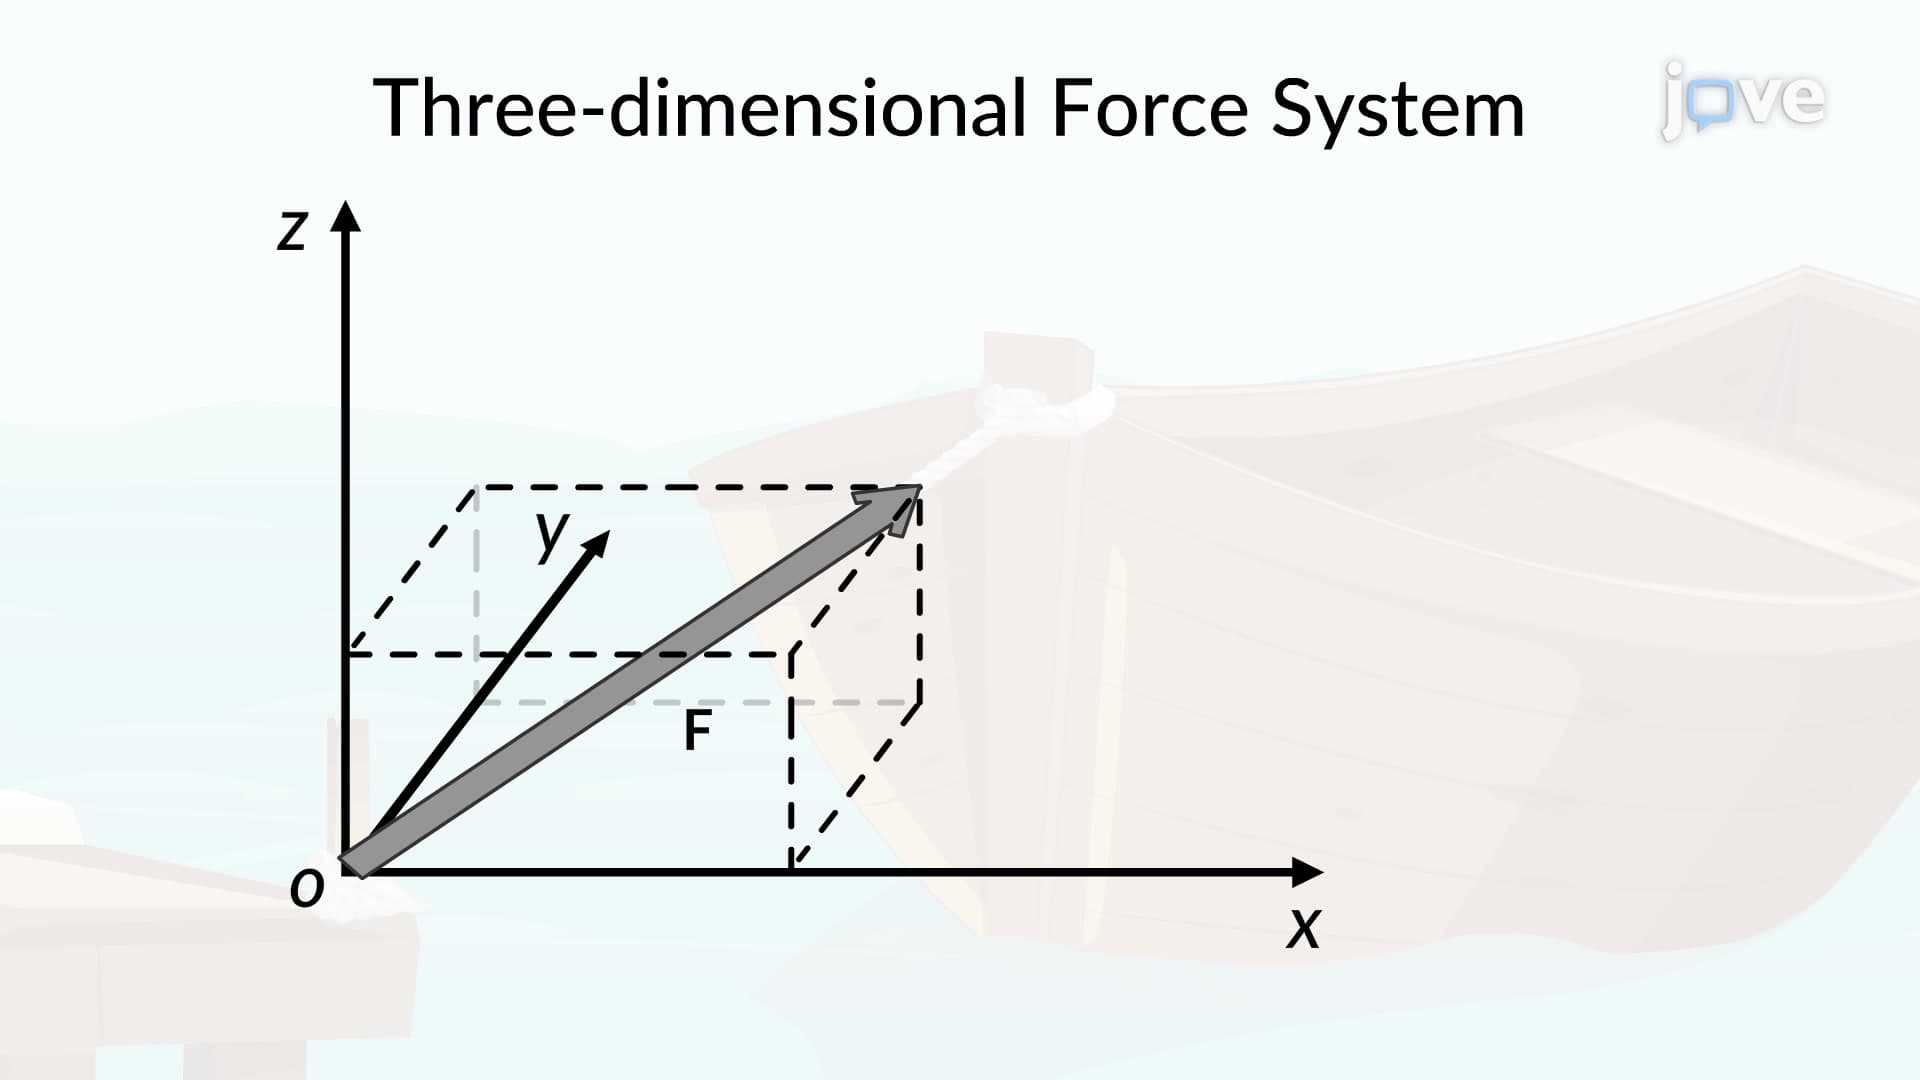
Three-Dimensional Force System
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...