Related Experiment Video
Updated: Apr 30, 2026

WheelCon: A Wheel Control-Based Gaming Platform for Studying Human Sensorimotor Control
Published on: August 15, 2020
The sine wave protocol: decrease movement time without increasing errors
Jason B Boyle1, Deanna M Kennedy, Chaoyi Wang
1a University of Texas at El Paso.

Abstract:
Practice tracking a sine wave template has been shown (J. B. Boyle, D. Kennedy, & C. H. Shea, 2012) to greatly enhance performance on a difficult Fitts task of the same amplitude. The purpose of the experiment was to replicate this finding and determine whether enhancements related to the sine wave practice are specific to the amplitude experienced during the sine wave practice. Following sine wave or Fitts task practice with amplitudes of 16° or 24°, participants were tested under the conditions they had practiced under (Test 1) and then all groups were tested under Fitts task conditions (Test 2; ID = 6, amplitude = 16°). Participants who practiced with the sine wave templates were able to move faster on Test 2 where a 16° amplitude Fitts task was used than participants that had practiced either the 16° or 24° amplitude Fitts tasks. The movements produced by the sine groups on Test 2 were not only faster than the movements of the Fitts groups on Test 2, but dwell time was lower with percent time to peak velocity and harmonicity higher for the Sine groups than for the Fitts groups. The decreased movement times for the sine groups on Test 2 were accomplished with hits or endpoint variability similar to that of the Fitts group.
More Related Videos
 06:58
A Structured Rehabilitation Protocol for Improved Multifunctional Prosthetic Control: A Case Study
Published on: November 6, 2015
 08:09
Multifunctional Setup for Studying Human Motor Control Using Transcranial Magnetic Stimulation, Electromyography, Motion Capture, and Virtual Reality
Published on: September 3, 2015
Related Concept Videos
 01:16
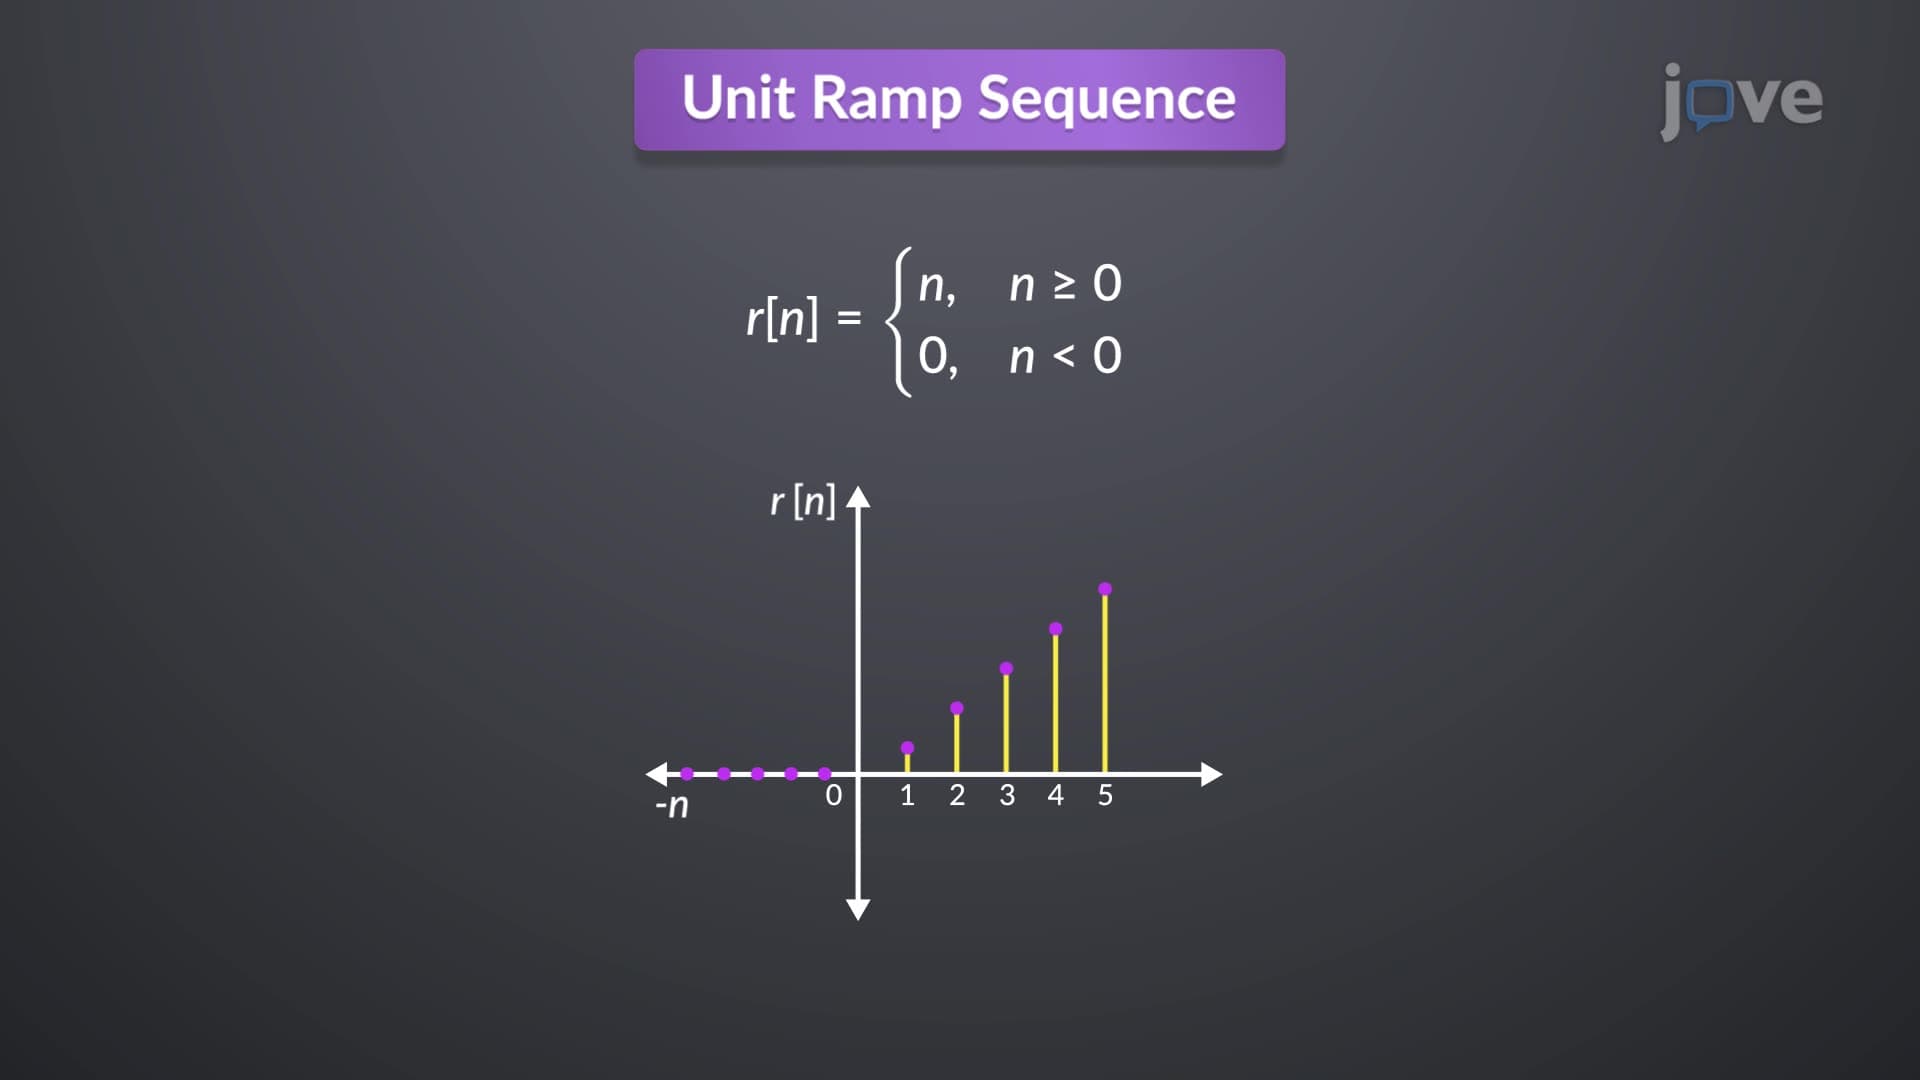
Basic Discrete Time Signals
The unit impulse or sample sequence is mathematically expressed as zero for all n values except at n=0, where it is one. The unit impulse sequence, denoted by δ(n), is the first difference of the unit step sequence, while the unit step sequence u(n) is...
 01:17
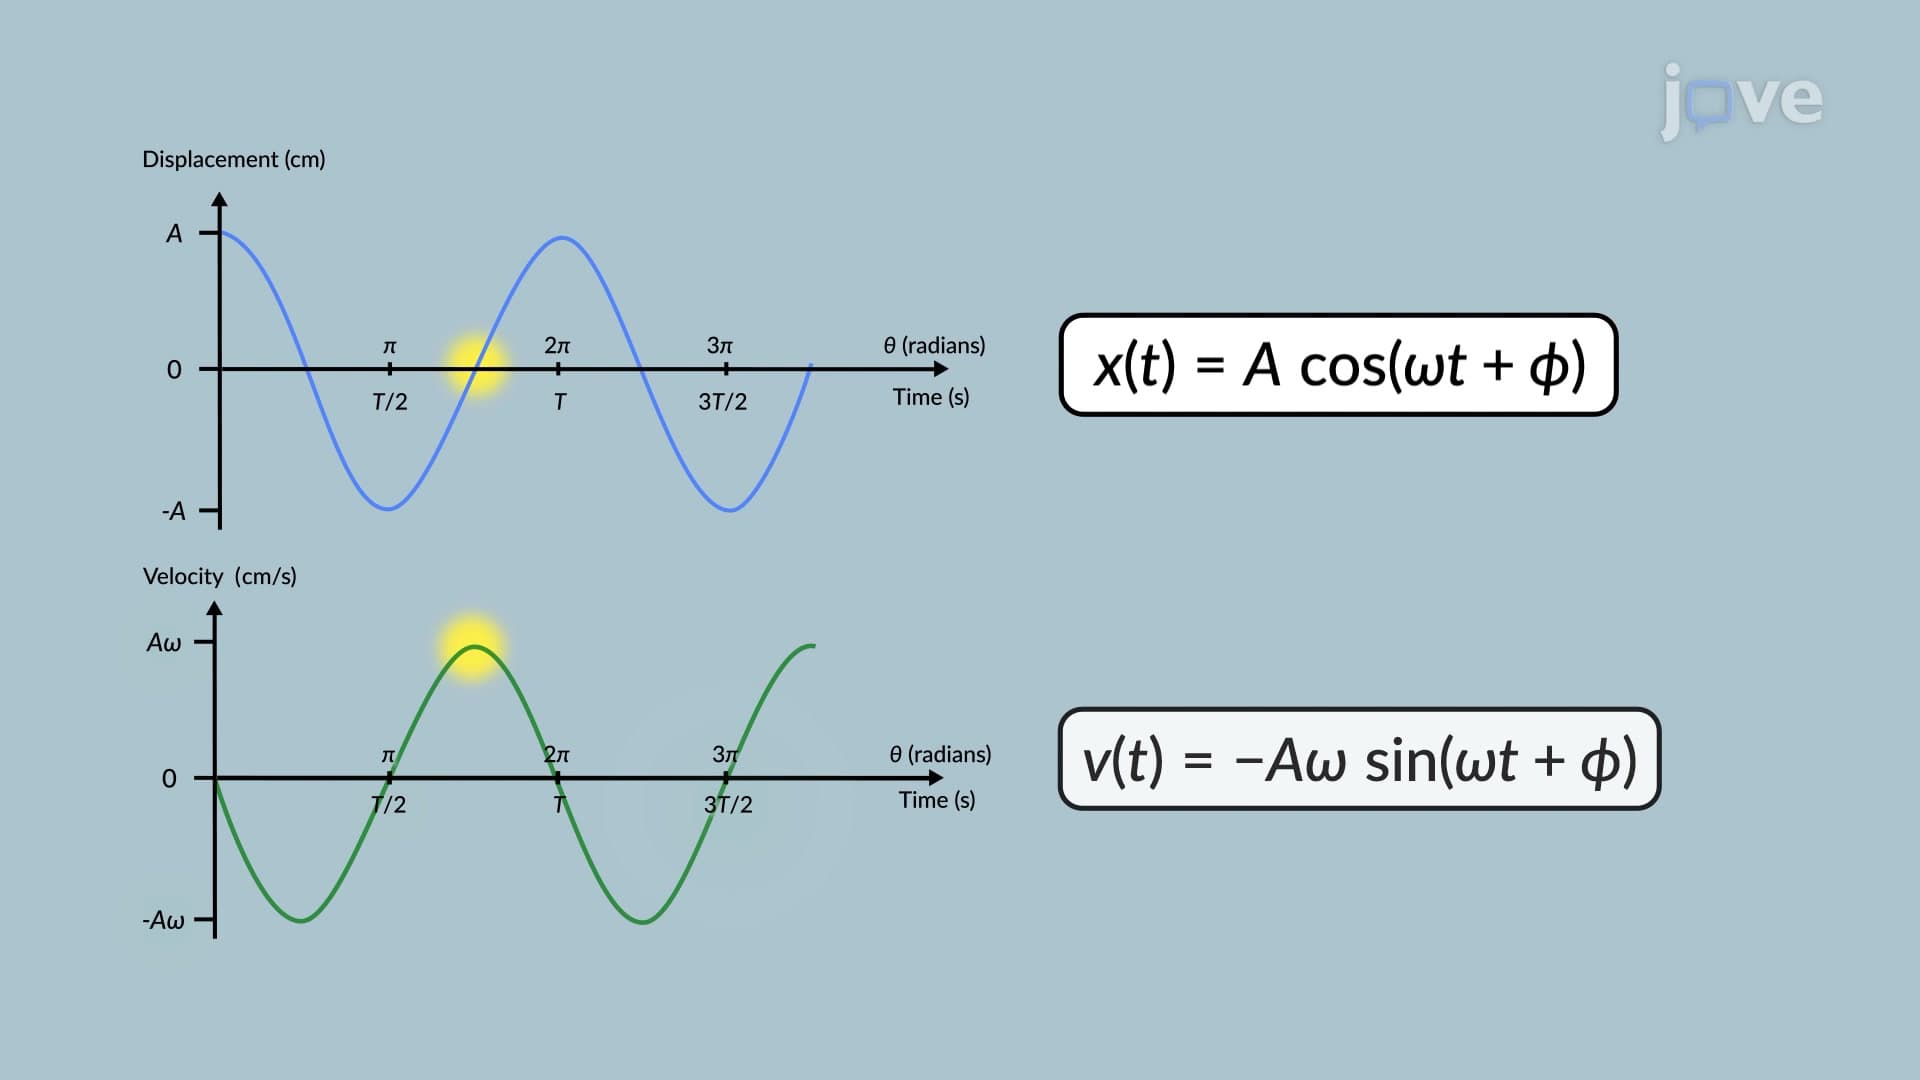
Characteristics of Simple Harmonic Motion
 01:22
Upsampling
 01:10
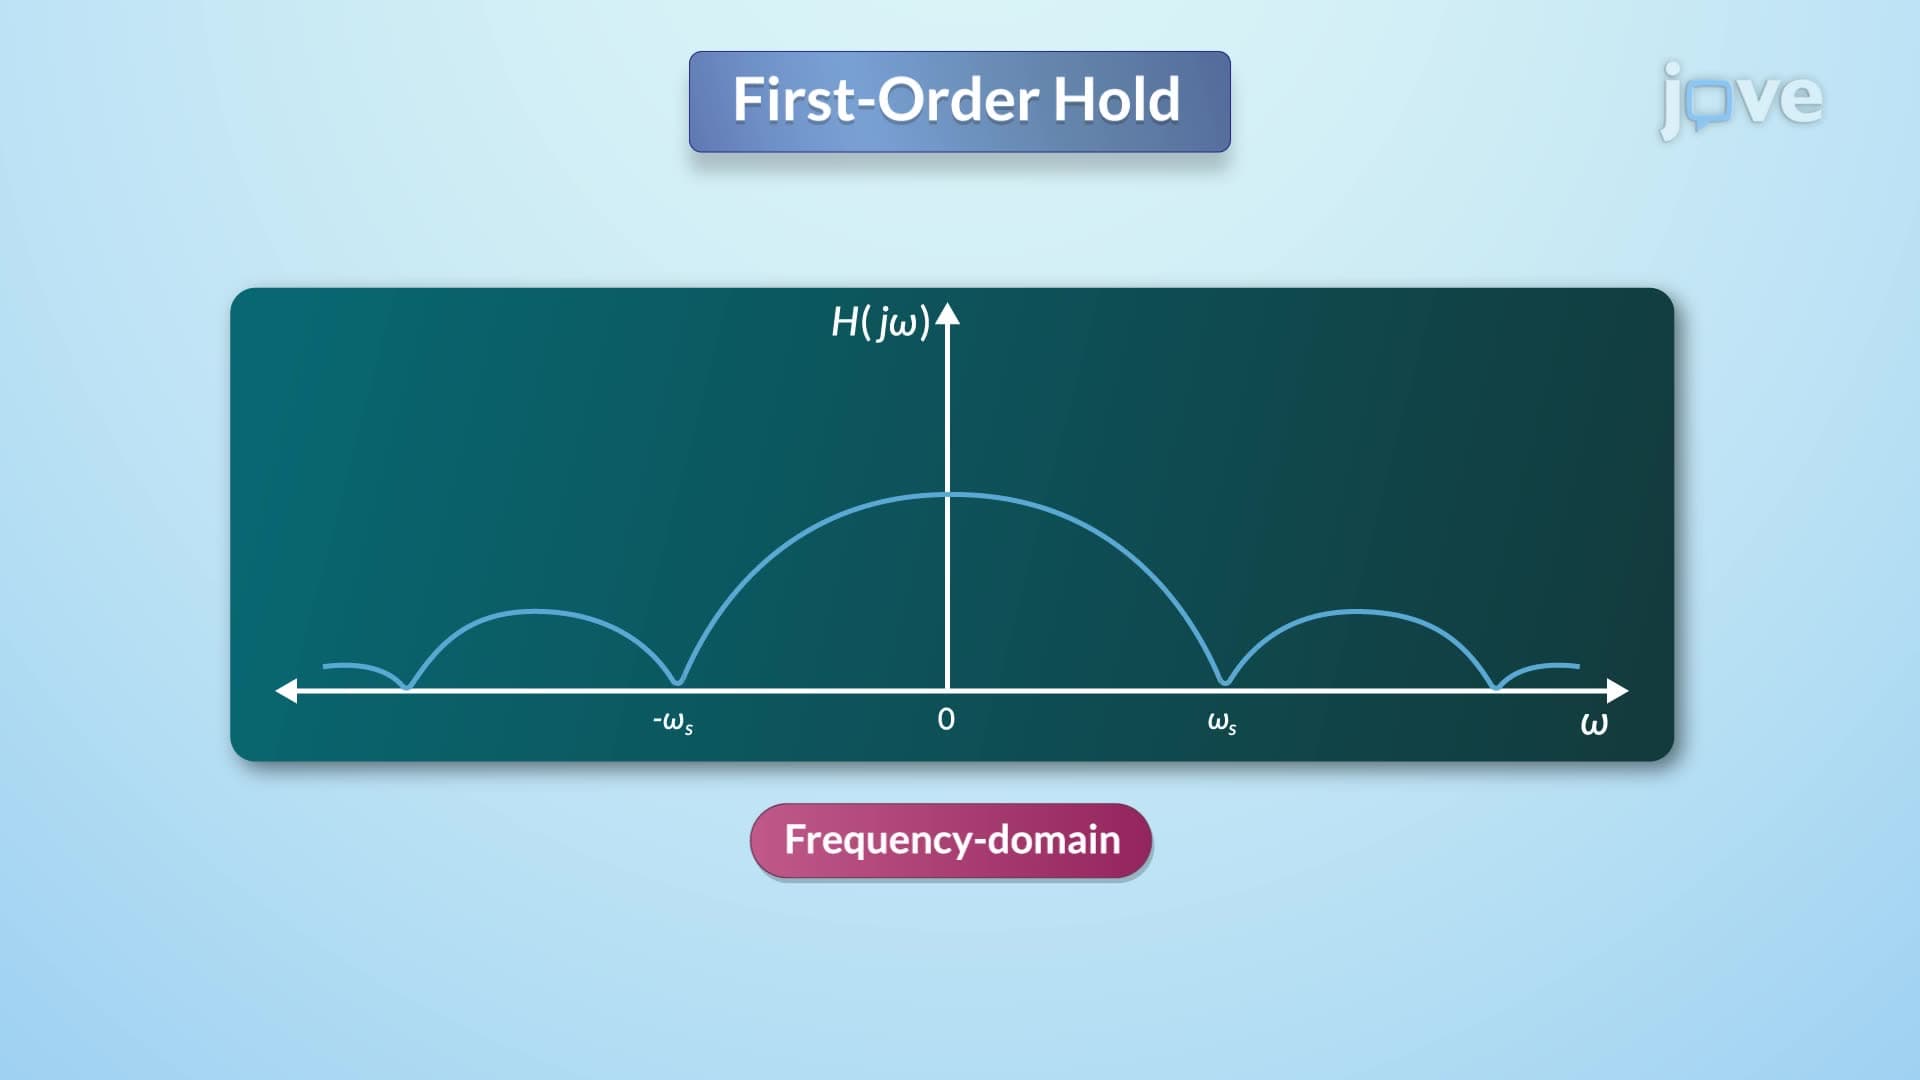
Reconstruction of Signal using Interpolation
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:18
Exponential and Sinusoidal Signals