Related Experiment Video
Updated: Apr 30, 2026


WheelCon: A Wheel Control-Based Gaming Platform for Studying Human Sensorimotor Control
Published on: August 15, 2020
Discrete-time neural inverse optimal control for nonlinear systems via passivation

Abstract:
This paper presents a discrete-time inverse optimal neural controller, which is constituted by combination of two techniques: 1) inverse optimal control to avoid solving the Hamilton-Jacobi-Bellman equation associated with nonlinear system optimal control and 2) on-line neural identification, using a recurrent neural network trained with an extended Kalman filter, in order to build a model of the assumed unknown nonlinear system. The inverse optimal controller is based on passivity theory. The applicability of the proposed approach is illustrated via simulations for an unstable nonlinear system and a planar robot.
Related Concept Videos
 01:27
Time and frequency -Domain Interpretation of PI Control
Acting as a low-pass filter, the PI controller slows the system's response and extends settling times. This requires...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:26
Linear Approximation in Frequency Domain
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:24
PI Controller: Design
 01:21
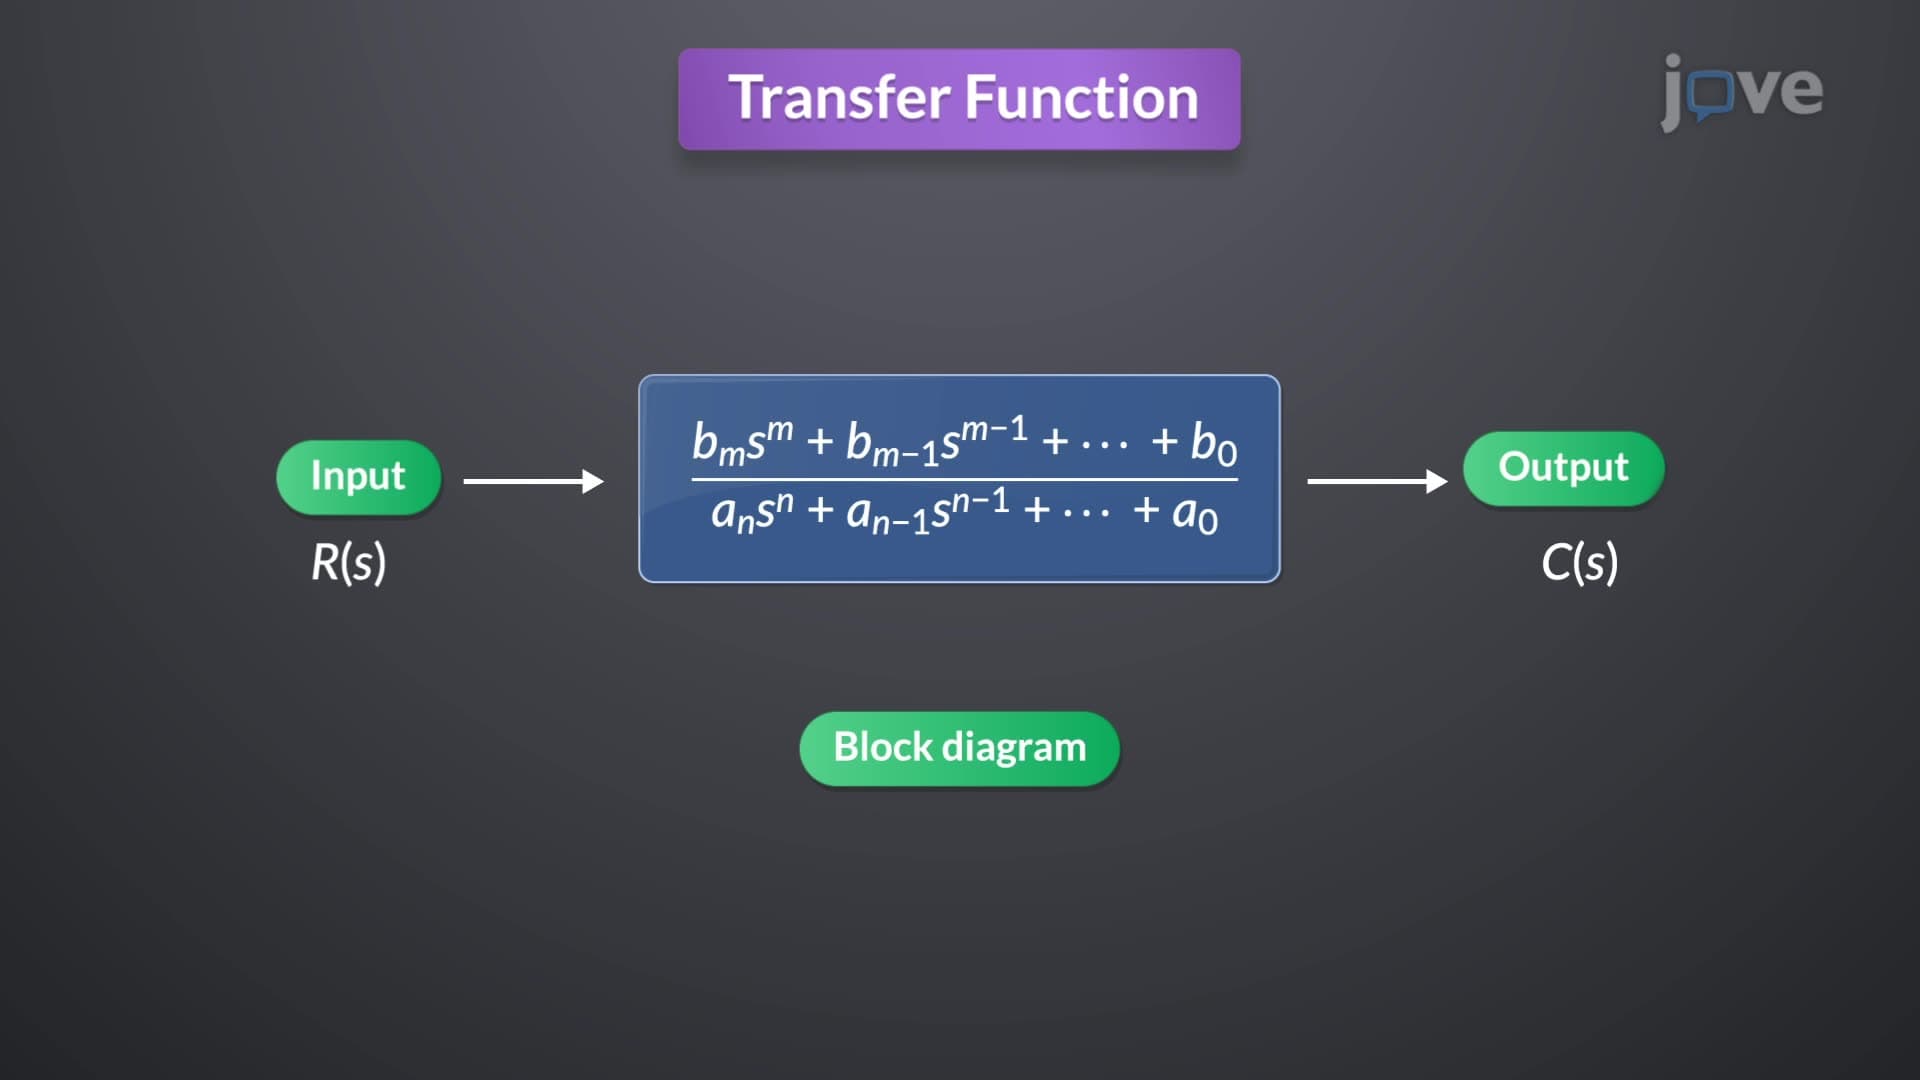
Transfer Function in Control Systems
To derive the transfer function, consider a general nth-order linear time-invariant...