Related Experiment Video
Updated: Apr 30, 2026
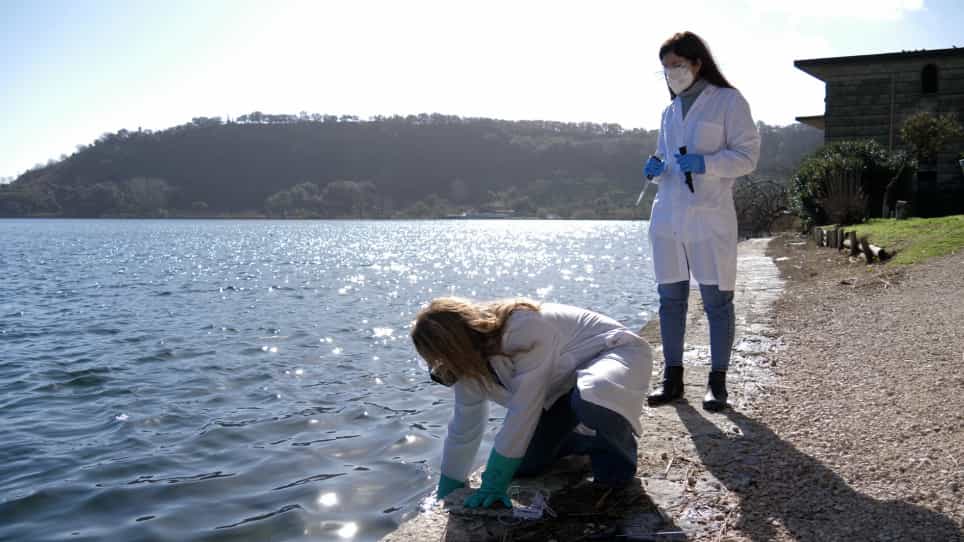

Early Detection of Cyanobacterial Blooms and Associated Cyanotoxins using Fast Detection Strategy
Published on: February 25, 2021
Real time detecting of harmful dinoflagellate Cochlodinium polykrikoides using unmanned surface vehicle in dynamic

Abstract:
Since the first occurrence in 1982, red tides have been observed annually in Korean coastal waters in the form of harmful dinoflagellate Cochlodinium polykrikoides blooms. The distinction in the proposed method for red tide monitoring is the focus on the narrow stripe red tide at an early stage to allow for advanced actions. The distance graph between Head of Narrow Red tide (HNR) and location of the robot have suggested in reference to unknown searching area. With mapping and path planning, then, it can quickly keep tracking out even if the magnitude and direction of current flow was changed. The one-hundred times simulations of different situations were attempted to comparison by box plot both algorithms of speed by reaching the right side of simulation window. Consequently, the red tide tracking algorithm is based on the red tide probability map and the tracking & recovering path planner. Inputs to the algorithm include the measured flow velocities and the detection or non-detection state at each robot location. Furthermore, a USV (Unmanned Surface Vehicle) model is added to evaluate the effectiveness of the algorithm. This approach for red tide monitoring may lead to a breakthrough in the field of environmental surveillance.
More Related Videos
 09:22
Quantitatively Measuring In situ Flows using a Self-Contained Underwater Velocimetry Apparatus SCUVA
Published on: October 31, 2011
 13:35
Reefshape: A System for the Efficient Collection and Automated Processing of Time-Series Underwater Photogrammetry Data for Benthic Habitat Monitoring
Published on: June 13, 2025