Related Experiment Video
Updated: Apr 30, 2026
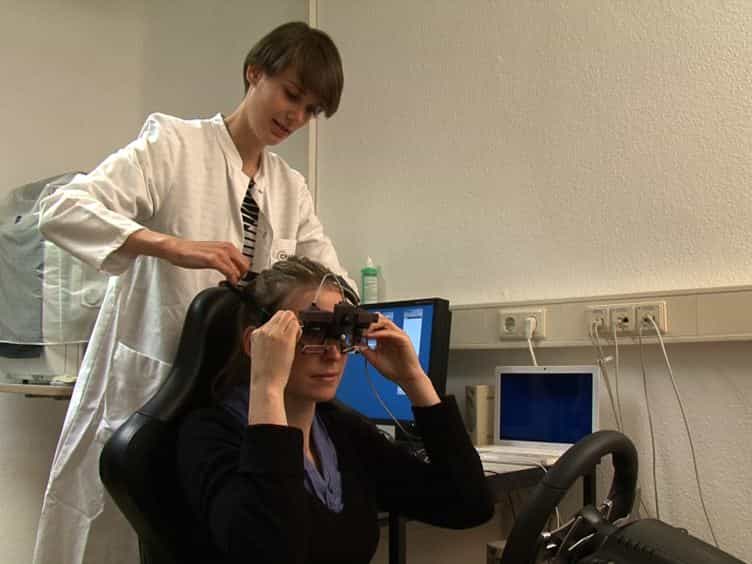

Driving Simulation in the Clinic: Testing Visual Exploratory Behavior in Daily Life Activities in Patients with Visual Field Defects
Published on: September 18, 2012
Effect of driving experience on anticipatory look-ahead fixations in real curve driving
Esko Lehtonen1, Otto Lappi2, Iivo Koirikivi3
1Traffic Research Unit, Institute of Behavioural Sciences, University of Helsinki, Finland; Cognitive Science, Institute of Behavioural Sciences, University of Helsinki, Finland.

Abstract:
Anticipatory skills are a potential factor for novice drivers' curve accidents. Behavioural data show that steering and speed regulation are affected by forward planning of the trajectory. When approaching a curve, the relevant visual information for online steering control and for planning is located at different eccentricities, creating a need to disengage the gaze from the guidance of steering to anticipatory look-ahead fixations over curves. With experience, peripheral vision can be increasingly used in the visual guidance of steering. This could leave experienced drivers more gaze time to invest on look-ahead fixations over curves, facilitating the trajectory planning. Eighteen drivers (nine novices, nine experienced) drove an instrumented vehicle on a rural road four times in both directions. Their eye movements were analyzed in six curves. The trajectory of the car was modelled and divided to approach, entry and exit phases. Experienced drivers spent less time on the road-ahead and more time on the look-ahead fixations over the curves. Look-ahead fixations were also more common in the approach than in the entry phase of the curve. The results suggest that with experience drivers allocate greater part of their visual attention to trajectory planning.

Related Concept Videos
 01:29
Sight Distance in a Vertical Curve
 01:25
The Anchoring-and-Adjustment Heuristic
 01:17
Dynamics Of Circular Motion: Applications
 01:27
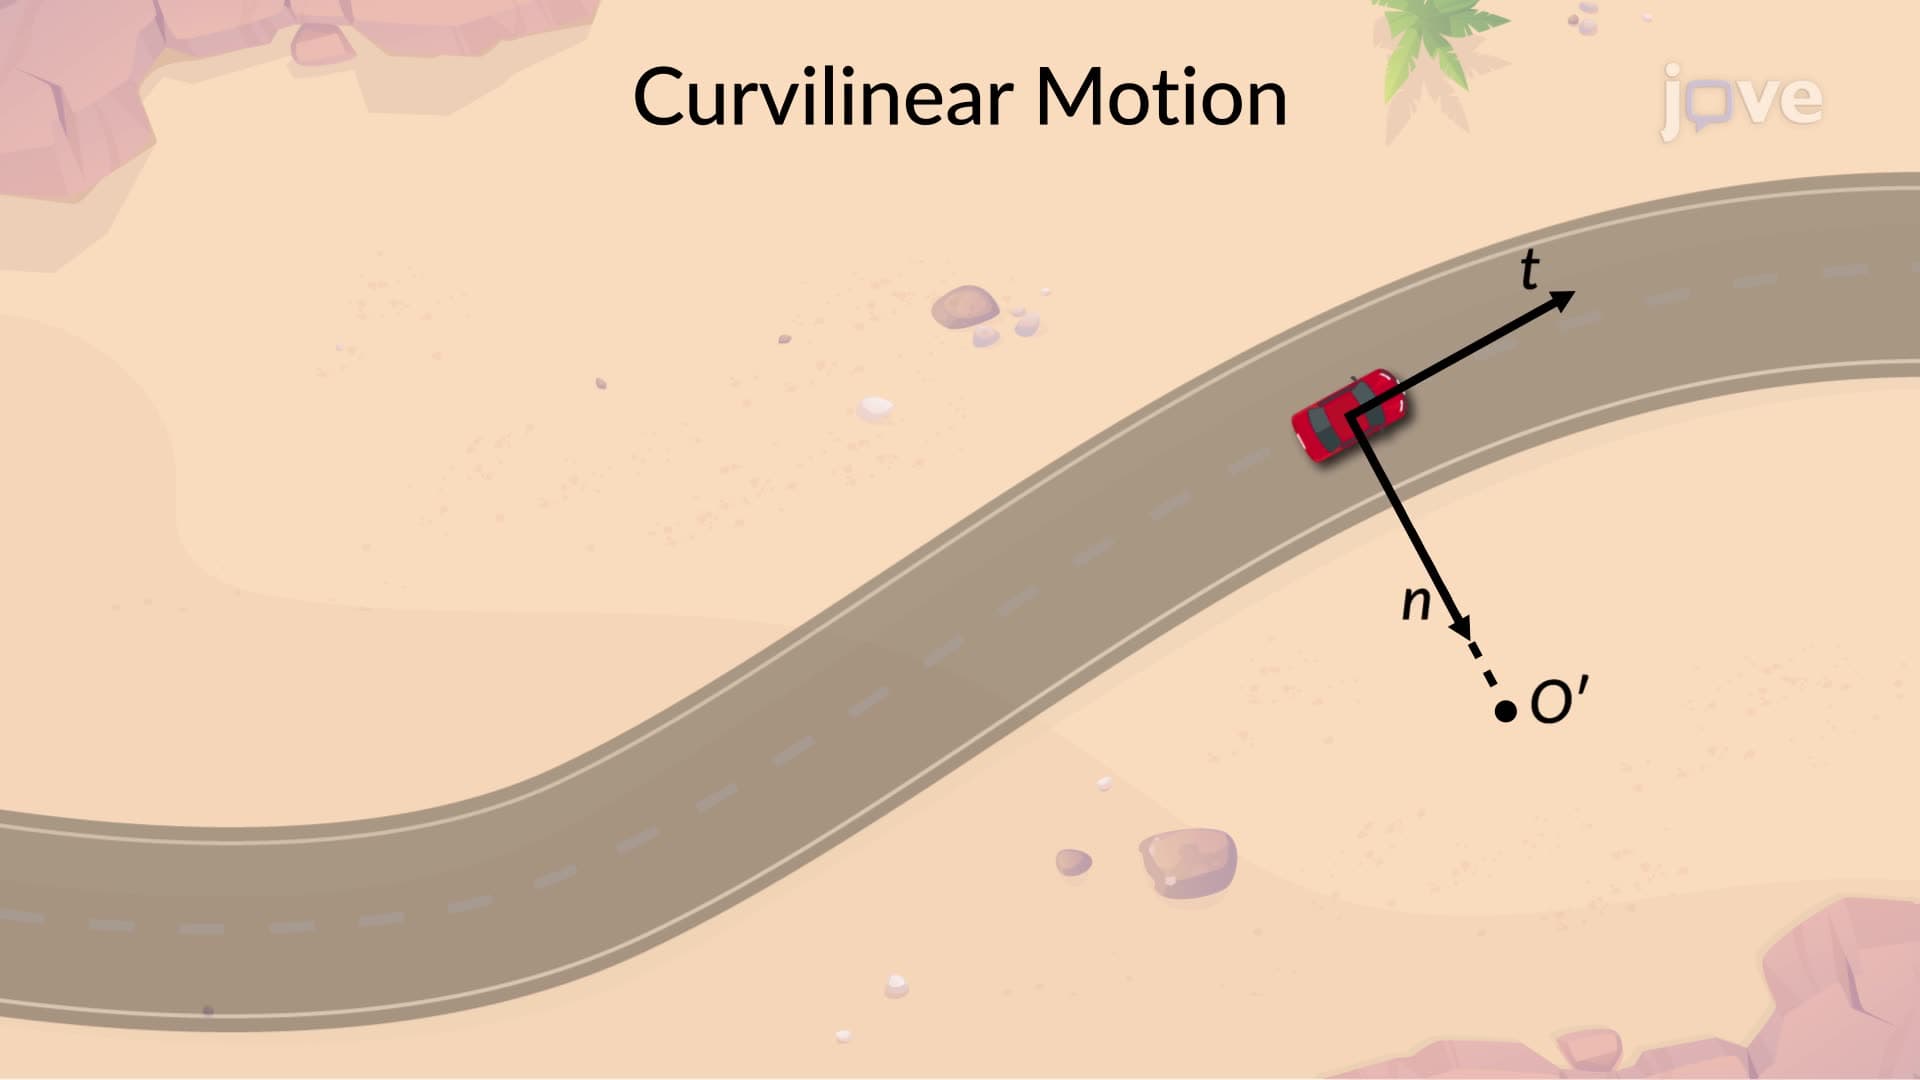
Curvilinear Motion: Normal and Tangential Components
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...