Related Experiment Video
Updated: Apr 27, 2026

Adaptation of a Haptic Robot in a 3T fMRI
Published on: October 4, 2011
Portable haptic interface with omni-directional movement and force capability

Abstract:
We describe the design of a new mobile haptic interface that employs wheels for force rendering. The interface, consisting of an omni-directional Killough type platform, provides 2DOF force feedback with different control modalities. The system autonomously performs sensor fusion for localization and force rendering. This paper explains the relevant choices concerning the functional aspects, the control design, the mechanical and electronic solution. Experimental results for force feedback characterization are reported.

Related Concept Videos
 01:14
Design Example: Resistive Touchscreen
When a user touches the screen, the two layers make contact at a specific point known as the touchpoint. This contact reduces the resistance between...
 01:30
Three-Dimensional Force System
 01:07
Frictional Force
 01:26
Kinetic Friction
 01:05
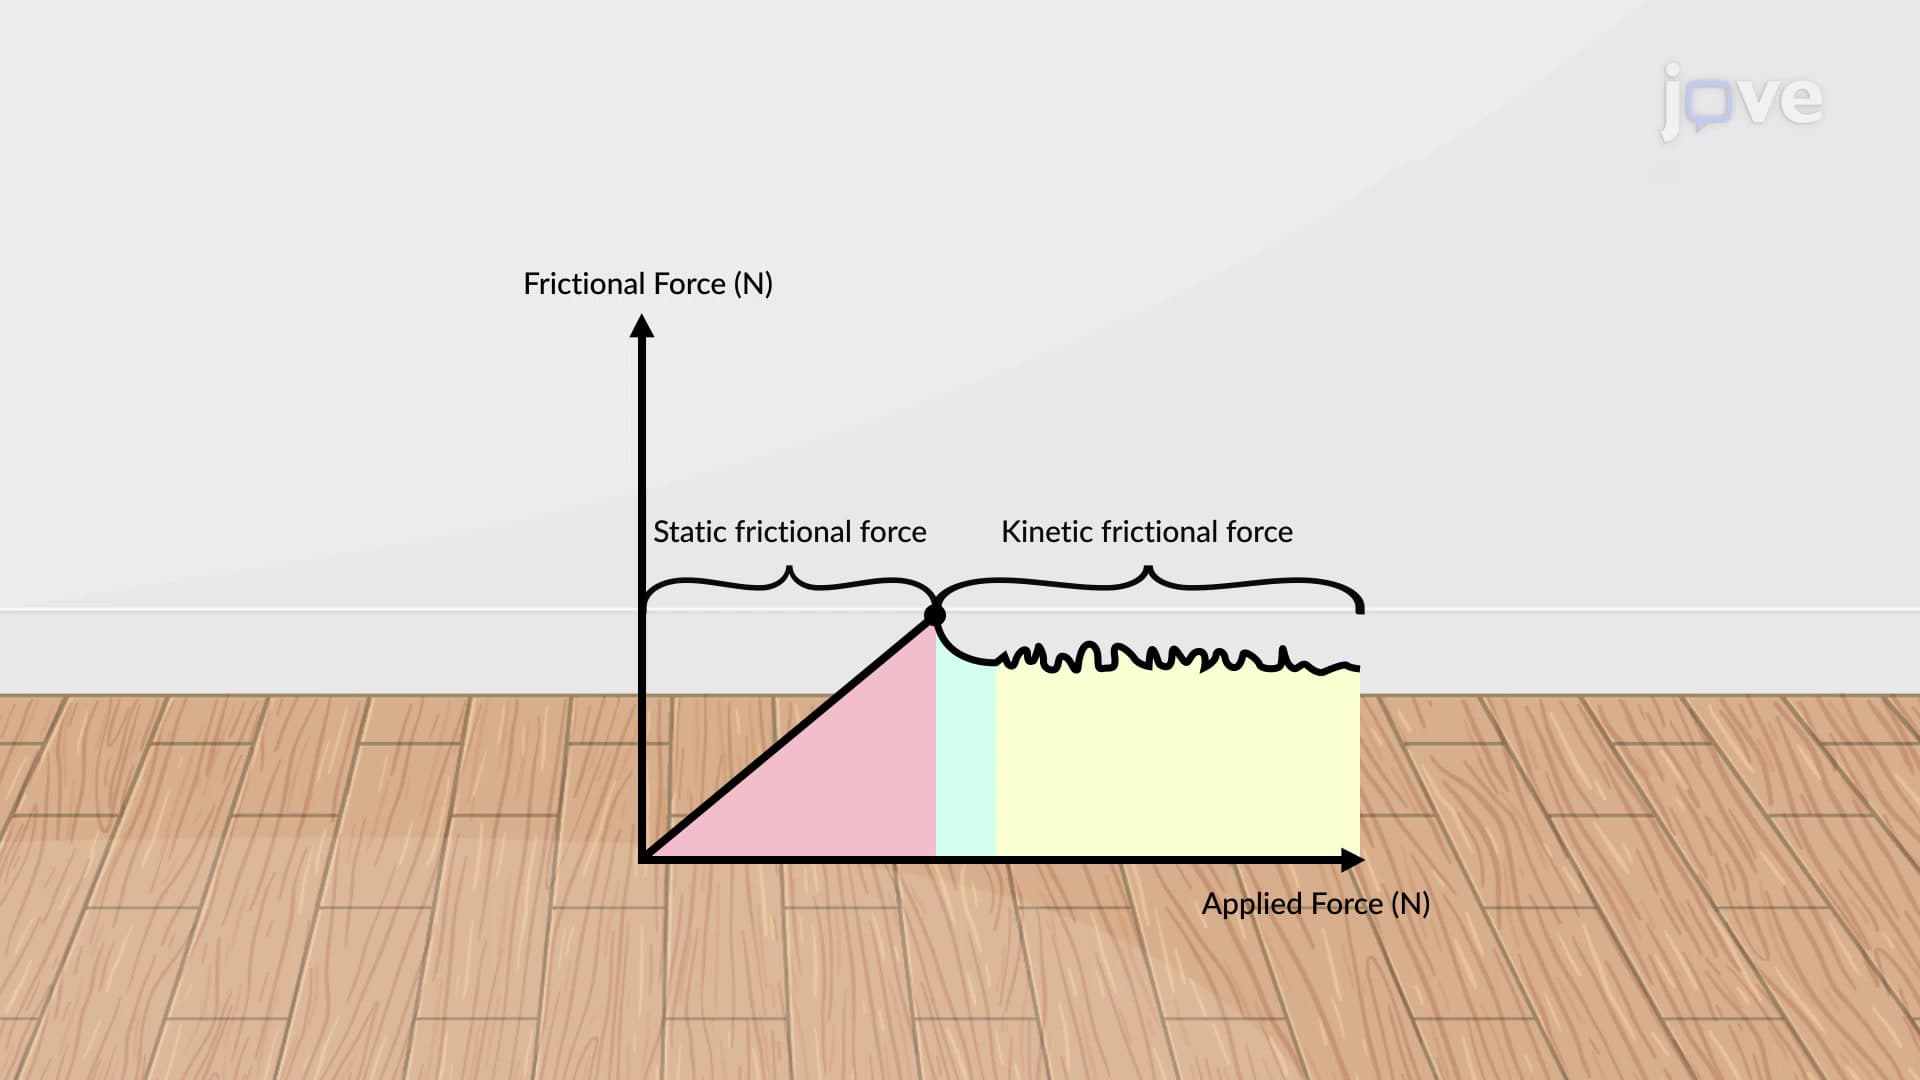
Static and Kinetic Frictional Force
However, if two systems are in contact and are stationary relative to one...
 01:20
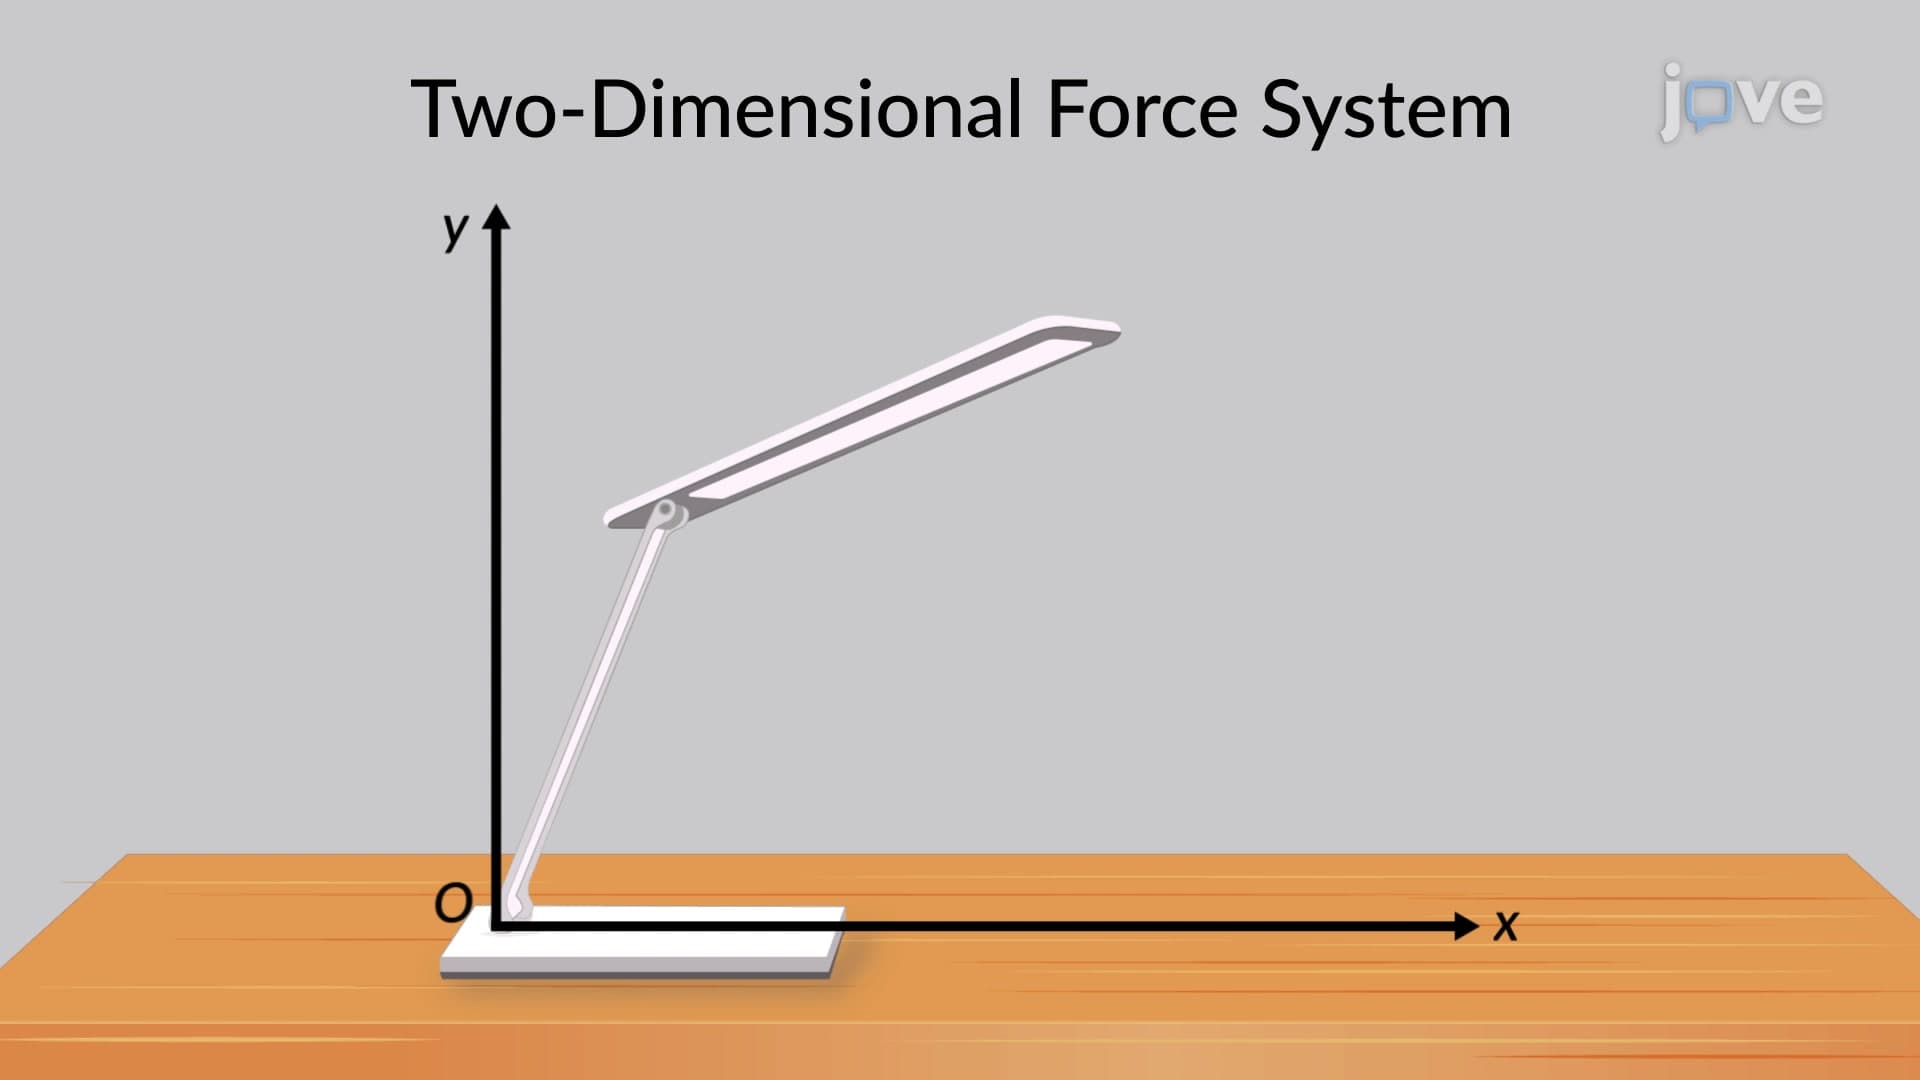
Two-Dimensional Force System