Related Experiment Video
Updated: Apr 27, 2026
Visualization Method for Proprioceptive Drift on a 2D Plane Using Support Vector Machine
Published on: October 27, 2016
Drift-free position estimation for periodic movements using inertial units

Abstract:
Latest advances in microelectromechanical systems have made inertial units (IUs) a powerful tool for human motion analysis. However, difficulties in handling their output signals must be overcome. The purpose of this study was to develop the novel "PB-algorithm" based on polynomial data fitting, splines interpolation, and the wavelet transform, one after the other, to cancel drift disturbances in position estimation for periodic movements. High-accuracy position measurements from an optical system (Vicon Nexus 1.0) were used to validate the proposed method and comparison with another drift-correction algorithm was provided. Results indicate the accuracy with respect to the Vicon's reference signal (euclidean error lower than 54.62 × 10(-3) m and correlation coefficient higher than 0.968). A reduction of the root-mean-square error of 68.74% was obtained when the proposed two-step method was compared with a modified-band limited Fourier linear combiner. All methods were applied to data from the 30-s chair stand test, which is one of the most used clinical tests dealing with lower body strength assessment, falls prediction, and gait disorders in older adults. The relevance of this study is that after cancelling drift disturbances, and obtaining an accurate Z-position estimation, it is possible to evaluate the sit-to-stand and stand-to-sit transitions from the whole test.
More Related Videos
 06:52
An Inertial Measurement Unit Based Method to Estimate Hip and Knee Joint Kinematics in Team Sport Athletes on the Field
Published on: May 26, 2020
 11:57
Three-dimensional Super Resolution Microscopy of F-actin Filaments by Interferometric PhotoActivated Localization Microscopy iPALM
Published on: December 1, 2016
Related Concept Videos
 01:03
Inertial Frames of Reference
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:27
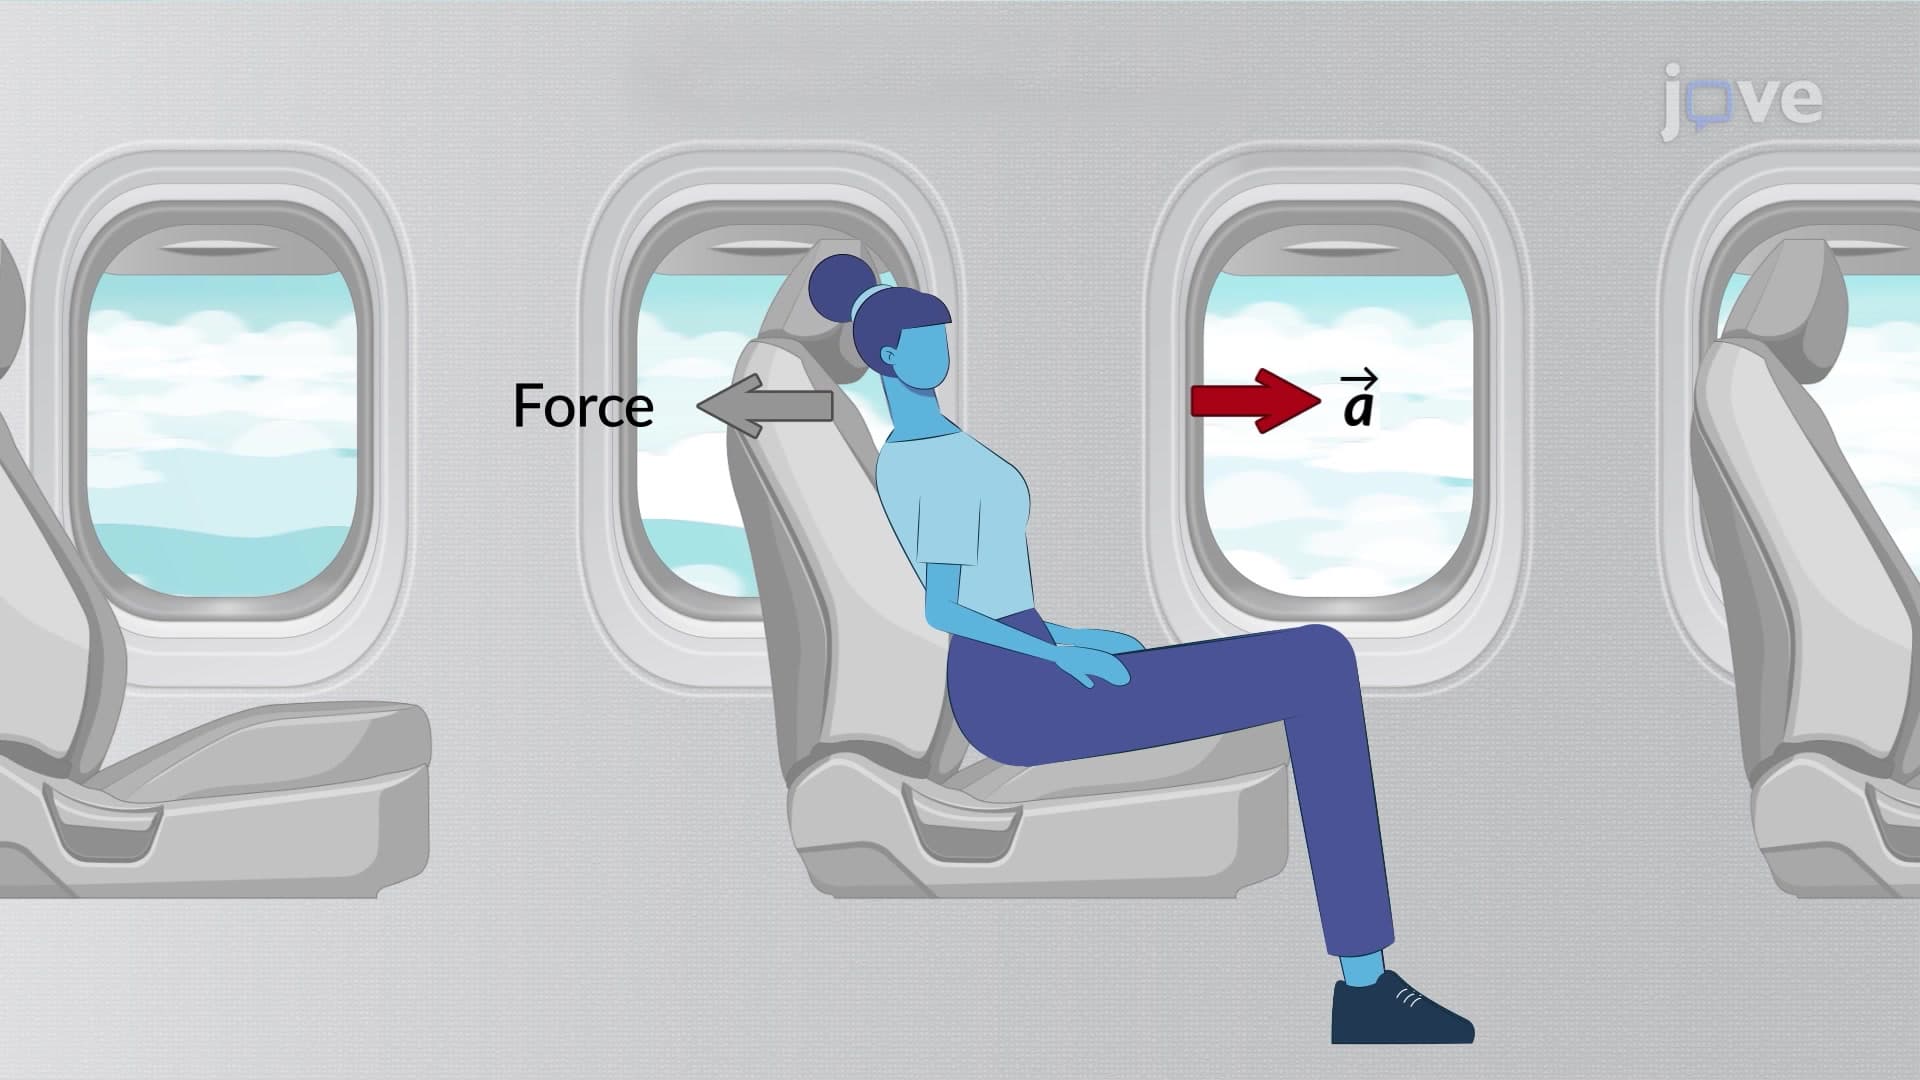
Non-inertial Frames of Reference
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...