Linearly estimating all parameters of affine motion using Radon transform
Related Experiment Video
Updated: Apr 26, 2026
Measuring 3D In-vivo Shoulder Kinematics using Biplanar Videoradiography
Published on: March 12, 2021

Abstract:
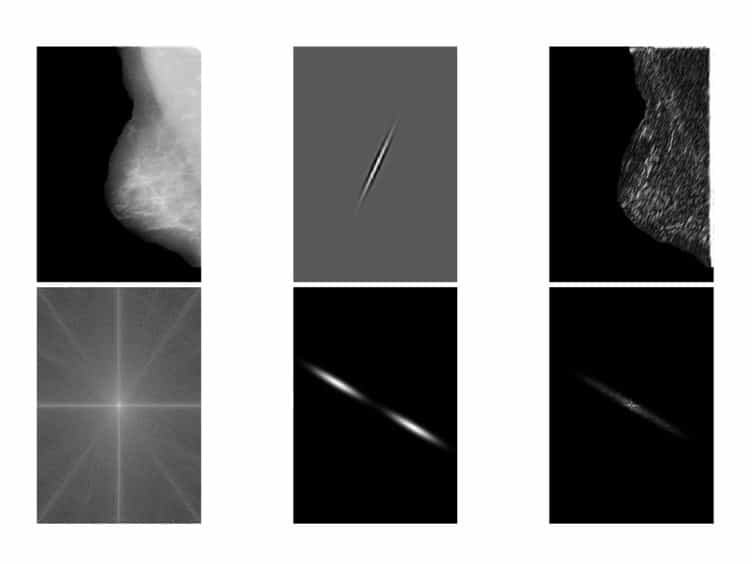
Fast and accurate motion estimation takes an important place in many fields of computer vision and image processing. Using Radon transform to compute projections of the images along specified directions is an effective way to show the relationship between the 2D image object and its projections and estimate motions between the images. All existing projection-based motion estimation methods without the use of iteration have a severe defect that only five of the six affine parameters can be estimated. There are some other methods that can estimate the six parameters, but most of them are usually based on a certain iterative framework, which is computationally intensive and sensitively dependent on the initial values. In this paper, a novel method based on Radon transform is proposed to estimate all the six affine parameters directly. The relationship in the projection domain between a pair of images connected by an affine motion is studied and a linear model is established, by which all the six affine parameters can be directively found. The employment of a hierarchical framework can produce more accurate results. The experimental results reveal that the proposed method has a much better performance than the state-of-the-art methods in this field.
More Related Videos

Related Concept Videos
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the...
 01:26
Linearization and Approximation
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...