Related Experiment Video
Updated: Apr 25, 2026


Sit-to-stand-and-walk from 120% Knee Height: A Novel Approach to Assess Dynamic Postural Control Independent of Lead-limb
Published on: August 30, 2016
Torque-stiffness-controlled dynamic walking with central pattern generators
Yan Huang1, Bram Vanderborght, Ronald Van Ham
1Intelligent Control Laboratory, College of Engineering, Peking University, Beijing , 100871, China.

Abstract:
Walking behavior is modulated by controlling joint torques in most existing passivity-based bipeds. Controlled Passive Walking with adaptable stiffness exhibits controllable natural motions and energy efficient gaits. In this paper, we propose torque-stiffness-controlled dynamic bipedal walking, which extends the concept of Controlled Passive Walking by introducing structured control parameters and a bio-inspired control method with central pattern generators. The proposed walking paradigm is beneficial in clarifying the respective effects of the external actuation and the internal natural dynamics. We present a seven-link biped model to validate the presented walking. Effects of joint torque and joint stiffness on gait selection, walking performance and walking pattern transitions are studied in simulations. The work in this paper develops a new solution of motion control of bipedal robots with adaptable stiffness and provides insights of efficient and sophisticated walking gaits of humans.


Related Concept Videos
 01:17
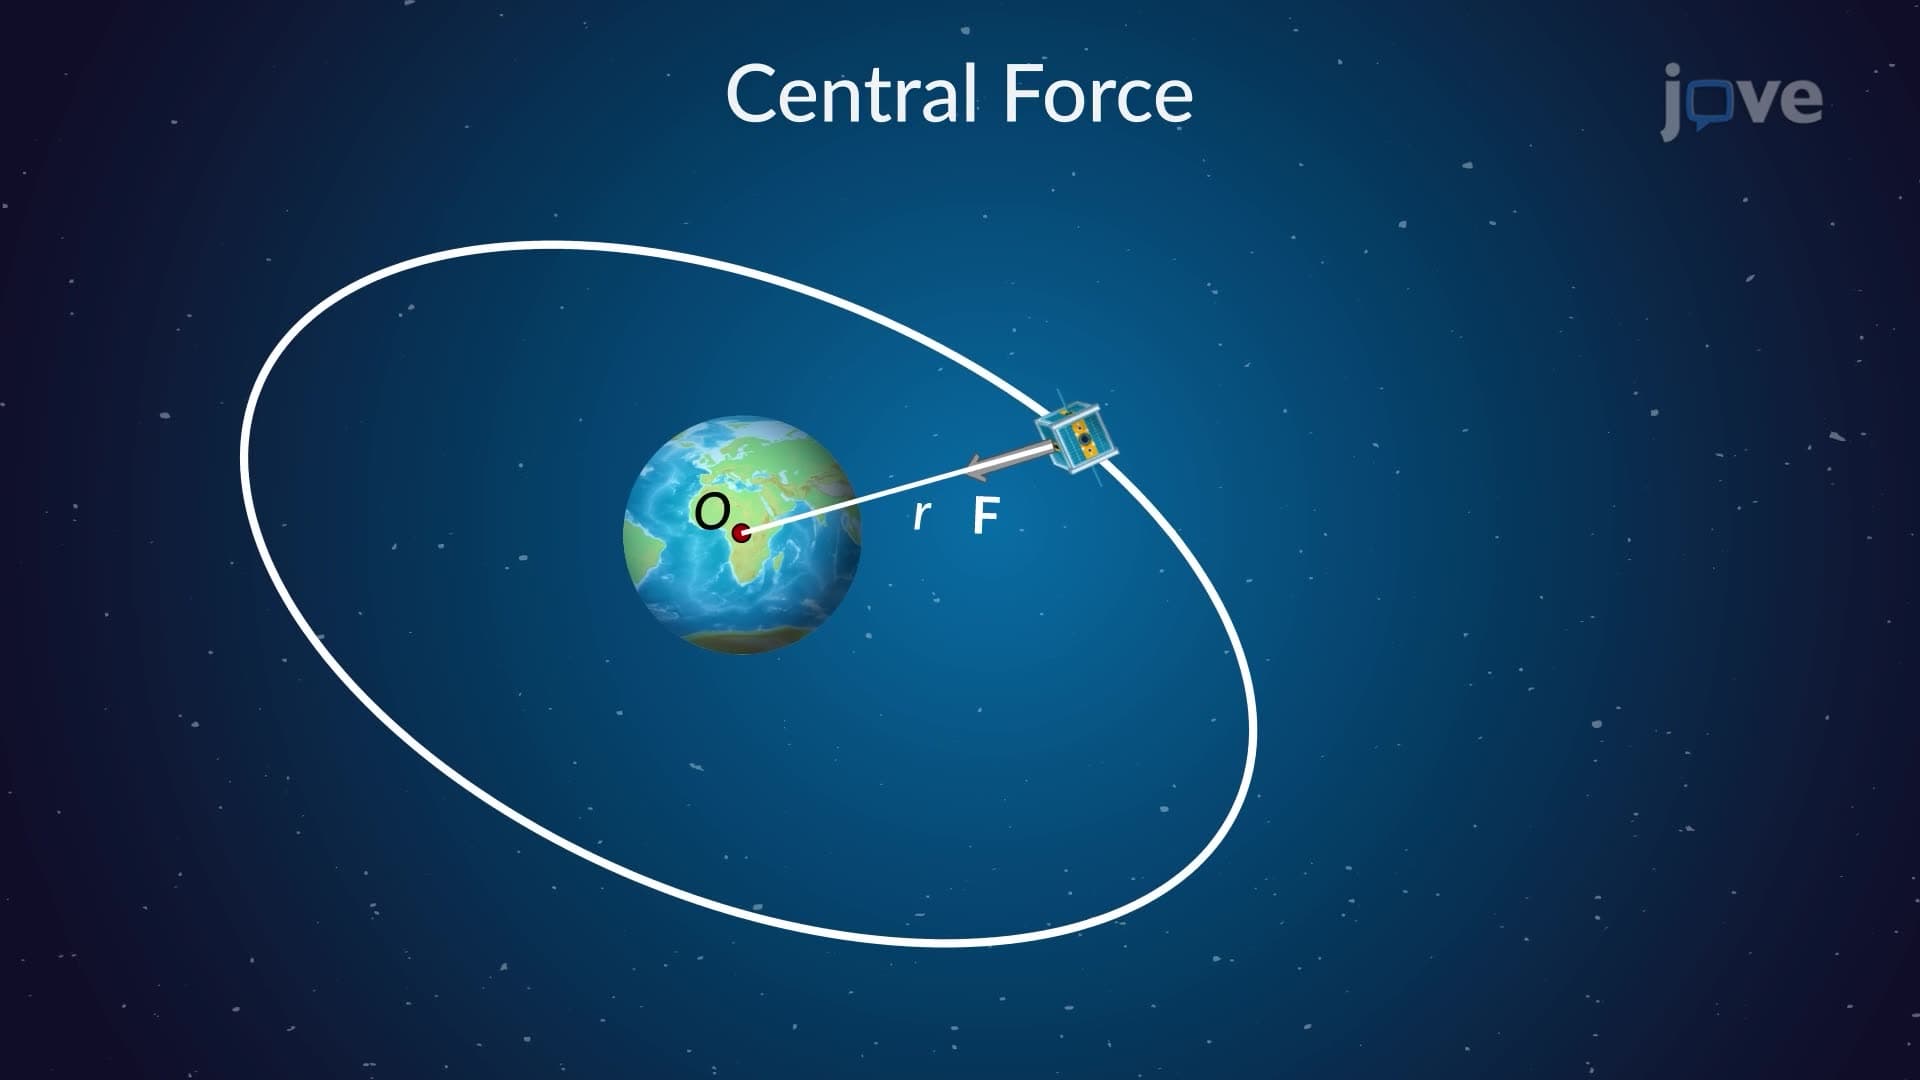
Central-Force Motion
 01:15
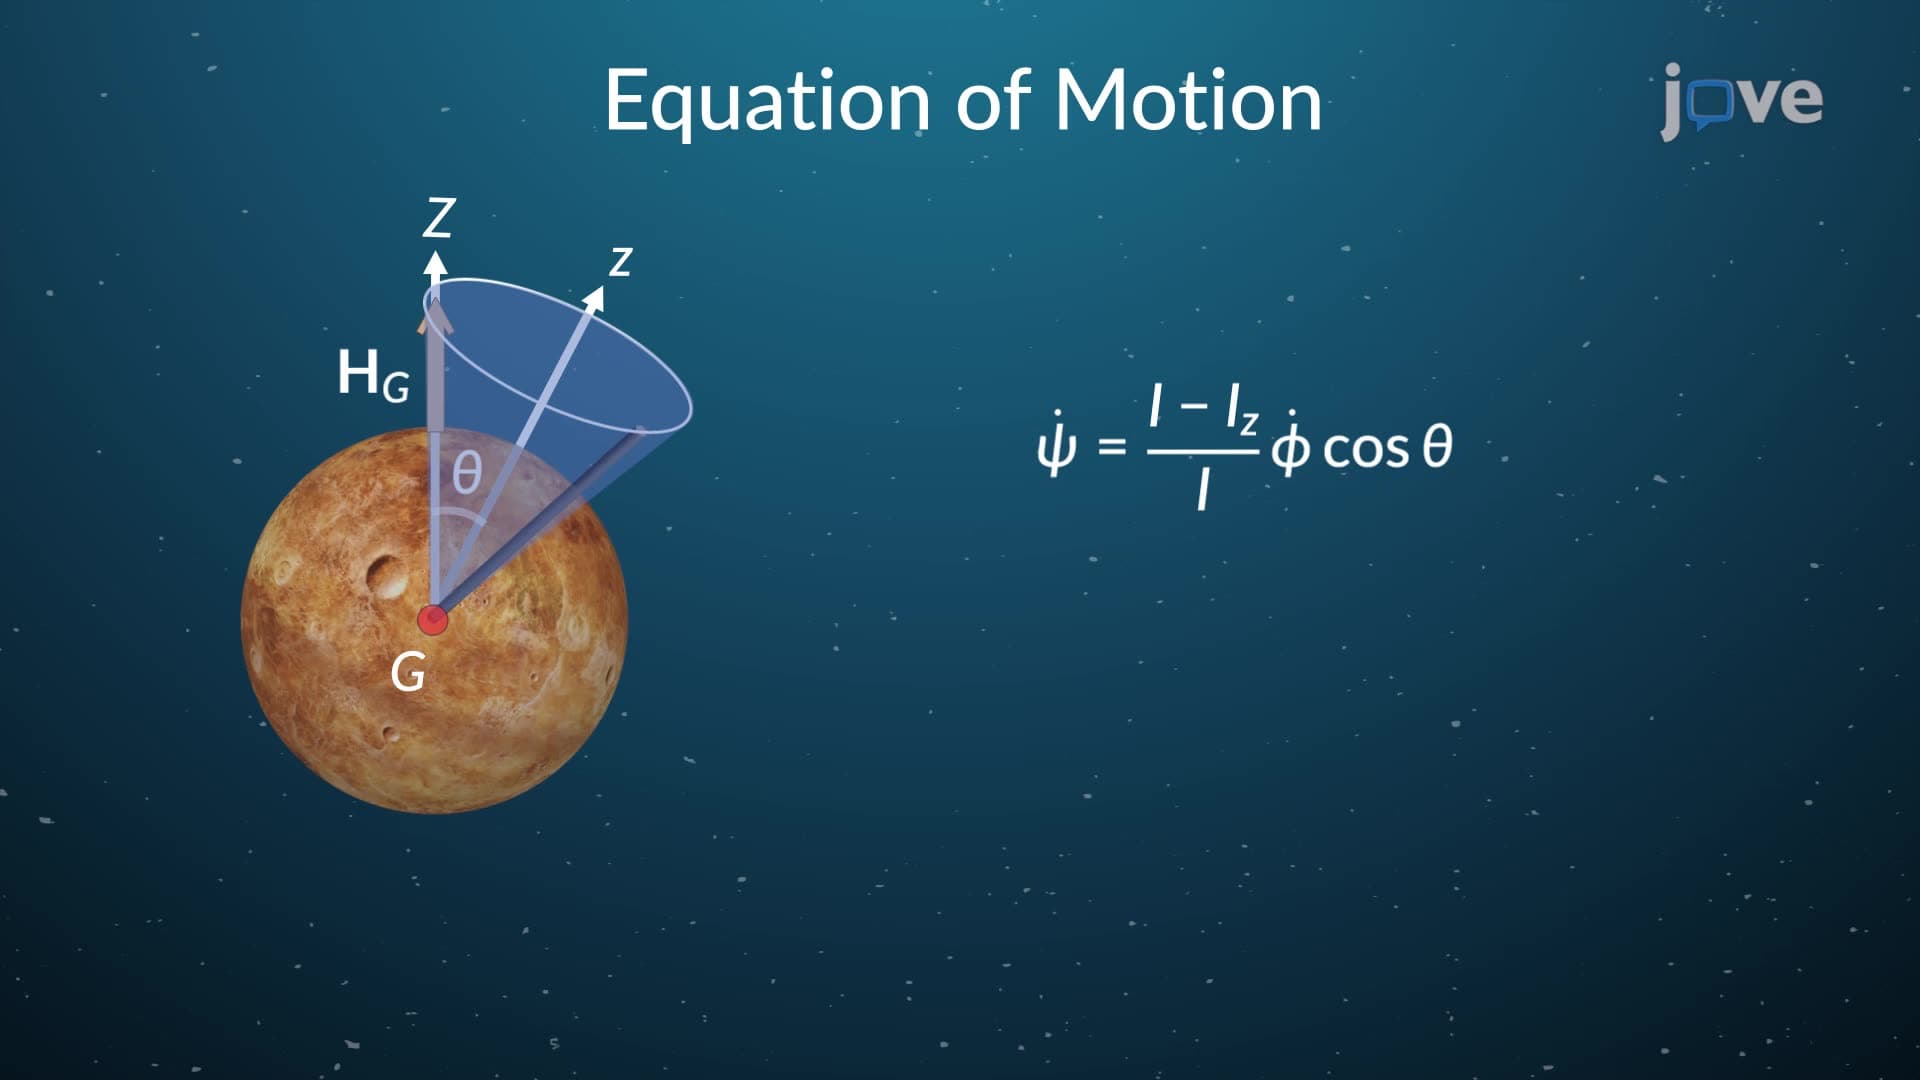
Torque Free Motion
 01:11
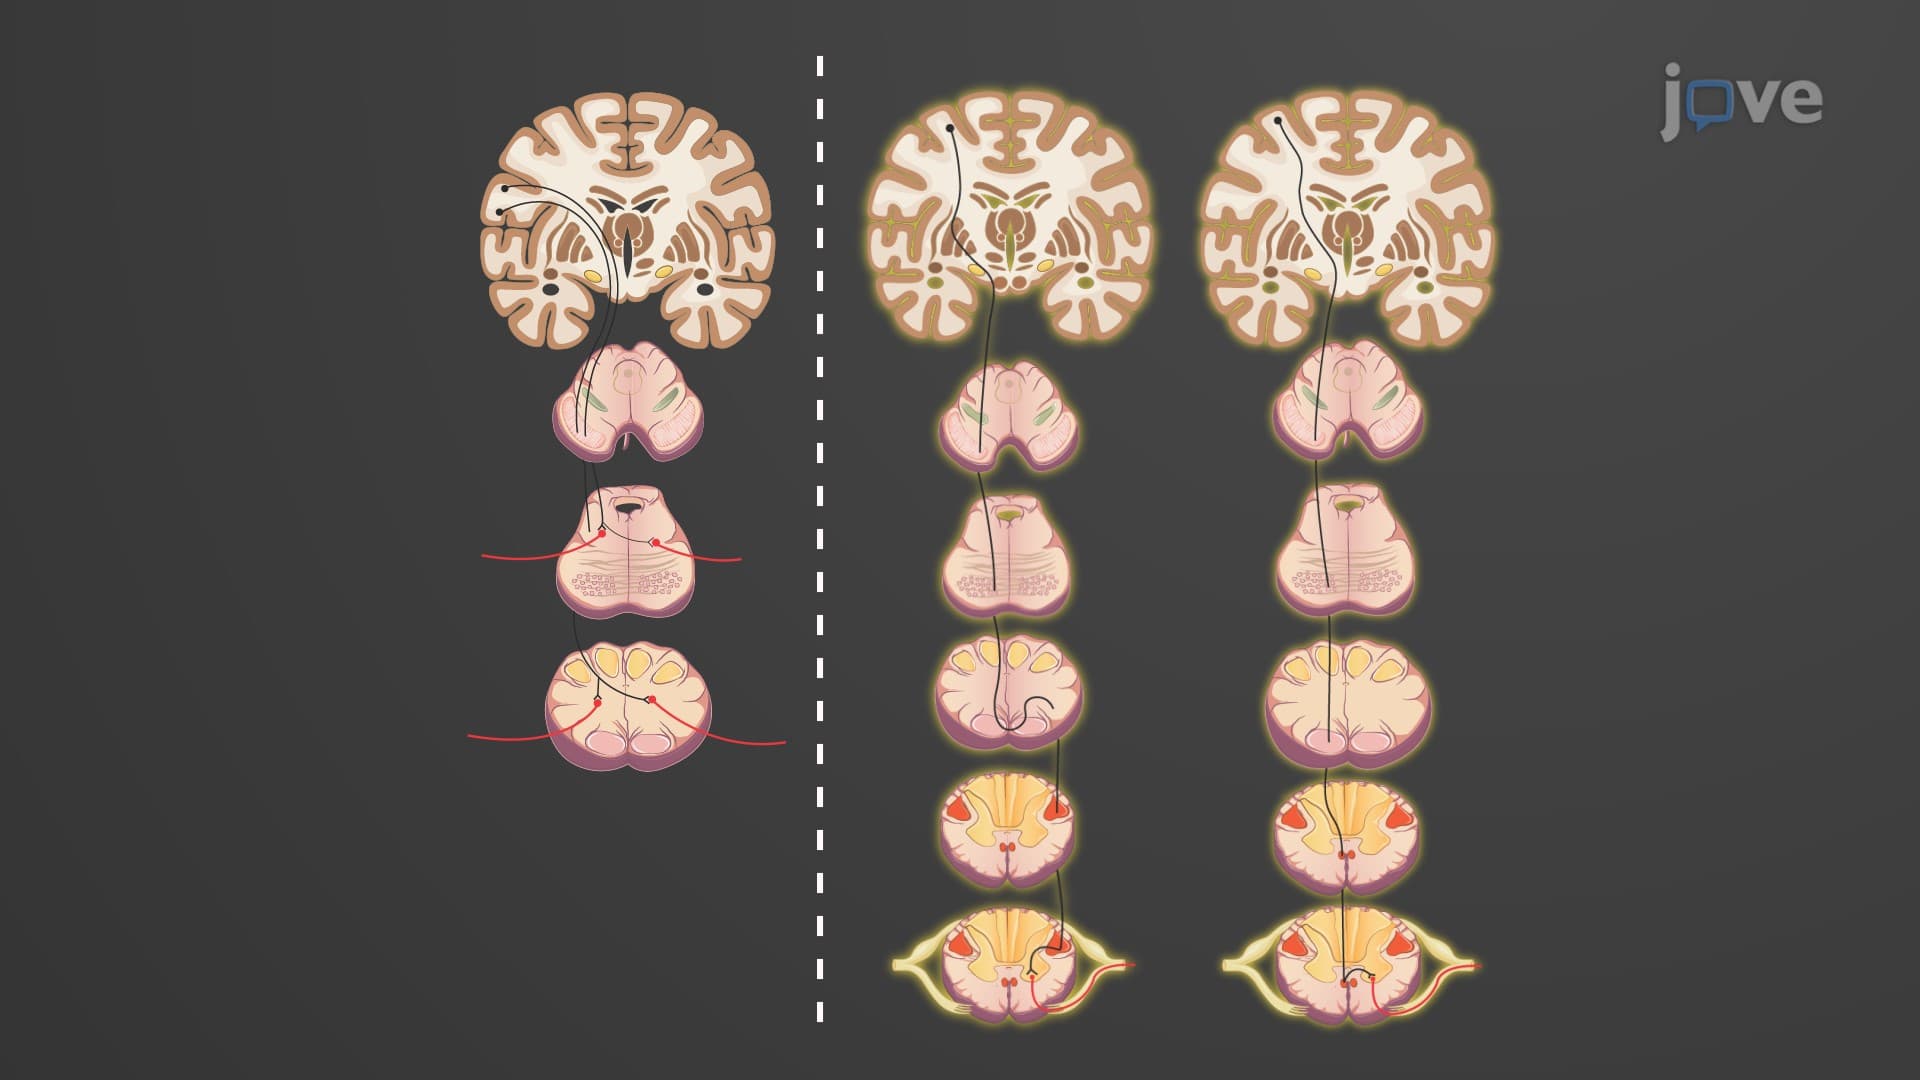
Direct Motor Pathways
The corticospinal tract is responsible for the voluntary movement of the limbs and trunk. It originates in the cerebral cortex of the brain and descends through the cerebrum's internal capsule and...