

A new design of robust H∞ sliding mode control for uncertain stochastic T-S fuzzy time-delay systems

Abstract:
In this paper, a novel dynamic sliding mode control scheme is proposed for a class of uncertain stochastic nonlinear time-delay systems represented by Takagi-Sugeno fuzzy models. The key advantage of the proposed scheme is that two very restrictive assumptions in most existing sliding mode control approaches for stochastic fuzzy systems have been removed. It is shown that the closed-loop control system trajectories can be driven onto the sliding surface in finite time almost certainly. It is also shown that the stochastic stability of the resulting sliding motion can be guaranteed in terms of linear matrix inequalities; moreover, the sliding-mode controller can be obtained simultaneously. Simulation results illustrating the advantages and effectiveness of the proposed approaches are also provided.
More Related Videos
 08:18
WheelCon: A Wheel Control-Based Gaming Platform for Studying Human Sensorimotor Control
Published on: August 15, 2020
 09:01
Gain-compensation Methodology for a Sinusoidal Scan of a Galvanometer Mirror in Proportional-Integral-Differential Control Using Pre-emphasis Techniques
Published on: April 4, 2017
Related Concept Videos
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:27
Time and frequency -Domain Interpretation of PI Control
Acting as a low-pass filter, the PI controller slows the system's response and extends settling times. This requires...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:18
Second Order systems II
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be...
 01:21
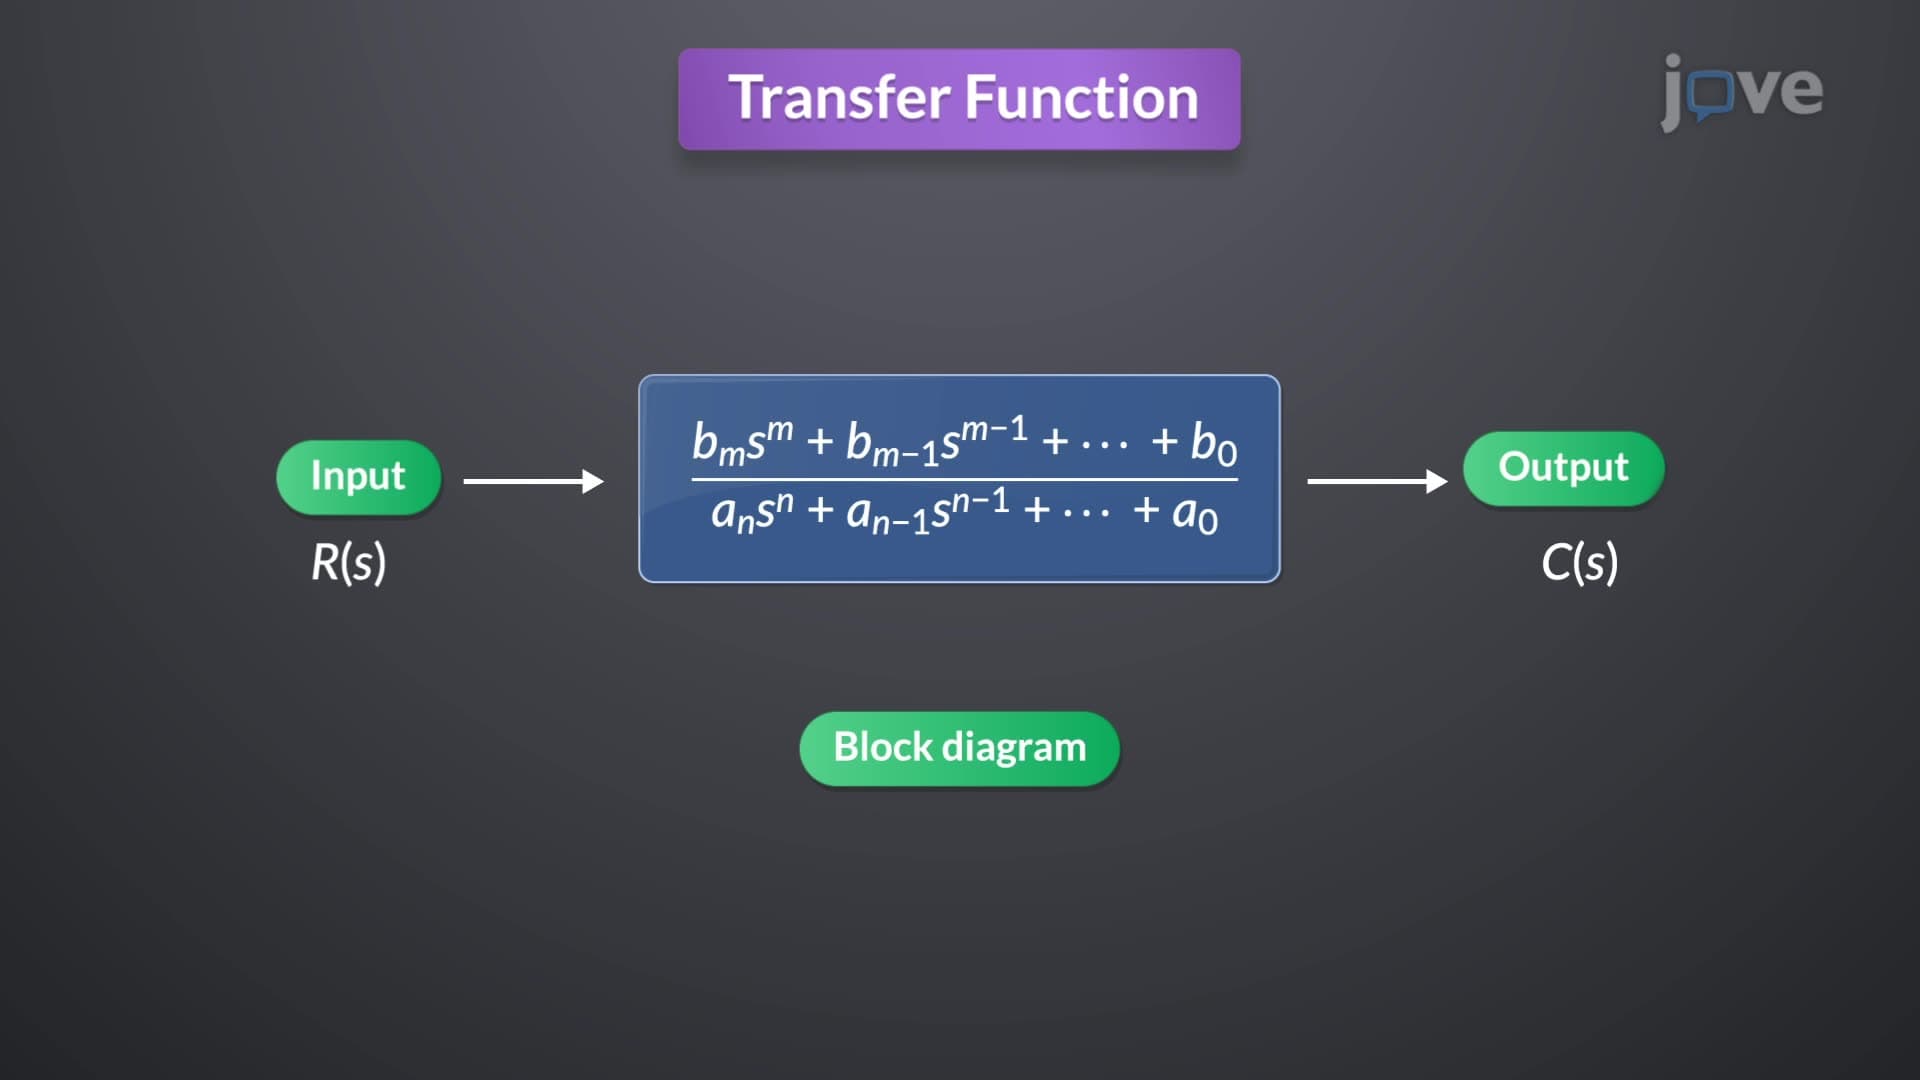
Transfer Function in Control Systems
To derive the transfer function, consider a general nth-order linear time-invariant...