Related Experiment Video
Updated: Apr 25, 2026


Manufacturing, Control, and Performance Evaluation of a Gecko-Inspired Soft Robot
Published on: June 10, 2020
Periodic spring-mass running over uneven terrain through feedforward control of landing conditions
Luther R Palmer1, Caitrin E Eaton
1Department of Computer Science and Engineering, University of South Florida, Tampa, Florida 33620, USA.

Abstract:
This work pursues a feedforward control algorithm for high-speed legged locomotion over uneven terrain. Being able to rapidly negotiate uneven terrain without visual or a priori information about the terrain will allow legged systems to be used in time-critical applications and alongside fast-moving humans or vehicles. The algorithm is shown here implemented on a spring-loaded inverted pendulum model in simulation, and can be configured to approach fixed running height over uneven terrain or self-stable terrain following. Offline search identifies unique landing conditions that achieve a desired apex height with a constant stride period over varying ground levels. Because the time between the apex and touchdown events is directly related to ground height, the landing conditions can be computed in real time as continuous functions of this falling time. Enforcing a constant stride period reduces the need for inertial sensing of the apex event, which is nontrivial for physical systems, and allows for clocked feedfoward control of the swing leg.
More Related Videos
 08:35
Interactive and Visualized Online Experimentation System for Engineering Education and Research
Published on: November 24, 2021
 11:06
A Human-machine-interface Integrating Low-cost Sensors with a Neuromuscular Electrical Stimulation System for Post-stroke Balance Rehabilitation
Published on: April 12, 2016
Related Concept Videos
 01:17
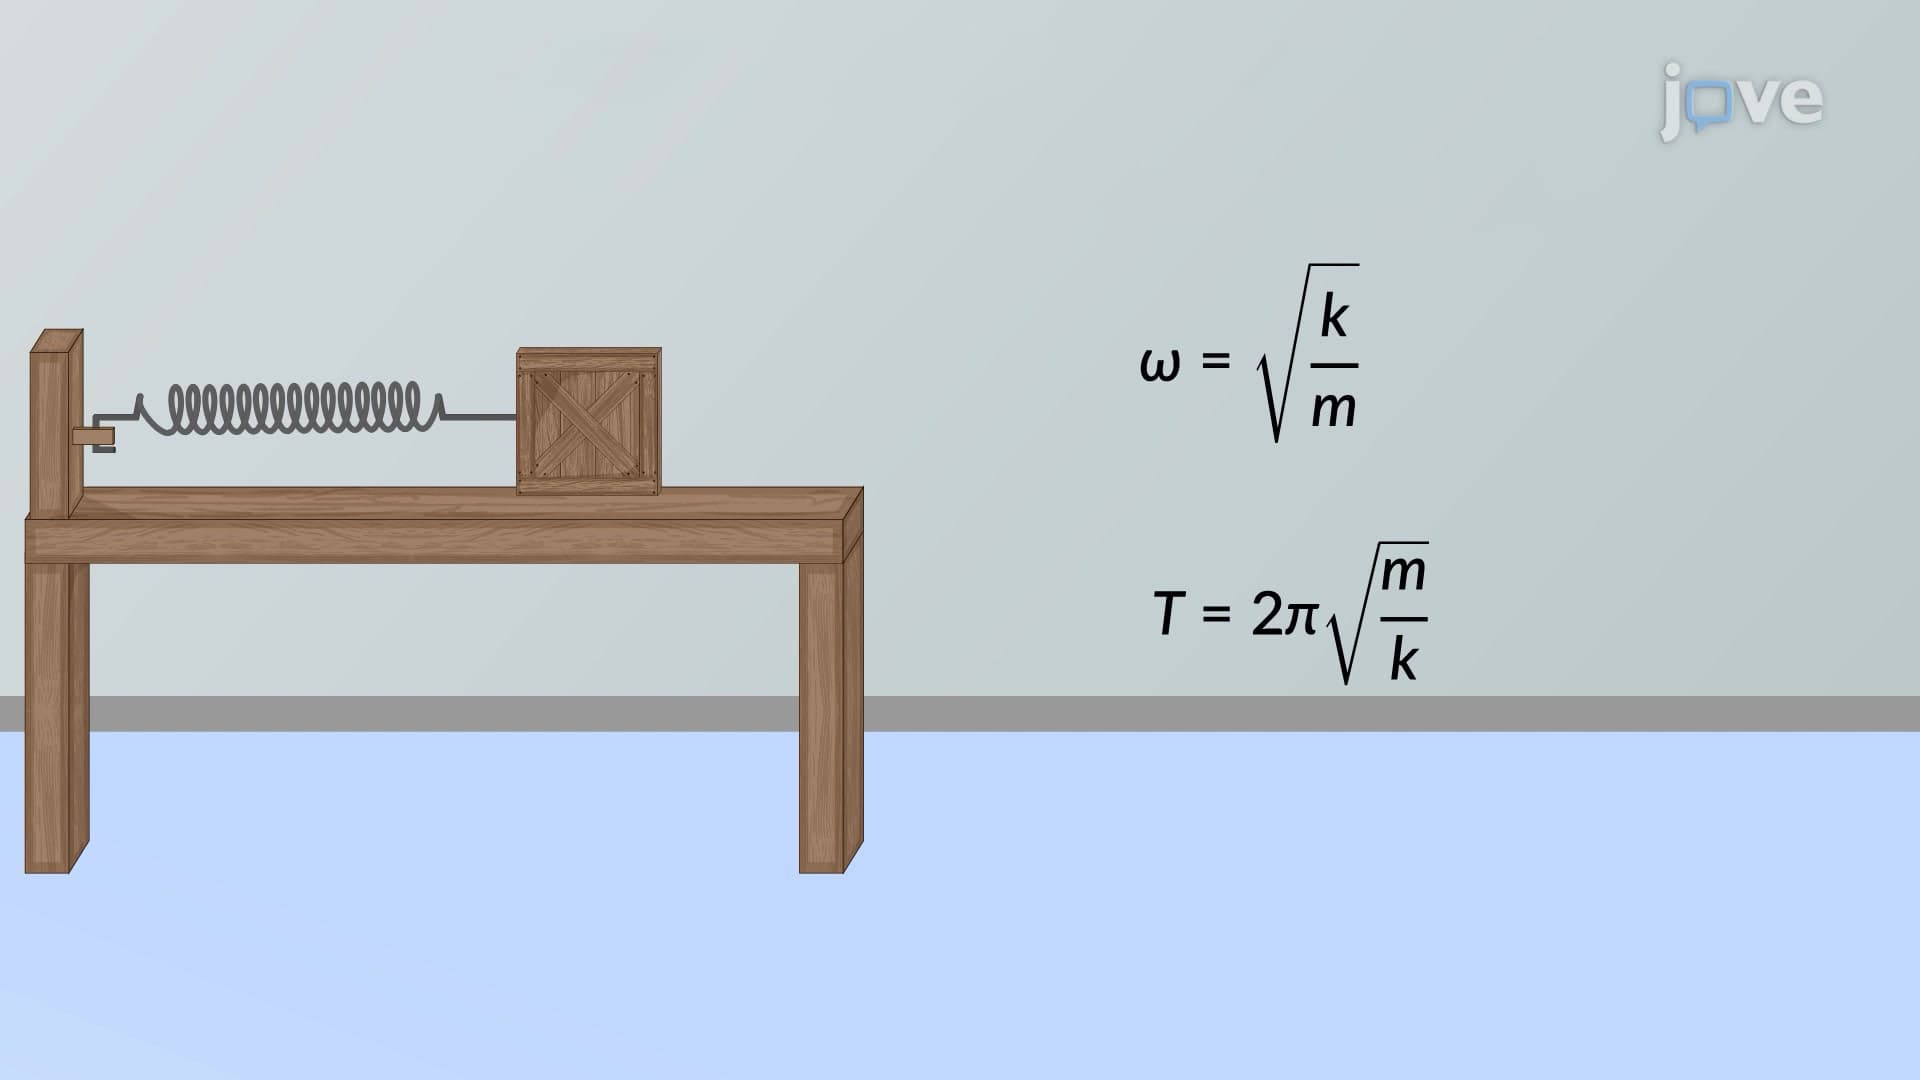
Frequency of Spring-Mass System
Consider a block on a spring on a frictionless surface. There...
 01:19
Root-Locus Method
This system can be represented by a block...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:10
Control Systems
At the heart...