Related Experiment Video
Updated: Apr 25, 2026

Estimation of Contact Regions Between Hands and Objects During Human Multi-Digit Grasping
Published on: April 21, 2023
Visual and haptic integration in the estimation of softness of deformable objects
Cristiano Cellini1, Lukas Kaim1, Knut Drewing1
1Department of General Psychology, Justus-Liebig-University of Giessen, Otto-Behaghel-Strasse 10F, 35394 Giessen, Germany;

Abstract:
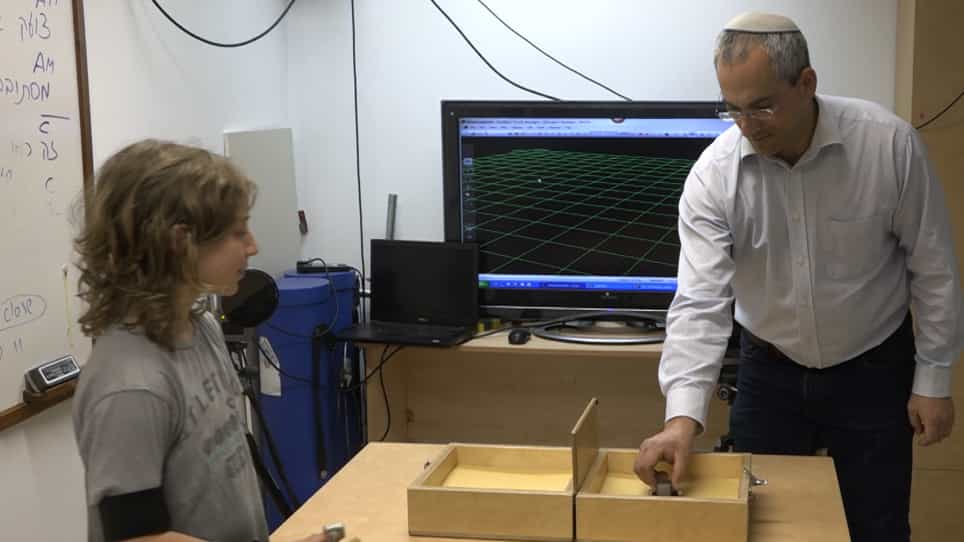
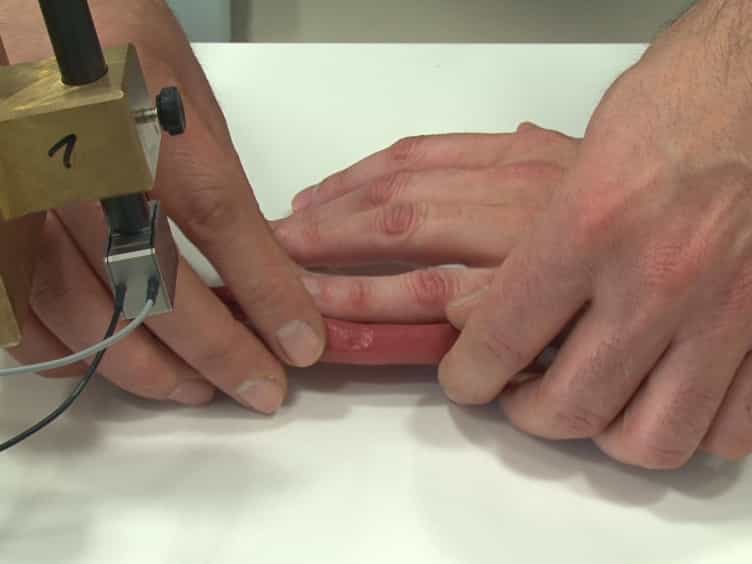
Softness perception intrinsically relies on haptic information. However, through everyday experiences we learn correspondences between felt softness and the visual effects of exploratory movements that are executed to feel softness. Here, we studied how visual and haptic information is integrated to assess the softness of deformable objects. Participants discriminated between the softness of two softer or two harder objects using only-visual, only-haptic or both visual and haptic information. We assessed the reliabilities of the softness judgments using the method of constant stimuli. In visuo-haptic trials, discrepancies between the two senses' information allowed us to measure the contribution of the individual senses to the judgments. Visual information (finger movement and object deformation) was simulated using computer graphics; input in visual trials was taken from previous visuo-haptic trials. Participants were able to infer softness from vision alone, and vision considerably contributed to bisensory judgments (∼35%). The visual contribution was higher than predicted from models of optimal integration (senses are weighted according to their reliabilities). Bisensory judgments were less reliable than predicted from optimal integration. We conclude that the visuo-haptic integration of softness information is biased toward vision, rather than being optimal, and might even be guided by a fixed weighting scheme.
Related Concept Videos
 01:12
Temperature Dependent Deformation
 01:33
Somatosensation
 01:06
Virtual Work for a System of Connected Rigid Bodies
Next,...
 01:11
Deformation of Member under Multiple Loadings
In the case of a member with a variable cross-section, the strain is not constant but depends on the position. The deformation of an...
 01:30
Three-Dimensional Force System:Problem Solving
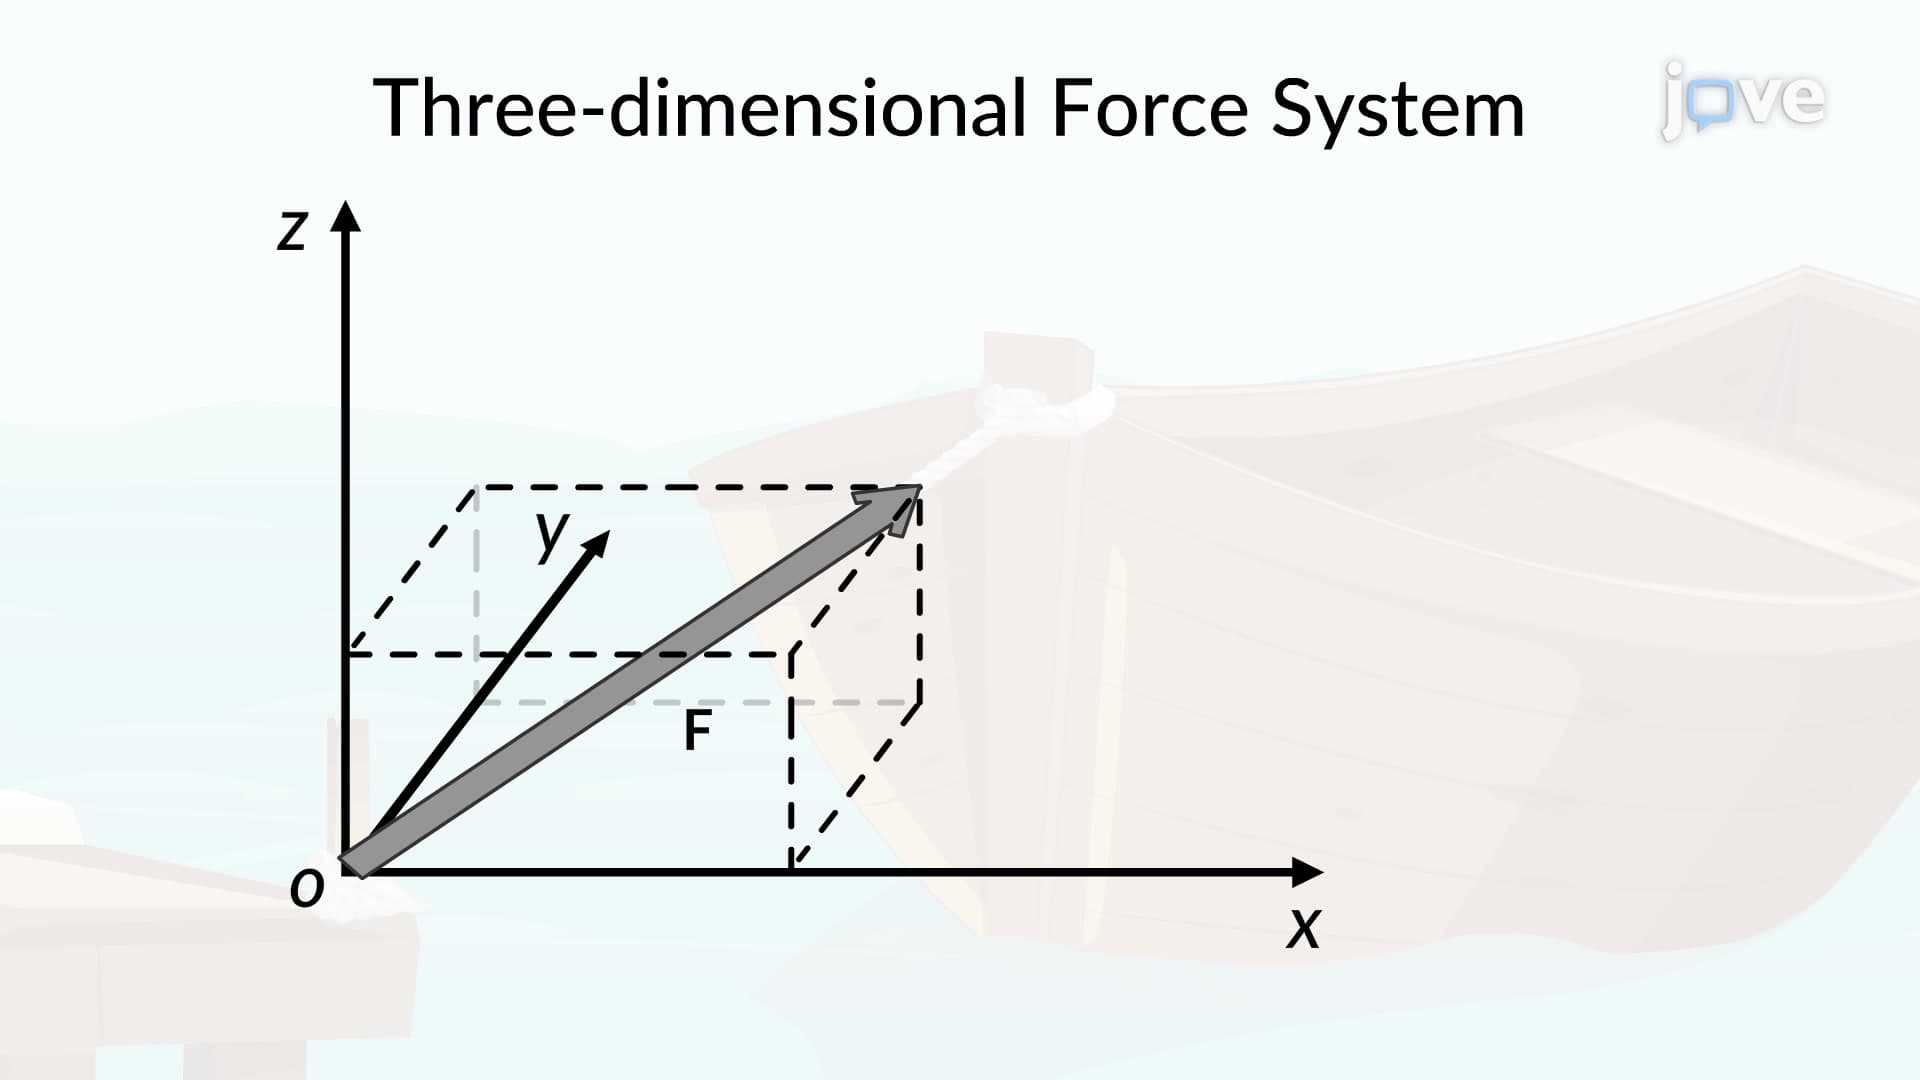
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:30
Three-Dimensional Force System