Related Experiment Video
Updated: Apr 25, 2026

High-resolution, High-speed, Three-dimensional Video Imaging with Digital Fringe Projection Techniques
Published on: December 3, 2013
A variable flip angle-based method for reducing blurring in 3D GRASE ASL
Xiaoyun Liang1, Alan Connelly, Jacques-Donald Tournier
1Florey Institute of Neuroscience and Mental Health, Heidelberg, Victoria, Australia.

Abstract:
Arterial Spin Labeling (ASL) is an MRI technique to measure cerebral blood flow directly and noninvasively, and thus provides a more direct quantitative correlate of neural activity than blood-oxygen-level-dependent fMRI. A 3D gradient and spin-echo (GRASE) sequence is capable of enhancing signal-to-noise ratio, and has been shown to be a very useful readout module for ASL sequences. Nonetheless, the introduction of significant blurring in its single-shot version, due to T2 decay along the partition dimension, compromises the achievable spatial resolution, limiting the potential of this technique for whole-brain coverage. To address this issue, a method for reducing blurring based on a variable flip angle (VFA) scheme is proposed in this study for 3D GRASE ASL perfusion. Numerical simulations show that the proposed method is capable of reducing the blurring significantly compared to the standard constant flip angle approach; this result was further confirmed using in vivo data. The proposed VFA method should therefore be of significance to 3D GRASE ASL fMRI studies, since it is able to reduce blurring without sacrificing temporal resolution.
Related Concept Videos
 01:13
Angle of Twist: Problem Solving
 01:25
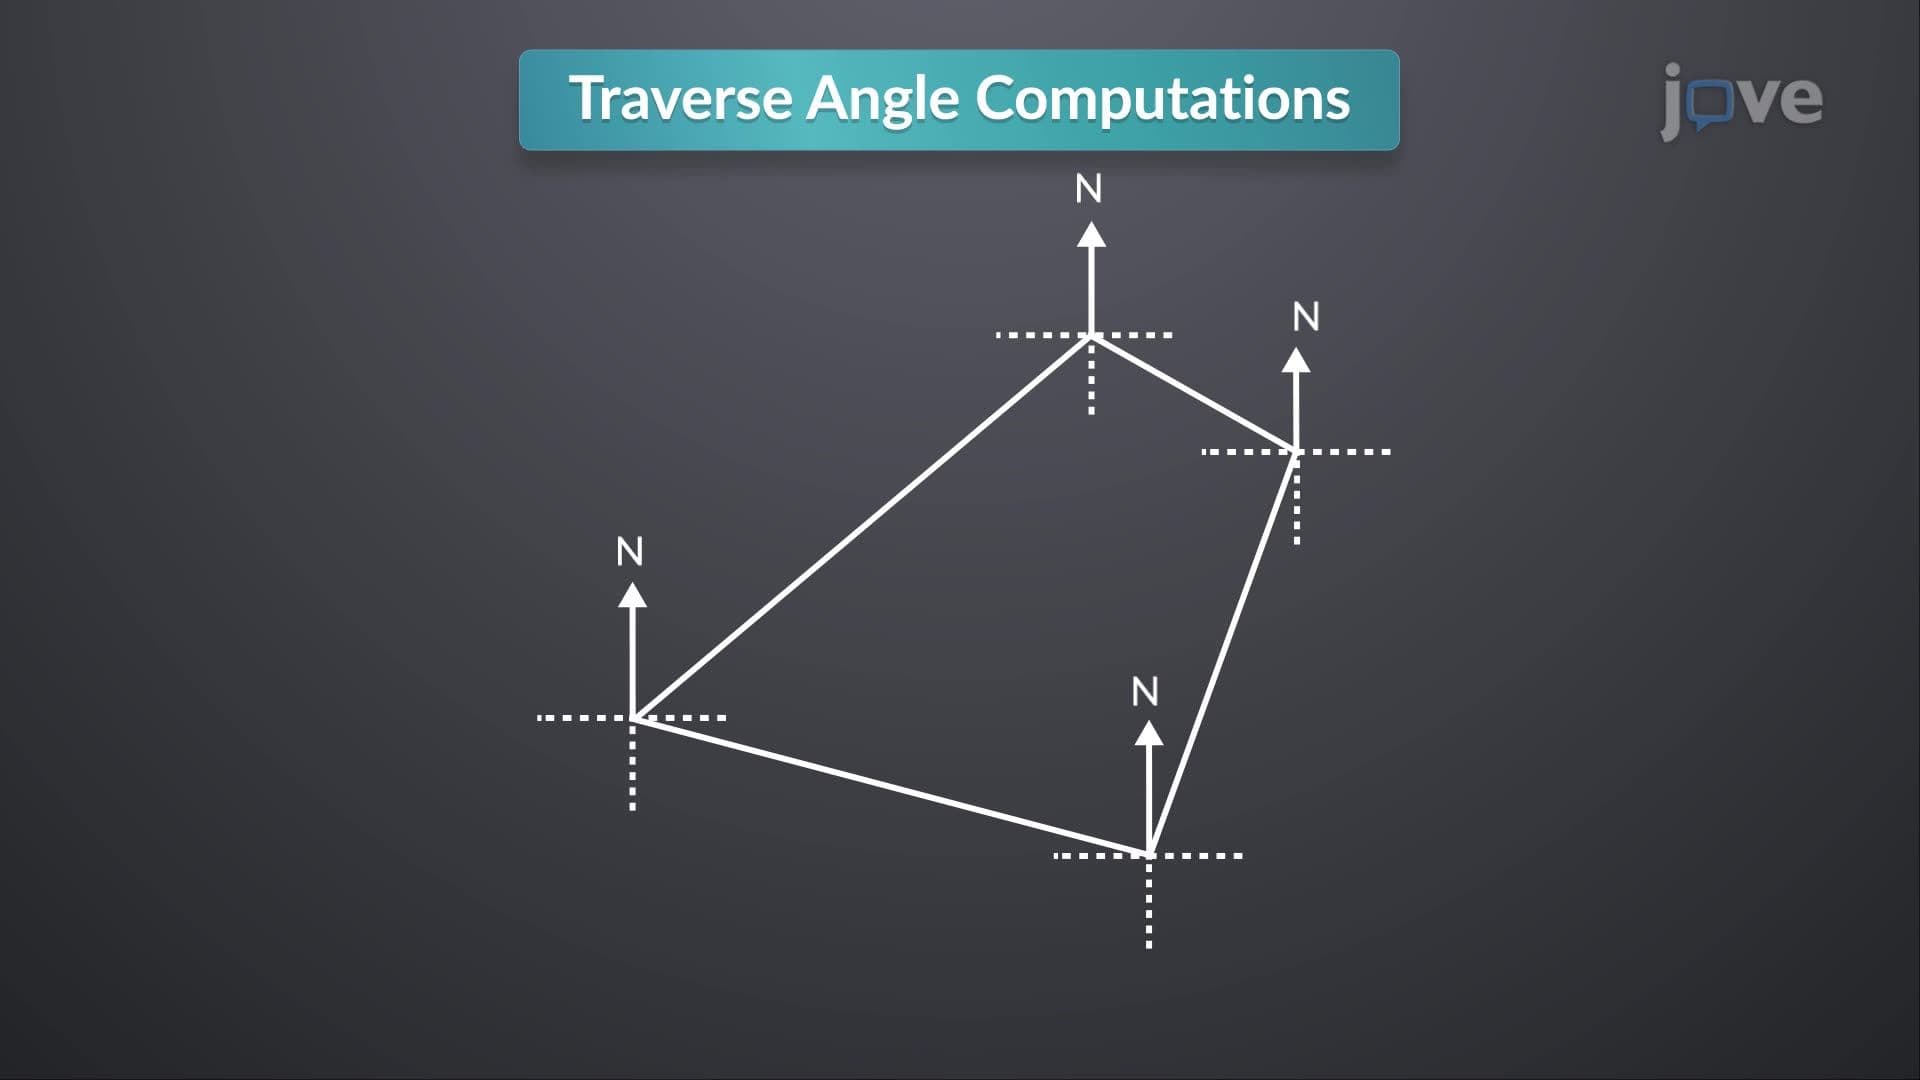
Design Example: Traverse Angle Computations
 01:18
Aliasing
If the sampling frequency is below the Nyquist rate, these replicas overlap, preventing the original...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
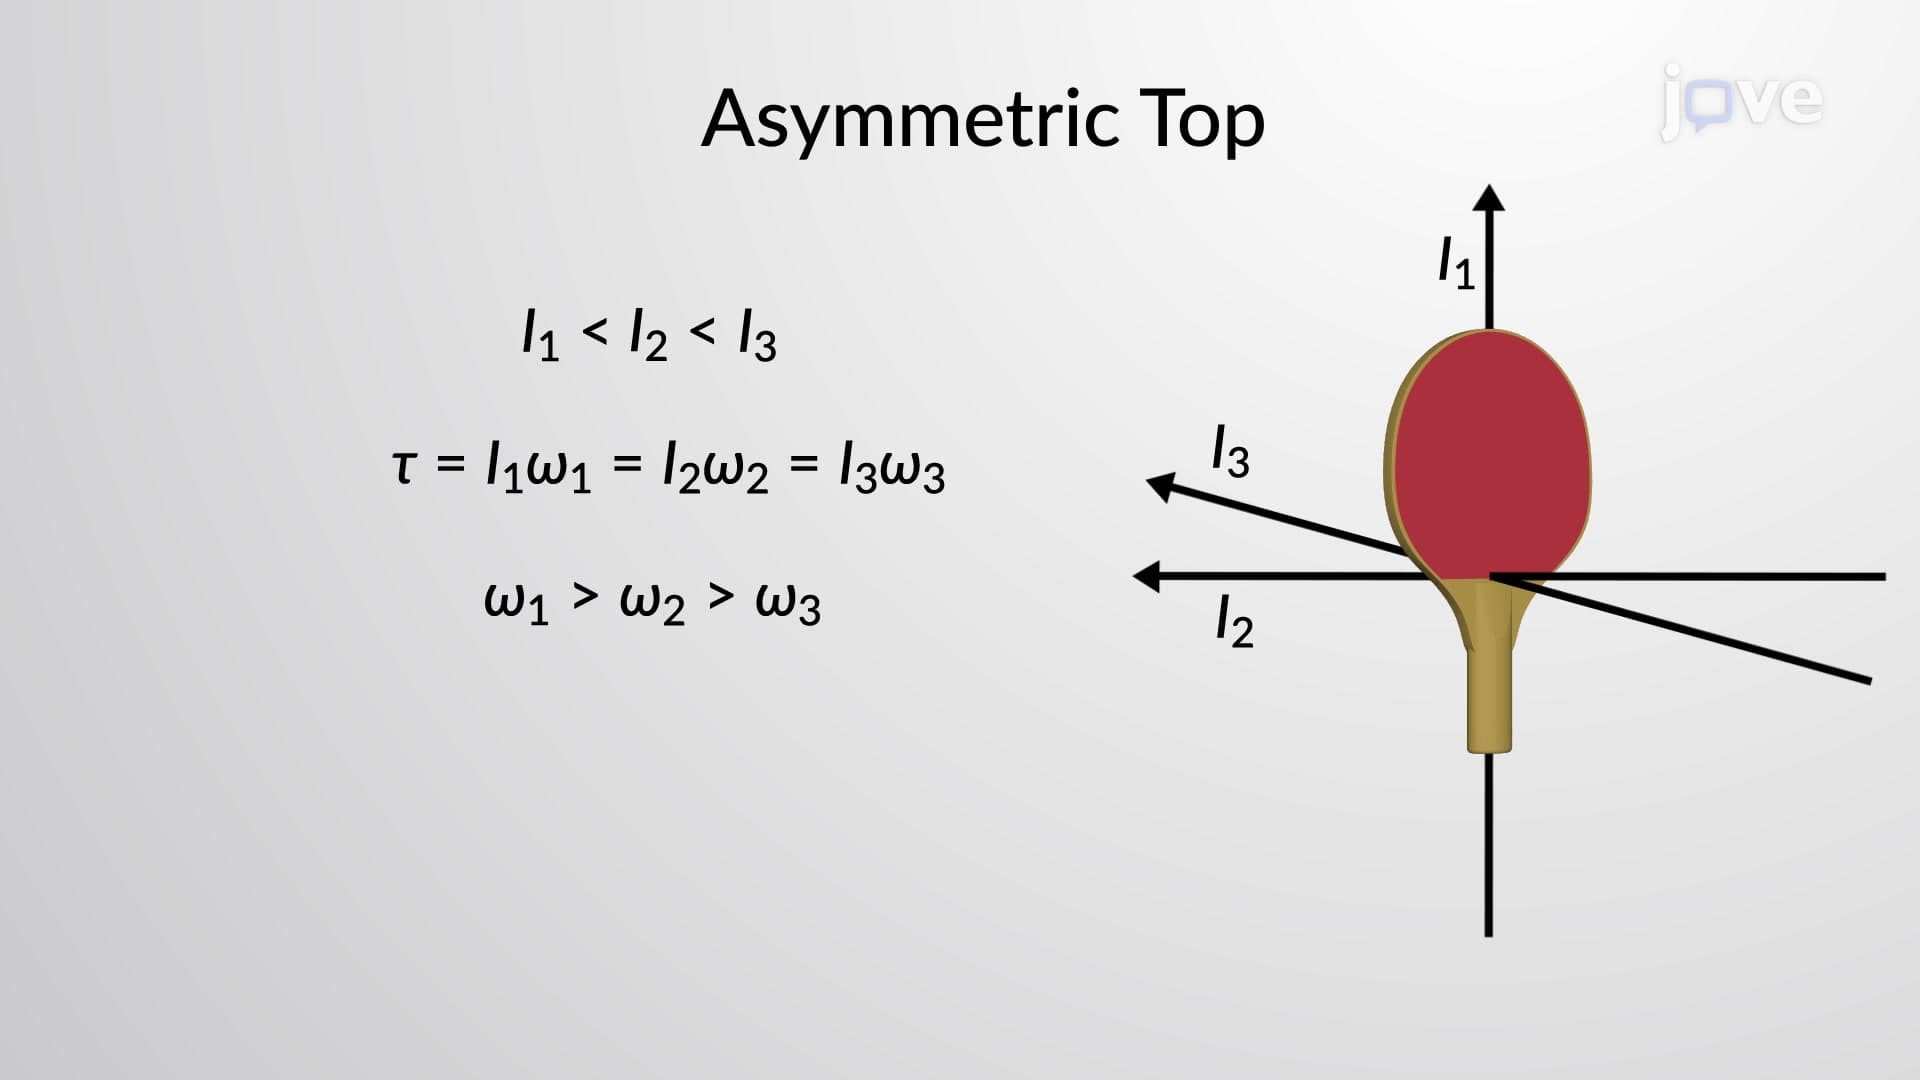 01:11
Rotation of Asymmetric Top
The relationship between the angular momentum of any rigid body and its angular velocity, both of which are vectors, involves the moment of inertia. The moment of inertia is a scalar quantity only for spherically symmetric...