Related Experiment Video
Updated: Apr 24, 2026

Application of Design Aspects in Uniaxial Loading Machine Development
Published on: September 19, 2018
Mechanics and energetics in tool manufacture and use: a synthetic approach
Liyu Wang1, Luzius Brodbeck2, Fumiya Iida2
1Bio-Inspired Robotics Lab, Institute of Robotics and Intelligent Systems, ETH Zurich, Leonhardstrasse 27, Zurich 8092, Switzerland liyu.wang@mavt.ethz.ch.

Abstract:
Tool manufacture and use are observed not only in humans but also in other animals such as mammals, birds and insects. Manufactured tools are used for biomechanical functions such as effective control of fluids and small solid objects and extension of reaching. These tools are passive and used with gravity and the animal users' own energy. From the perspective of evolutionary biology, manufactured tools are extended phenotypes of the genes of the animal and exhibit phenotypic plasticity. This incurs energetic cost of manufacture as compared to the case with a fixed tool. This paper studies mechanics and energetics aspects of tool manufacture and use in non-human beings. Firstly, it investigates possible mechanical mechanisms of the use of passive manufactured tools. Secondly, it formulates the energetic cost of manufacture and analyses when phenotypic plasticity benefits an animal tool maker and user. We take a synthetic approach and use a controlled physical model, i.e. a robot arm. The robot is capable of additively manufacturing scoop and gripper structures from thermoplastic adhesives to pick and place fluid and solid objects, mimicking primates and birds manufacturing tools for a similar function. We evaluate the effectiveness of tool use in pick-and-place and explain the mechanism for gripper tools picking up solid objects with a solid-mechanics model. We propose a way to formulate the energetic cost of tool manufacture that includes modes of addition and reshaping, and use it to analyse the case of scoop tools. Experiment results show that with a single motor trajectory, the robot was able to effectively pick and place water, rice grains, a pebble and a plastic box with a scoop tool or gripper tools that were manufactured by itself. They also show that by changing the dimension of scoop tools, the energetic cost of tool manufacture and use could be reduced. The work should also be interesting for engineers to design adaptive machines.
Related Concept Videos
 01:14
Mechanical Efficiency of Real Machines
However, in reality, no machine can be truly ideal, and all of them experience some...
 01:28
An Introduction to Mechanics
According to records, the history of mechanics starts with Aristotle (384–322 BC). He related mechanics to physical theory, aiming for a universal synthesis.
Newton defined mechanics as the branch of physical science that...
 01:09
Transmission Shafts: Problem Solving
Next, use bending moment diagrams for the shaft to...
 01:19
Machines
A free-body diagram of the...
 01:17
Frictional Forces on Screws
A jack with a square-threaded screw is a mechanical device used to lift heavy loads by applying a force at its handle. When the force is applied, the screw turns, raising the load. The screw can...
 01:10
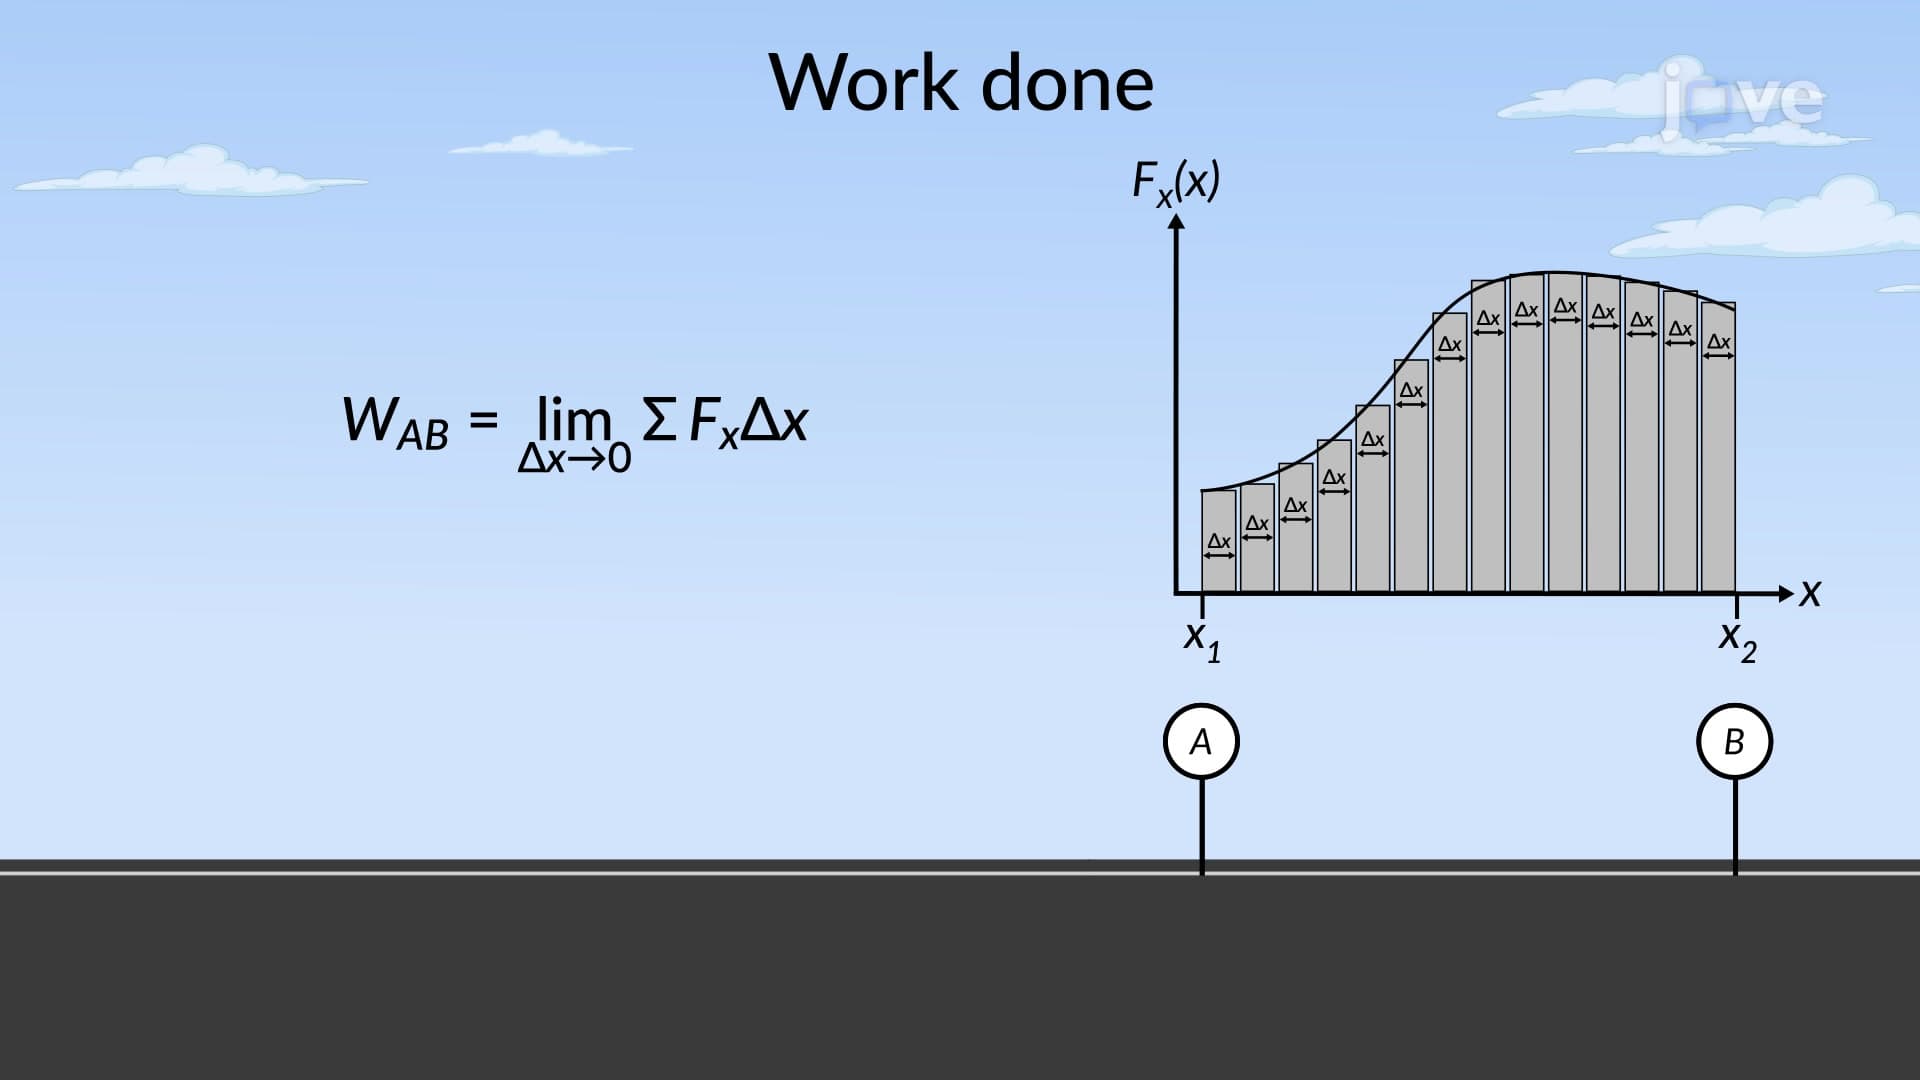
Work and Energy for Variable Forces