Subspace learning of dynamics on a shape manifold: a generative modeling approach
Related Experiment Video
Updated: Apr 23, 2026
Three-Dimensional Shape Modeling and Analysis of Brain Structures
Published on: November 14, 2019

Abstract:
In this paper, we propose a novel subspace learning algorithm of shape dynamics. Compared to the previous works, our method is invertible and better characterizes the nonlinear geometry of a shape manifold while retaining a good computational efficiency. In this paper, using a parallel moving frame on a shape manifold, each path of shape dynamics is uniquely represented in a subspace spanned by the moving frame, given an initial condition (the starting point and starting frame). Mathematically, such a representation may be formulated as solving a manifold-valued differential equation, which provides a generative modeling of high-dimensional shape dynamics in a lower dimensional subspace. Given the parallelism and a path on a shape manifold, the parallel moving frame along the path is uniquely determined up to the choice of the starting frame. With an initial frame, we minimize the reconstruction error from the subspace to shape manifold. Such an optimization characterizes well the Riemannian geometry of the manifold by imposing parallelism (equivalent as a Riemannian metric) constraints on the moving frame. The parallelism in this paper is defined by a Levi-Civita connection, which is consistent with the Riemannian metric of the shape manifold. In the experiments, the performance of the subspace learning is extensively evaluated using two scenarios: 1) how the high dimensional geometry is characterized in the subspace and 2) how the reconstruction compares with the original shape dynamics. The results demonstrate and validate the theoretical advantages of the proposed approach.
Related Concept Videos
 01:27
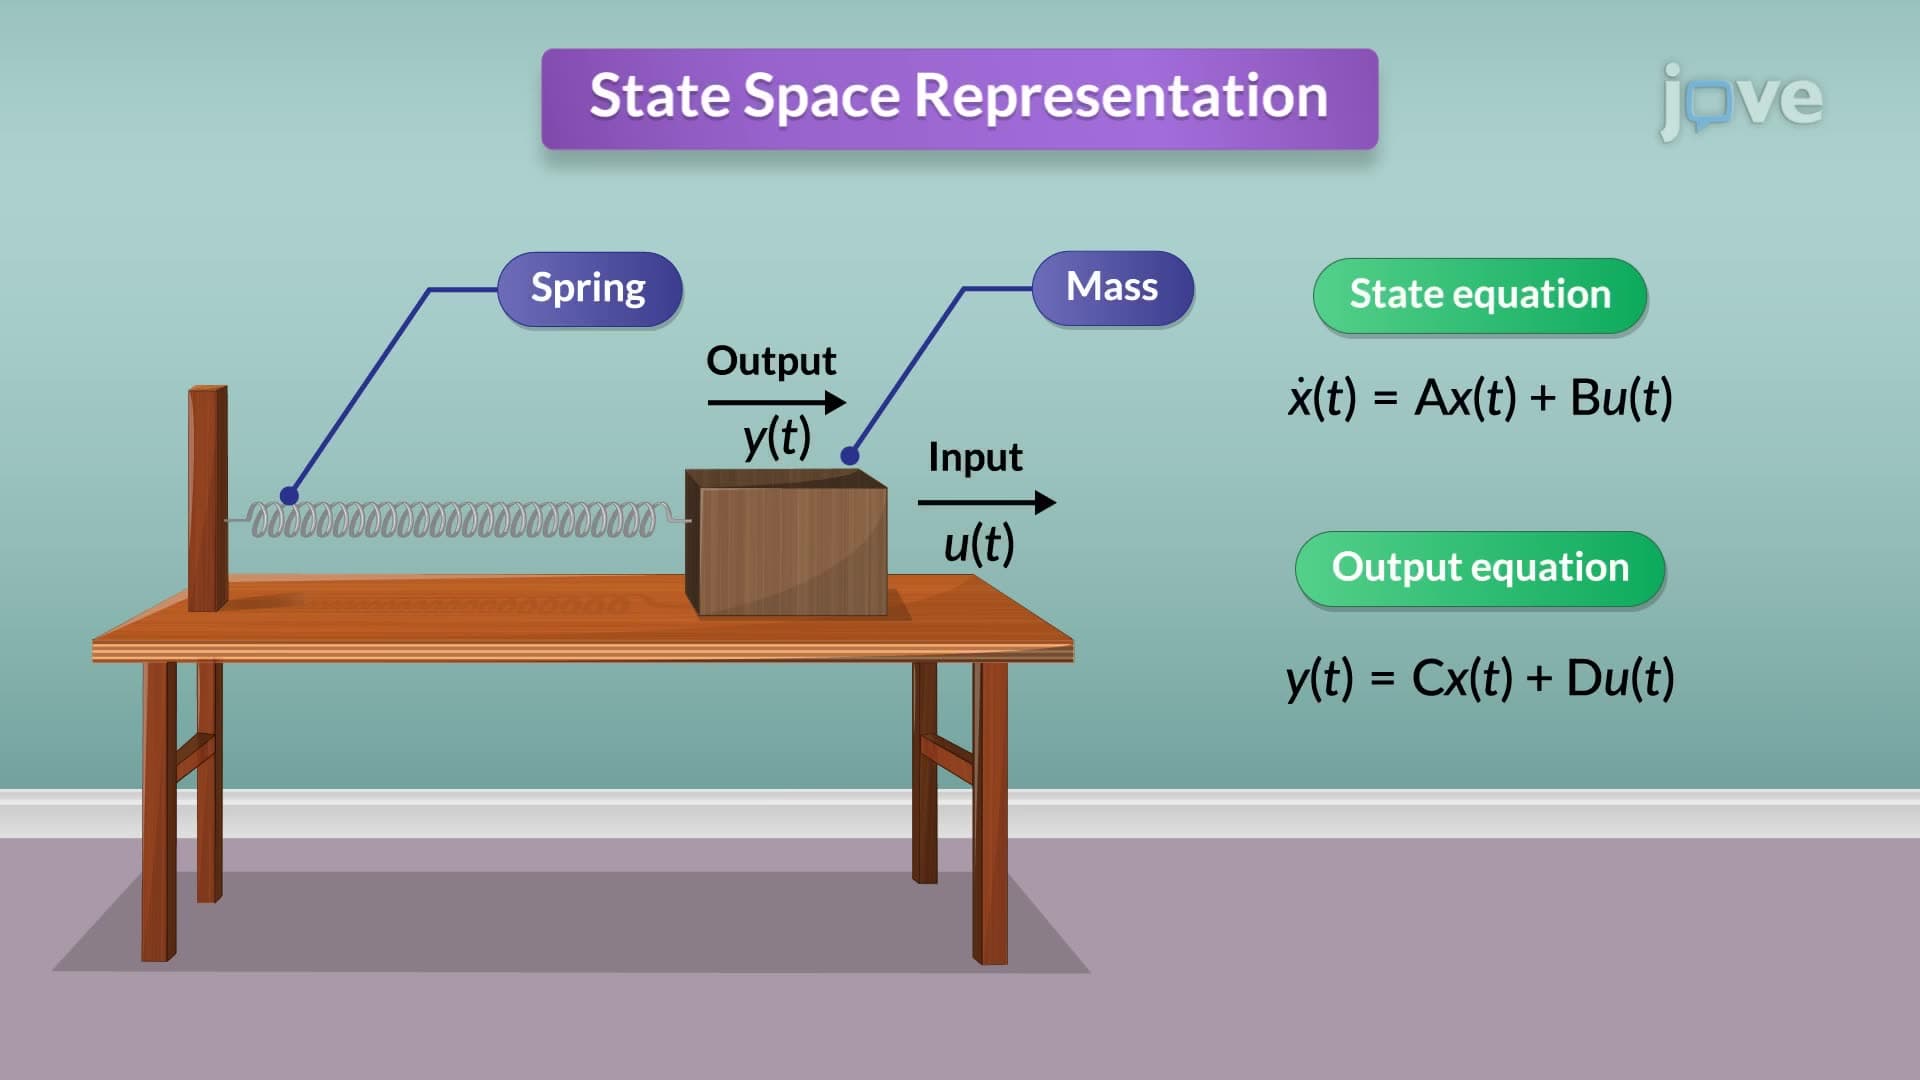
State Space Representation
Consider an RLC circuit, a...
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:25
Modeling with Differential Equations
 01:21
State Space to Transfer Function
The transformation process begins with the state-space representation, characterized by the state equation and the output equation. These equations are typically represented as:
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...