Stability of multifinger action in different state spaces
Related Experiment Video
Updated: Apr 23, 2026
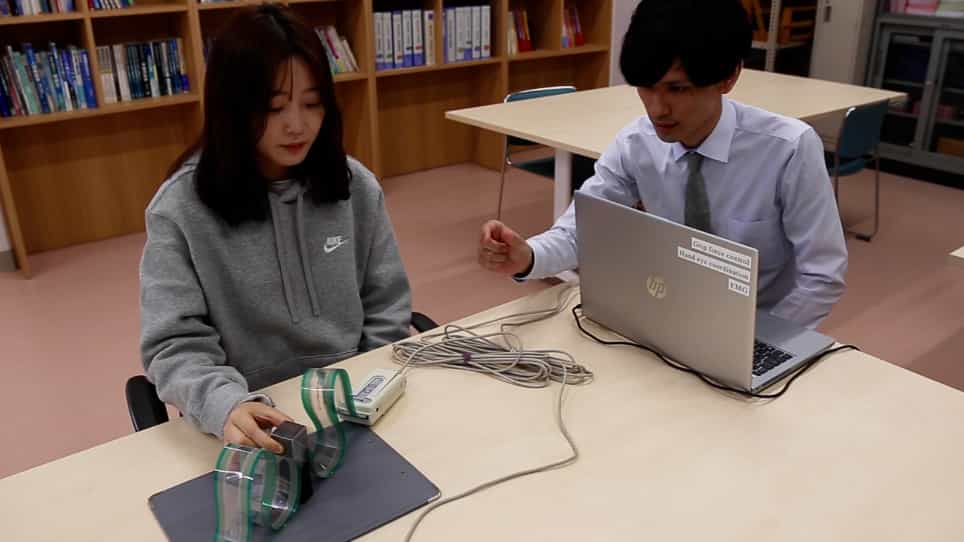
Measurement of Spatial Stability in Precision Grip
Published on: June 4, 2020
Sasha Reschechtko1, Vladimir M Zatsiorsky1, Mark L Latash2
1Department of Kinesiology, The Pennsylvania State University, University Park, Pennsylvania.

Abstract:
We investigated stability of action by a multifinger system with three methods: analysis of intertrial variance, application of transient perturbations, and analysis of the system's motion in different state spaces. The "inverse piano" device was used to apply transient (lifting-and-lowering) perturbations to individual fingers during single- and two-finger accurate force production tasks. In each trial, the perturbation was applied either to a finger explicitly involved in the task or one that was not. We hypothesized that, in one-finger tasks, task-specific stability would be observed in the redundant space of finger forces but not in the nonredundant space of finger modes (commands to explicitly involved fingers). In two-finger tasks, we expected that perturbations applied to a nontask finger would not contribute to task-specific stability in mode space. In contrast to our expectations, analyses in both force and mode spaces showed lower stability in directions that did not change total force output compared with directions that did cause changes in total force. In addition, the transient perturbations led to a significant increase in the enslaving index. We consider these results within a theoretical scheme of control with referent body configurations organized hierarchically, using multiple few-to-many mappings organized in a synergic way. The observed volatility of enslaving, greater equifinality of total force compared with elemental variables, and large magnitude of motor equivalent motion in both force and mode spaces provide support for the concept of task-specific stability of performance and the existence of multiple neural loops, which ensure this stability.

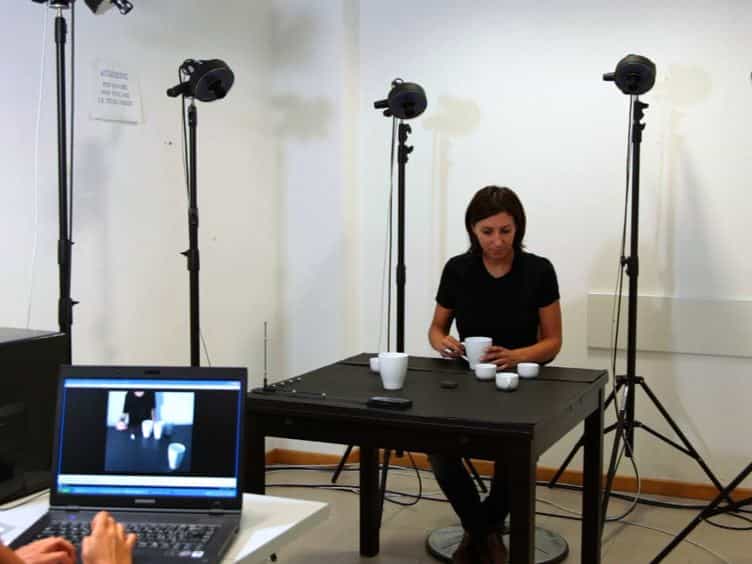
Related Concept Videos
 01:23
Stability of Equilibrium Configuration
A stable equilibrium occurs when a system tends to return to its original position when given a small displacement, and the potential energy is at its minimum. An example of a stable equilibrium is when a cantilever beam is fixed at one end and a weight is attached to the other end. If the weight...
 01:13
Stability of Equilibrium Configuration: Problem Solving
Problem-solving in the context of the stability of equilibrium configuration...
 01:24
Pole and System Stability
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's...
 01:28
Stability
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...
 01:27
State Space Representation
Consider an RLC circuit, a...
 01:25
Multimachine Stability
In analyzing the system, the nodal equations represent the relationship between bus voltages, machine voltages, and machine currents. The nodal equation is given by: