Related Experiment Video
Updated: Apr 23, 2026


Manufacturing, Control, and Performance Evaluation of a Gecko-Inspired Soft Robot
Published on: June 10, 2020
Coordinated control of slip ratio for wheeled mobile robots climbing loose sloped terrain
1School of Mechanical Instrumental Engineering, Harbin Institute of Technology, Harbin 150001, China.

Abstract:
A challenging problem faced by wheeled mobile robots (WMRs) such as planetary rovers traversing loose sloped terrain is the inevitable longitudinal slip suffered by the wheels, which often leads to their deviation from the predetermined trajectory, reduced drive efficiency, and possible failures. This study investigates this problem using terramechanics analysis of the wheel-soil interaction. First, a slope-based wheel-soil interaction terramechanics model is built, and an online slip coordinated algorithm is designed based on the goal of optimal drive efficiency. An equation of state is established using the coordinated slip as the desired input and the actual slip as a state variable. To improve the robustness and adaptability of the control system, an adaptive neural network is designed. Analytical results and those of a simulation using Vortex demonstrate the significantly improved mobile performance of the WMR using the proposed control system.


Related Concept Videos
 01:17
Rolling Resistance: Problem Solving
 01:14
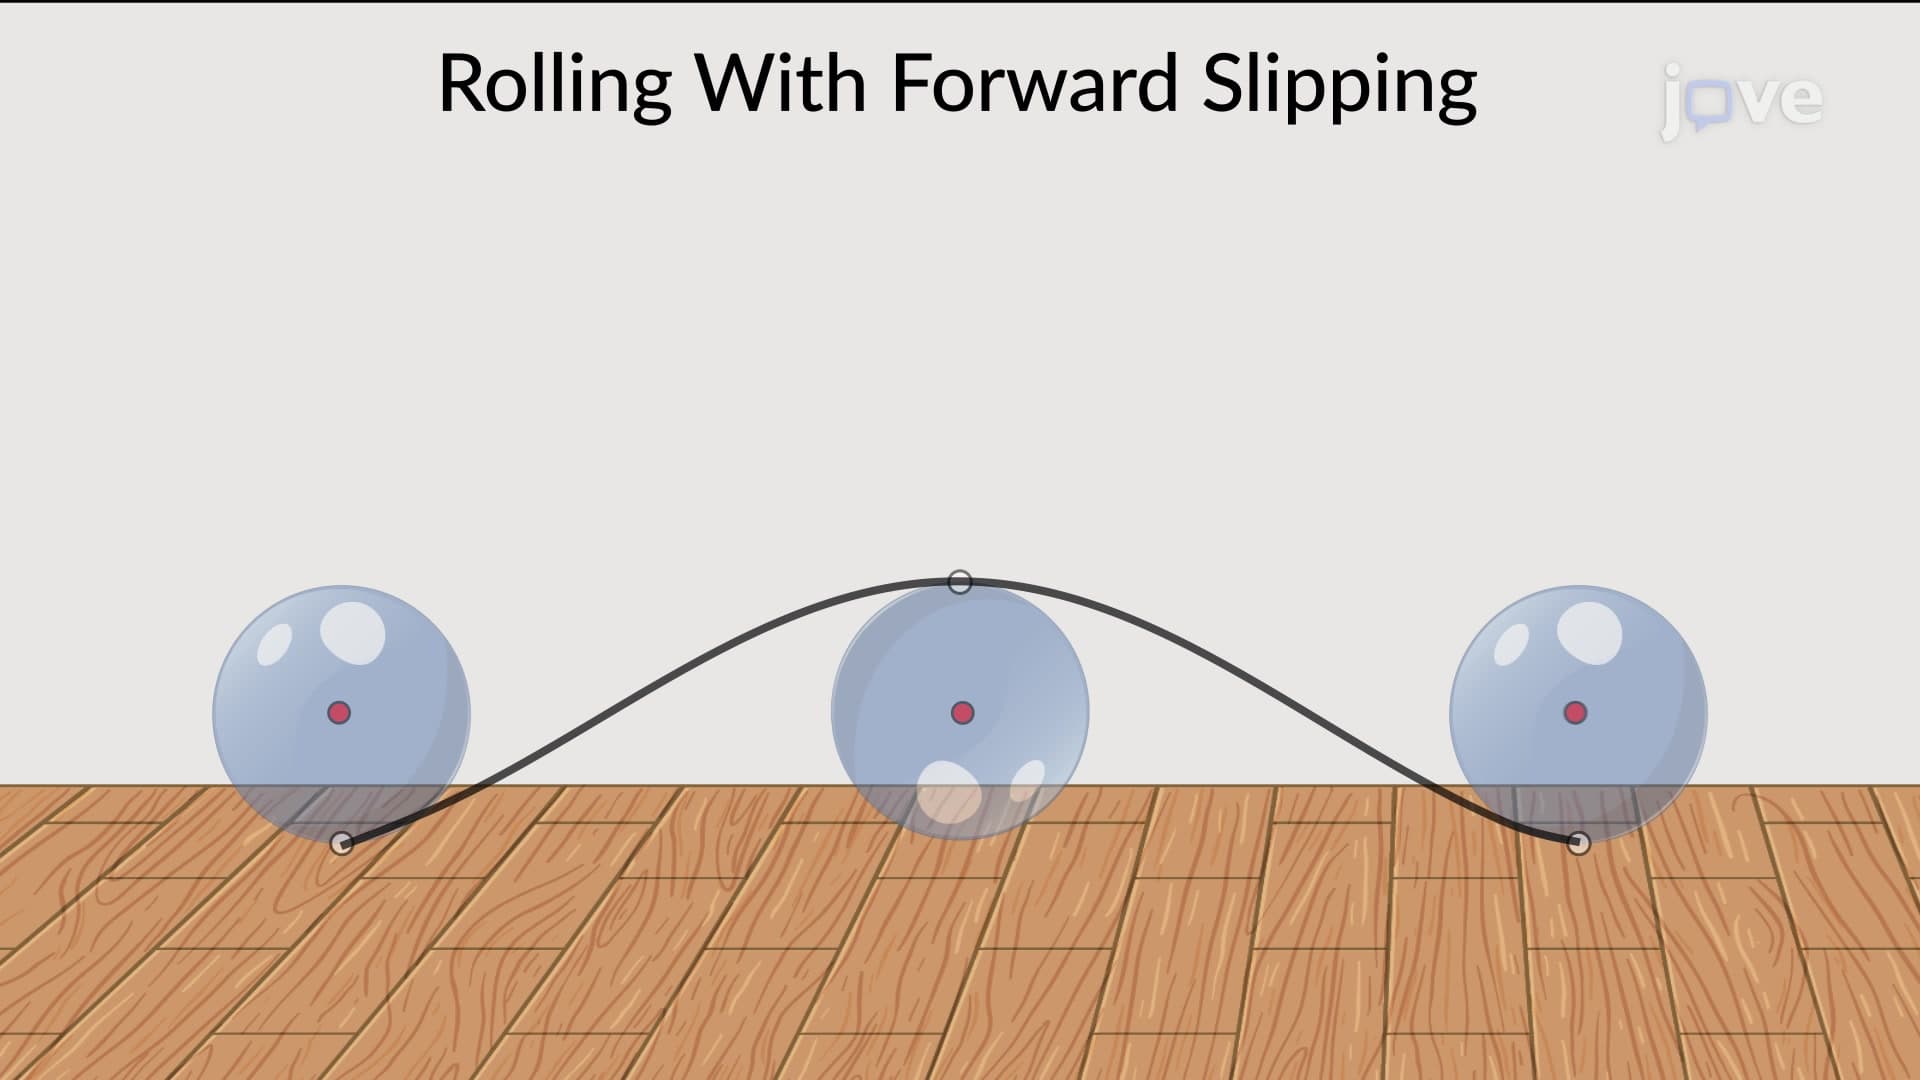
Rolling With Slipping
An object's rolling motion is characterized by its rotation around its axis, while linear motion refers to the object's translational motion along a surface. Frictional forces can...
 01:16
Equation of Motion: General Plane motion - Problem Solving
The friction between the roller and the ground is characterized by two coefficients. The static friction coefficient is 0.15, while the kinetic friction coefficient is 0.1. These values are crucial in understanding the interaction between...
 01:21
Friction: Problem Solving
Initially, a visual representation of the...
 01:21
Rolling Resistance
For instance, imagine a hard cylinder rolling on a comparatively soft surface. The cylinder's weight compresses the surface beneath it. As the cylinder moves, the material in front of it slows down due to...
 01:09
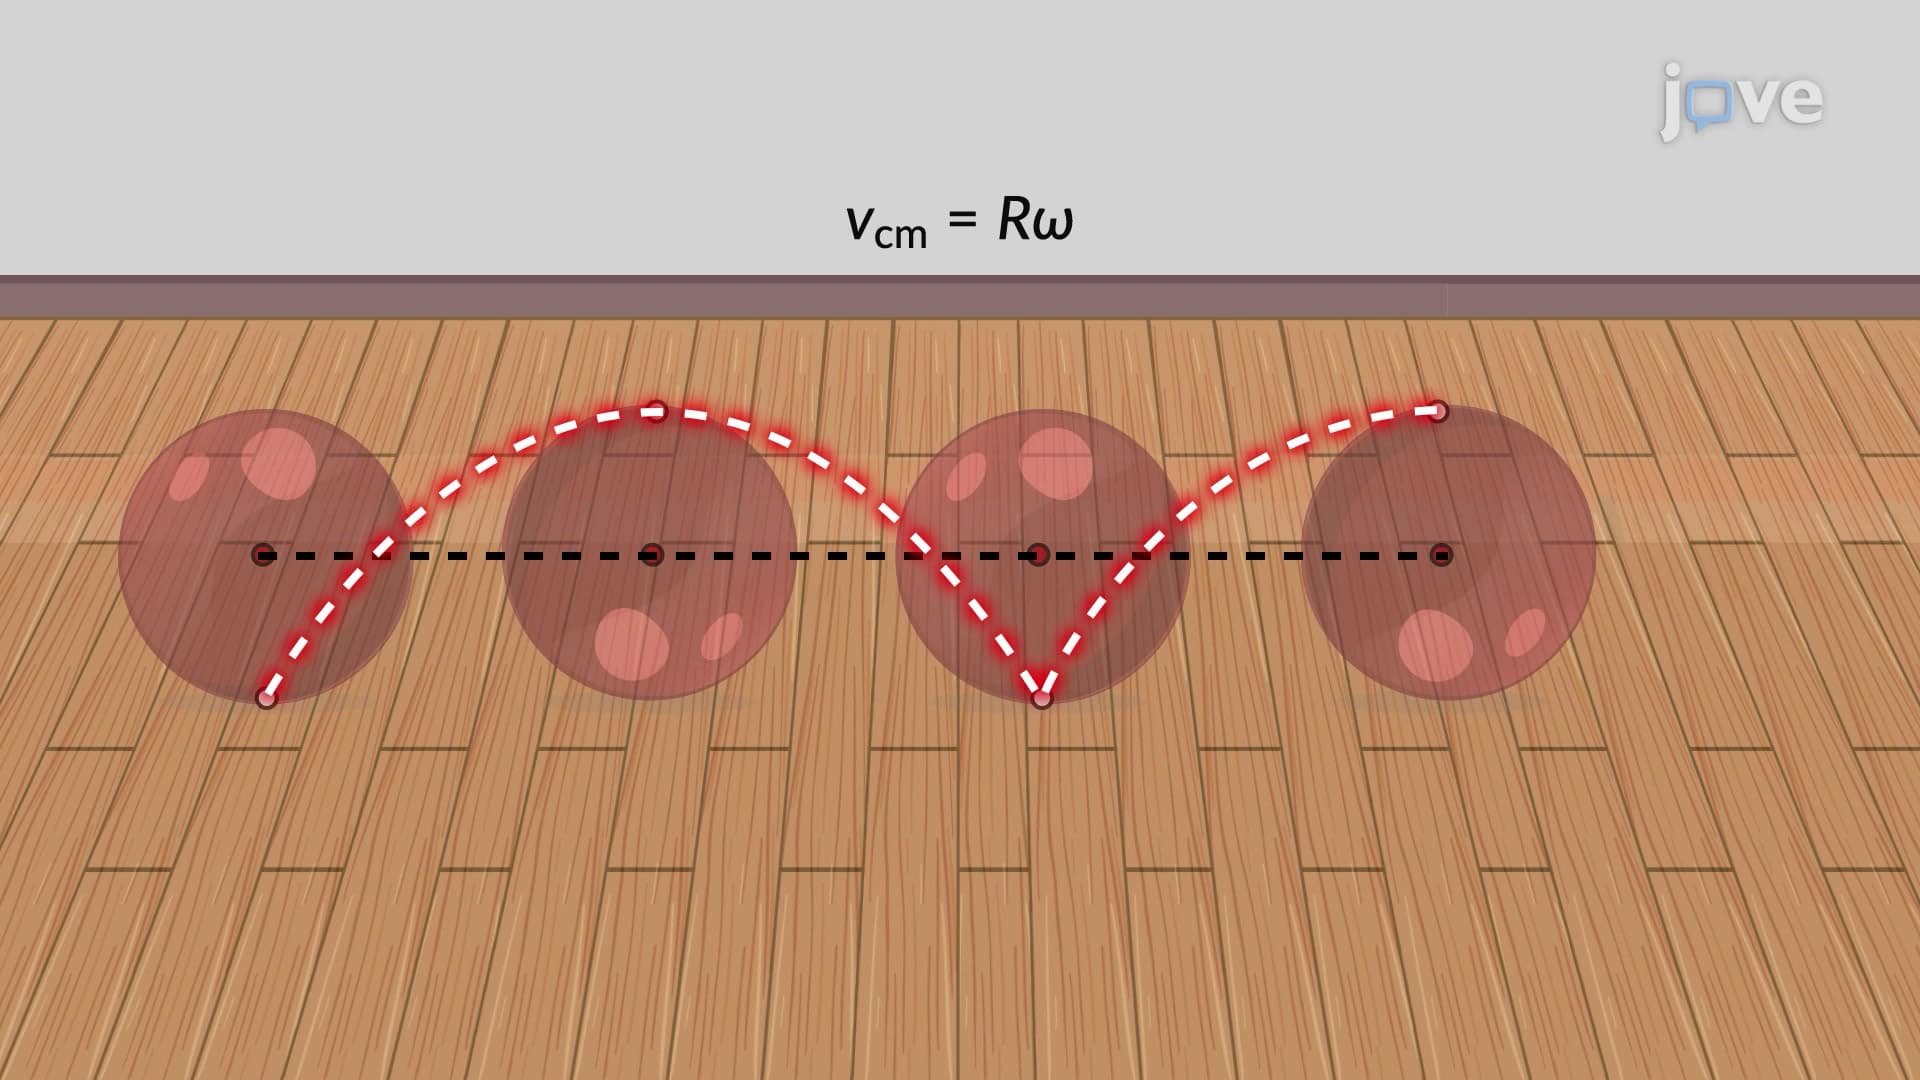
Rolling Without Slipping