Related Experiment Video
Updated: Apr 22, 2026
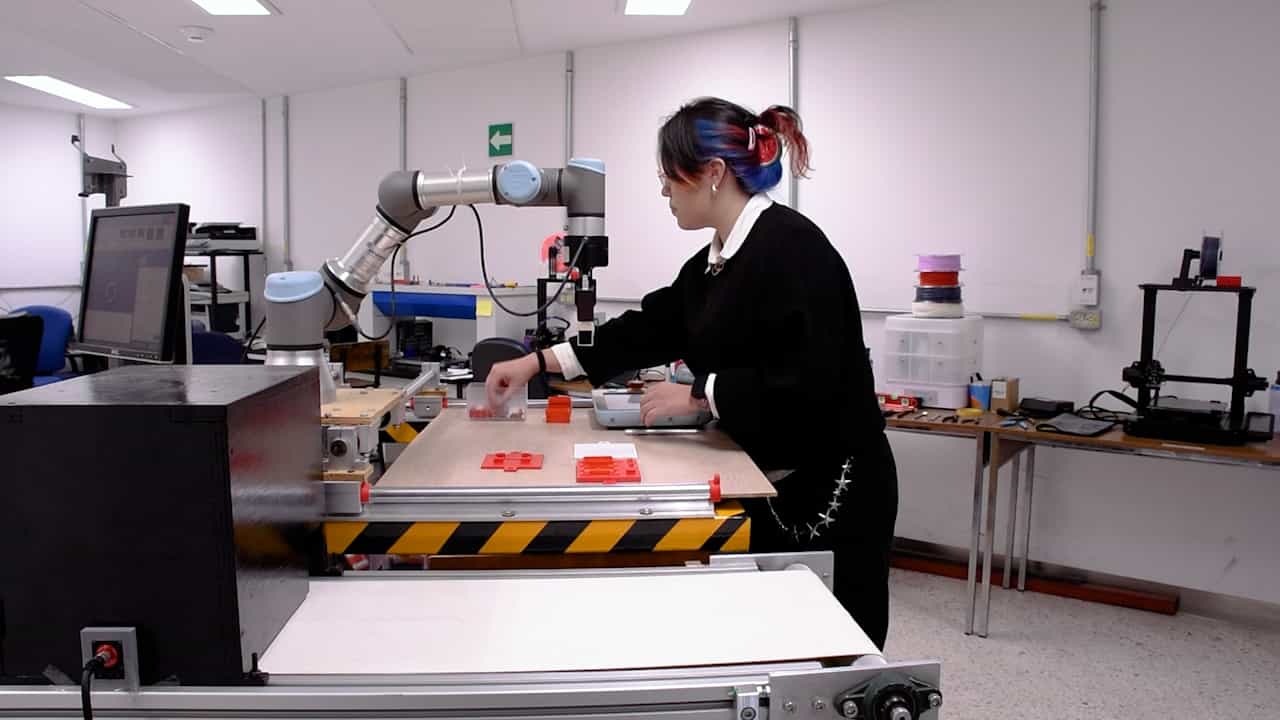

Simulation of a Scaled Assembly Process with Collaboration of a Robotic Arm and Monitoring through a Vision System for Quality Control
Published on: August 29, 2025
Development of a Guaranteed Stable Network of Telerobots with Kinesthetic Consensus

Abstract:
We present the research advances on the development of 50-200 mJ energy range diode-pumped Yb:CaF2- based multipass amplifiers operating at relatively high repetition rates. These laser amplifiers are based on diverse innovative geometries. All these innovations aim to design compact, stable and reliable amplifiers adapted to our application that consists in pumping ultrashort-pulse OPCPA (optical parametric chirped pulse amplifier) systems in the frame of the Apollon 10 PW laser project. The targeted repetition rate is in the range of 20-100 Hz with energies of few tens of mJ for the first stages up to 1 J for the final stage. An analysis of the specificities of Yb:CaF2 is done to explain the different options we chose to fulfil these specifications. The critical points and limitations of the multipass Yb:CaF2-based amplifiers are subsequently discussed. To overcome the encountered problems, different issues are investigated such as crystal optimisation, laser head geometry, thermo-optical dynamics or coherent combining techniques. Experimental results for different multipass configurations are demonstrated and discussed.

