Related Experiment Video
Updated: Apr 22, 2026


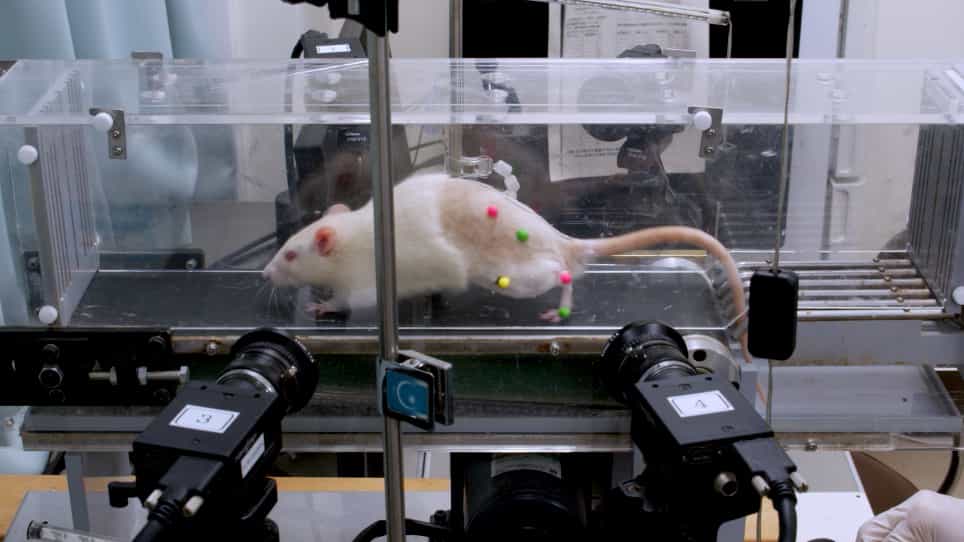
Deep-Learning Based Multi-Joint Synchronous Tracking for Objective Quantification of Hindlimb Locomotor Kinematics in Rats
Published on: April 3, 2026
Physiologically corrected coupled motion during gait analysis using a model-based approach
Bruno Bonnechère1, Victor Sholukha2, Patrick Salvia1
1Laboratory of Anatomy, Biomechanics and Organogenesis (LABO), Université Libre de Bruxelles, Belgium.

Abstract:
Gait analysis is used in daily clinics for patients' evaluation and follow-up. Stereophotogrammetric devices are the most used tool to perform these analyses. Although these devices are accurate results must be analyzed carefully due to relatively poor reproducibility. One of the major issues is related to skin displacement artifacts. Motion representation is recognized reliable for the main plane of motion displacement, but secondary motions, or combined, are less reliable because of the above artifacts. Model-based approach (MBA) combining accurate joint kinematics and motion data was previously developed based on a double-step registration method. This study presents an extensive validation of this MBA method by comparing results with a conventional motion representation model. Thirty five healthy subjects participated to this study. Gait motion data were obtained from a stereophotogrammetric system. Plug-in Gait model (PiG) and MBA were applied to raw data, results were then compared. Range-of-motion, were computed for pelvis, hip, knee and ankle joints. Differences between PiG and MBA were then computed. Paired-sample t-tests were used to compare both methods. Normalized root-mean square errors were also computed. Shapes of the curves were compared using coefficient of multiple correlations. The MBA and PiG approaches shows similar results for the main plane of motion displacement but statistically significative discrepancies appear for the combined motions. MBA appear to be usable in applications (such as musculoskeletal modeling) requesting better approximations of the joints-of-interest thanks to the integration of validated joint mechanisms.
Related Concept Videos
 01:10
Relative Motion Analysis - Acceleration
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
 01:24
Relative Motion Analysis - Velocity
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:15
Kinematic Equations: Problem Solving