Related Experiment Video
Updated: Apr 22, 2026

Studying the Neural Basis of Adaptive Locomotor Behavior in Insects
Published on: April 13, 2011
Scaling of the spring in the leg during bouncing gaits of mammals
David V Lee1, Michael R Isaacs2, Trevor E Higgins2
1*School of Life Sciences, University of Nevada Las Vegas, Las Vegas, NV 89154, USA; Concord Field Station, Harvard University, Bedford, MA 01730, USA; Department of Biological Sciences, University of Idaho, Moscow, ID 83844, USA david.lee@unlv.edu.

Abstract:
Trotting, bipedal running, and especially hopping have long been considered the principal bouncing gaits of legged animals. We use the radial-leg spring constant [Formula: see text] to quantify the stiffness of the physical leg during bouncing gaits. The radial-leg is modeled as an extensible strut between the hip and the ground and [Formula: see text] is determined from the force and deflection of this strut in each instance of stance. A Hookean spring is modeled in-series with a linear actuator and the stiffness of this spring [Formula: see text] is determined by minimizing the work of the actuator while reproducing the measured force-deflection dynamics of an individual leg during trotting or running, and of the paired legs during hopping. Prior studies have estimated leg stiffness using [Formula: see text], a metric that imagines a virtual-leg connected to the center of mass. While [Formula: see text] has been applied extensively in human and comparative biomechanics, we show that [Formula: see text] more accurately models the spring in the leg when actuation is allowed, as is the case in biological and robotic systems. Our allometric analysis of [Formula: see text] in the kangaroo rat, tammar wallaby, dog, goat, and human during hopping, trotting, or running show that [Formula: see text] scales as body mass to the two-third power, which is consistent with the predictions of dynamic similarity and with the scaling of [Formula: see text]. Hence, two-third scaling of locomotor spring constants among mammals is supported by both the radial-leg and virtual-leg models, yet the scaling of [Formula: see text] emerges from work-minimization in the radial-leg model instead of being a defacto result of the ratio of force to length used to compute [Formula: see text]. Another key distinction between the virtual-leg and radial-leg is that [Formula: see text] is substantially greater than [Formula: see text], as indicated by a 30-37% greater scaling coefficient for [Formula: see text]. We also show that the legs of goats are on average twice as stiff as those of dogs of the same mass and that goats increase the stiffness of their legs, in part, by more nearly aligning their distal limb-joints with the ground reaction force vector. This study is the first allometric analysis of leg spring constants in two decades. By means of an independent model, our findings reinforce the two-third scaling of spring constants with body mass, while showing that springs in-series with actuators are stiffer than those predicted by energy-conservative models of the leg.
More Related Videos
 10:28
Kinematics and Ground Reaction Force Determination: A Demonstration Quantifying Locomotor Abilities of Young Adult, Middle-aged, and Geriatric Rats
Published on: February 22, 2011
 07:28
Author Spotlight: Using the MouseWalker to Quantify Locomotor Dysfunction in a Mouse Model of Spinal Cord Injury
Published on: March 24, 2023
Related Concept Videos
 01:23
Euler's Formula to Columns: Problem Solving
The system comprises two vertical rigid bars, AB and BC, of...
 01:17
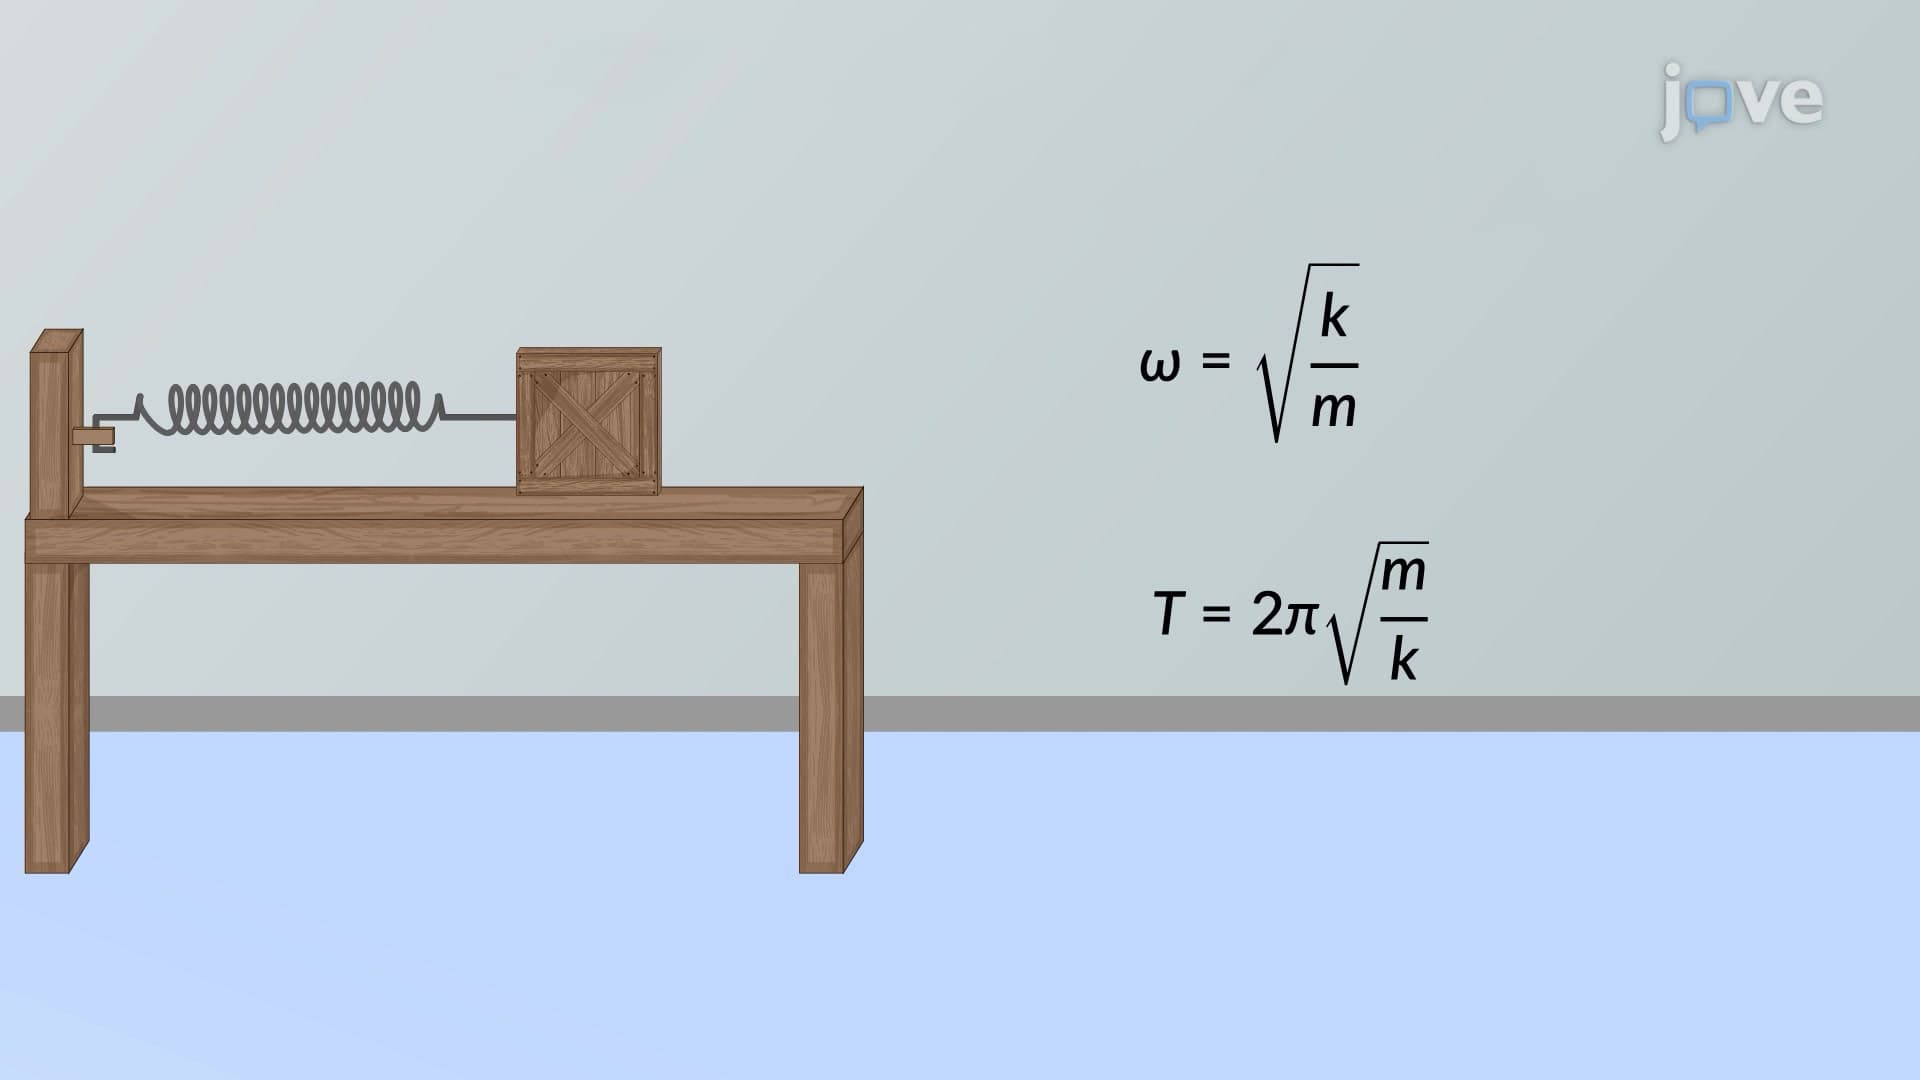
Frequency of Spring-Mass System
Consider a block on a spring on a frictionless surface. There...
 01:22
Muscle Stimulation Frequency
Wave summation
At low firing rates, motor neurons induce individual twitch contractions in muscle fibers. These twitches...
 01:22
Somatic Spinal Reflexes
One of the most well-known somatic spinal reflexes is the stretch reflex, which is activated by the sudden stretching of a muscle. This reflex involves the activation of specialized sensory receptors called muscle spindles, which are located in the muscle tissue and detect changes in the length and speed of muscle contractions. When a muscle is suddenly...
 01:14
Design Example: Frog Muscle Response
When the switch connecting the RL circuit is closed, a brief muscle contraction is observed. This is because, at a steady state, the inductor acts like a short...
 01:27
Substitution Rule Applied to Indefinite Integrals