A robust likelihood function for 3D human pose tracking
Related Experiment Video
Updated: Apr 21, 2026

Deep-Learning Based Multi-Joint Synchronous Tracking for Objective Quantification of Hindlimb Locomotor Kinematics in Rats
Published on: April 3, 2026

Abstract:
Recent works on 3D human pose tracking using unsupervised methods typically focus on improving the optimization framework to find a better maximum in the likelihood function (i.e., the tracker). In contrast, in this paper, we focus on improving the likelihood function, by making it more robust and less ambiguous, thus making the optimization task easier. In particular, we propose an exponential chamfer distance for model matching that is robust to small pose changes, and a part-based model that is better able to localize partially occluded and overlapping parts. Using a standard annealing particle filter and simple diffusion motion model, the proposed likelihood function obtains significantly lower error than other unsupervised tracking methods on the HumanEva dataset. Noting that the joint system of the tracker’s body model is different than the joint system of the motion capture ground-truth model, we propose a novel method for transforming between the two joint systems. Applying this bias correction, our part-based likelihood obtains results equivalent to state-of-the-art supervised tracking methods.
More Related Videos


Related Concept Videos
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:22
Planar Rigid-Body Motion
Planar motion is typically divided into three distinct categories. The first is rectilinear translation, demonstrated by a subway train that moves along...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:18
Kinematic Equations - III
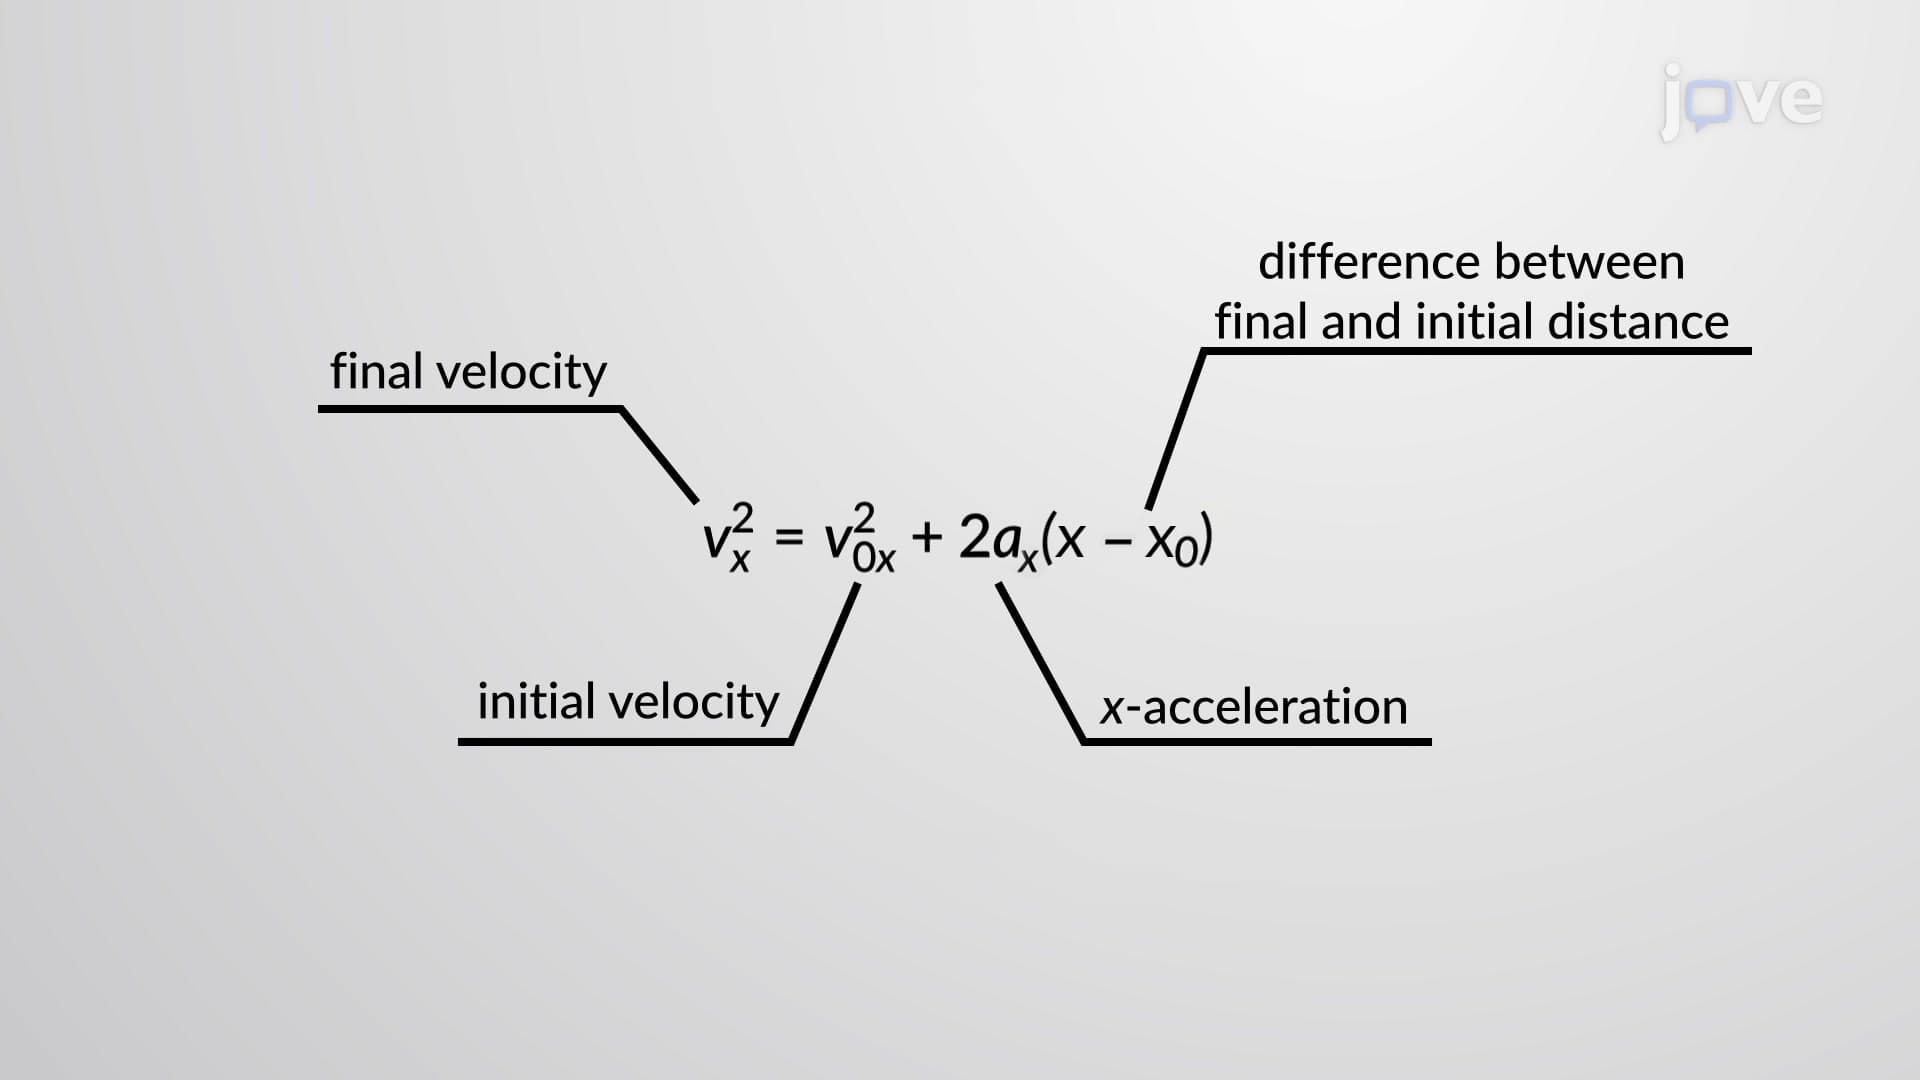
Using the kinematic equations,...
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...