Synchronised and complementary coordination mechanisms in an asymmetric joint aiming task
Related Experiment Video
Updated: Apr 21, 2026
Efficiently Recording the Eye-Hand Coordination to Incoordination Spectrum
Published on: March 21, 2019
Joshua C Skewes1, Lea Skewes, John Michael
1Department of Society and Culture, Interacting Minds Centre, Aarhus University, Jens Chr. Skous Vej 4, Building 1.483, 3, 8000, Aarhus C, Denmark, filjcs@cas.au.dk.

Abstract:
Many forms of social interaction require that behaviour be coordinated in the here and now. Much research has been conducted on how people coordinate their actions in real time to achieve a joint goal, showing that people use both synchronised (i.e., symmetric) and complementary (i.e., asymmetric) strategies. These two mechanisms have been mostly studied independently, the former in the context of rhythmic tasks, and the latter in non-rhythmic tasks. However, people often balance these two strategies in real-life social interactions, in order to achieve a joint goal more effectively. Here, our aim was to investigate how people may implicitly balance synchronisation and complementarity in a continuous joint aiming task. We asked dyads to synchronise the timing of their clicks between targets, while changing task constraints for one member of the dyad (i.e., different task difficulties) to asymmetrically perturb the continuous interaction. This allowed us to investigate how individuals implicitly negotiate complementary leader-follower dynamics to achieve synchronisation. We found that dyads flexibly switch from mutual to asymmetric adaptation given variations in task constraints. Specifically, our results show that both members adapt equally up to a certain level of difficulty; after this point, the partner with the difficult task becomes less adaptive, and hence more of a leader, while the adaptability of the member with the easier task remains unchanged. This proves to be an effective strategy in this asymmetric task, as people synchronise better with an irregular, but adaptive partner, than with a completely predictable, but non-responsive metronome. These results show that given asymmetric task constraints, adaptability, rather than predictability, facilitates coordination.

Related Concept Videos
 01:24
Muscle Coordination and Action
Agonists
Agonist muscles, often called prime movers, are the primary muscles responsible for producing a specific movement....
 01:30
Method of Joints: Problem Solving II
 01:30
Method of Joints: Problem Solving I
 01:09
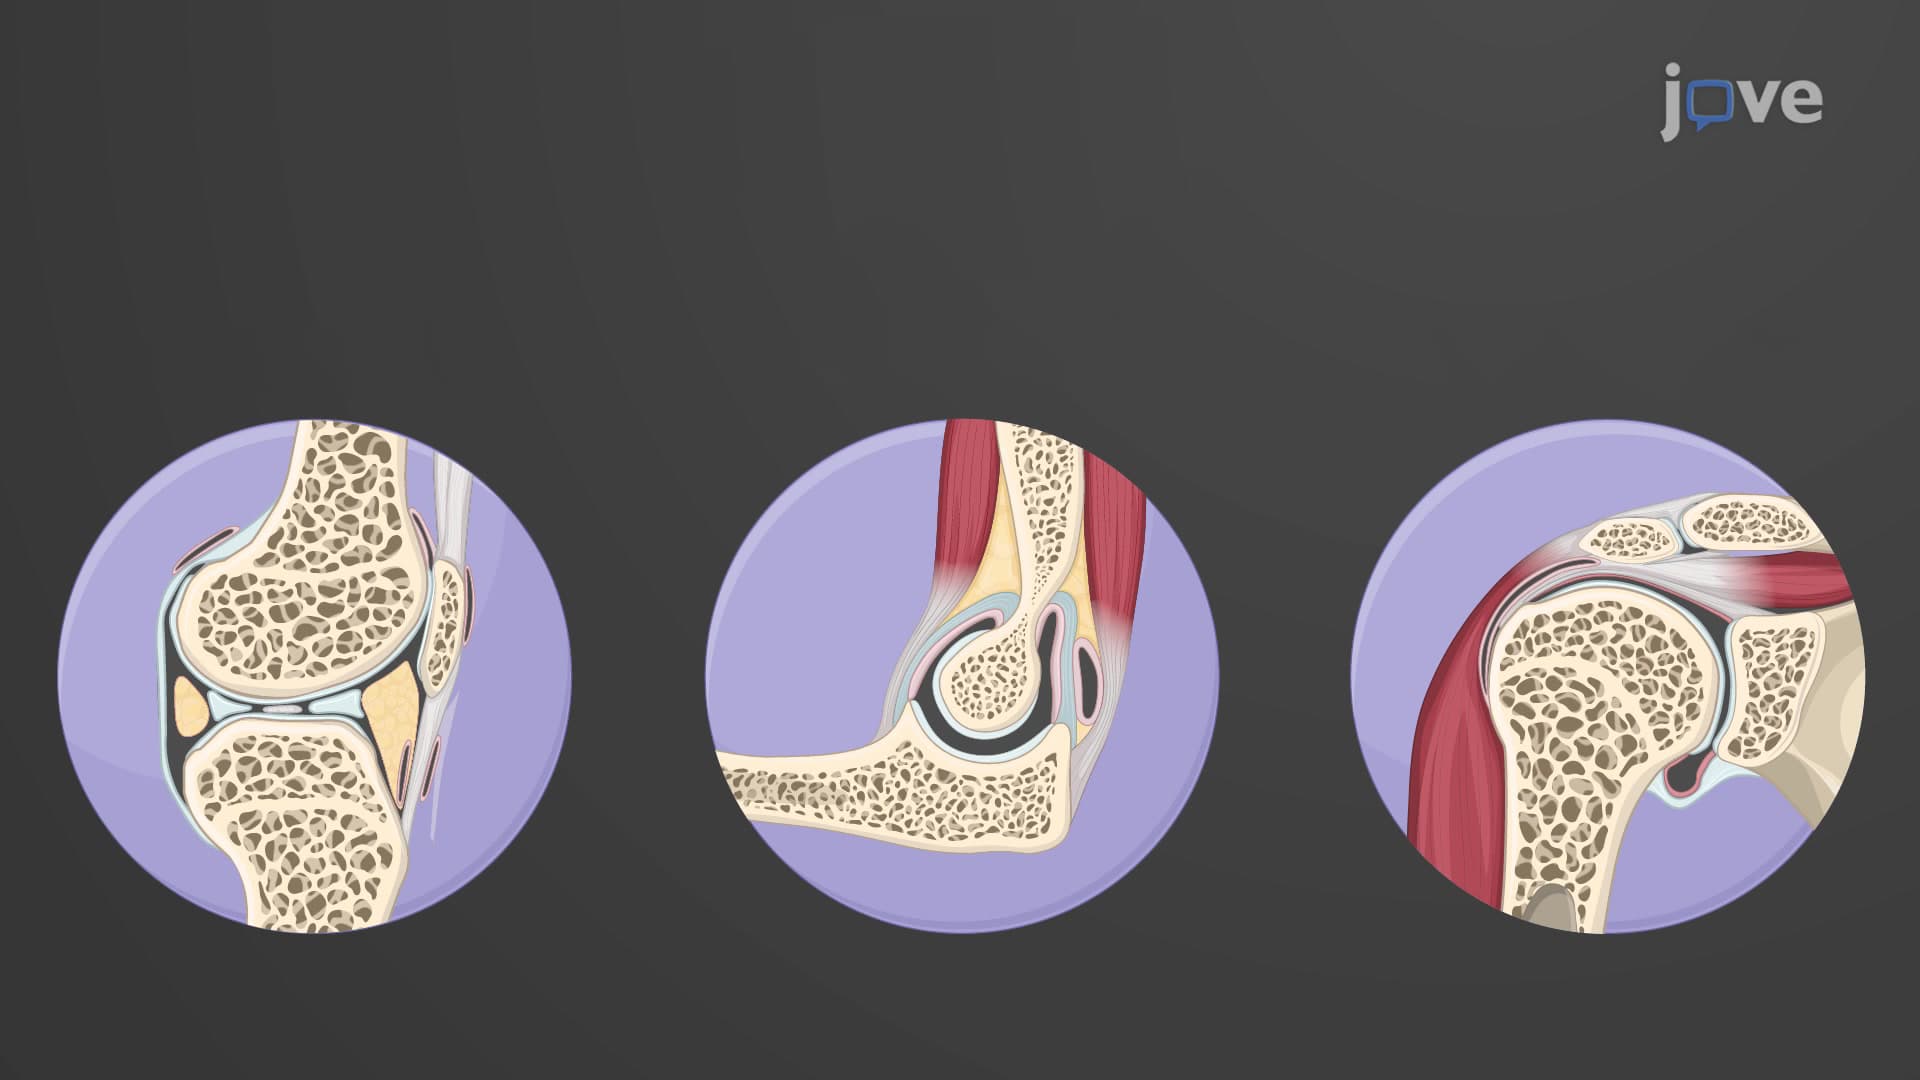
Functional Classification of Joints
The functional classification of joints is determined by the amount of mobility between the adjacent bones. Joints are functionally classified as a synarthrosis or immobile joint, an amphiarthrosis or slightly moveable joint, or as a diarthrosis, a freely moveable joint. Fibrous and cartilaginous joints can be functionally classified as either synarthroses or amphiarthroses, whereas all synovial joints are classified as diarthroses.
Synarthrosis
An...
 01:16
Structural Joints: Synovial Joints
 01:15
Kinematic Equations: Problem Solving