A novel estimation algorithm based on data and low-order models for virtual unmodeled dynamics
Related Experiment Video
Updated: Apr 20, 2026
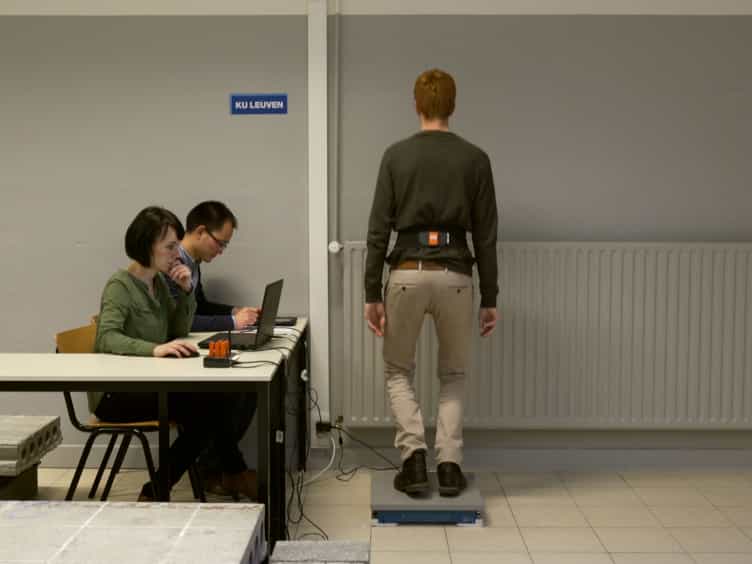
Simulation of Human-induced Vibrations Based on the Characterized In-field Pedestrian Behavior
Published on: April 13, 2016

Abstract:
In this paper, the challenging issue of estimating virtual unmodeled dynamics is addressed. A novel estimation algorithm based on historical data and the output of low-order approximation models for virtual un-modeled dynamics is presented. In particular, the virtual un-modeled dynamics are decomposed into known and unknown parts, where only the unknown part is to be estimated. The method effectively avoids the need to use the unknown control input directly, and enables the estimation of the un-modeled dynamics with a relatively simple algorithm. Moreover, it is shown that the proposed algorithm overcomes the difficulty in obtaining the control solutions caused by the fact that the controller input is embedded in un-modeled dynamics. Finally, simulation studies are presented to demonstrate the effectiveness of the proposed method.

Related Concept Videos
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:06
Virtual Work for a System of Connected Rigid Bodies
Next,...
 01:15
Kinematic Equations: Problem Solving
 01:25
Modeling with Differential Equations
 01:29
Mechanistic Models: Compartment Models in Algorithms for Numerical Problem Solving
In individual population analyses, different algorithms are employed, such as Cauchy's method, which uses a...
 01:20
Virtual Work
In static equilibrium, a body can experience an imaginary or virtual movement, such as displacement or rotation. The virtual work done by a force is equal to the dot product of force and virtual displacement in the direction of the force. When it comes to virtually rotating a...