A grip force model for the da Vinci end-effector to predict a compensation force
Related Experiment Video
Updated: Apr 20, 2026
Measurement of Spatial Stability in Precision Grip
Published on: June 4, 2020
Chiwon Lee1, Yong Hyun Park, Chiyul Yoon
1The Interdisciplinary Program for Bioengineering, Graduate School, Seoul National University, Seoul, 110-744, Korea, lcwkf16@snu.ac.kr.

Abstract:
A torque transfer system (TTS) that measures grip forces is developed to resolve a potential drawback of the current da Vinci robot system whose grip forces vary according to the different postures of its EndoWrist. A preliminary model of EndoWrist Inner Mechanism Model (EIMM) is also developed and validated with real grip force measurements. EndoWrist's grip forces, posture angles, and transferred torque are measured by using TTS. The mean measured grip forces of three different EndoWrist for 27 different postures were very diverse. The EndoWrist exerted different grip forces, with a minimum of 1.84-times more and a maximum of 3.37-times more in specific posture even if the surgeon exerted the same amount of force. Using the posture angles as input and the grip forces as output, the EIMM is constructed. Then, expected grip force values obtained from EIMM are compared with actual measurements of da Vinci EndoWrist to validate the proposed model. From these results, surgeons will be beneficial with the understandings of actual grip force being applied to tissue and mechanical properties of robotic system. The EIMM could provide a baseline in designing a force-feedback system for surgical robot. These are significantly important to prevent serious injury by maintaining a proper force to tissue.
Related Concept Videos
 01:30
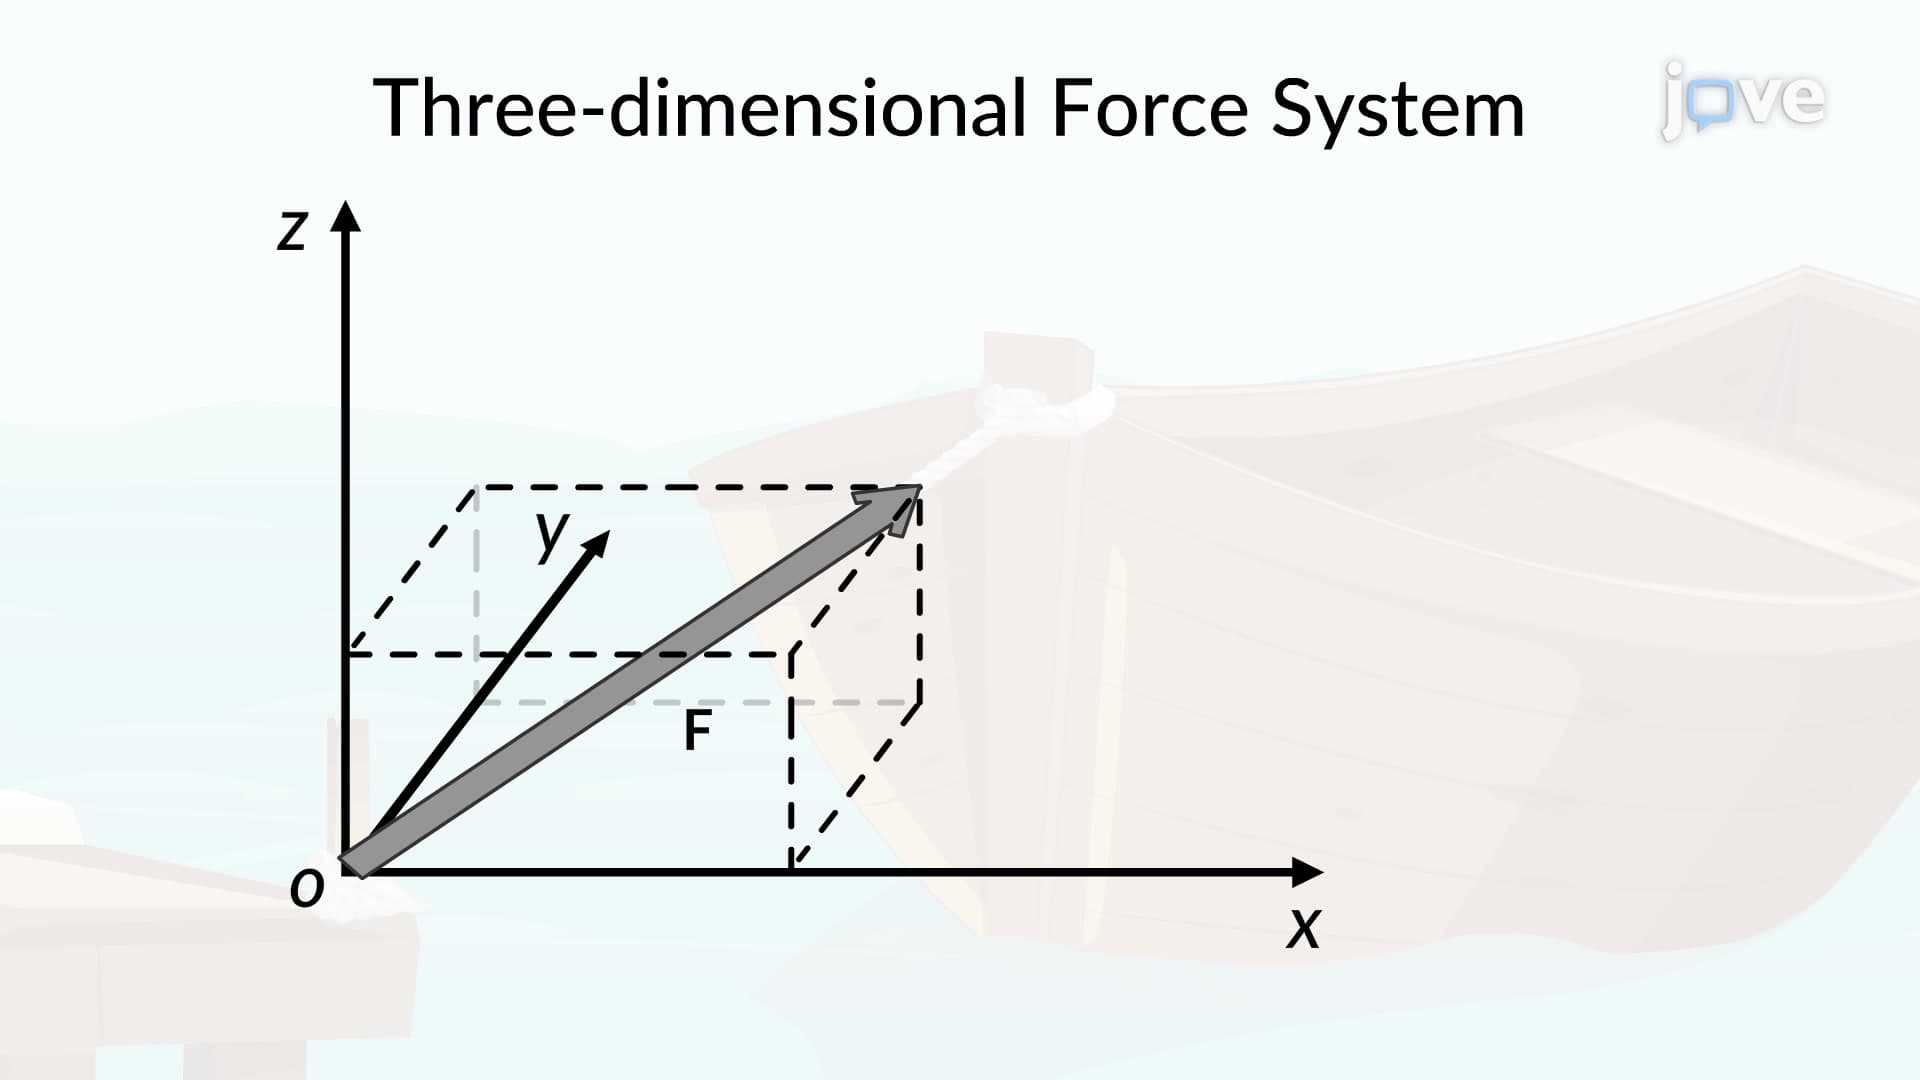
Three-Dimensional Force System
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:20
Two-Dimensional Force System
 01:17
Frictional Forces on Screws
A jack with a square-threaded screw is a mechanical device used to lift heavy loads by applying a force at its handle. When the force is applied, the screw turns, raising the load. The screw can...
 01:05
Static and Kinetic Frictional Force
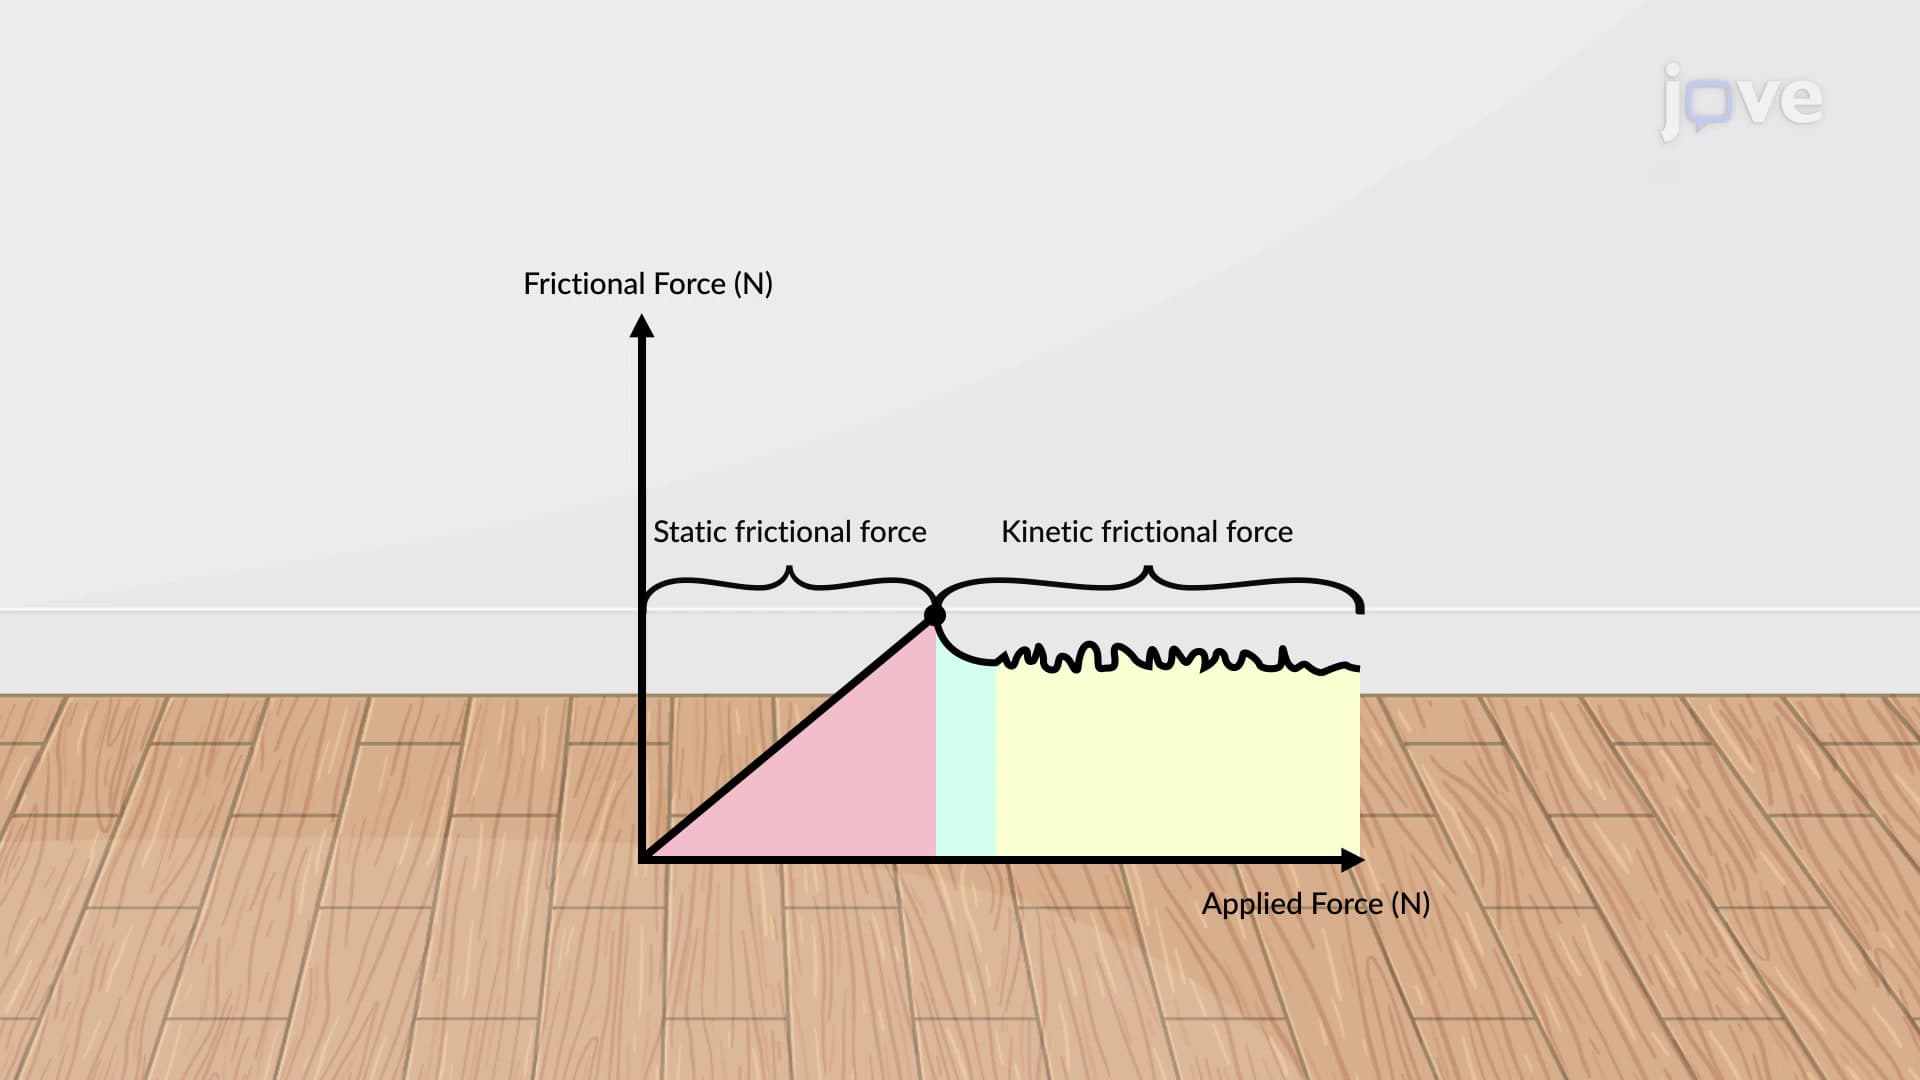
However, if two systems are in contact and are stationary relative to one...
 00:57
Power Expended by a Constant Force