Related Experiment Video
Updated: Apr 19, 2026
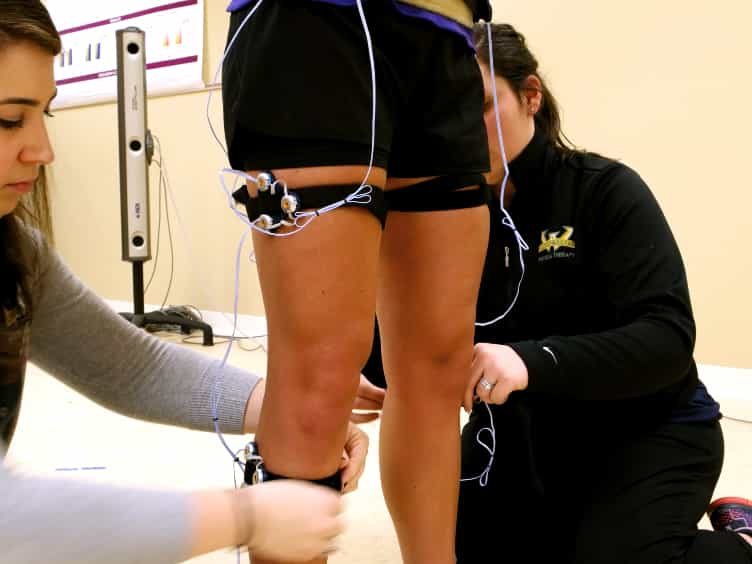

Video Movement Analysis Using Smartphones ViMAS: A Pilot Study
Published on: March 14, 2017
Magnetic, Acceleration Fields and Gyroscope Quaternion (MAGYQ)-based attitude estimation with smartphone sensors for
Valérie Renaudin1, Christophe Combettes2
1IFSTTAR, GEOLOC Laboratory, Route de Bouaye CS4, Bouguenais 44344, France. valerie.renaudin@ifsttar.fr.

Abstract:
The dependence of proposed pedestrian navigation solutions on a dedicated infrastructure is a limiting factor to the deployment of location based services. Consequently self-contained Pedestrian Dead-Reckoning (PDR) approaches are gaining interest for autonomous navigation. Even if the quality of low cost inertial sensors and magnetometers has strongly improved, processing noisy sensor signals combined with high hand dynamics remains a challenge. Estimating accurate attitude angles for achieving long term positioning accuracy is targeted in this work. A new Magnetic, Acceleration fields and GYroscope Quaternion (MAGYQ)-based attitude angles estimation filter is proposed and demonstrated with handheld sensors. It benefits from a gyroscope signal modelling in the quaternion set and two new opportunistic updates: magnetic angular rate update (MARU) and acceleration gradient update (AGU). MAGYQ filter performances are assessed indoors, outdoors, with dynamic and static motion conditions. The heading error, using only the inertial solution, is found to be less than 10° after 1.5 km walking. The performance is also evaluated in the positioning domain with trajectories computed following a PDR strategy.
More Related Videos

Related Concept Videos
 01:02
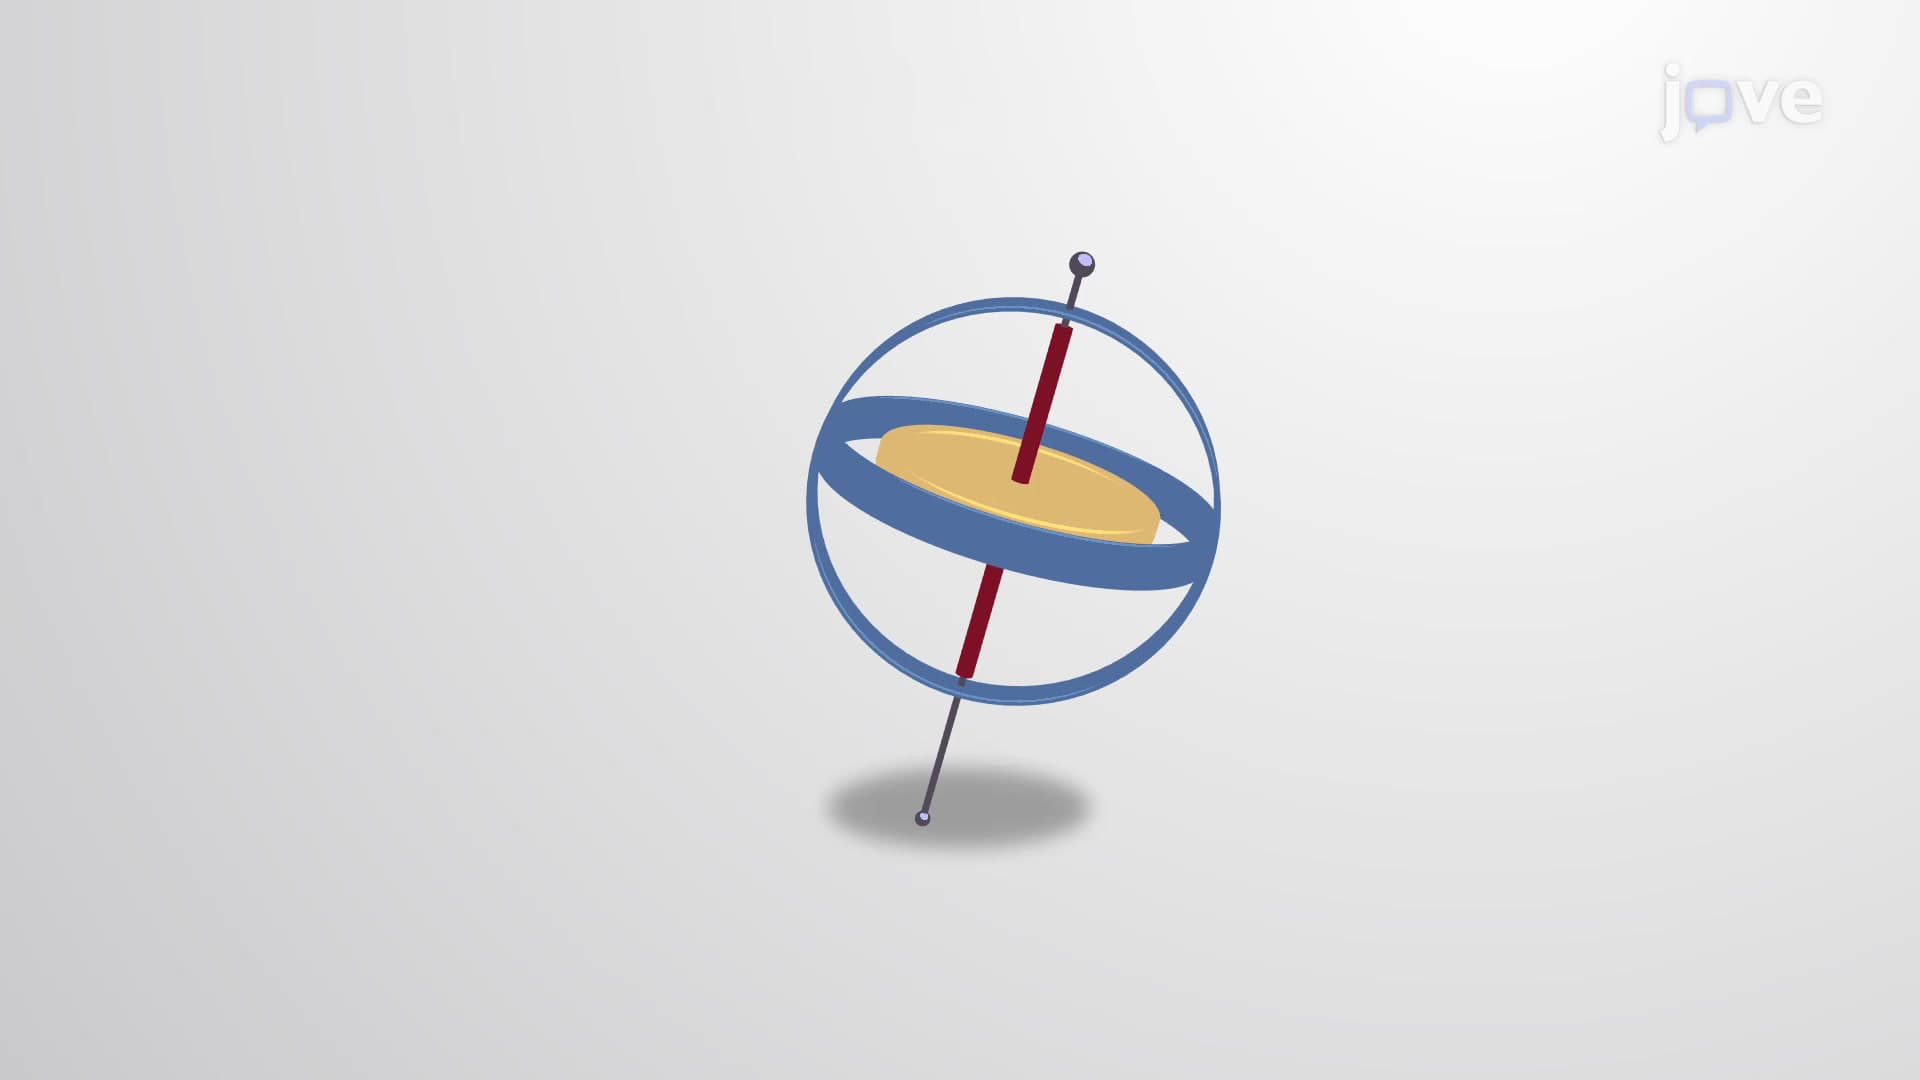
Gyroscope
 01:24
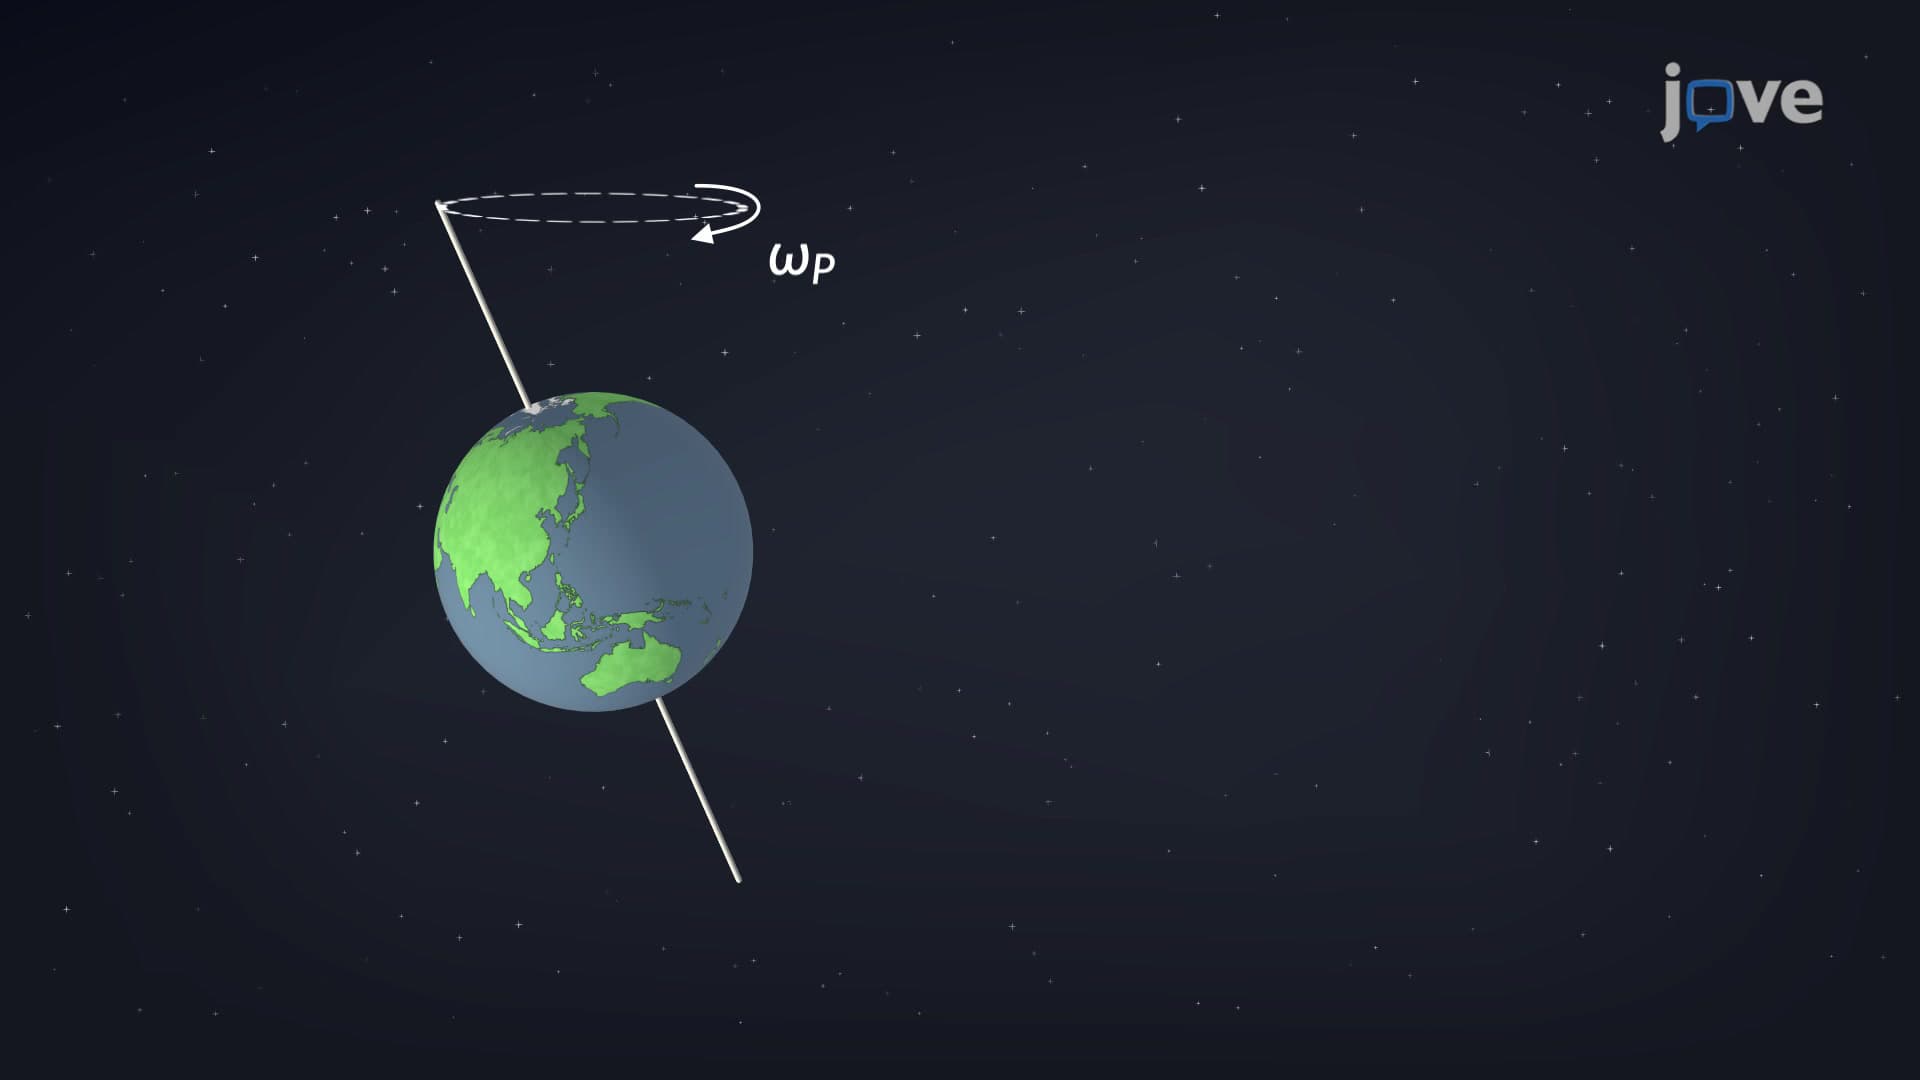
Gyroscope: Precession
 01:12
Measuring Acceleration Due to Gravity
A simple pendulum can be described as a point mass and a string. Meanwhile, a physical pendulum is any object whose oscillations are similar to a simple pendulum, but cannot be modeled as a point mass on a string because its mass is distributed over a larger area. The behavior of a physical pendulum can be modeled using the principles of...
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...
 01:28
Field Application of Global Positioning System
 01:11
Angular Velocity and Acceleration