Related Experiment Video
Updated: Apr 19, 2026

Imaging and Analysis of Neurofilament Transport in Excised Mouse Tibial Nerve
Published on: August 31, 2020
Transverse compactlike pulse signals in a two-dimensional nonlinear electrical network
Fabien Kenmogne1, David Yemélé2, Jacques Kengne3
1Laboratory of Modelling and Simulation in Engineering and Biological Physics, Faculty of Science, University of Yaoundé I, Po Box 812, Yaoundé, Cameroon.

Abstract:
We investigate the compactlike pulse signal propagation in a two-dimensional nonlinear electrical transmission network with the intersite circuit elements (both in the propagation and transverse directions) acting as nonlinear resistances. Model equations for the circuit are derived and can reduce from the continuum limit approximation to a two-dimensional nonlinear Burgers equation governing the propagation of the small amplitude signals in the network. This equation has only the mass as conserved quantity and can admit as solutions cusp and compactlike pulse solitary waves, with width independent of the amplitude, according to the sign of the product of its nonlinearity coefficients. In particular, we show that only the compactlike pulse signal may propagate depending on the choice of the realistic physical parameters of the network, and next we study the dissipative effects on the pulse dynamics. The exactness of the analytical analysis is confirmed by numerical simulations which show a good agreement with results predicted by the Rosenau and Hyman K(2,2) equation.
Related Concept Videos
 01:17
NMR Spectrometers: Radiofrequency Pulses and Pulse Sequences
 01:19
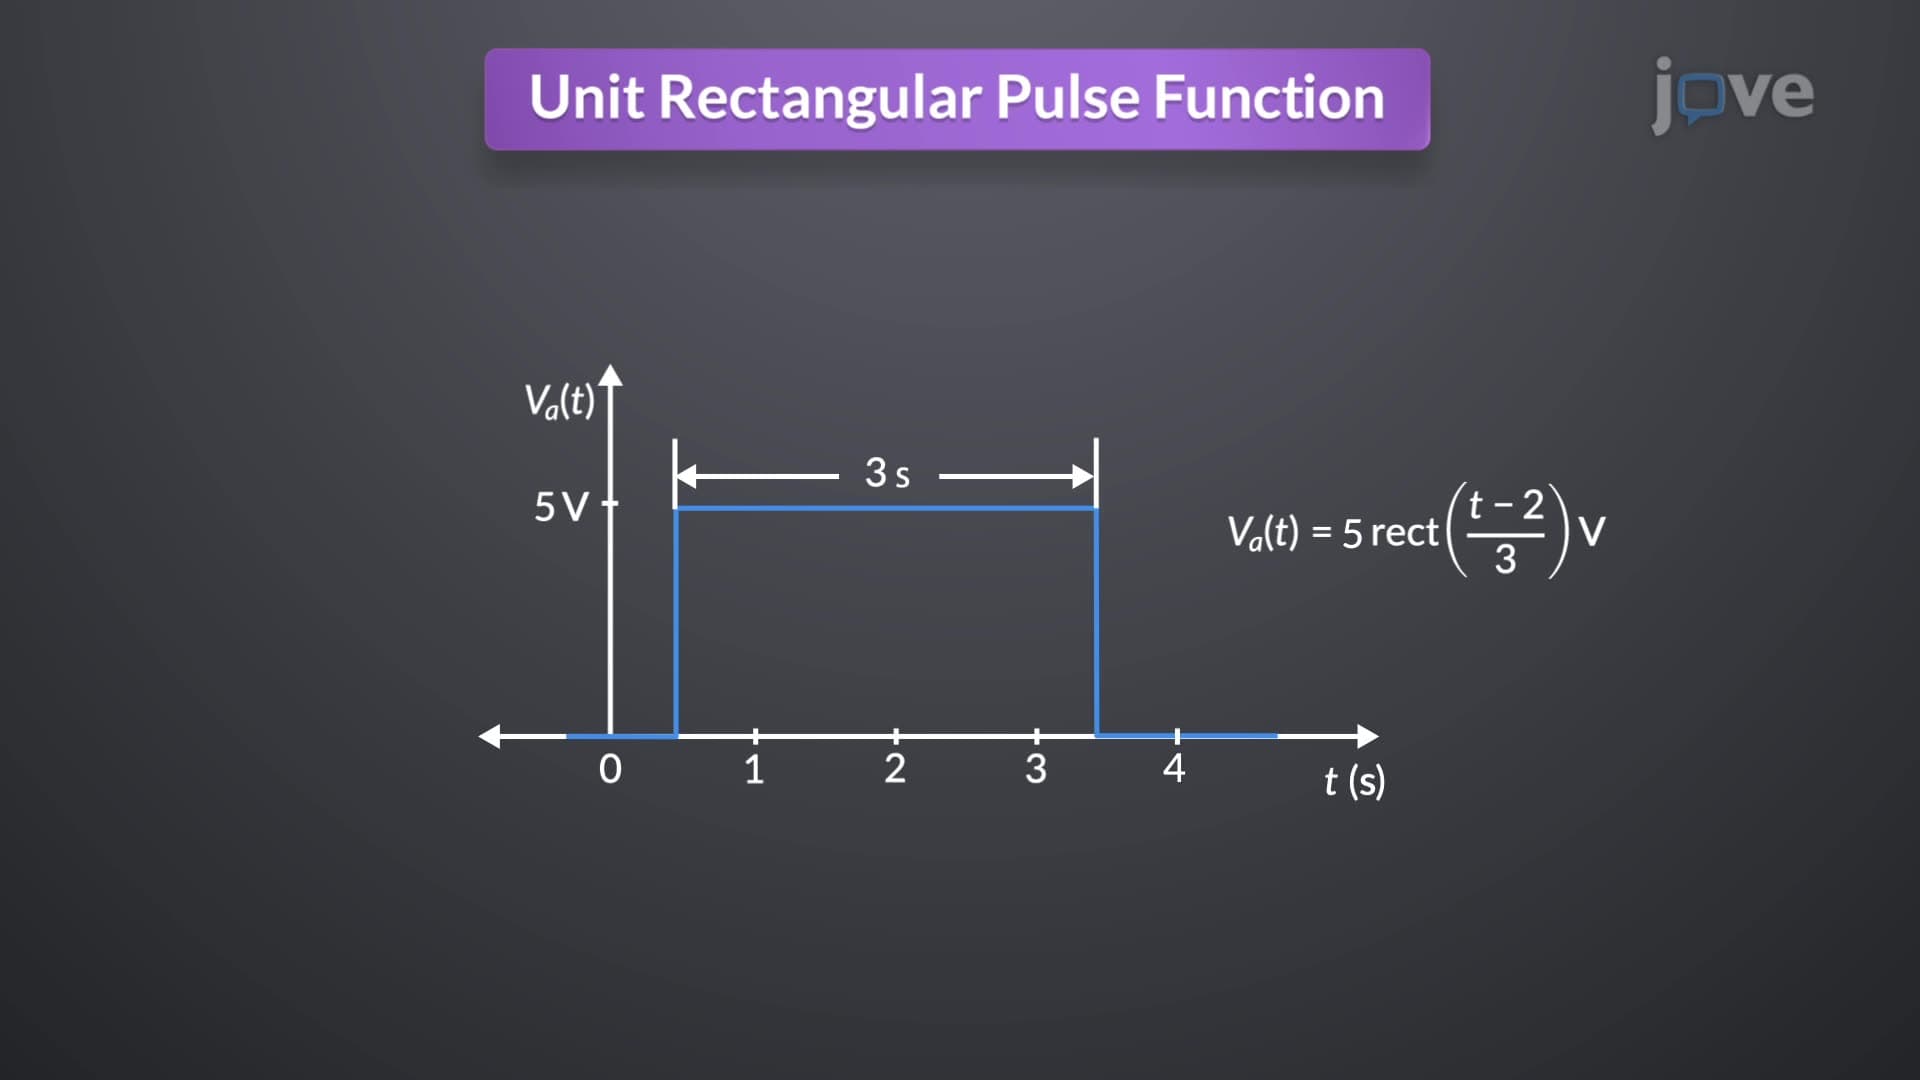
Rectangular and Triangular Pulse Function
For example, consider a rectangular pulse with a 5V amplitude, a 3-second duration, and centered at t=2 seconds. This pulse can be expressed using the rectangular function, written as,
 01:27
Traveling Waves: Lossless Lines
 01:26
Linear Approximation in Frequency Domain
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
 01:24
Convolution: Math, Graphics, and Discrete Signals
To simplify the convolution integral, it is assumed that both the input signal and impulse response are zero for negative time values. The graphical convolution process...
 01:26
Transmission-Line Differential Equations
Line Section Model
A circuit representing a line section of length Δx helps in understanding the transmission line parameters. The voltage V(x) and current i(x) are measured...