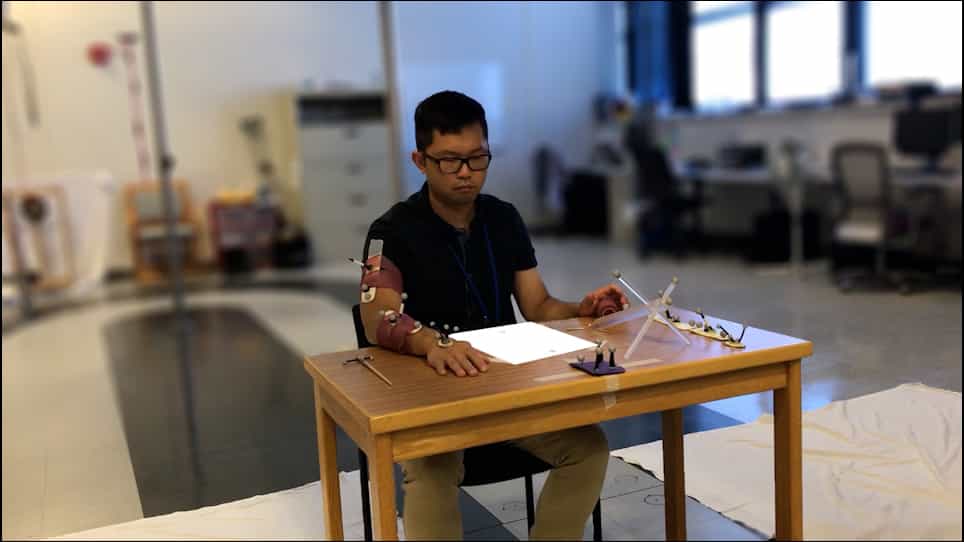
Related Experiment Video
Updated: Apr 19, 2026
An Objective and Child-friendly Assessment of Arm Function by Using a 3-D Sensor
Published on: February 12, 2018
Spatial Map of Synthesized Criteria for the Redundancy Resolution of Human Arm Movements

Abstract:
The kinematic redundancy of the human arm enables the elbow position to rotate about the axis going through the shoulder and wrist, which results in infinite possible arm postures when the arm reaches to a target in a 3-D workspace. To infer the control strategy the human motor system uses to resolve redundancy in reaching movements, this paper compares five redundancy resolution criteria and evaluates their arm posture prediction performance using data on healthy human motion. Two synthesized criteria are developed to provide better real-time arm posture prediction than the five individual criteria. Of these two, the criterion synthesized using an exponential method predicts the arm posture more accurately than that using a least squares approach, and therefore is preferable for inferring the contributions of the individual criteria to motor control during reaching movements. As a methodology contribution, this paper proposes a framework to compare and evaluate redundancy resolution criteria for arm motion control. A cluster analysis which associates criterion contributions with regions of the workspace provides a guideline for designing a real-time motion control system applicable to upper-limb exoskeletons for stroke rehabilitation.