Task-specific stability of multifinger steady-state action
Related Experiment Video
Updated: Apr 18, 2026
Measurement of Spatial Stability in Precision Grip
Published on: June 4, 2020
Sasha Reschechtko1, Vladimir M Zatsiorsky, Mark L Latash
1a Department of Kinesiology , The Pennsylvania State University , University Park.

Abstract:
The authors explored task-specific stability during accurate multifinger force production tasks with different numbers of instructed fingers. Subjects performed steady-state isometric force production tasks and were instructed not to interfere voluntarily with transient lifting-and-lowering perturbations applied to the index finger. The main results were (a) intertrial variance in the space of finger modes at steady states was larger within the subspace that had no effect on the total force (the uncontrolled manifold [UCM]); (b) perturbations caused large deviations of finger modes within the UCM (motor equivalence); and (c) deviations caused by the perturbation showed larger variance within the UCM. No significant effects of the number of task fingers were noted in any of the 3 indicators. The results are discussed within the frameworks of the UCM and referent configuration hypotheses. The authors conclude, in particular, that all the tasks were effectively 4-finger tasks with different involvement of task and nontask fingers.
More Related Videos
 15:00
The Impact of Motor Task Conditions on Goal-Directed Arm Reaching Kinematics and Trunk Compensation in Chronic Stroke Survivors
Published on: May 2, 2021
 08:27
Three-Dimensional Finger Motion Tracking during Needling: A Solution for the Kinematic Analysis of Acupuncture Manipulation
Published on: October 28, 2021
Related Concept Videos
 01:21
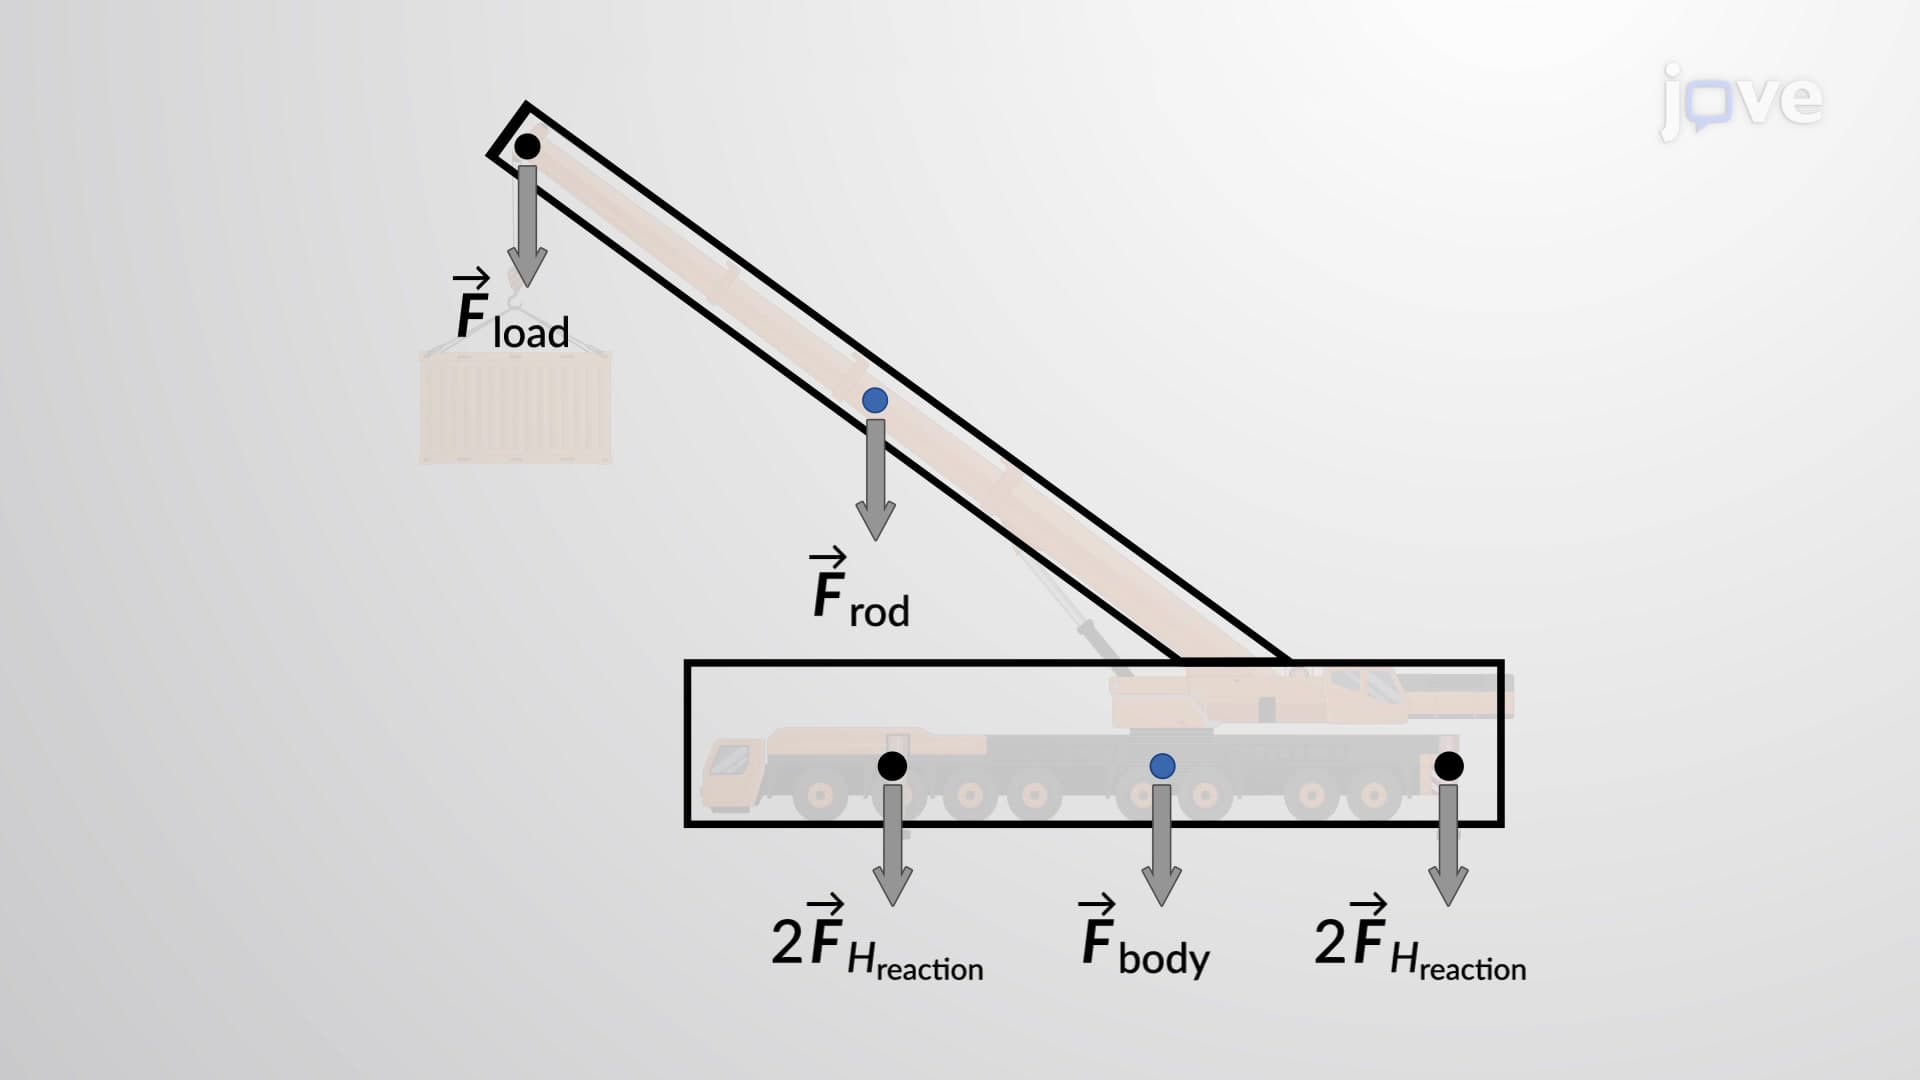
Rigid Body Equilibrium Problems - II
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
 00:49
Rigid Body Equilibrium Problems - I
 01:15
Kinematic Equations: Problem Solving
 01:13
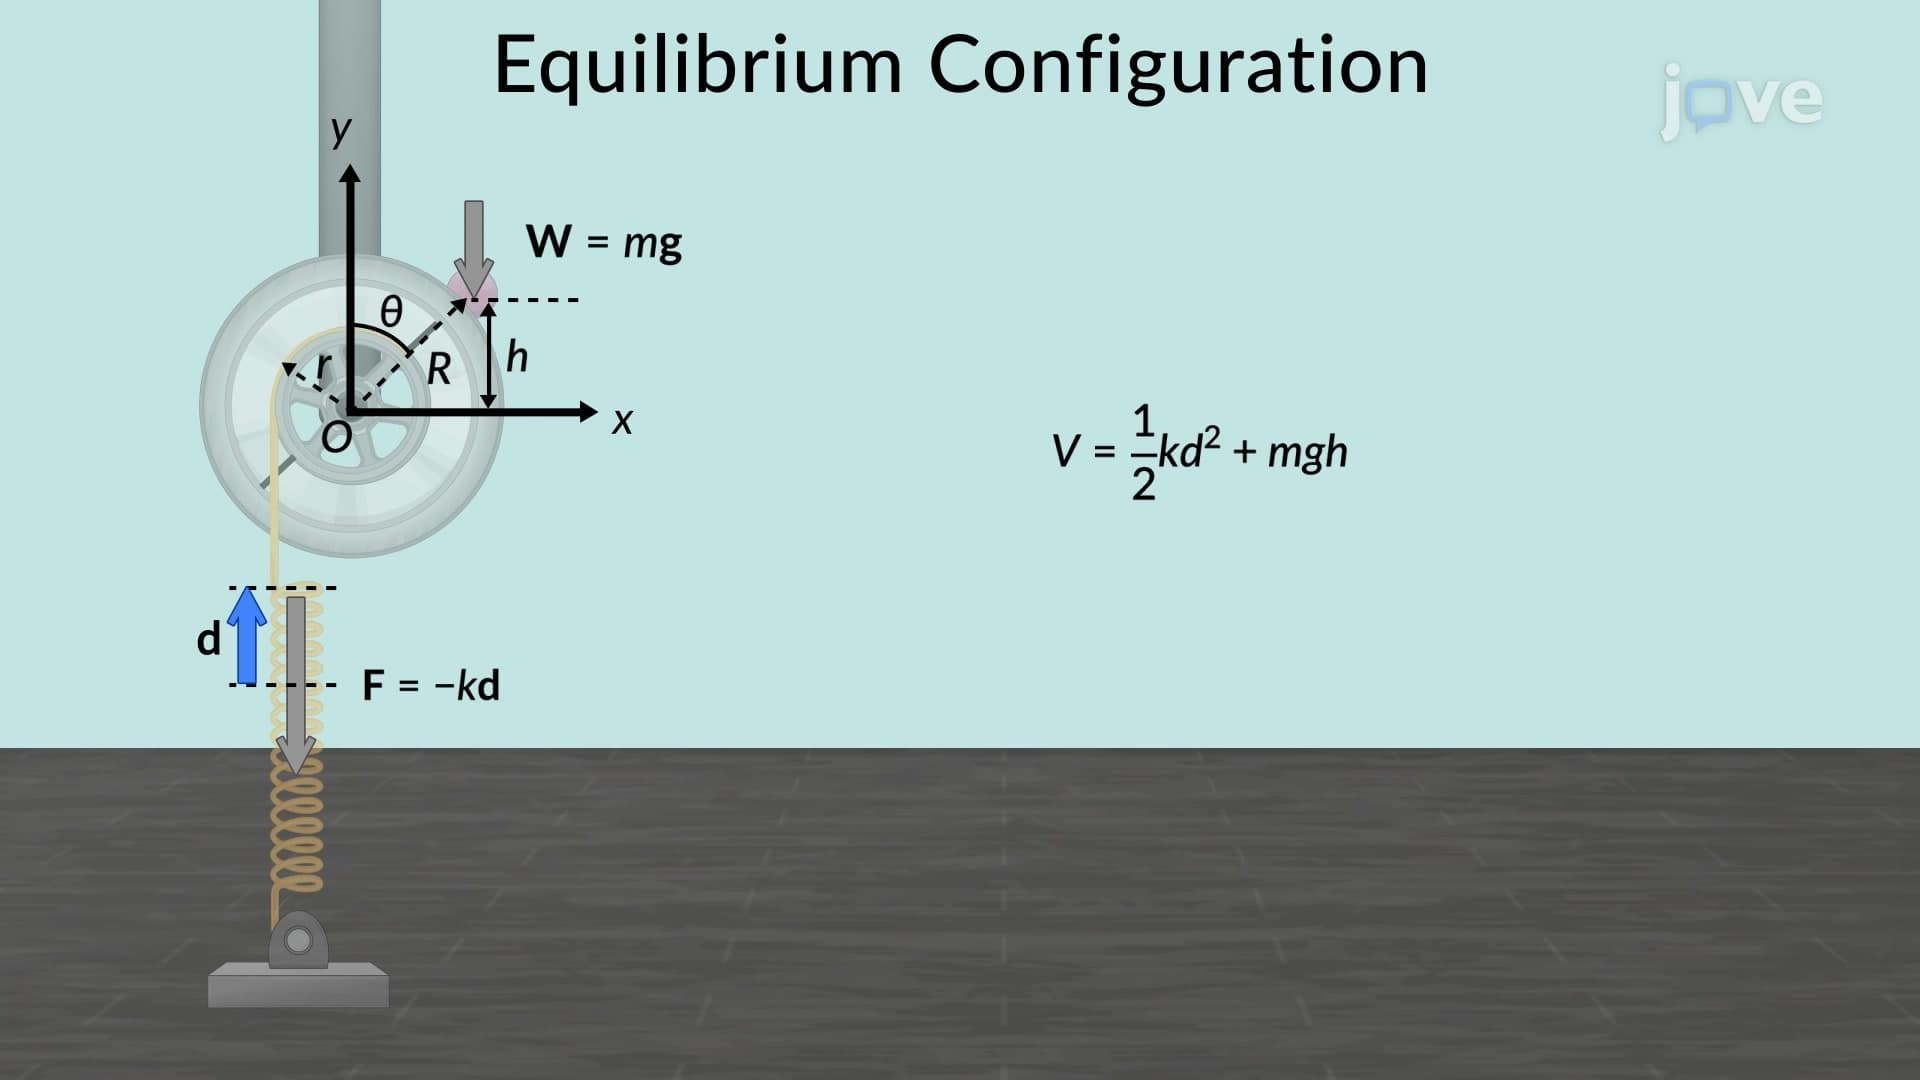
Stability of Equilibrium Configuration: Problem Solving
Problem-solving in the context of the stability of equilibrium configuration...
 01:23
Stability of Equilibrium Configuration
A stable equilibrium occurs when a system tends to return to its original position when given a small displacement, and the potential energy is at its minimum. An example of a stable equilibrium is when a cantilever beam is fixed at one end and a weight is attached to the other end. If the weight...
 01:14
Stability of structures