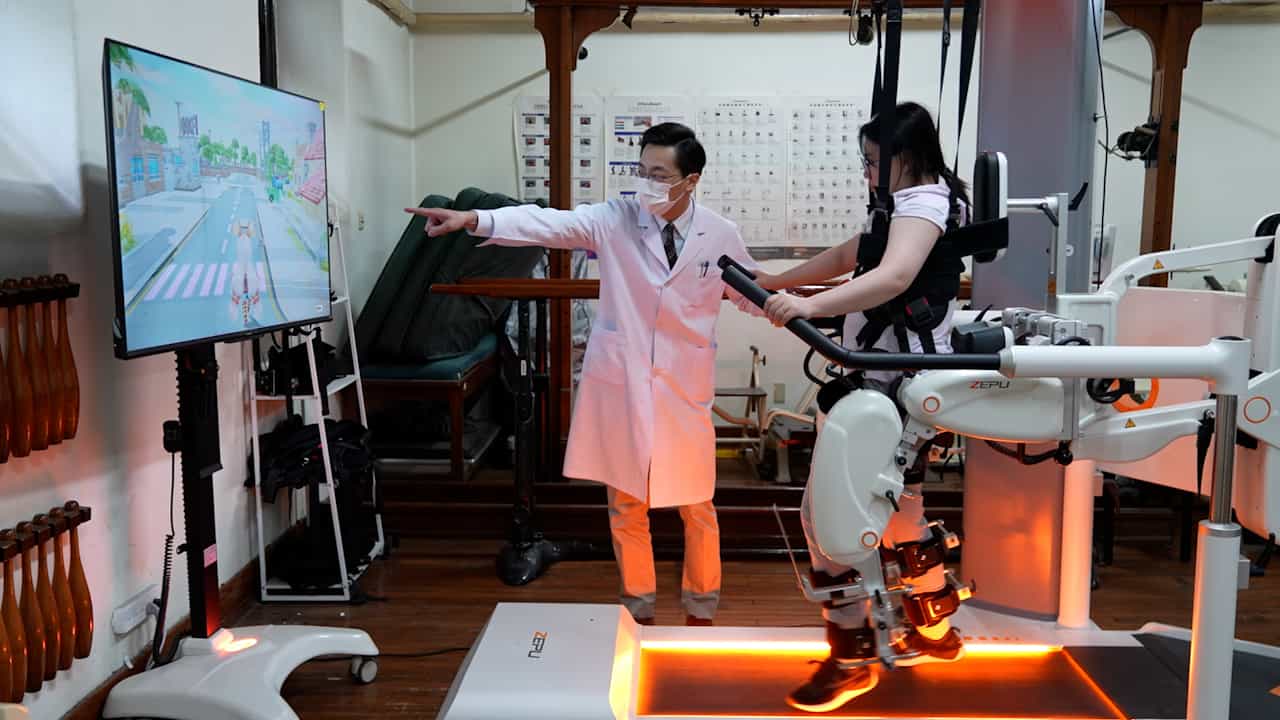
Related Experiment Video
Updated: Apr 18, 2026


Author Spotlight: Assessing Brain Activity in Robotic-Assisted Lower Limb Rehabilitation Using fNIRS
Published on: June 7, 2024
An assistive controller for a lower-limb exoskeleton for rehabilitation after stroke, and preliminary assessment

Abstract:
This paper describes a novel controller, intended for use in a lower-limb exoskeleton, to aid gait rehabilitation in patients with hemiparesis after stroke. The controller makes use of gravity compensation, feedforward movement assistance, and reinforcement of isometric joint torques to achieve assistance without dictating the spatiotemporal nature of joint movement. The patient is allowed to self-select walking speed and is able to make trajectory adaptations to maintain balance without interference from the controller. The governing equations and the finite state machine which comprise the system are described herein. The control architecture was implemented in a lower-limb exoskeleton and a preliminary experimental assessment was conducted in which a patient with hemiparesis resulting from stroke walked with assistance from the exoskeleton. The patient exhibited improvements in fast gait speed, step length asymmetry, and stride length in each session, as measured before and after exoskeleton training, presumably as a result of using the exoskeleton.