Related Experiment Video
Updated: Apr 18, 2026
Utilizing a 3D Printed Laparoscopic Nissen Fundoplication Model to Shorten a Resident's Learning Curve
Published on: August 15, 2025
Impact of laparoscopic experience on virtual robotic simulator dexterity
Byung Eun Yoo1, Jin Kim1, Jae Sung Cho1
1Division of Colorectal Surgery, Department of Surgery, Korea University College of Medicine, Seoul, Korea.

Background:
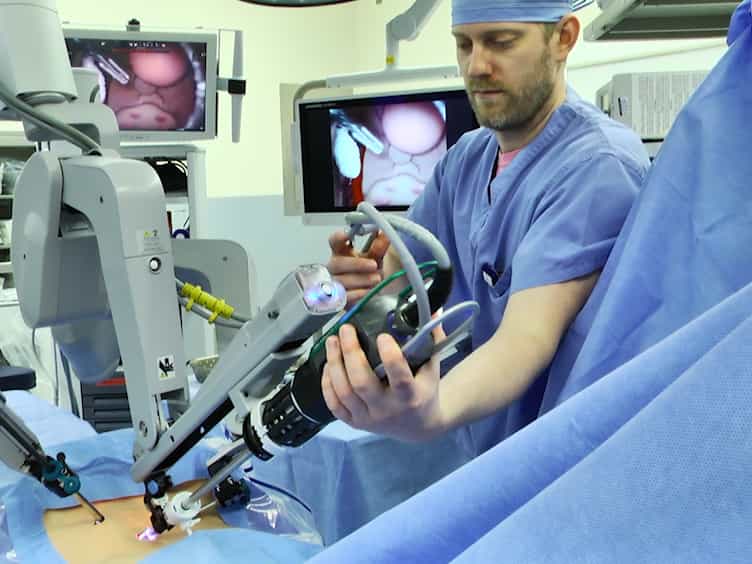
Different skills are required for robotic surgery and laparoscopic surgery. We hypothesized that the laparoscopic experience would not affect the performance with the da Vinci(®) system. A virtual robotic simulator was used to estimate the operator's robotic dexterity.
Materials And Methods:
The performance of 11 surgical fellows with laparoscopic experience and 14 medical students were compared using the dV-trainer(®). Each subject completed three virtual endo-wrist modules ("Pick and Place," "Peg Board," and "Match Board"). Performance was recorded using a built-in scoring algorithm.
Results:
In the Peg Board module, the performance of surgical fellows was better in terms of the number of instrument collisions and number of drops (P < 0.05). However, no significant differences were found in the percentage scores of the three endo-wrist modules between the groups.
Conclusion:
Robotic dexterity was not significantly affected by laparoscopic experience in this study. Laparoscopic experience is not an important factor for learning robotic skills.