Related Experiment Video
Updated: Apr 18, 2026

Assessment of Static Graviceptive Perception in the Roll-Plane using the Subjective Visual Vertical Paradigm
Published on: April 28, 2020
Inertial sensor self-calibration in a visually-aided navigation approach for a micro-AUV
Francisco Bonin-Font1, Miquel Massot-Campos2, Pep Lluis Negre-Carrasco3
1Systems, Robotics and Vision, Department of Mathematics and Computer Science, University of the Balearic Islands, Cra de Valldemossa, km 7.5, Palma de Mallorca 07122, Spain. francisco.bonin@uib.es.

Abstract:
This paper presents a new solution for underwater observation, image recording, mapping and 3D reconstruction in shallow waters. The platform, designed as a research and testing tool, is based on a small underwater robot equipped with a MEMS-based IMU, two stereo cameras and a pressure sensor. The data given by the sensors are fused, adjusted and corrected in a multiplicative error state Kalman filter (MESKF), which returns a single vector with the pose and twist of the vehicle and the biases of the inertial sensors (the accelerometer and the gyroscope). The inclusion of these biases in the state vector permits their self-calibration and stabilization, improving the estimates of the robot orientation. Experiments in controlled underwater scenarios and in the sea have demonstrated a satisfactory performance and the capacity of the vehicle to operate in real environments and in real time.
More Related Videos
 09:46
MPI CyberMotion Simulator: Implementation of a Novel Motion Simulator to Investigate Multisensory Path Integration in Three Dimensions
Published on: May 10, 2012
 07:24
Using Eye-tracking to Assess the Relative Importance of Visual and Vestibular Input to Subcortical Motion Processing in the Roll Plane
Published on: August 22, 2025
Related Concept Videos
 01:02
Gyroscope
 01:03
Inertial Frames of Reference
 01:12
Instrument Calibration
Analytical Balance Calibration
An analytical balance measures mass and requires regular calibration to...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:24
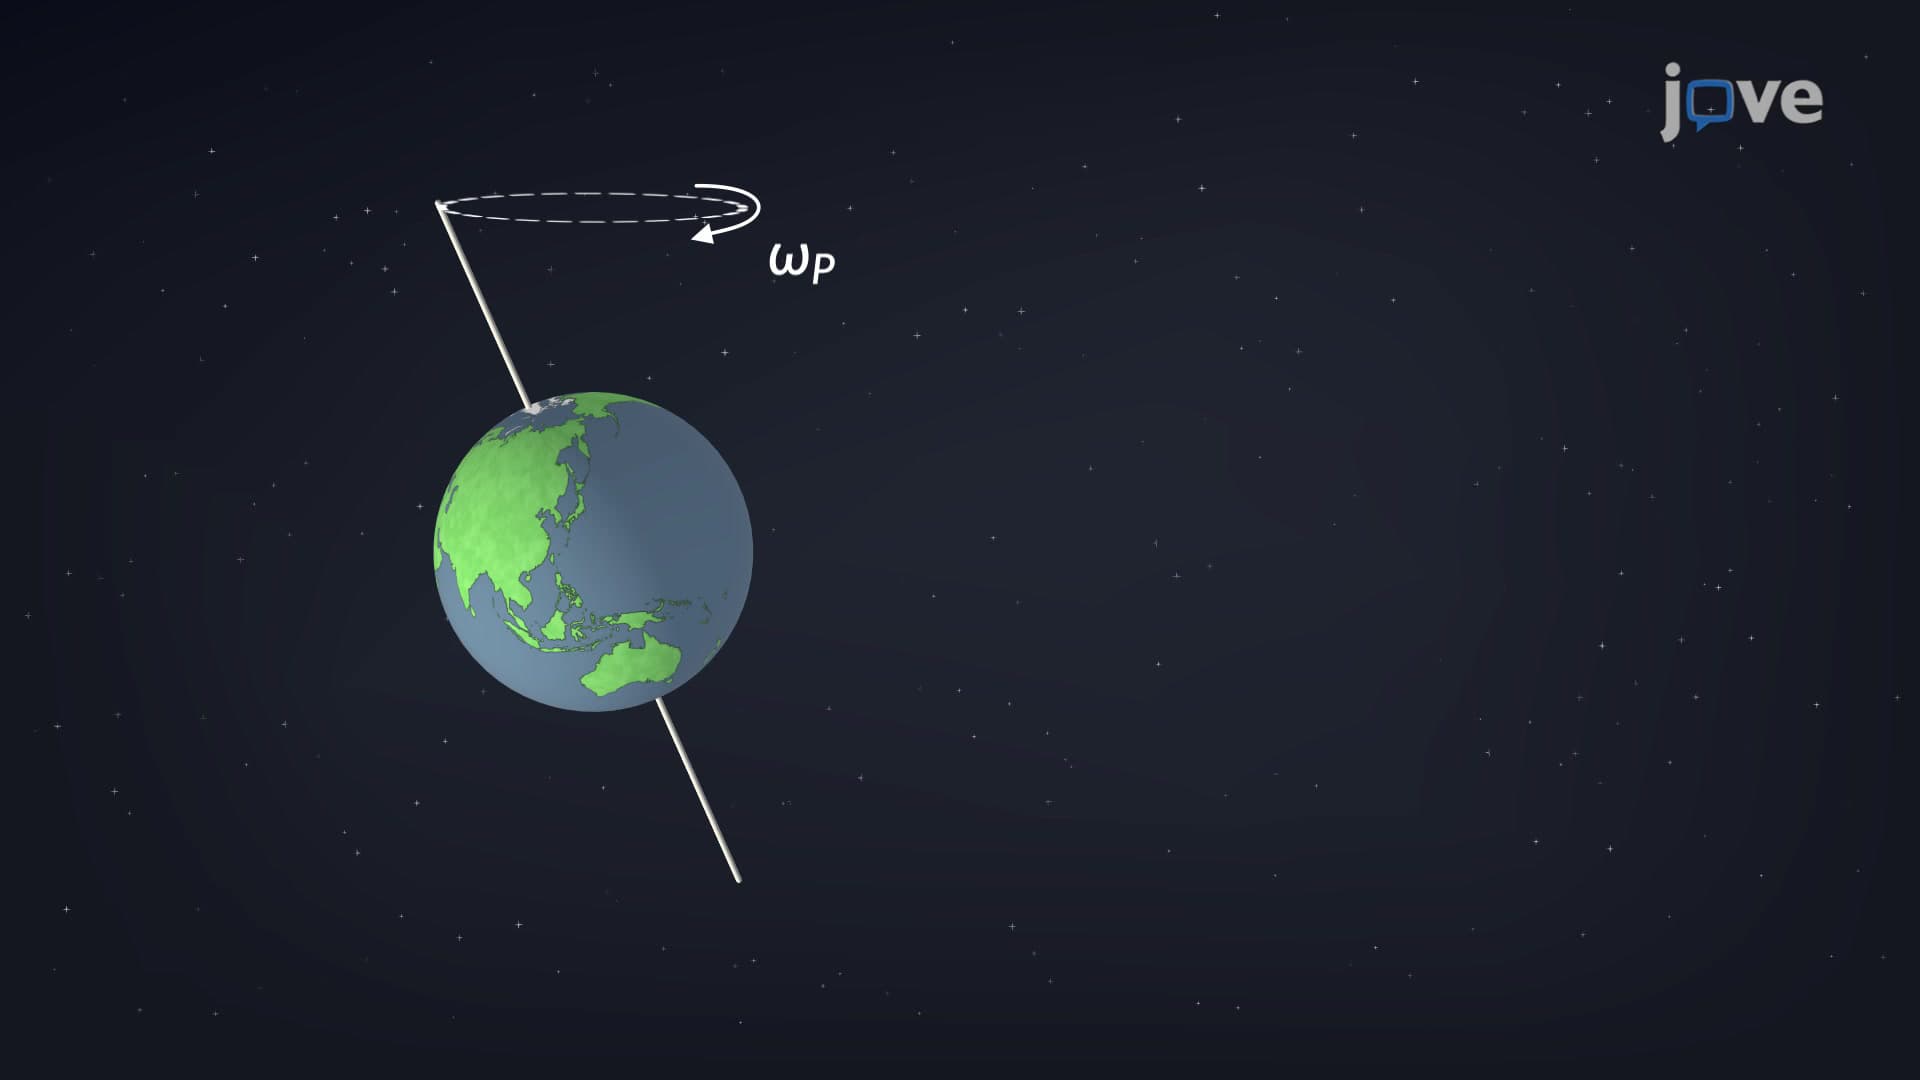
Gyroscope: Precession
 01:26
Errors in Global Positioning System