Related Experiment Video
Updated: Apr 18, 2026

Author Spotlight: Enhancing Neurorehabilitation Through EEG, Motor Imagery, and Virtual Reality
Published on: May 10, 2024
Timing of continuous motor imagery: the two-thirds power law originates in trajectory planning
Matan Karklinsky1, Tamar Flash2
1Department of Computer Science and Applied Mathematics, Weizmann Institute of Science, Rehovot, Israel matan.karklinsky@weizmann.ac.il.

Abstract:
The two-thirds power law, v = γκ(-1/3), expresses a robust local relationship between the geometrical and temporal aspects of human movement, represented by curvature κ and speed v, with a piecewise constant γ. This law is equivalent to moving at a constant equi-affine speed and thus constitutes an important example of motor invariance. Whether this kinematic regularity reflects central planning or peripheral biomechanical effects has been strongly debated. Motor imagery, i.e., forming mental images of a motor action, allows unique access to the temporal structure of motor planning. Earlier studies have shown that imagined discrete movements obey Fitts's law and their durations are well correlated with those of actual movements. Hence, it is natural to examine whether the temporal properties of continuous imagined movements comply with the two-thirds power law. A novel experimental paradigm for recording sparse imagery data from a continuous cyclic tracing task was developed. Using the likelihood ratio test, we concluded that for most subjects the distributions of the marked positions describing the imagined trajectory were significantly better explained by the two-thirds power law than by a constant Euclidean speed or by two other power law models. With nonlinear regression, the β parameter values in a generalized power law, v = γκ(-β), were inferred from the marked position records. This resulted in highly variable yet mostly positive β values. Our results imply that imagined trajectories do follow the two-thirds power law. Our findings therefore support the conclusion that the coupling between velocity and curvature originates in centrally represented motion planning.
Related Concept Videos
 01:18
Hierarchy of Motor Control
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:26
Orthogonal Trajectories
 01:11
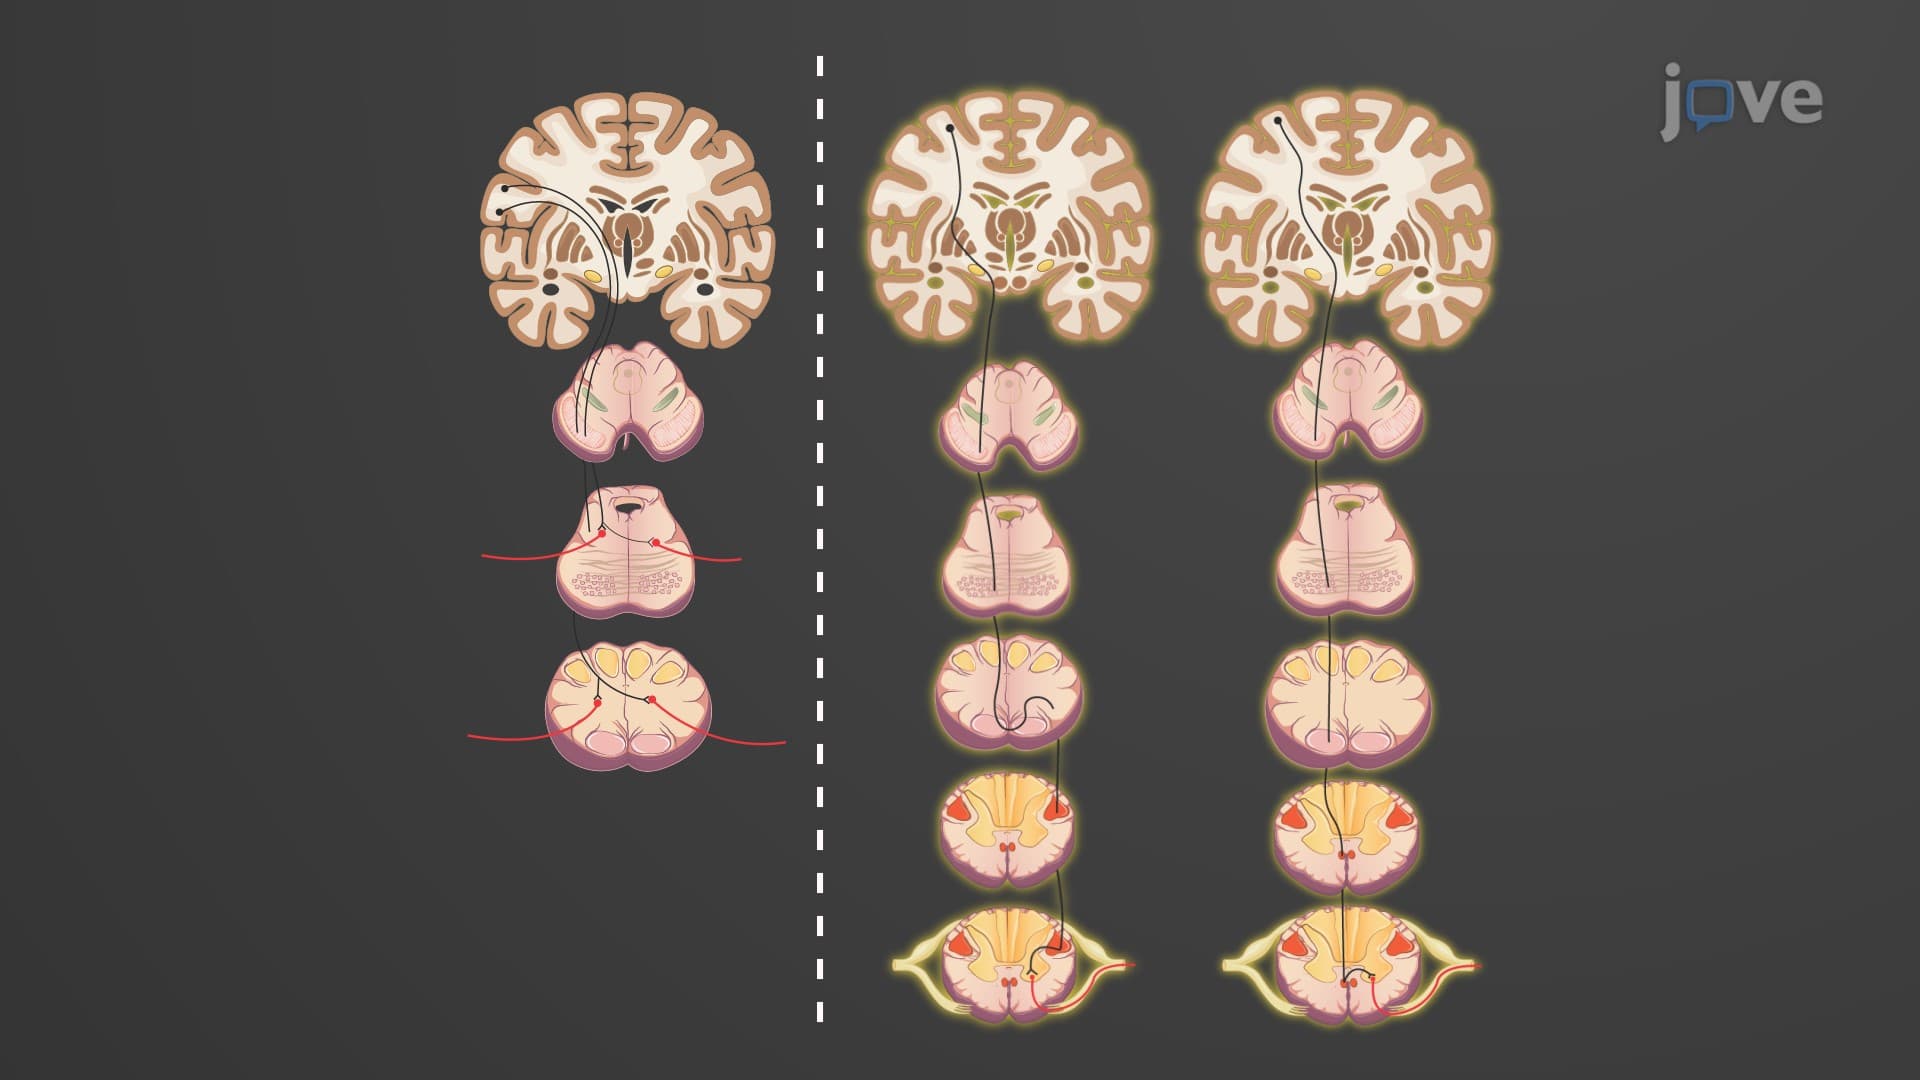
Direct Motor Pathways
The corticospinal tract is responsible for the voluntary movement of the limbs and trunk. It originates in the cerebral cortex of the brain and descends through the cerebrum's internal capsule and...