Related Experiment Video
Updated: Apr 18, 2026


Oscillation and Reaction Board Techniques for Estimating Inertial Properties of a Below-knee Prosthesis
Published on: May 8, 2014
Symmetrical kinematics does not imply symmetrical kinetics in people with transtibial amputation using cycling model
W Lee Childers1, Géza F Kogler
1Cycling Biomechanics Laboratory, School of Applied Physiology, Georgia Institute of Technology, Atlanta, GA; and Department of Prosthetics and Orthotics, Alabama State University, Montgomery, AL;

Abstract:
People with amputation move asymmetrically with regard to kinematics (joint angles) and kinetics (joint forces and moments). Clinicians have traditionally sought to minimize kinematic asymmetries, assuming kinetic asymmetries would also be minimized. A cycling model evaluated locomotor asymmetries. Eight individuals with unilateral transtibial amputation pedaled with 172 mm-length crank arms on both sides (control condition) and with the crank arm length shortened to 162 mm on the amputated side (CRANK condition). Pedaling kinetics and limb kinematics were recorded. Joint kinetics, joint angles (mean and range of motion [ROM]), and pedaling asymmetries were calculated from force pedals and with a motion capture system. A one-way analysis of variance with tukey post hoc compared kinetics and kinematics across limbs. Statistical significance was set to p
Related Concept Videos
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
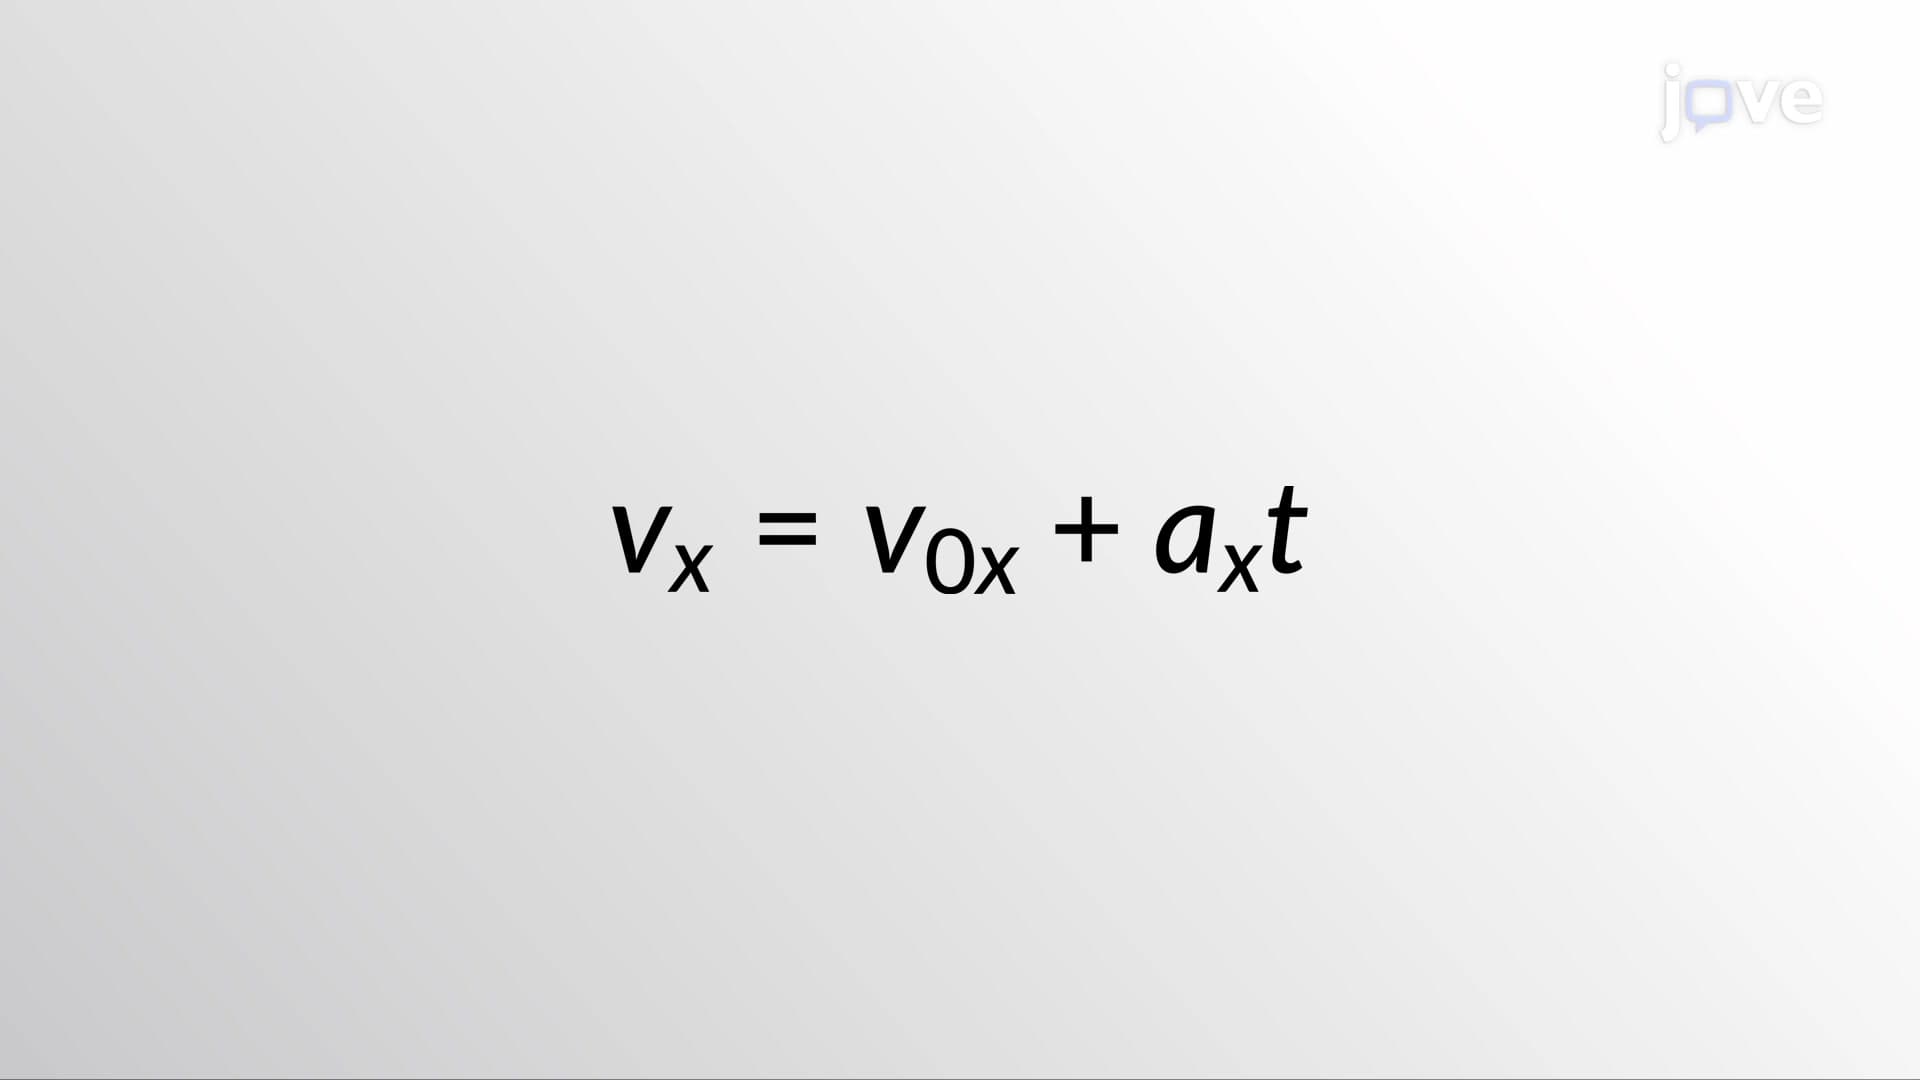 01:26
Kinematic Equations - I
 01:18
Kinematic Equations - III
Using the kinematic equations,...
 01:15
Kinematic Equations: Problem Solving
 01:30
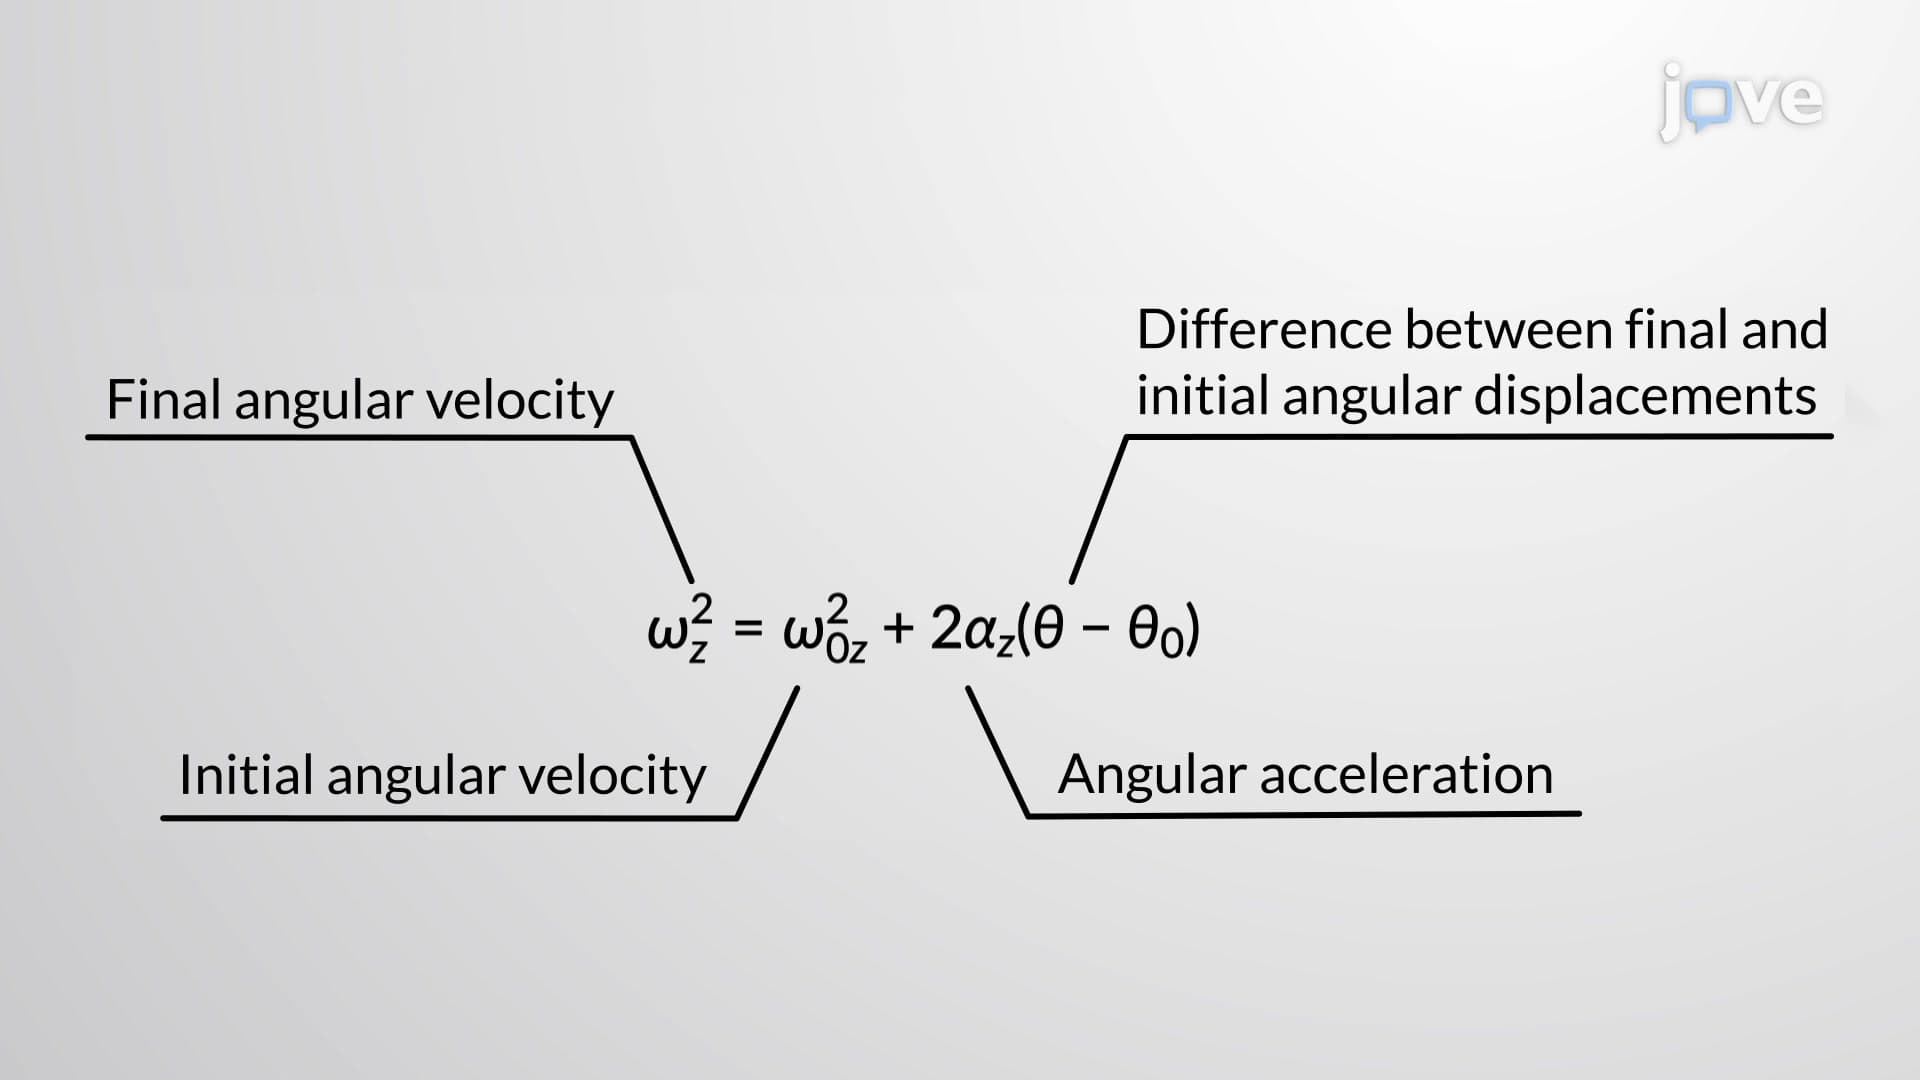
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:16
Rotation with Constant Angular Acceleration - II
The first...